Final Project: Design of an Electric Vehicle
PROJECT:-
Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Objectives:
1. System level configurations
2. Model parameters
3. Results
4. Conclusion
SOLUTION:-
Electric Vehicle (EV)
An electric vehicle (EV) is a vehicle that uses one or more electric motors or traction motors for propulsion. An electric vehicle may be powered through a collector system by electricity from off-vehicle sources or may be self-contained with a battery, solar panels, fuel cells or an electric generator to convert fuel to electricity. EVs include, but are not limited to, road and rail vehicles, surface and underwater vessels, electric aircraft and electric spacecraft.
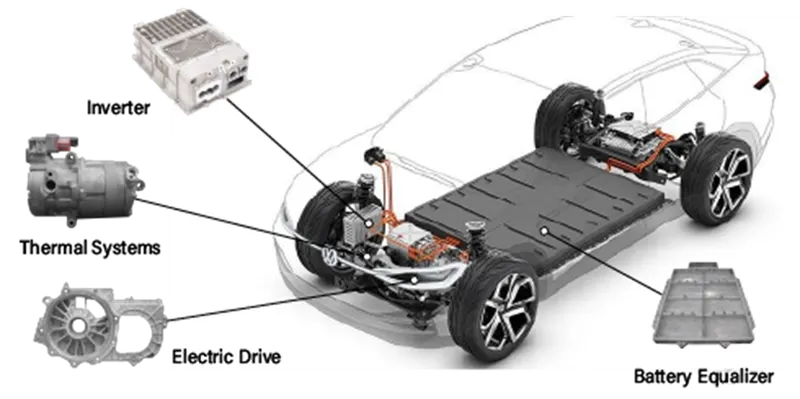
EVs first came into existence in the mid-19th century, when electricity was among the preferred methods for motor vehicle propulsion, providing a level of comfort and ease of operation that could not be achieved by the gasoline cars of the time. Internal combustion engines were the dominant propulsion method for cars and trucks for about 100 years, but electric power remained commonplace in other vehicle types, such as trains and smaller vehicles of all types.
Commonly, the term EV is used to refer to an electric car. In the 21st century, EVs have seen a resurgence due to technological developments, and an increased focus on renewable energy and the potential reduction of transportation's impact on climate change and other environmental issues. Project Drawdown describes electric vehicles as one of the 100 best contemporary solutions for addressing climate change.
Component of the electrical vehicle :
Battery:-
- Most electric vehicles use lithium-ion batteries (Li-Ions or LIBs). Lithium-ion batteries have a higher energy density, longer life span and higher power density than most other practical batteries. Complicating factors include safety, durability, thermal breakdown and cost. Li-ion batteries should be used within the safe temperature and voltage ranges in order to operate safely and efficiently.
- Increasing the battery's lifespan decreases effective costs. One technique is to operate a subset of the battery cells at a time and switching these subsets.
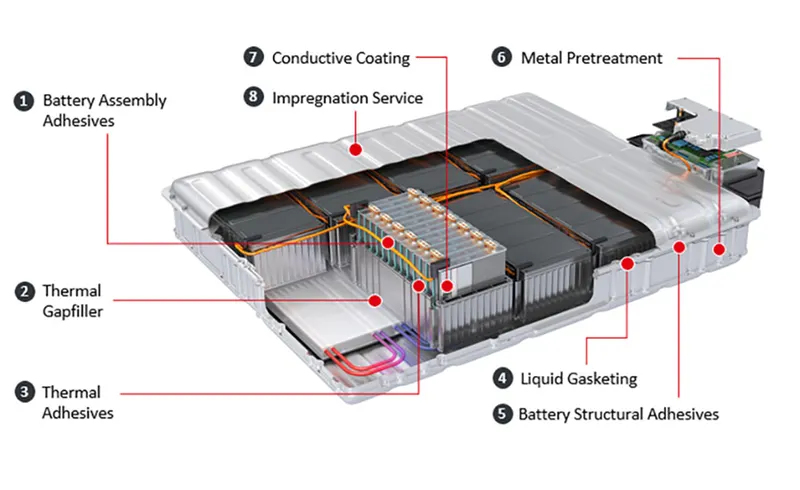
- In the past, nickel-metal hydride battery batteries were used in some electric cars, such as those made by General Motors. These battery types are considered outdated due to their tendencies to self-discharge in the heat. Furthermore, a patent for this type of battery was held by Chevron, which created a problem for their widespread development. These factors, coupled with their high cost, have led to lithium-ion batteries leading as the predominant battery for EVs.
- The prices of lithium-ion batteries are constantly decreasing, contributing to a reduction in the price of electric vehicles.
Electrical Motor:-
- The power of a vehicle's electric motor, as in other machines, is measured in kilowatts (kW). Electric motors can deliver their maximum torque over a wide RPM range.
- This means that the performance of a vehicle with a 100 kW electric motor exceeds that of a vehicle with a 100 kW internal combustion engine, which can only deliver its maximum torque within a limited range of engine speed.
- The efficiency of charging varies considerably depending on the type of charger, and energy is lost during the process of converting the electrical energy to mechanical energy.
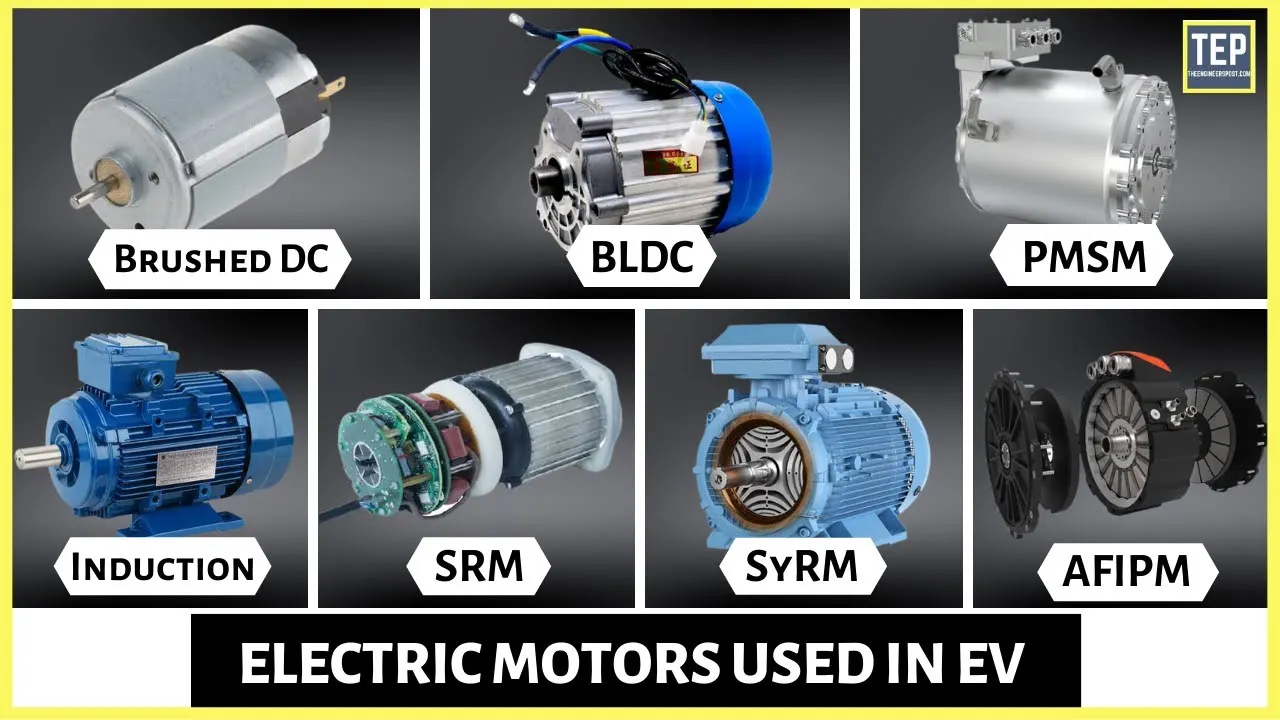
- Usually, direct current (DC) electricity is fed into a DC/AC inverter where it is converted to alternating current (AC) electricity and this AC electricity is connected to a 3-phase AC motor.
- For electric trains, forklift trucks, and some electric cars, DC motors are often used. In some cases, universal motors are used, and then AC or DC may be employed. In recent production vehicles, various motor types have been implemented; for instance, induction motors within Tesla Motor vehicles and permanent magnet machines in the Nissan Leaf and Chevrolet Bolt
Motor Controller:
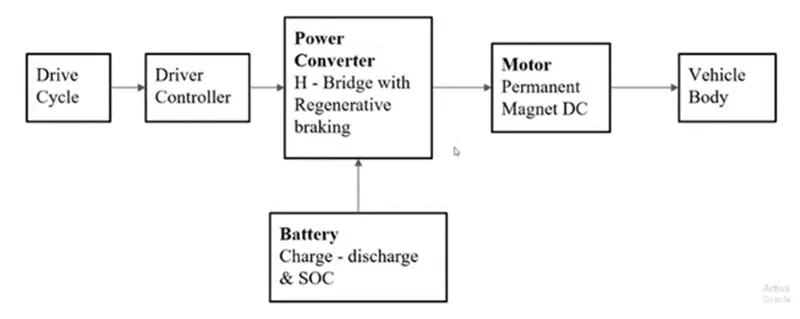
The motor controller of an electric car administers its complete operation and the distribution of its power at any given moment. It acts as a floodgate between the motor and batteries.
It helps monitor and regulates all key performance indications such as the vehicle's operator, motor, battery, and accelerator pedal. It has a microprocessor that can limit or redirect current.
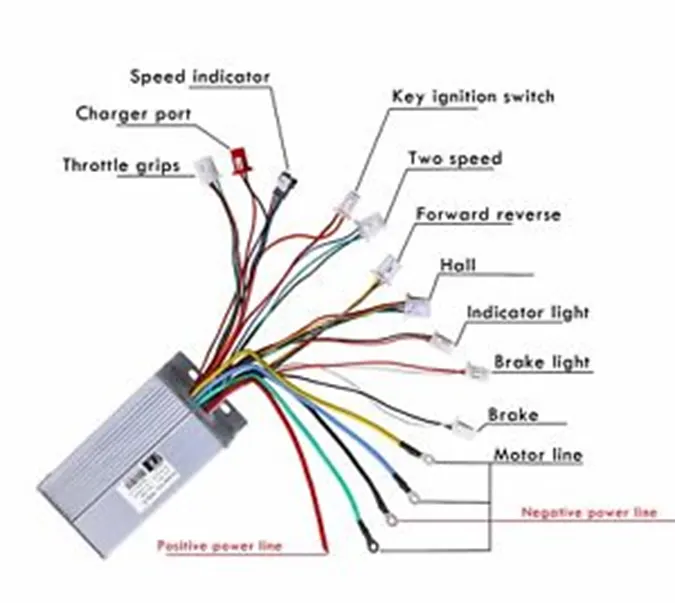
It is used to either improve the mechanical performance of the car or suit the operator's driving style. There are also more refined controllers which are capable of greater accuracy and thus, higher efficiency.
Methods:-
1.Vehicle body and tire subsystem:-
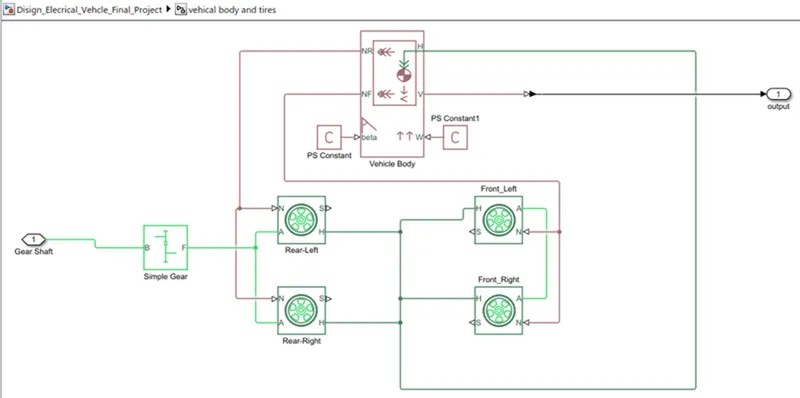
- Represents a two-axle vehicle body in motion.
- Accounts for body mass, aerodynamic drag. grade, externally defined mass and centre of gravity of the vehicle body.
o Input Ports:
W=Wind Velocity in m/s
beta=Grade angle in radians
o Output Ports:
V=Velocity in m/s
NR=Normal force on Rear Axle (N)
NF=Normal Force on Front Axle (N)
Vehicle Body Parameters:
- Vehicle body mass, Centre of gravity distance values and aerodynamic drag
variables are modified. Pitch dynamics are kept ON with other variable values as default values.
1.1Tire:
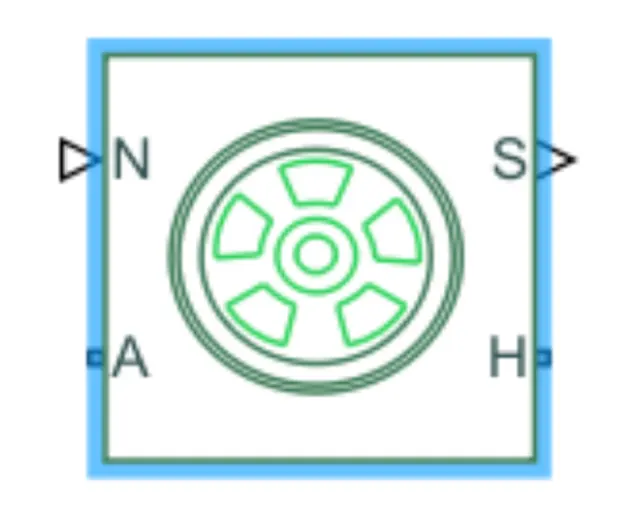
The vehicle is assumed to be front axle is driven (4 wheels- 2 on each axle).
The wheels are modelled using simple Tire (Magic formula) Simulink blocks.
The block can model tire dynamics under constant or variable contact surface
conditions.
- Input Port:
N=Normal force acting on the tire, positive when force is acting downwards/towards the contact surface.
- Output Port:
S=Slip value is relative to tire and surface of contact.
- Conserving Ports:
H=represents wheel hub which transmits thrust generated by the wheel to the body of the vehicle.
A=represents the axle on which the tires are mounted.
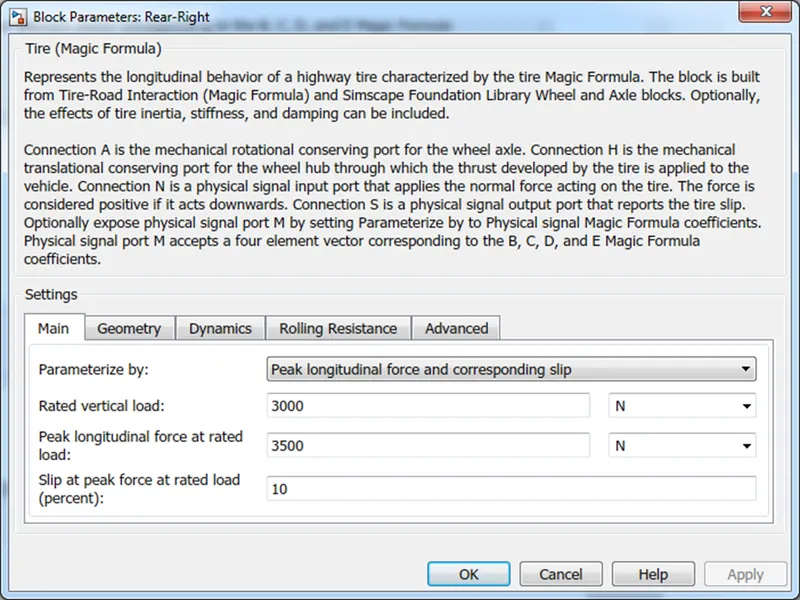
- The tires are parameterized by Peak longitudinal force and corresponding slip
- The other block parameters such as rated vertical load, peak longitudinal force at rated load and slip at peak force at rated load - are kept with their default values.
1.2 Gear:
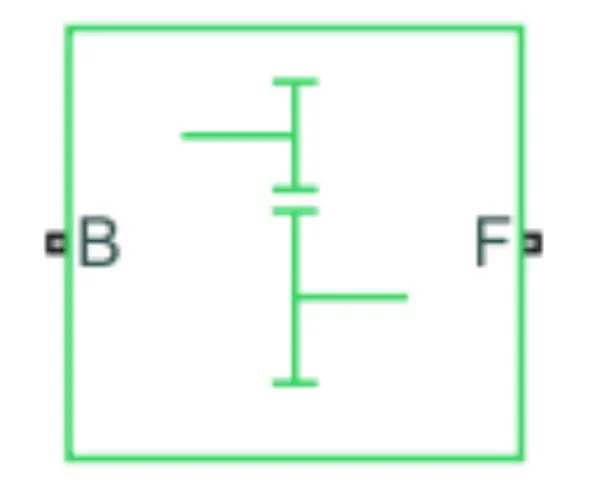
A simple gear block is used to connect the motor to the rear axle of the vehicle.
It represents the gearbox that connects the input shaft to the base gear and output from the follower gear.
Conserving Ports:
B=port associated with an input shaft (motor shaft)
F=port associated with the output shaft (axle/ differential)
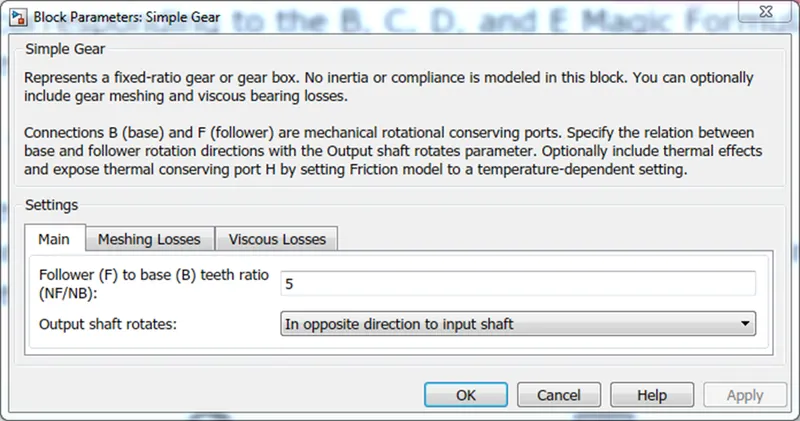
Simple Gear Parameters:
Gear ratio and output direction are modified. Meshing loss is kept constant and gear is having a constant efficiency throughout the simulation.
Viscous losses and faults are kept at default conditions
1.3 Vehicle Body:-
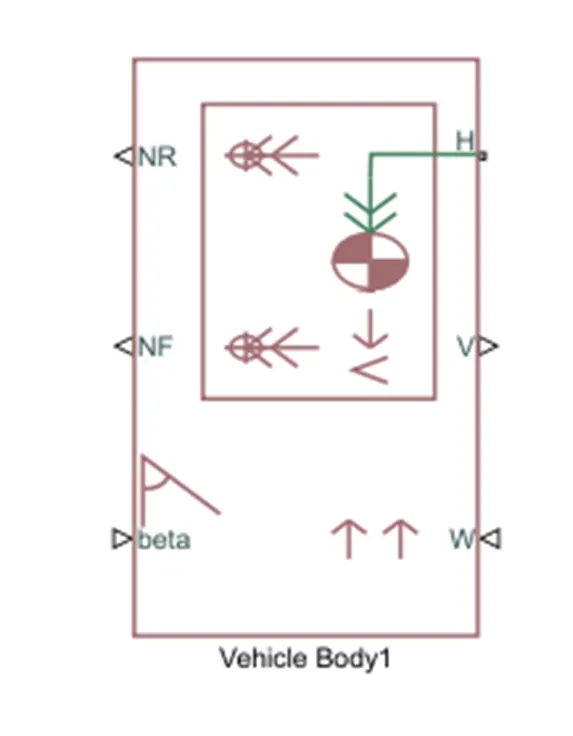
- This block basically represents a two-axle vehicle body in longitudinal motion. The block accounts for - body mass, aerodynamic drag, road incline, weight distribution between axles due to acceleration road profile.
- Here, connection H is the mechanical translational conserving port hub.
- NF & NR correspond to the output ports for normal reaction forces on the front axle and rear axle wheels respectively.
- Connection V represents the actual output translational velocity of the vehicle.
- beta is the road inclination angle & W corresponds to the headwind speed (headwind direction opposite to that of the vehicle).
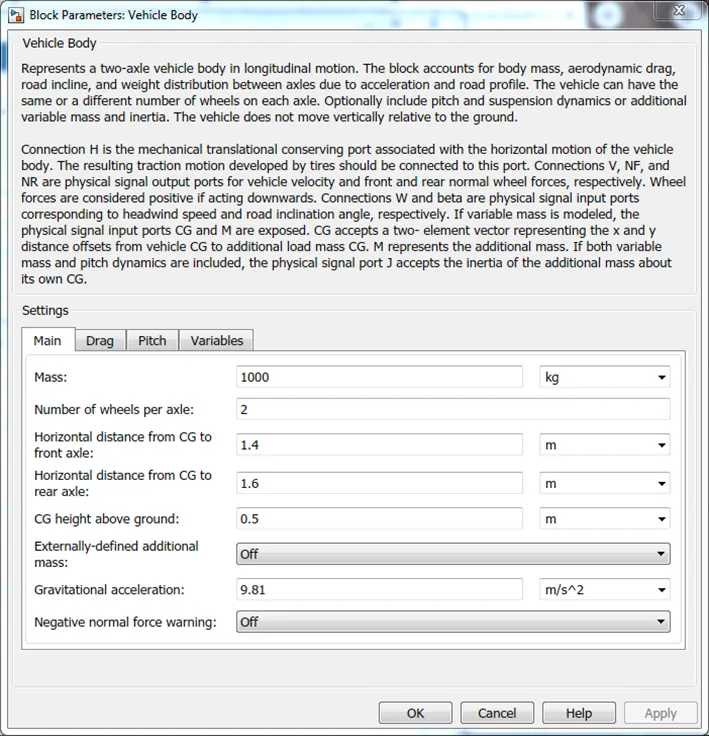
- The gross weight is given to be 1000 kg
- The geometric parameters of the vehicle are given as -
2. Power and Motor Controlled Subsystem:-
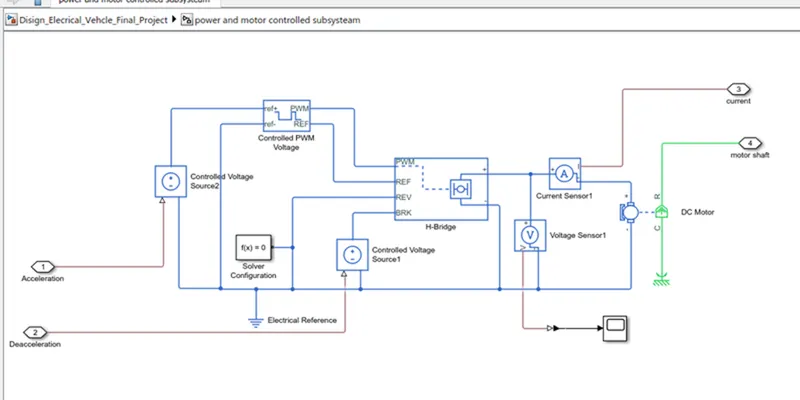
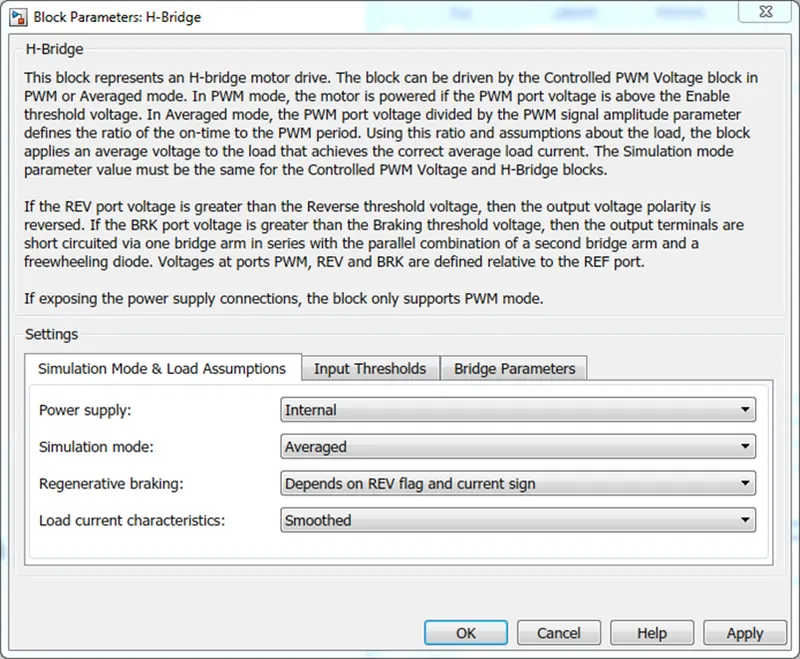
2.1 H-Bridge:-
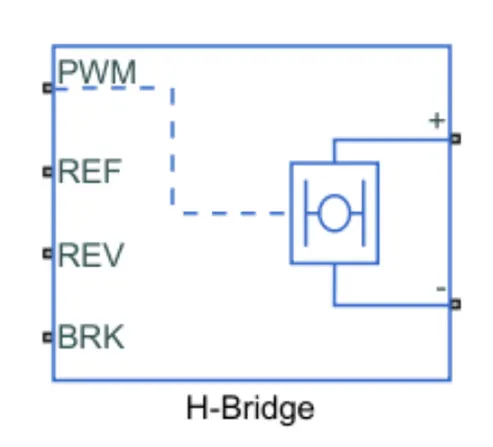
The H-Bridge helps in controlling the power that is input according to the requirement. The output provided is converted voltage as per the controlled parameters.
2.2 D.C Motor:-
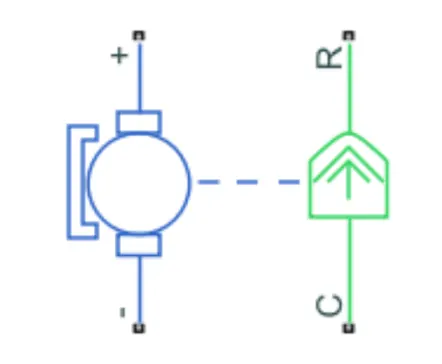
This is the DC Motor which would give rotational power to the wheels and become the sole power generation source.
The DC Motors terminals are connected as mentioned below.
+ =Electrical signal to the motor Positive Terminal
- =Electrical signal to the motor Negative Terminal
R=Casing of the Motor connected with the Mechanical Rotational Reference Block
C=Rotor Case connected to the Mechanical Rotational reference
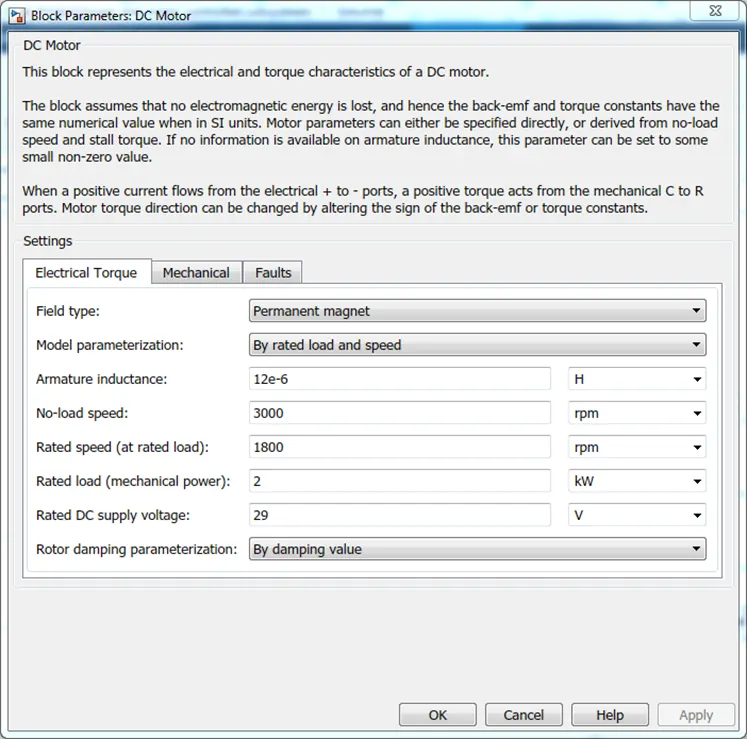
The parameter considered is, The Armature inductance is as default, varied the changes in the No-Load Speed 3000 rpm, the rated speed 1800 rpm, the Rated Load at 2kW, and the Rated DC Supply Voltage 29 V. All other parameters are as default.
2.3 Controlled PWM Voltage:
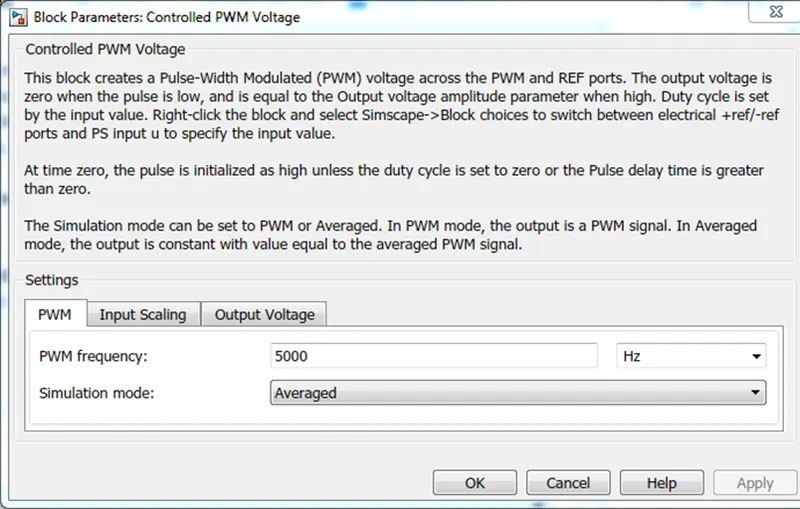
The Controlled PWM Voltage Block helps in keeping the Modulated Pulses as per the required pulses. So that the operations happen smooth and higher variations are not observed.
The Ports are connected as follows.
PWM=PWM connected directly to the H-Block
REF=REF connected directly to the H-Block
ref+ = Reference Positive connected with Driver Model ith the Acceleration Commands from the
ref- =Reference Negative connected with the Deceleration Commands from the Driver Model
Note: The parameters are set as default.
3 Battery and SOC System:-
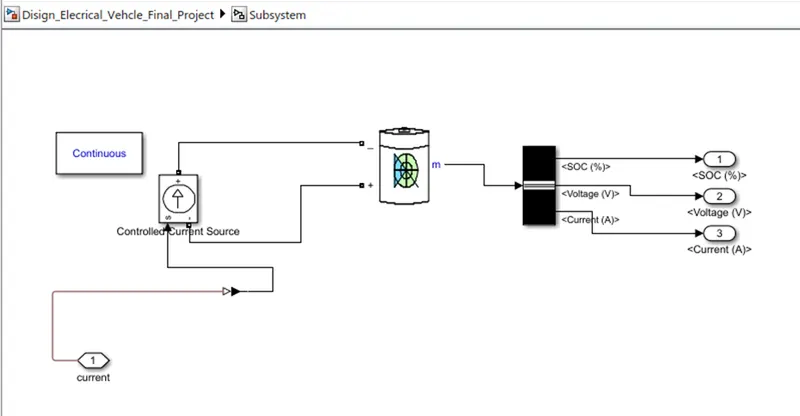
3.1 Battery:-
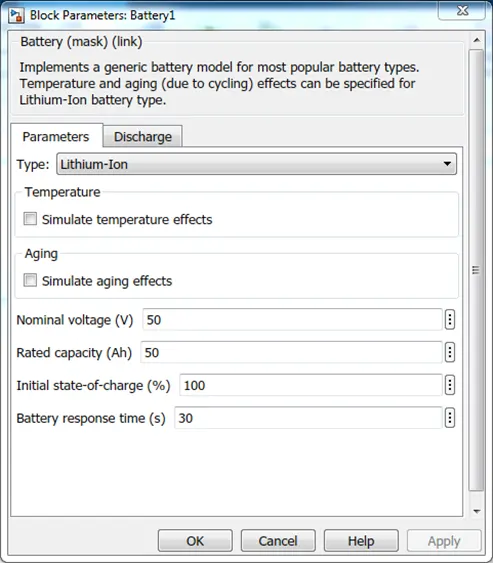
Implements a generic battery model for most popular battery types. Temperature and ageing (due to cycling) effects can be specified for Lithium-Ion battery type.
3.2 controlled Current Source:-
a controlled current source is connected to the lithium battery. this controlled current source provided will initiate the flow of current from the battery to the motor and during regenerative braking from the motor to the battery.
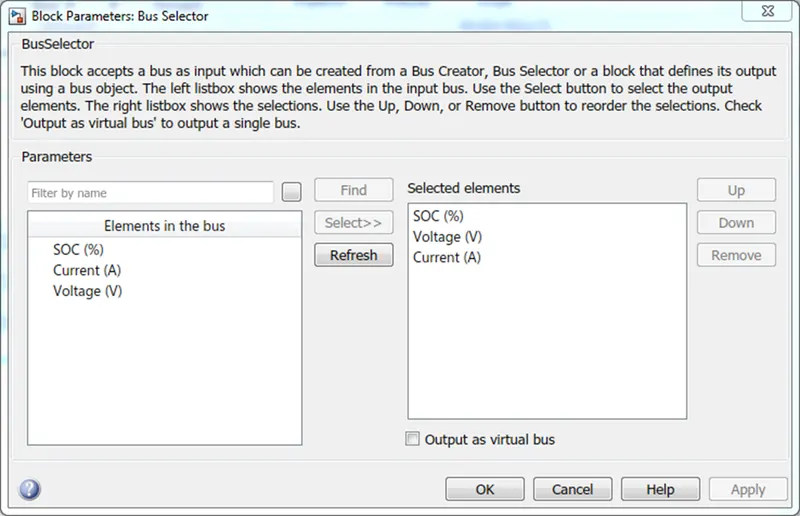
3.3 Bus selector
4 Longitudinal Driver:
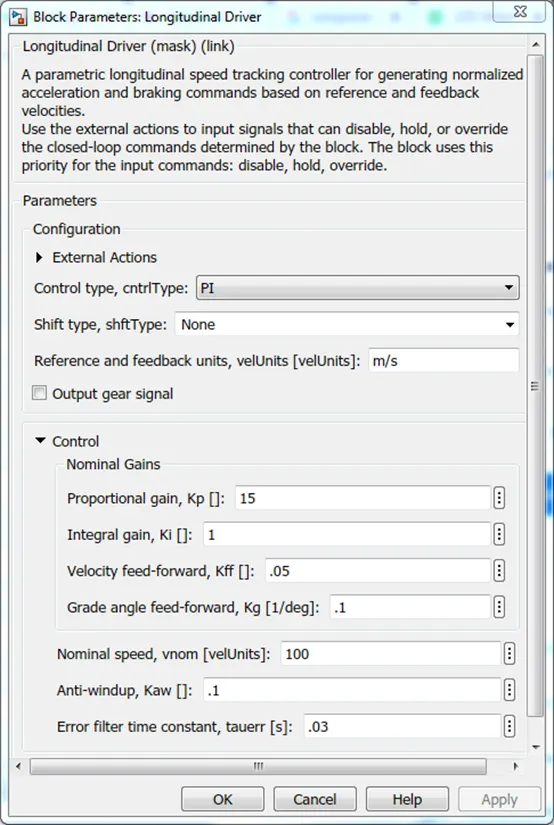
- Longitudinal Driver is an inbuilt block provided by the powertrain blocks.
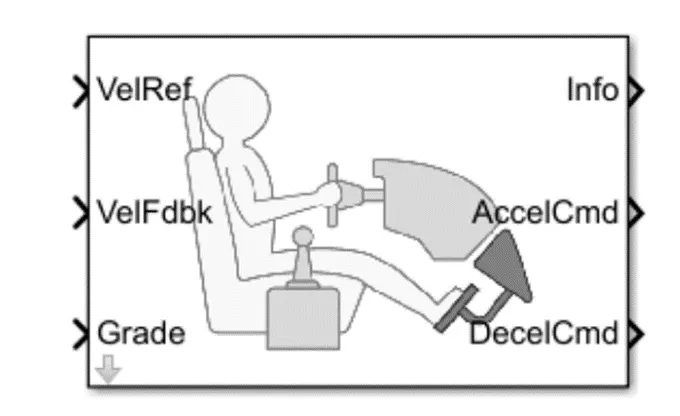
- It is a parametric longitudinal speed tracking controller for generating normalized Acceleration and Braking commands based on reference and feedback velocities,
- The VelFdbk port corresponds to the feedback velocity. The actual velocity output given by the vehicle body is connected here. By comparing the actual (feedback) velocity with the reference velocity, the driver block generates acceleration and braking signals in order to minimise the error between the two concerned velocities.
- Grade corresponds to the grade angle. For this simulation, no inclination is considered and hence, a constant block with value 0 is connected.
- Info gives the output for the bus signal for different block calculations like the difference in reference vehicle speed and vehicle speed, etc.
- AccelCmd & DecelCmd correspond to the acceleration and deceleration commands generated respectively and are connected to the corresponding ports of the Controlled PWM Voltage block Here, the selected control type is Pl. Accordingly, the block implements proportional-integral (PI) control with tracking windup and feed-forward gains.
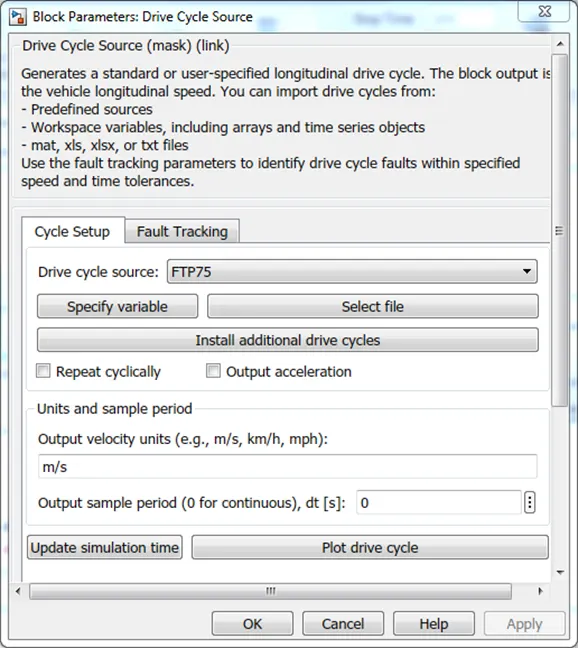
5 Reference Velocity (Drive Cycle):
- The Drive Cycle Source block is used to provide the reference speed for the simulation.
- It generates a standard or user-specified longitudinal drive cycle.
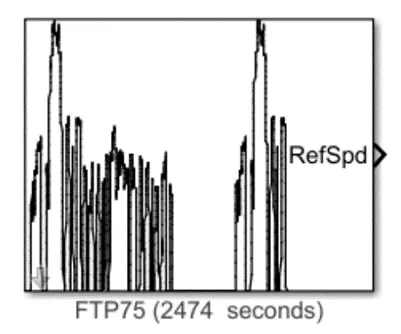
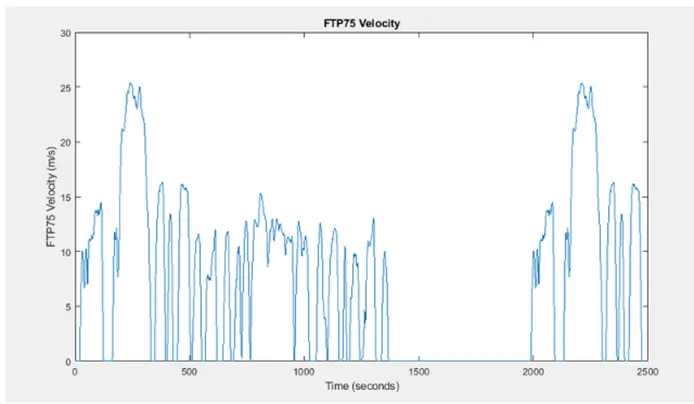
this is the plot of the FTP75 drive cycle
7 Distance in km/hr
The scope will display velocity of the vehicle in km/hr to measure the distance in km, an integrator block is used because the interaction of velocity will give us distance and 3600 constant blocks are used because 1hr=3600sec
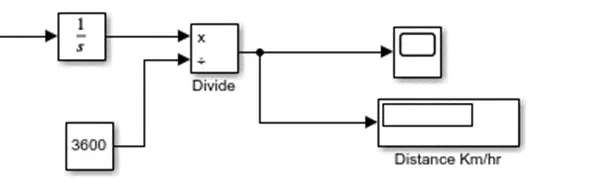
thus scope 5 will give a distance graph
8 Simulink Explanation:-
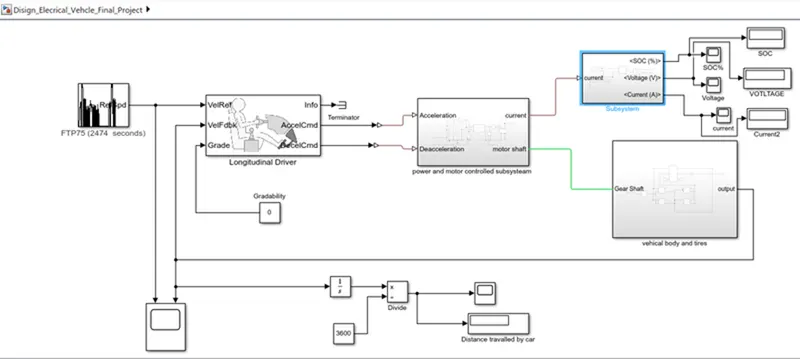
The system is running for simulation for 1000s which is the total time for which the input drive cycle is defined.
A Solver Configuration is added to ensure proper solving of the mathematical equations by the model.
- Scopes are connected to analyze different outputs such as the SOC of the battery, the reference velocity & the actual velocity of the vehicle and the distance covered by the vehicle during the total run
RESULTS:-
1)
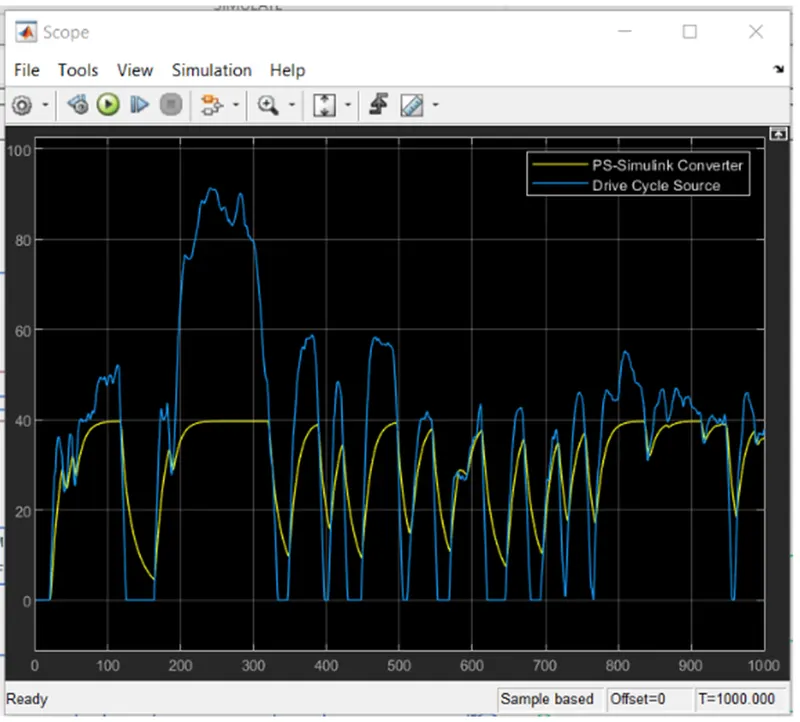
The blue line is a graph of the drive cycle source and the yellow line shows the corresponding velocity graph
2)
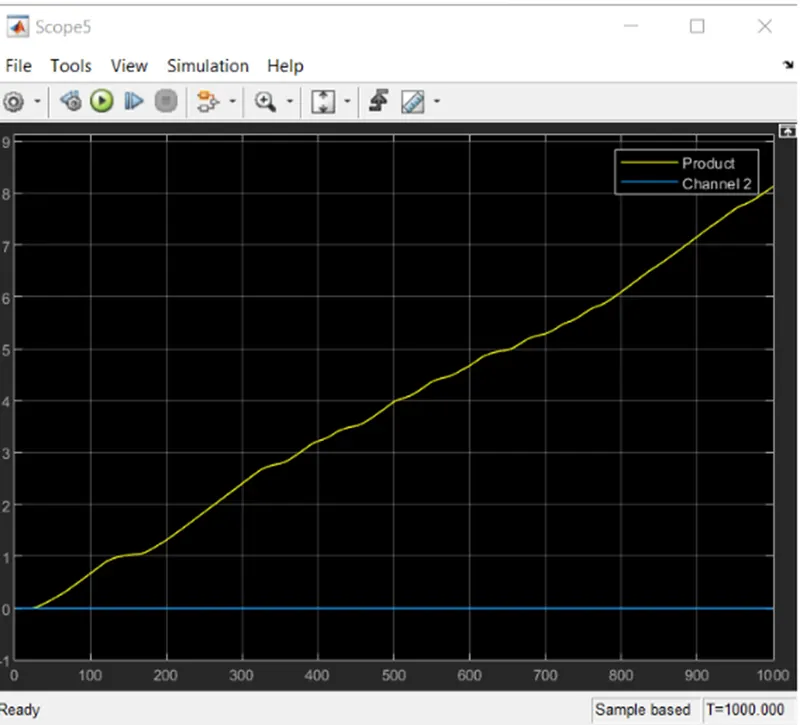
the yellow line shows the distance covered by the electrical car
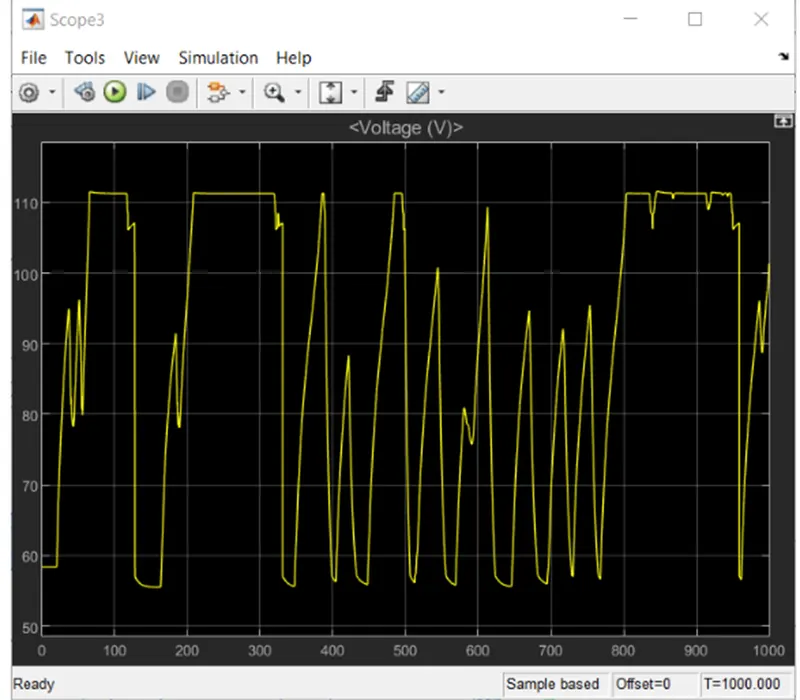
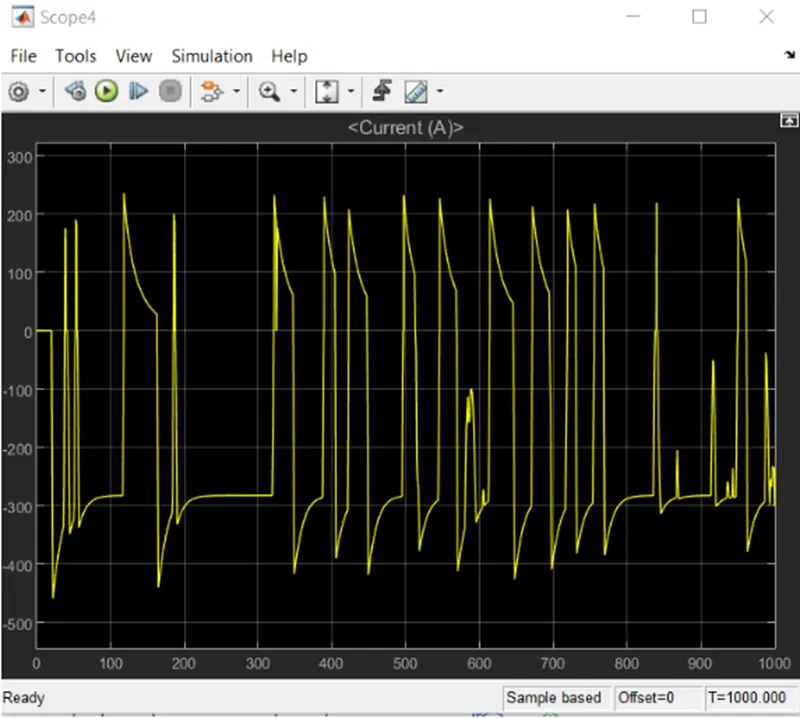
3) SOC calculation:
the change of SOC is given below
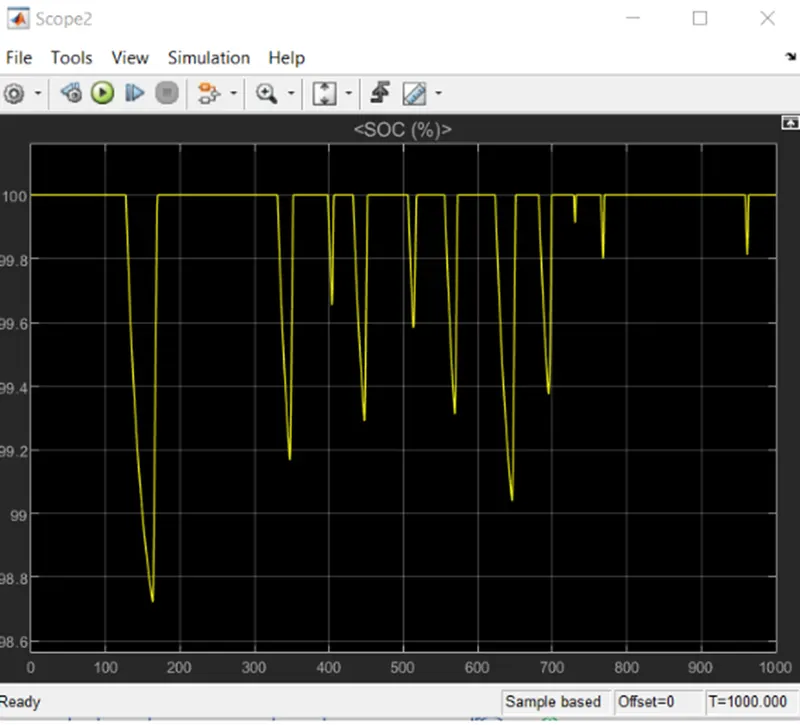
the change of battery voltage is given below
the change of battery current is given below
CONCLUSION:
from the above model and from the assumed parameters we found that the velocity of an electric vehicle is 35.96 km and the distance covered by the electric vehicle is 8:121 km and also the variation of SOC and the battery current and battery voltage is also studied.