Final Project: Design of an Electric Vehicle
ELECTRIC VEHICLE MODEL:-
The EV model is divided into 6 major parts as below:-
- Vehicle body
- Motor
- Power converter
- Driver controller
- Drive cycle source
- Battery system
The prediction of range of a vehicle is important concept for design of vehicle. In order to determine the performance of vehicle, the important parameter to be focused on is acceleration on top seed where the vehicles always have poor response. it is also mandatory to predict the range of vehicle. Now we see the simulation of the electric vehicle model to calculate the distance traveled by the vehicle. Also compare with the actual vehicle and drive cycle.
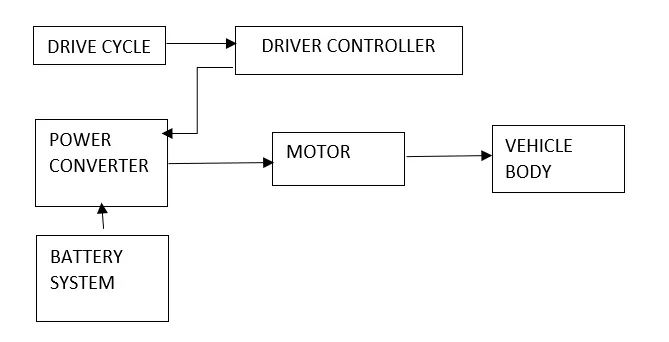
ELECTRIC MODEL:-
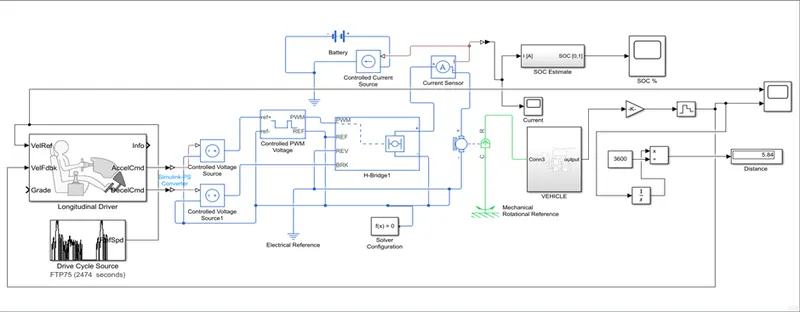
Following blocks are used in ELECTRICAL VEHICLE MODEL:-
1) VEHICLE BODY:-
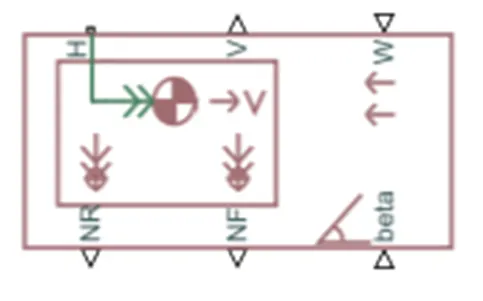
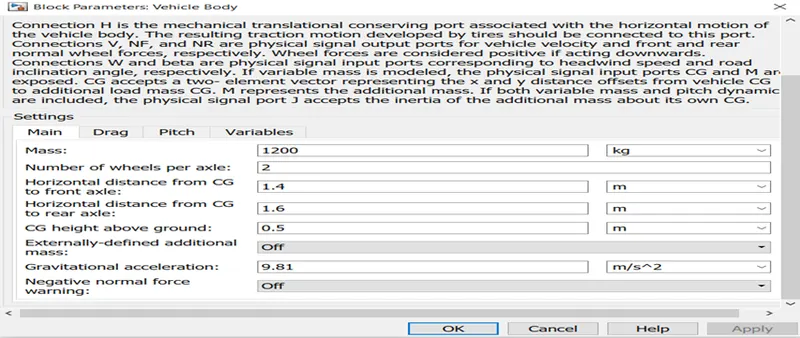
- The Vehicle Bodyblock represents a two-axle vehicle body in longitudinal motion. The vehicle can have the same or a different number of wheels on each axle.
- For example, two wheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed identical in size.
- The vehicle can also have a centre of gravity (CG) that is at or below the plane of travel.
- The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile.
- Optionally include pitch and suspension dynamics. The vehicle does not move vertically relative to the ground.
- The block has an option to include an externally-defined mass and an externally-defined inertia.
- The mass, inertia, and centre of gravity of the vehicle body can vary over the course of simulation in response to system changes.
- TIRE BLOCK:-
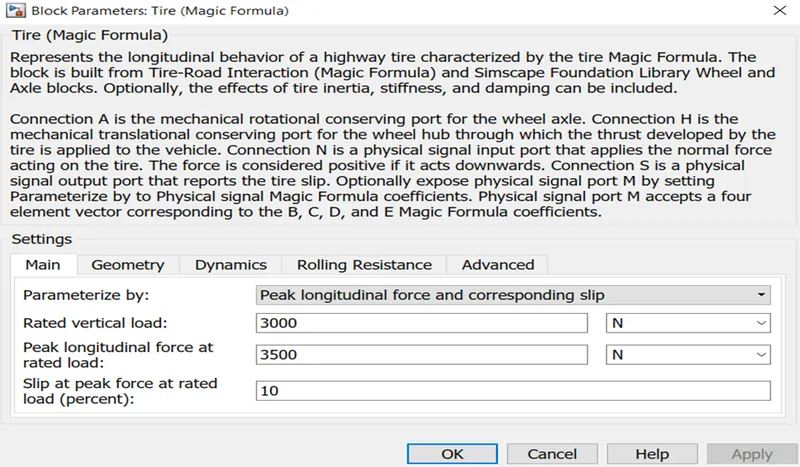
- The Tire (Magic Formula) block models a tire with longitudinal behavior given by the Magic Formula [1], an empirical equation based on four fitting coefficients.
- The block can model tire dynamics under constant or variable pavement conditions.
- The longitudinal direction of the tire is the same as its direction of motion as it rolls on pavement. This block is a structural component based on the Tire-Road Interaction (Magic Formula)
- To increase the fidelity of the tire model, you can specify properties such as tire compliance, inertia, and rolling resistance. However, these properties increase the complexity of the tire model and can slow down simulation.
- Consider ignoring tire compliance and inertia if simulating the model in real time or if preparing the model for hardware-in-the-loop (HIL) simulation.
Model
- The vehicle axles are parallel and form a plane. The longitudinal, x, direction lies in this plane and perpendicular to the axles. If the vehicle is traveling on an incline slope, β, the normal, z, direction is not parallel to gravity but is always perpendicular to the axle-longitudinal plane.
- SIMPLE GEAR BLOCK:-
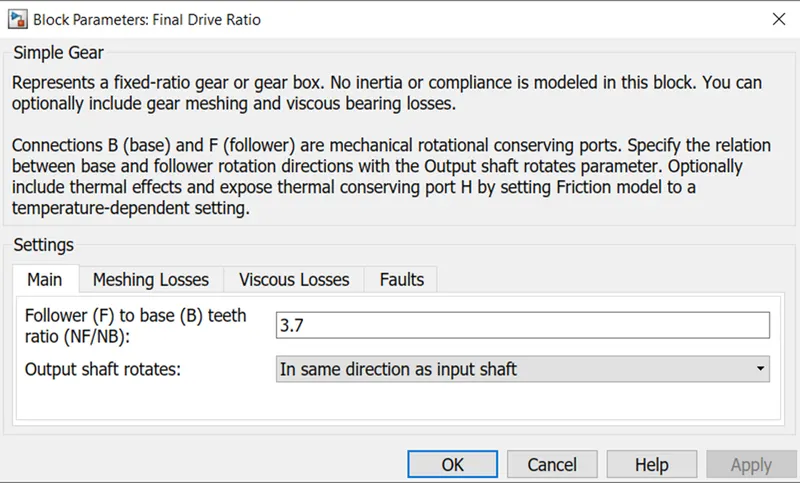
- The Simple Gearblock represents a gearbox that constrains the connected driveline axes of the base gear, B, and the follower gear, F, to corotate with a fixed ratio that you specify.
- You choose whether the follower axis rotates in the same or opposite direction as the base axis.
- If they rotate in the same direction, the angular velocity of the follower, ωF, and the angular velocity of the base, ωB, have the same sign. If they rotate in opposite directions, ωFand ωBhave opposite signs
B] POWER CONTROLLER BLOCKS:-
- CONTROLLED PWM VOLTAGE:-
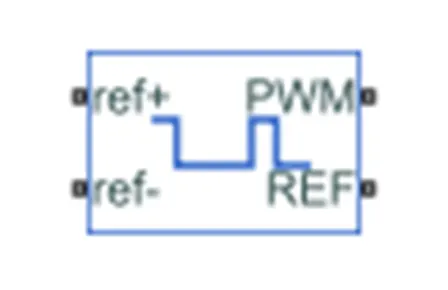
- The Controlled PWM Voltage block represents a pulse-width modulated (PWM) voltage source.
- The block has two modelling variants, accessible by right-clicking the block in your block diagram and then selecting the appropriate option from the context menu, under Simscape> Block choices:
- Electrical input ports— The block calculates the duty cycle based on the reference voltage across its ref+ and ref- This modelling variant is the default.
- PS input— Specify the duty cycle value directly by using an input physical signal port.
For the Electrical input ports variant of the block,
- The value of the Output voltage amplitudeparameter determines amplitude of the output voltage.
- At time zero, the pulse is initialized as high, unless the Pulse delay timeparameter is greater than zero, or the demanded duty cycle is zero.
- You can use parameters Pulse delay timeand Pulse width offsetto add a small turn-on delay and a small turn-off advance. This can be useful when fine-tuning switching times so as to minimize switching losses
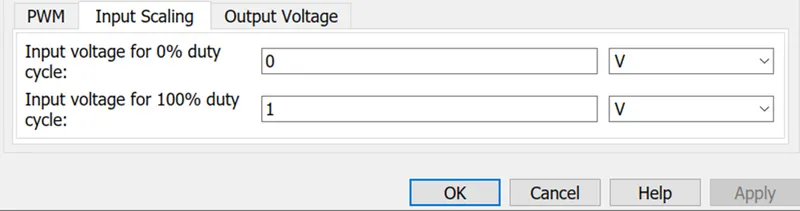
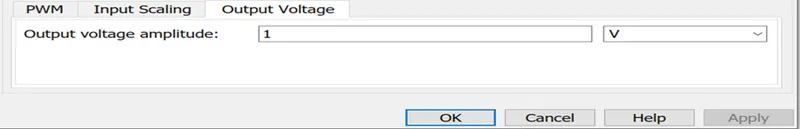
No changes made in the PWM block parameters
Input voltage for 100% duty is 1 V and output voltage amplitude is 1V
- H-Bridge:-
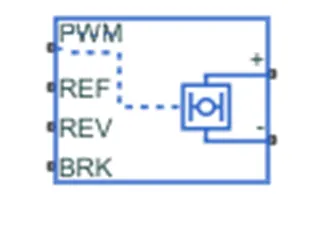
- This block represents an H-bridge motor drive.
- The block can be driven by the Controlled PWM Voltage block in PWM or Averaged mode.
- In PWM mode, the motor is powered if the PWM port voltage is above the Enable threshold voltage.
- In Averaged mode, the PWM port voltage divided by the PWM signal amplitude parameter defines the ratio of the on-time to the PWM period.
- Using this ratio and assumptions about the load, the block applies an average voltage to the load that achieves the correct average load current.
- The Simulation mode parameter value must be the same for the Controlled PWM Voltage and H-Bridge blocks.
- If the REV port voltage is greater than the Reverse threshold voltage, then the output voltage polarity is reversed.
- If the BRK port voltage is greater than the Braking threshold voltage, then the output terminals are short circuited via one bridge arm in series with the parallel combination of a second bridge arm and a freewheeling diode.
- Voltages at ports PWM, REV and BRK are defined relative to the REF port.
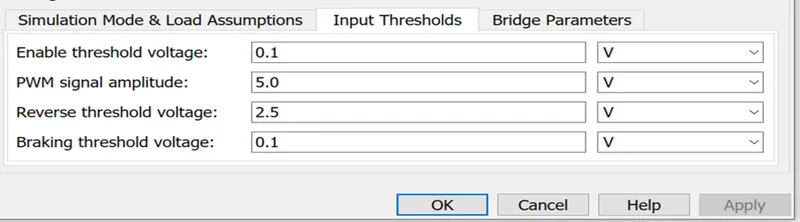
- Input threshold voltage is 0.1 v
- Reverse threshold voltage is 2.5v
- DC MOTOR:-
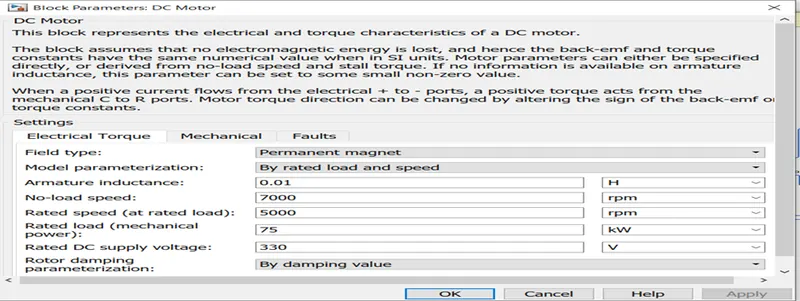
- This block represents the electrical and torque characteristics of a DC motor.
- The block assumes that no electromagnetic energy is lost, and hence the back-emf and torque constants have the same numerical value when in SI units. Motor parameters can either be specified directly, or derived from no-load speed and stall torque.
- If no information is available on armature inductance, this parameter can be set to some small non-zero value.
- When a positive current flows from the electrical + to - ports, a positive torque acts from the mechanical C to R ports.
- Motor torque direction can be changed by altering the sign of the back-emf or torque constants.
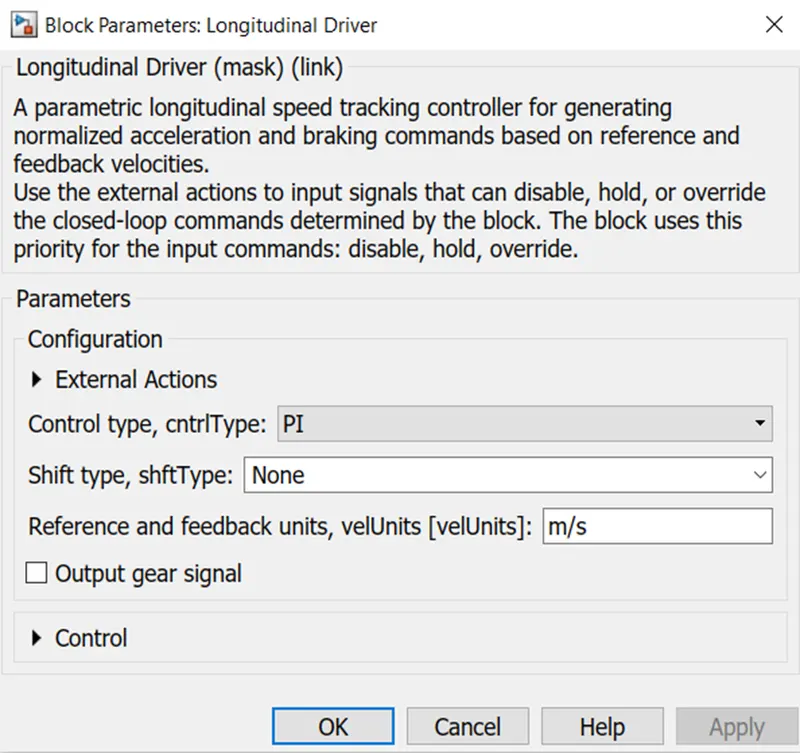
C] LONGITUDINAL DRIVER:-
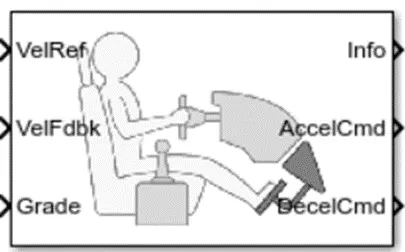
- The Longitudinal Driverblock implements a longitudinal speed-tracking controller.
- Based on reference and feedback velocities, the block generates normalized acceleration and braking commands that can vary from 0 through 1.
- You can use the block to model the dynamic response of a driver or to generate the commands necessary to track a longitudinal drive cycle
- Use the External Actionsparameters to create input ports for signals that can disable, hold, or override the closed-loop acceleration or deceleration commands.
- The block uses this priority order for the input commands: disable (highest), hold, override
D] DRIVE CYCLE SOURCE:-
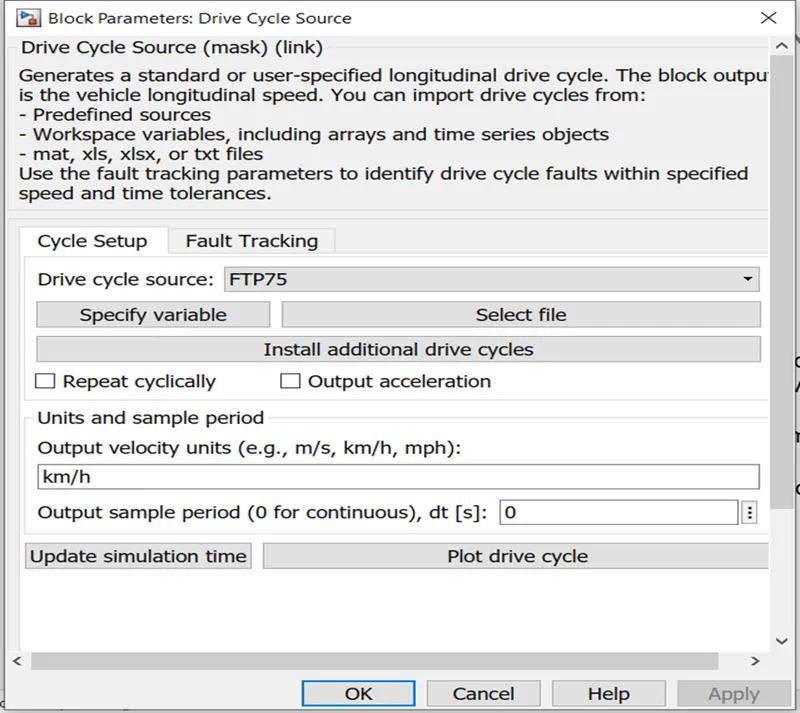
- Generates a standard or user-specified longitudinal drive cycle. The block output is the vehicle longitudinal speed. You can import drive cycles from:
- Predefined sources
- Workspace variables, including arrays and time series objects
- mat, xls, xlsx, or txt files
- Use the fault tracking parameters to identify drive cycle faults within specified speed and time tolerances.
F] CONTROLLED VOLTAGE SOURCE:-
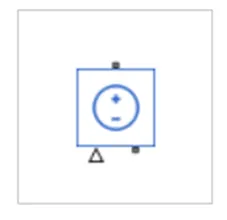
- This is the simscape model which is driven by the input signal
The Controlled Voltage Sourceblock represents an ideal voltage source that is powerful enough to maintain the specified voltage at its output regardless of the current flowing through the source. - The output voltage is V = Vs, where Vsis the numerical value presented at the physical signal port.
- The block has one physical signal input port and two electrical conserving ports associated with its electrical terminals
G] Controlled Current Source:-
- The Controlled Current Sourceblock represents an ideal current source that is powerful enough to maintain the specified current through it regardless of the voltage across the source.
- The output current is I = Is, where Isis the numerical value presented at the physical signal port.
- The positive direction of the current flow is indicated by the arrow.
- The block has one physical signal input port and two electrical conserving ports associated with its electrical terminals.
H] UNIT CONVESION:-
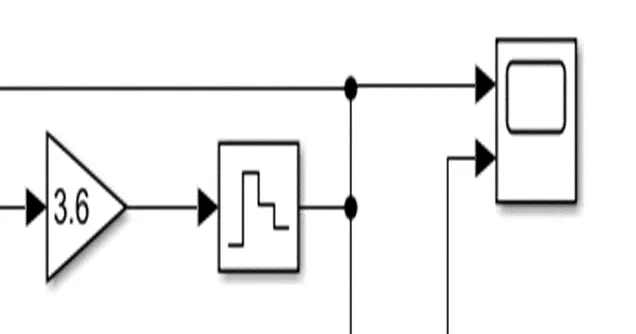
- Output from vehicle is m/s since the reference value from drive cycle is km/h and the output value is also to be in km/h so to change m/s to km/hr following blocks are used.
- Input as m/s coming from the vehicle body and output as km/hr send to the scope
I] DISTANCE INDICATOR:-
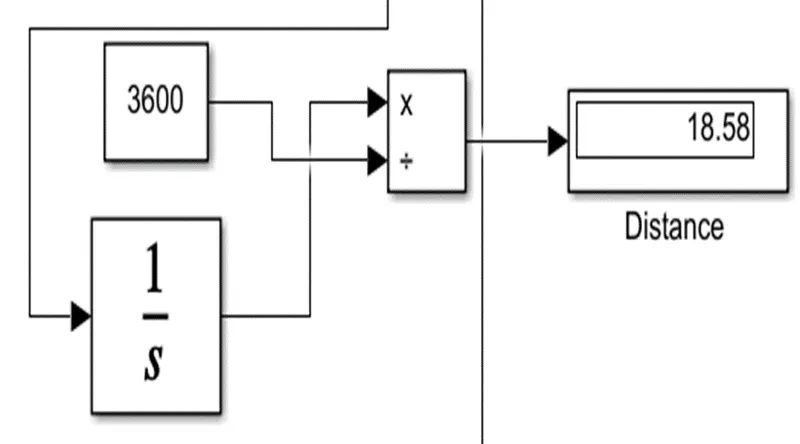
- Total travelling distance is calculated by 3600/1000 to the input data given by vehicle
- Which is displayed as below
J] SOC ESTIMATE:-
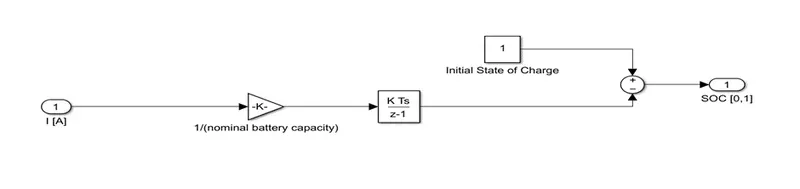
- New subsystem is generated as current value is multiplied by 1/(80*3600)
- And discrete time indicator provided
- So the value is subtract from the initial SOC which is 1
- Initially state of charge is 100%
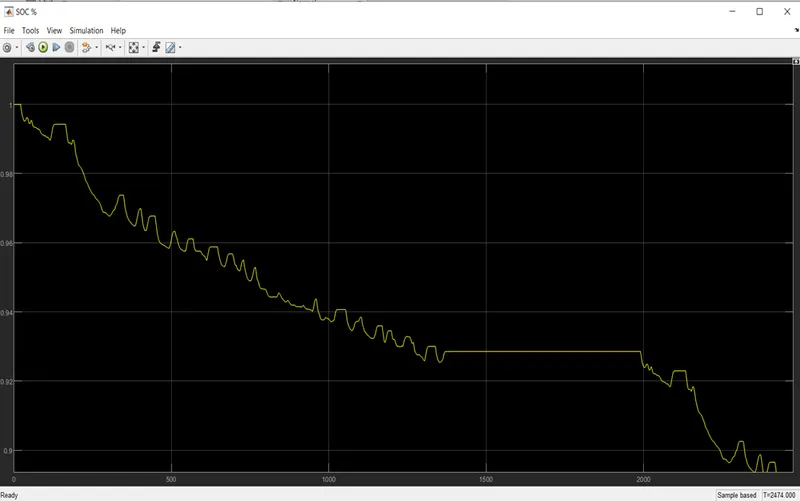
RESULT:-
- From above graph of soc battery is discharged to 0%
- And soc is gradually decreased.
- Between 300 sec to 1400 sec battery is charged because of regenerative braking
- Between 1400 sec to 2000 sec soc found constant because of 0 speed of vehicle
- In this way we can calculate the range of a battery SOC % of the system.
K] Plot (Actual Vehicle Velocity and Drive Cycle):-
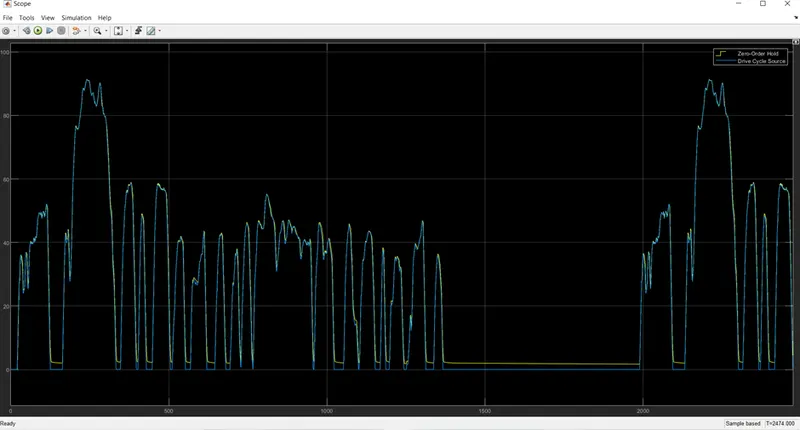
RESULTS:-
- Actual vehicle speed is following drive cycle by minimal difference for the given power supply and drives.
- Vehicle range is about 95km/hr and it shows good respone.
- Distance travelled by this drive cycle is 18.58 km and vehicle is propelling til the given time
CONCLUSION :-
- So, EV Model is created using matlab Simulink
- We have simulated with the given drive cycle and vehicle is travelled the distance is 18.58 km
- We have calculated the range of the vehicle and batter with given power supply and drives.
- By increasing the battery capacity vehicle can travel more distance considering space and cost.