Collision Mitigation Brake System
Collision Mitigation Brake System (CMBS) is a radar‐based autonomous emergency braking system. At speeds above 15km/h, moving and stationary vehicles are detected along a path some 100m ahead of the vehicle.
First of all as per the requirement document one subsystem is created with the number of input & outputs given.
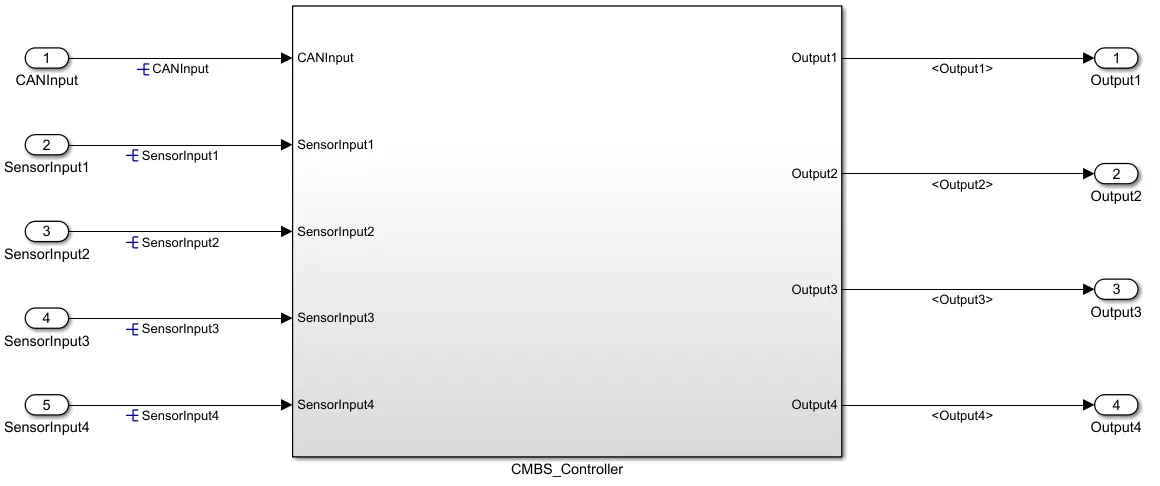
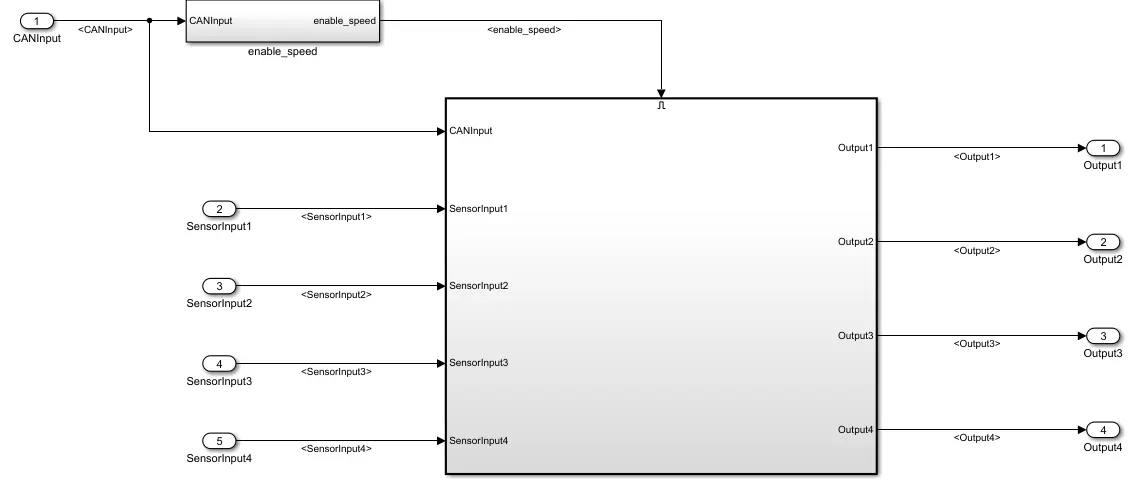
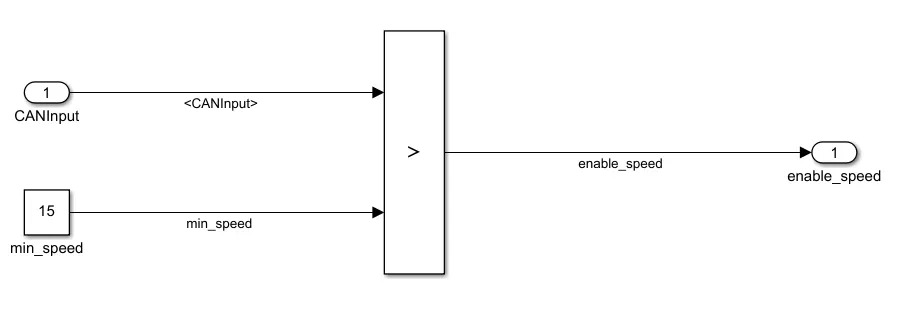
Here the CANinput is comapred against a constant block whole value is defined 15 explicitely. If the value from CANinput is above 15 the subsystem will be enabled.
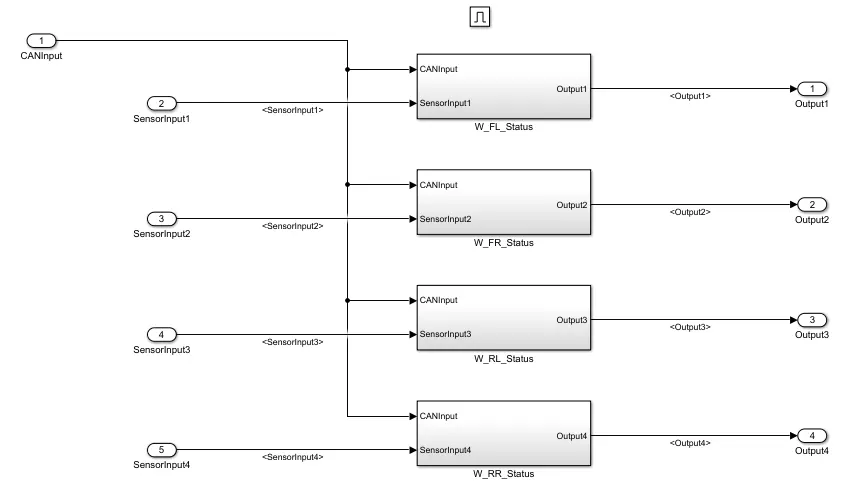
Inside the enabled subsystem, four more subsystem is created. Each of one has two inputs i.e. CANinput and sensorinput (wheel direction sensor).
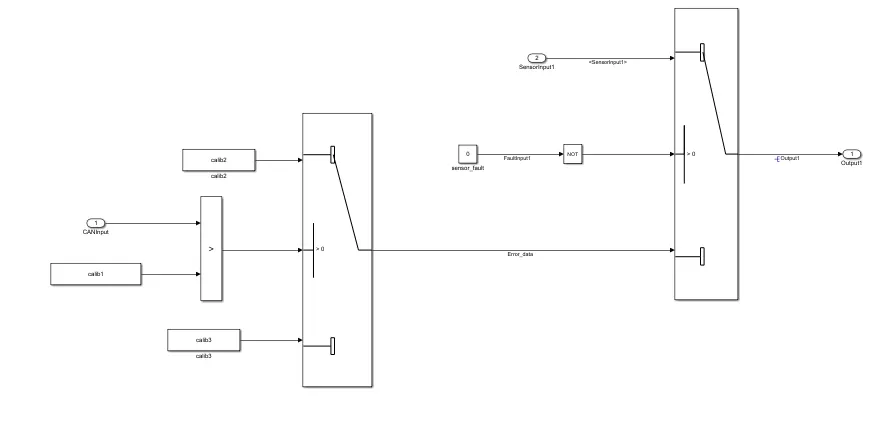
Here the logic is applied such that if a fault prevents accurate detection of vehicle direction, Output shall be set to 'calib2'. In case of a normal condition it shall report ‘calib3’. (i.e. around 0 kph if the direction detection is temporary not accurate enough).
Data Dictionary:
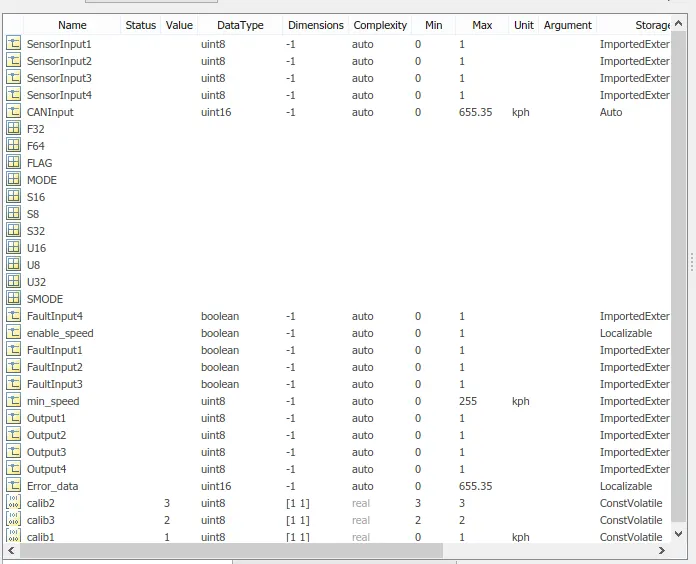
https://drive.google.com/drive/folders/1bOCGrhV43HGf-fVY3JGR-uFCFcE9jCUl?usp=sharing
Please refer above link for model.