Assignment 7-Side Pole Crash Simulation Challenge
OBJECTIVE:
To perform Side Impact Crash Analysis on the neon car model using Hypermesh and RADIOSS and discuss the simulation results obtained.
PROCEDURE:
1) Initially, the given model is imported into HyperCrash.
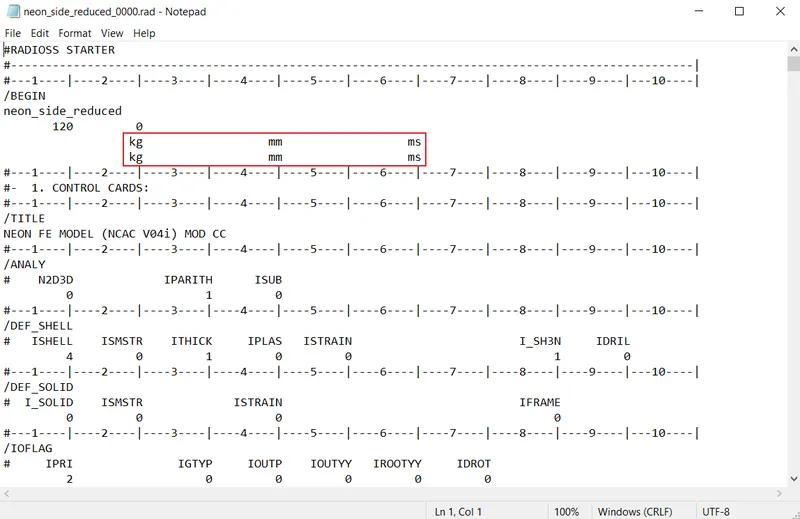
The unit system used in the model is checked by opening the Starter file (0000.rad) using NotePad. From the starter file it is found that the unit system used is [Kg mm ms].
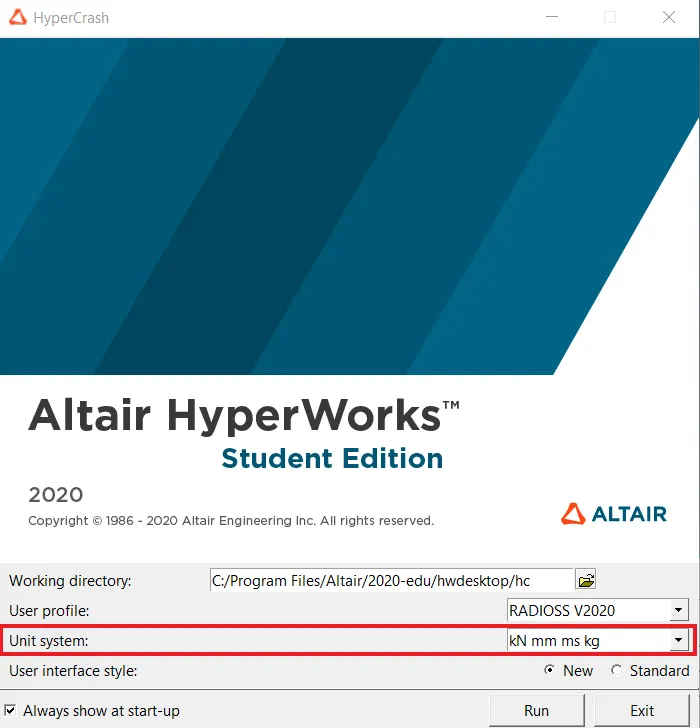
The Unit System can be selected while opening the HyperCrash Application,
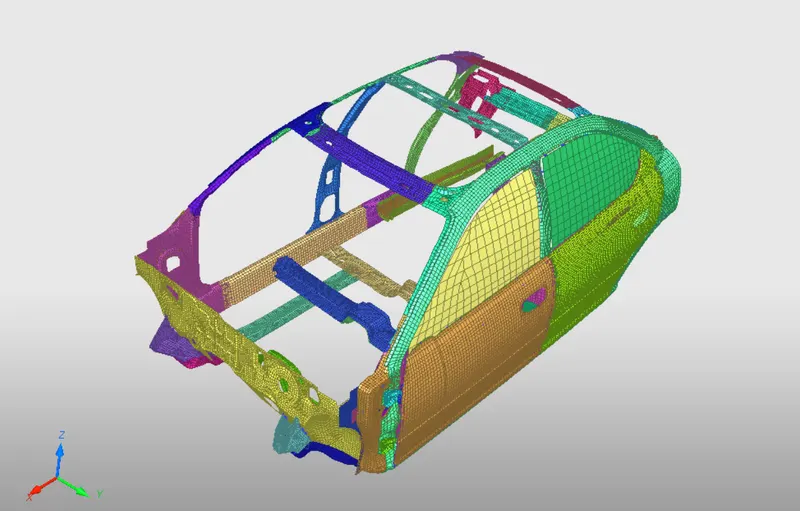
2) The model is checked for any penetration or intersections. The presence of these will lead to energy errors and therefore negatively affect the results.
Menu>Quality>Check Intersections of Tree Selection
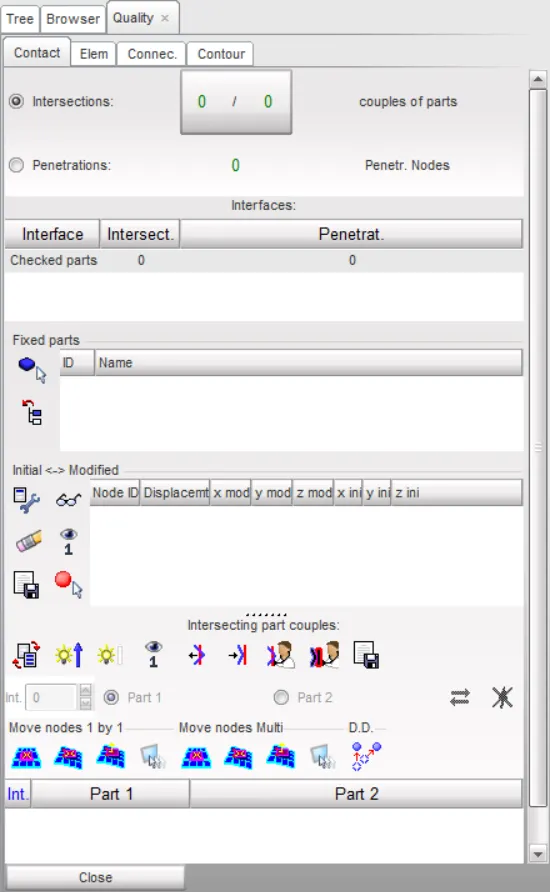
No penetration or intersections are found to be present in the model.
3) Next, the model weight is compared with the full-scale 300k nodes model. Added masses are used to reach target weight of 700kg while getting CG about the required range.
Menu>Mass>Balancing
Due to the limitation in the number of nodes for the student version many components are missing in the model. The current mass of the model is found to be approximately 166 Kg.
By using the isolate tool the current position of the COG can be viewed.
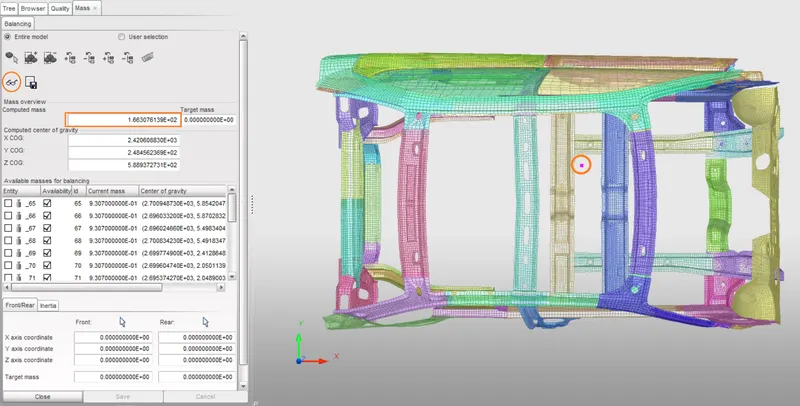
To move the COG to the required position located at the middle of the cross beam, the masses have to be added accordingly. The masses are added at the suitable locations to represent the mass of the seat, passengers etc. Thereby the overall mass of the model is brought to 700 Kg.
Added Mass > Right Click > Create New > Type =1 > [MASS]Added Mass: Enter the amount of mass to be added > [grnod_ID]Support: Define the nodes where mass is to be added by selecting in the graphics > after selecting hit YES > Save
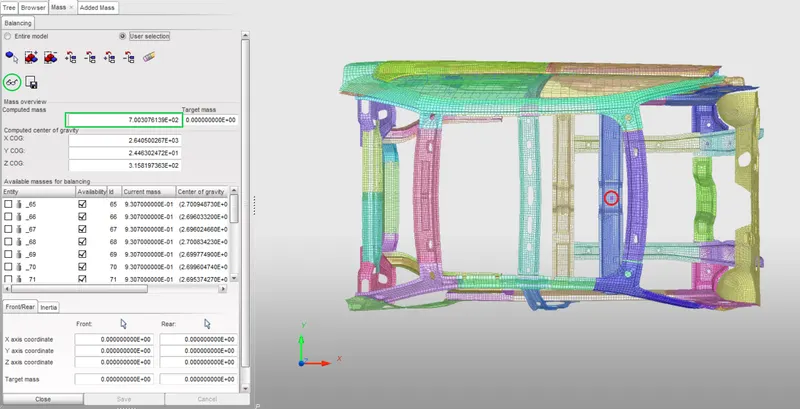
4) The model is now exported from HyperCrash and is imported into HyperMesh as the rest of the operations are carried out in Hypermesh.
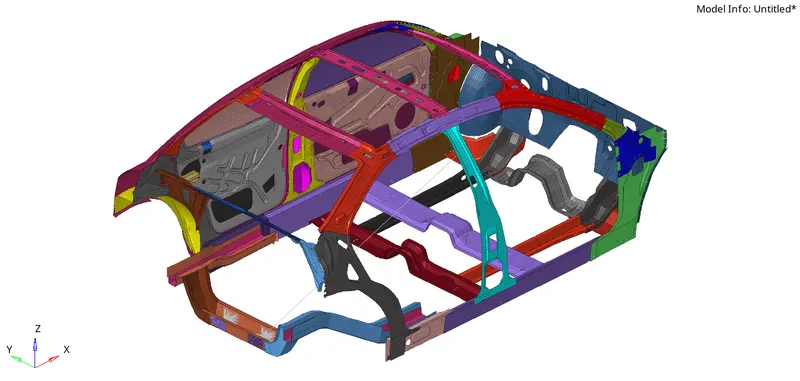
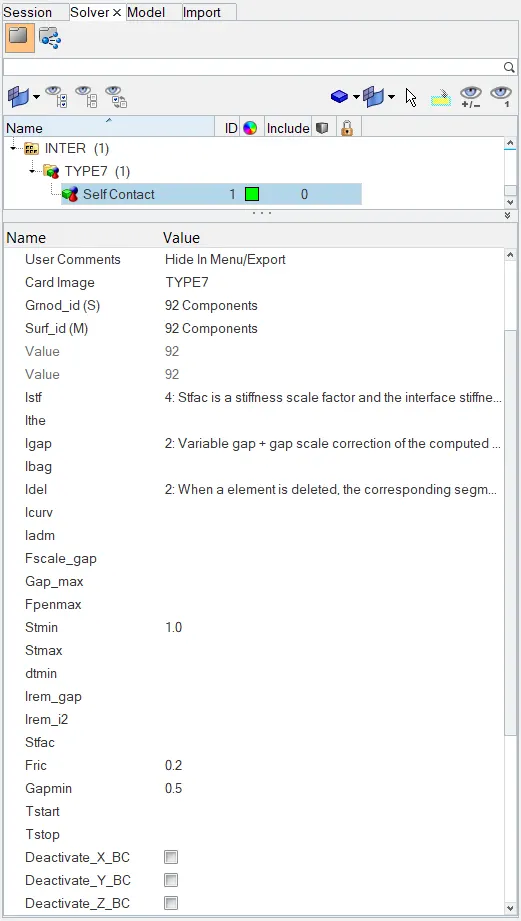
5) The Contact Interface for the model is defined. Type 7 interface has been used, which is a node to surface contact with non-linear stiffness. Since Self-Impact has to be defined in the model, for both the Slave and Master the entire given model will be selected.
Solver Browser>Right Click>Create>INTER>Type 7
All the recommended properties are applied under the Type 7 contact.
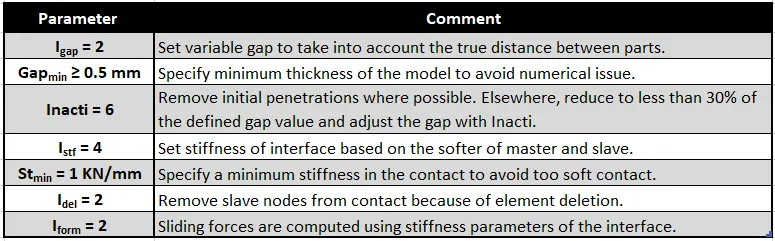
Also, Fric = 0.2
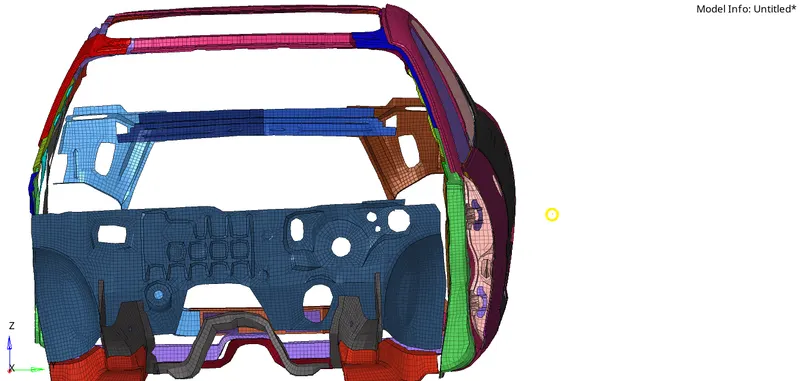
6) A cylindrical rigid wall has to be created. For this a temporary node is created in the middle of the B-Pillar. This node will be used as reference for creating the rigid wall. The temporary node is translated a certain distance away from the B-Pillar so that there is a certain gap present between the rigid wall and the car model.
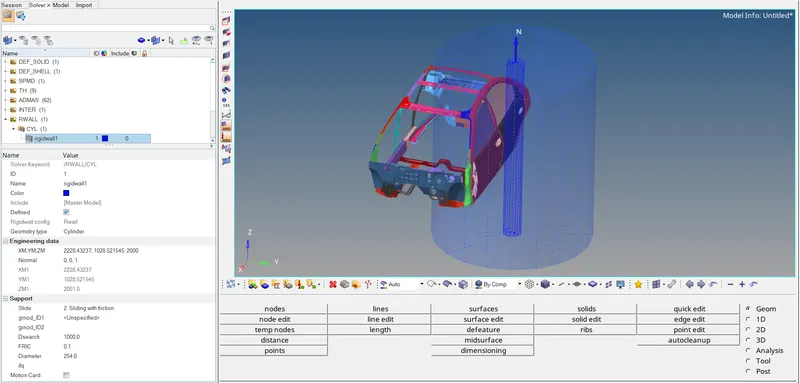
Solver Browser>Right Click>Create>RWALL>CYL
Under Engineering Data for ‘XM, YM, ZM’, the newly created temporary node is selected. Also, since the normal of the rigid wall plane is to be oriented towards the Z-axis, under ‘Normal’, the value ‘0,0,1’ (i.e. z=1) is given. The diameter of the cylinder is set as 254 mm.
The search distance, Dsearch, is set as 1000 mm. All the nodes that come within this range will be considered as slave nodes. Also, frictional parameters for the rigid wall have to be provided for when the slave nodes come in contact with the rigid wall. The ‘Slide’ option is set to ‘2: Sliding with friction’ and the frictional coefficient value, ‘FRIC’ is set to 0.1.
7) An initial velocity of 35 mph has to be provided to the car model. The unit system used in our model is mm/ms, therefore 35 mph becomes 15.6464 mm/ms on conversion.
Solver Browser>Right Click>Create>BOUNDARY CONDITIONS>INIVEL
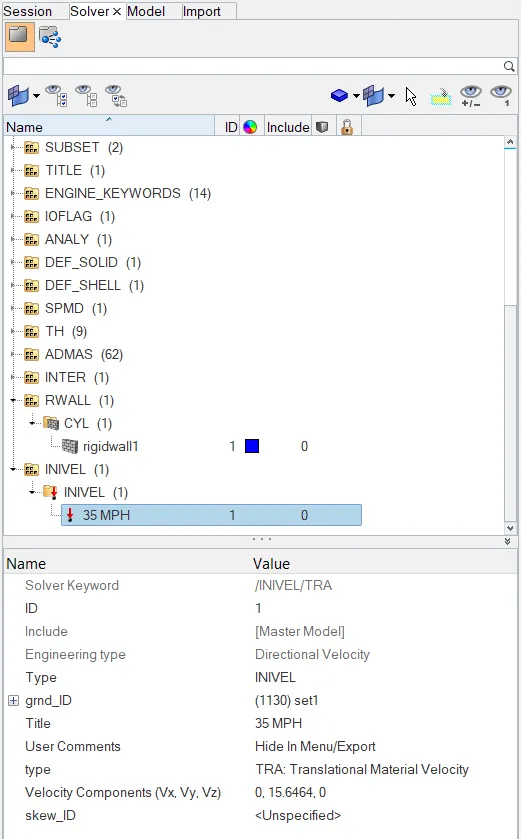
Since the velocity is to be applied only in the translational Y direction, the Velocity Component is specified as ’0, 15.6464, 0’.
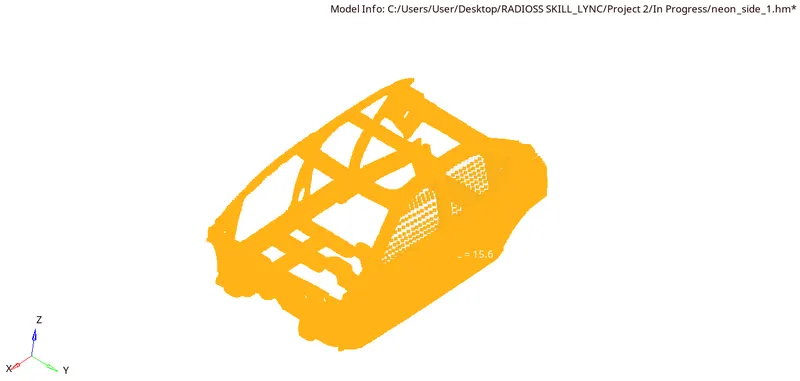
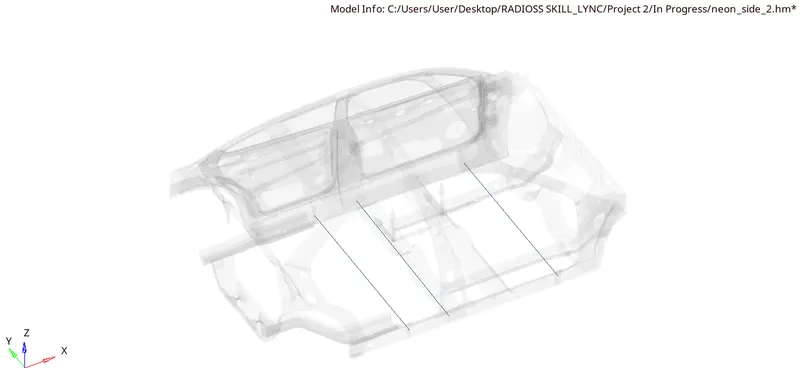
8) Sectional Forces at the Cross Members have to be obtained to see how the forces are being transmitted and thereby study the side impact load path.
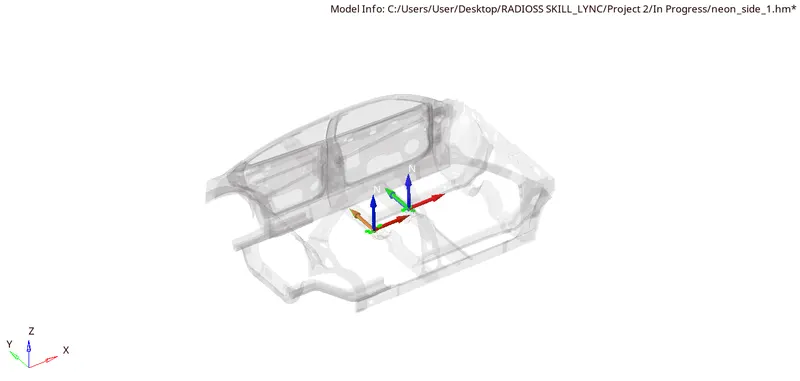
For defining the section, frames have to be created at the required locations.
Solver Browser>Right Click>Create>FRAME>MOV
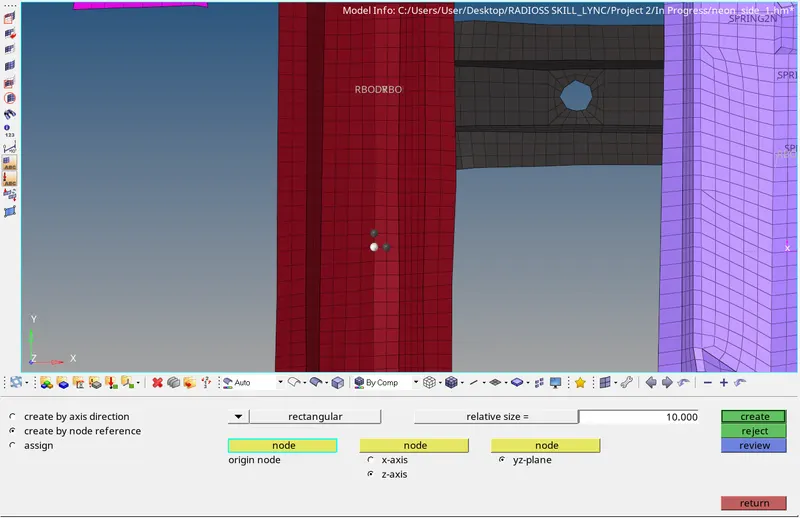
Create the Frame and Sections at all the required locations.
Solver Browser>Right Click>Create>SECT>SECT
Also, ‘delta T’ set to 0.1, ‘alpha’ value is set to 0.6, ‘ISAVE’ is set to 0 and ‘Iframe’ is set to 12.
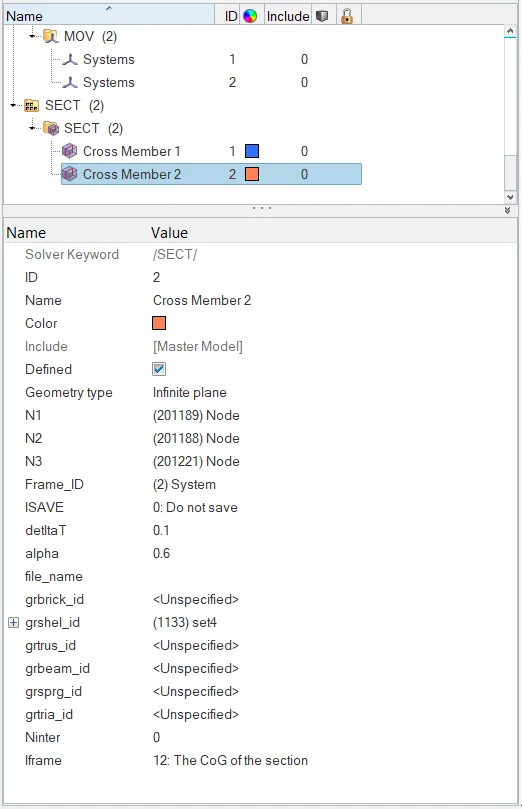
9) The amount of intrusion inside the cabin after impact needs to be measured and if the intrusions are beyond a certain limit, it can compromise the safety of the passengers.
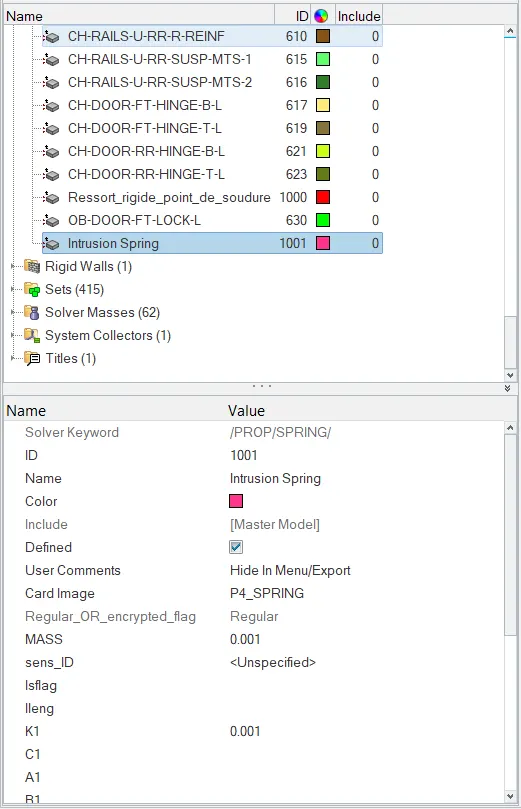
The intrusion is measured with the help of spring elements. The spring elements are created at the required locations where the intrusion needs to be measured.
The change in length of the spring will give the amount of intrusion. The mass of the spring is set to 0.001 Kg and stiffness of the spring is set to a small value of 0.001.
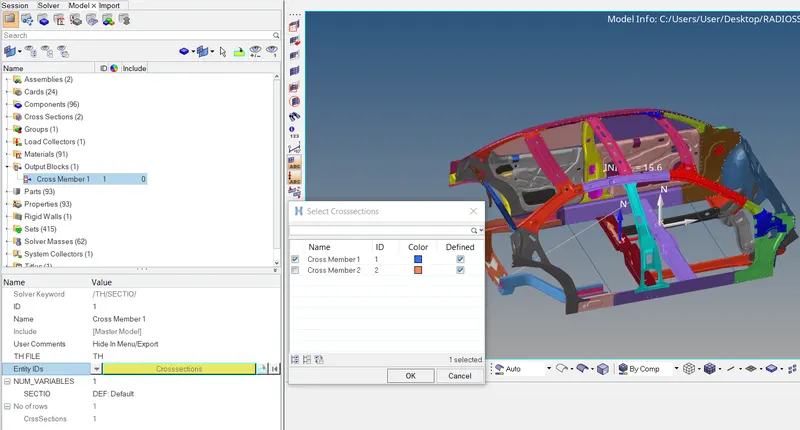
10) The output has to be requested by defining the output blocks. Global Variables are requested by default. Additional time history file has to be requested for the Sections, peak velocity node, Springs(Intrusions) and the Rigid Wall.
Model Browser>Right Click>Create>Output Block
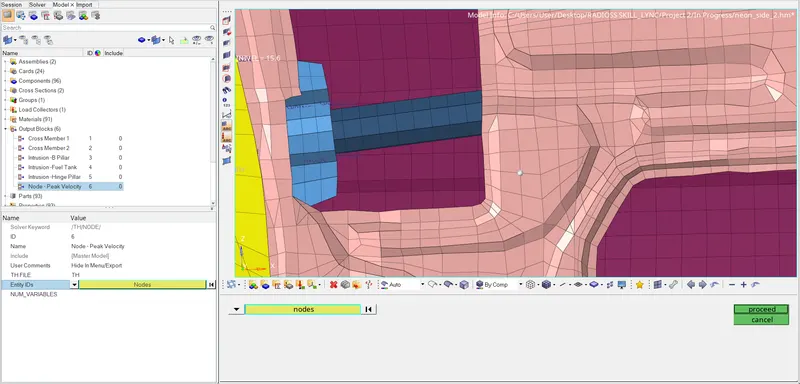
The output for the inner node of the door is requested to obtain its peak velocity.
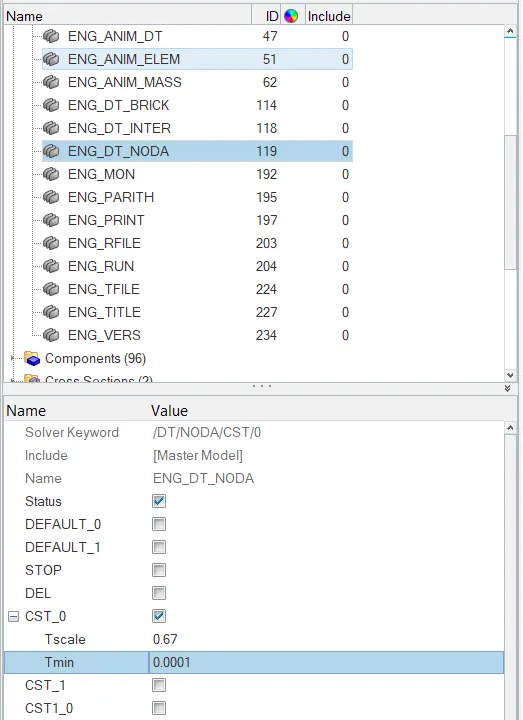
11) The time step for the simulation has to be defined. The timestep value, Tmin is set to 0.0001 under the ENG_DT_NODA card.
Model Browser>CARDS>ENG_DT_NODA>Tmin: 0.0001
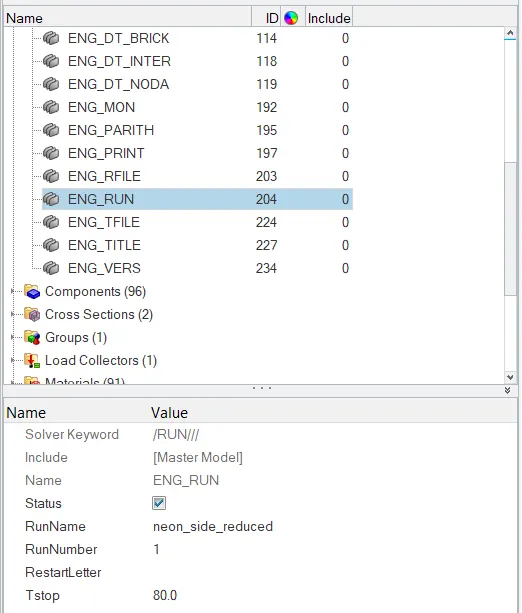
Also, the Run time is set as 80 ms under the ENG_RUN card.
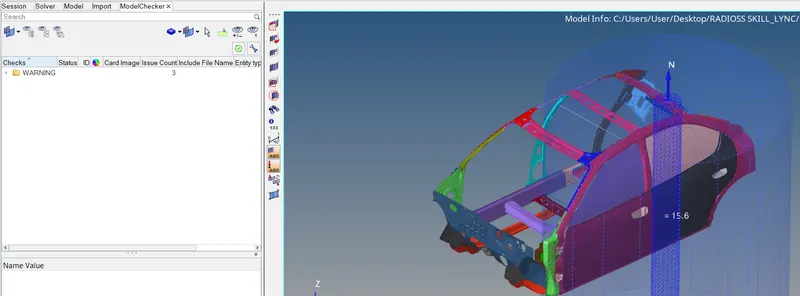
12) After completing all these steps the model is checked for any errors by running the Model Checker. If any errors are found, it should be rectified before running the simulation. Warnings can be ignored.
Tools>Model Checker>RadiossBlock
13) Now the simulation can be run using the RADIOSS solver.
Analysis > Radioss > click ’save as’ to save the file to the required directory >export options: ‘all’ > run options: ‘analysis’ > run number: ‘1’ > options: ‘-nt 4’(number of threads set to 4, for faster simulation) > Radioss
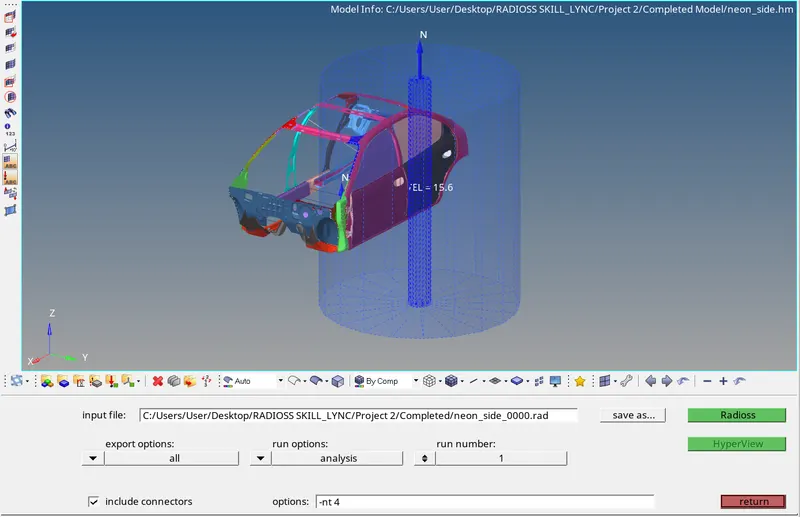
On completion of the simulation, a pop up window opens showing the run summary.
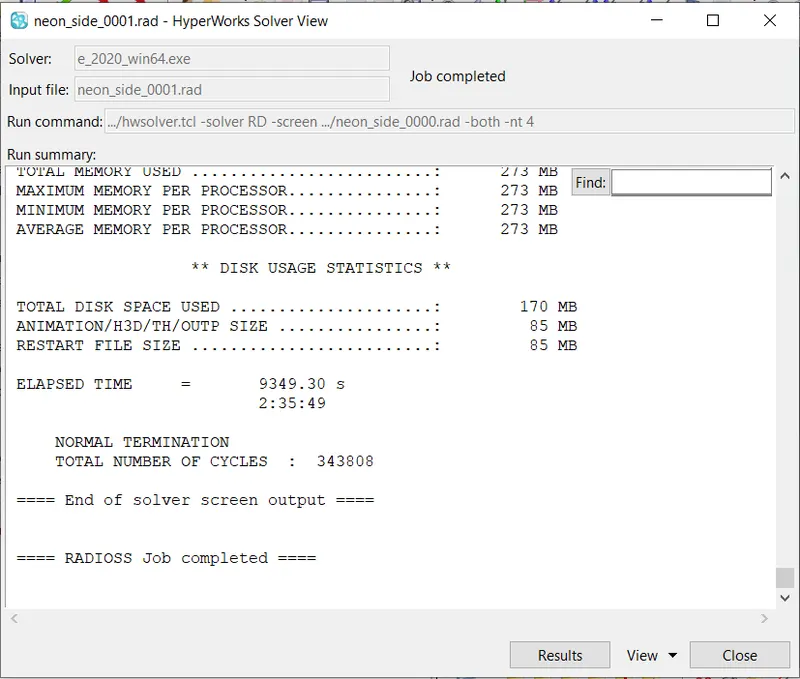
14) After the simulation is completed, the required values such as ‘Energy error percentage’ and ‘Mass error’ can be viewed by opening the engine output file (file ending with 0001.out) using Notepad.
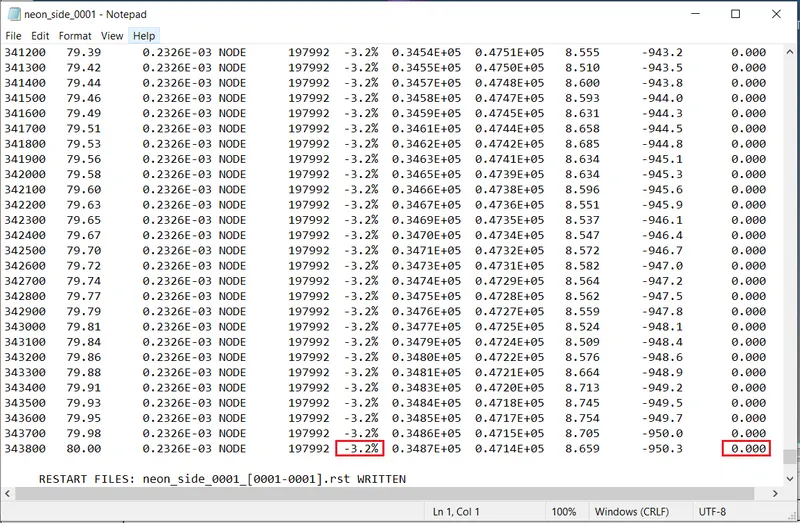
The energy error obtained is -3.2% which is within the acceptable range. Also, the mass error is 0%. Hence the result is acceptable.
RESULTS:
ANIMATION:
To visualize the simulation results as an animation, HyperView is used. For this, the animation file(file ending with .h3d) is loaded in Hyperview.
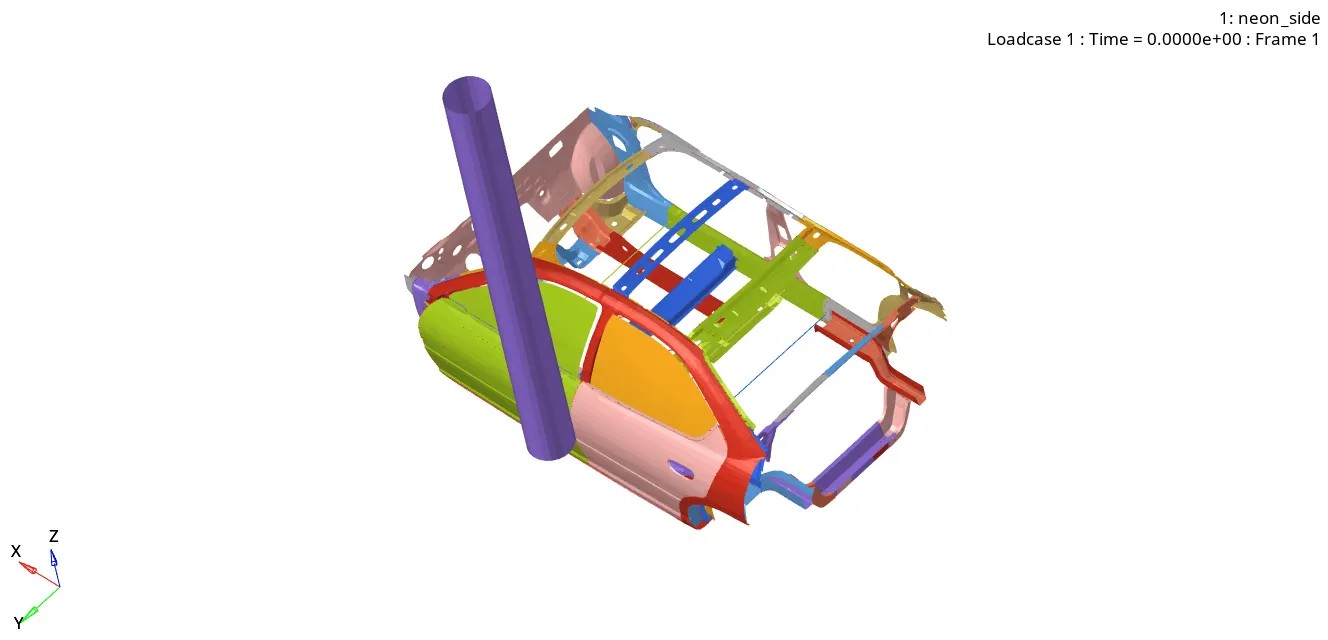
Von Misses Stress Contour:
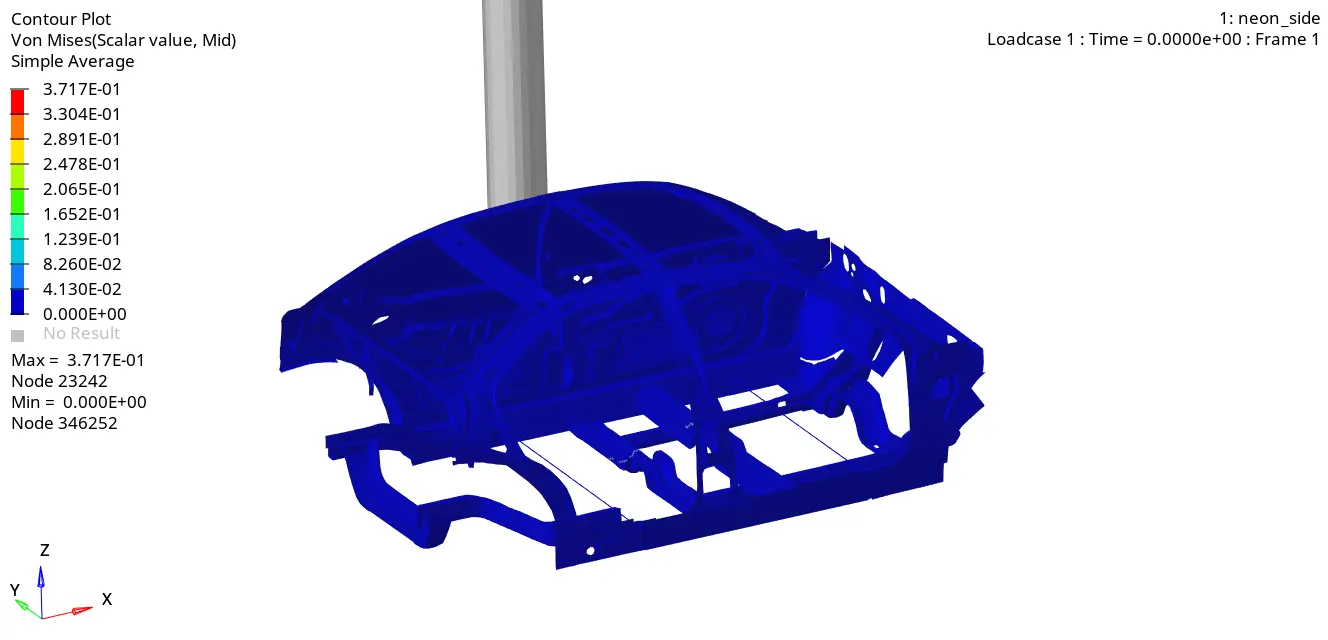
The above animation shows the von misses stress developed in the car. From the animation, it can be observed that, on impacting the rigid wall, the B-Pillar starts deforming first and then the energy is gets transferred from the B-Pillar through the roof rails and rocker to the Cross members. Thus the impact energy is distributed along the body and getting absorbed.
The maximum von-misses stress obtained is 0.3717 kN/mm2.
PLOTTING GRAPHS:
- GLOBAL VARIABLES:
To plot the graph, HyperGraph is opened.
Under ‘data file’, the Time History File ( file ending with T01) is loaded.
(X Type: Time > Y type: Global Variables > Y Request: Internal Energy, Kinetic Energy, Contact Energy, Hourglass Energy and Total Energy > Y Component: MAG > Apply)
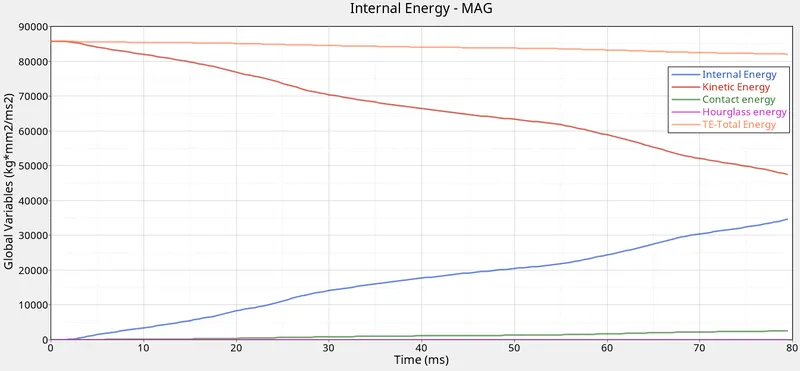
As the graph shows, the Kinetic Energy is maximum at the beginning and starts to decrease once the car model hits the rigid wall. This Kinetic Energy gets converted to Internal Energy as the model deforms as can be seen in the graph by the rise of the Internal Energy Curve. The Maximum Kinetic Energy of 85687.54 J is present at T=0 and gets reduced to 47446.33 J by the end of the simulation, at T=80 ms. Whereas, the Internal Energy is 0 at T=0 and reaches its maximum value of 34599.72 J at T=80 ms.
As the model undergoes deformation, due to self-impact, there is an interaction between the slave nodes and the master segments and as a result resistive forces are generated to keep the slave nodes out of the contact gap. Thus the contact energy slightly increases thereby reducing the total energy.
The Hourglass Energy is found to be negligible due to the use of QEPH element formulation.
- SECTIONAL FORCES:
Sectional Forces at the Cross Members are obtained to see how the forces are being transmitted through the model and thereby study the side impact load path.
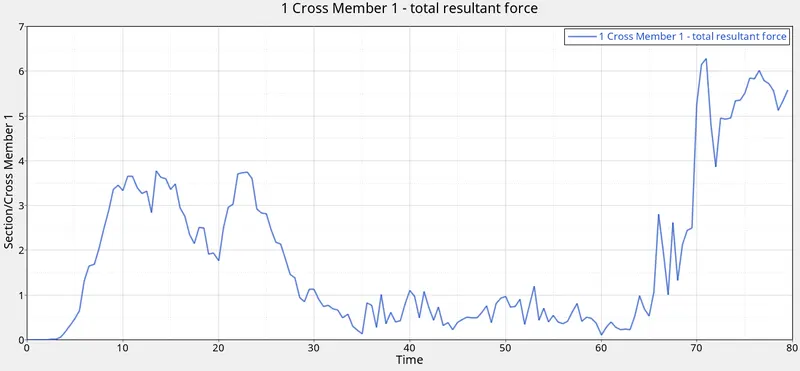
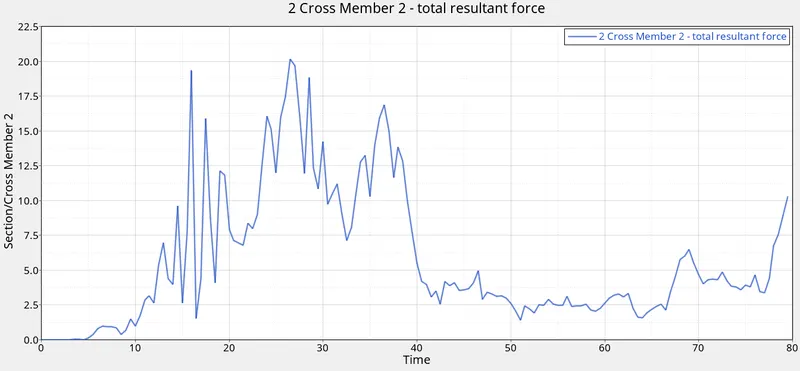
The maximum sectional force at the Cross Member below the driver seat is 6.27 kN and the maximum sectional force at Cross Member besides the B-Pillar is 20.16 kN. As seen in the plot, initially on impact with the rigid wall, a large amount of force is transmitted through the Cross Members. Due to this the Cross Member deforms and then less force is transmitted as can be seen by the drop in the graph. Again the graph rises as the force is transmitted by the deformed cross member.
- PEAK VELOCITY OF INNER NODE OF THE DOOR:
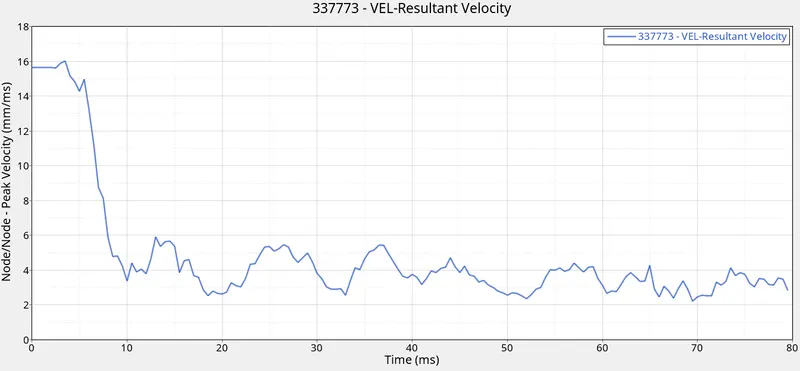
The Peak velocity of inner node of the door is observed to be 16.03 m/s. This velocity is attained on the initial impact of the model with the rigid wall. After impact, the velocity drops and then it is found to be varying in the range of 6 m/s to 2 m/s.
- INTRUSION:
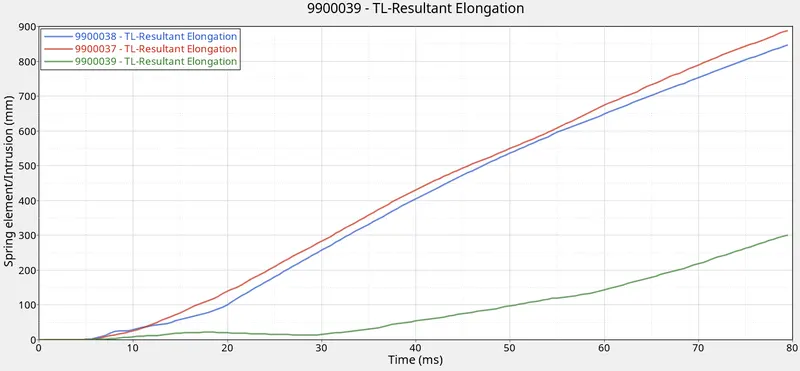
The intrusion at Hinge Pillar region is found to be 301.16 mm. The intrusion at Fuel Tank region is found to be 846.90 mm and the intrusion at B-Pillar region is found to be 888.83 mm, they are higher as they are closer to the impact region.
The intrusion at the Fuel Tank Region can be reduced by providing an additional Cross Member in that region and by using more energy absorbing materials.
CONCLUSION:
Side Crash Simulation was carried out on the given neon car model using RADIOSS solver after doing the Analysis setup using the HyperMesh and HyperCrash Pre-Processors and the results obtained were studied.