Assignment 7-Side Pole Crash Simulation Challenge
AIM:
Side crash analysis, deck setup using hypermesh and hypercrash.
OBJECTIVE:
- To check the unit system and either follow [Mg mm s] or [Kg mm ms].
- To create the appropriate interface, friction 0.2 and recommended parameters.
- To make sure of no penetrations and intersections.
- To correct rigid bodies if any issues.
- To create a rigid wall with friction 0.1.
- To compare the model weight with the full-scale 300k nodes model and use added masses to reach target weight 700kg while getting CG about the required range.
- To create an initial velocity of 35 mph.
- To input Time-step:0.5 to 0.1 microseconds and Run 80 ms
INTRODUCTION:
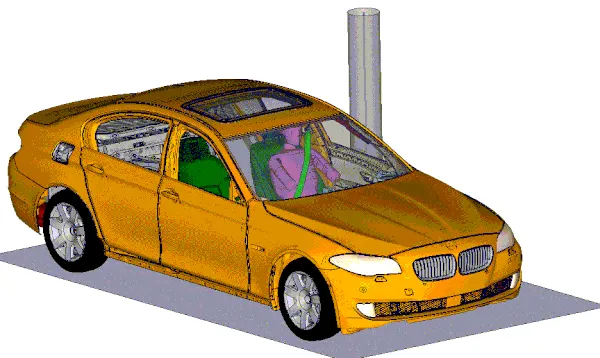
Assume that you tried to steer your car at high speed at turning but speed was enough to outwit the Tires resisting force and you hit the rigid cylindrical object like a tree. So, in this and many other cases like a side car accident, slipping on a snowflake, etc. can cause damage to the passenger if the car is not designed with great care. This is where the side-impact standard comes into the role. The standard has been devised by the standard maker like FMVSS (214, 201), EURO NCAP, US NCAP, and IIHS. Again, for this project, the car with the simplified model is taken for analysis purpose. The model is prepared following the guidelines suggested by the FMVSS 214 standard. The analysis is executed to check the intrusion made inside the car, intrusion inside the fuel tank (for hybrid electric vehicles, battery-package system, which is more dangerous), and how much the B pillar is affected.
According to the standard, relative displacement (intrusion) must be small before the inflation of the airbag. Indeed, the strength of the B pillar and other surrounding structures should be high enough to bear the impact force and should not deform at least up to a small duration of time. The major component which is going to play the major role in this impact is B pillar, rocker, Door outer, Door beam, Door support, roof rail, roof bow, front header, and cross rail. So, let's our discussion starting from the preparation of the model, simulation to the analysis of the result and validation.
In different parts of the world, there are several vehicle safety assessment programs that perform crash test in order to increase vehicle safety and ensure that vehicle has good occupant and pedestrians safety. These programs focus on improving the crashworthiness of motor passenger vehicles and reduce the number of injuries. In Europe, there is the New Car Assessment Program (NCAP), based on the program introduced in 1979 by the NHTSA (National Highway Traffic Safety Administration) in the USA. the Euro NCAP frontal crash test standards are followed in India.
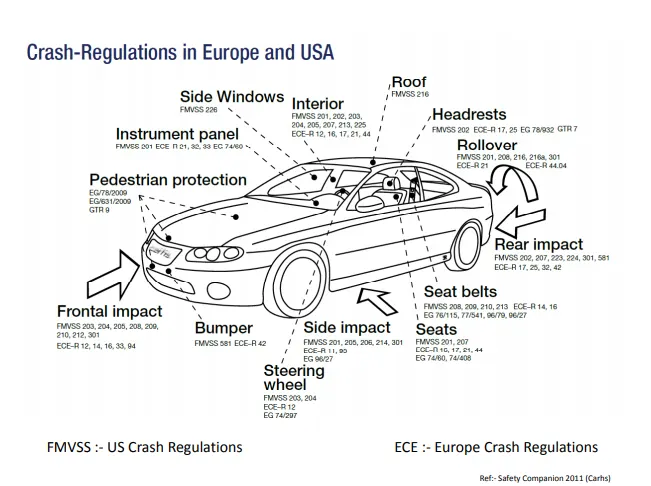
Going through the FMVSS standards: https://www.nhtsa.gov/sites/nhtsa.dot.gov/files/tp214p-01.pdf 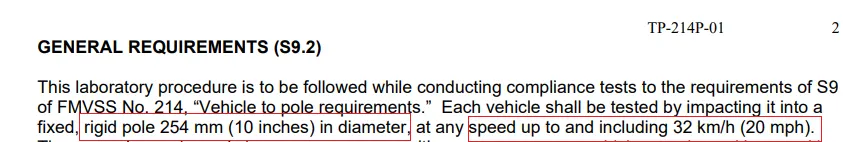
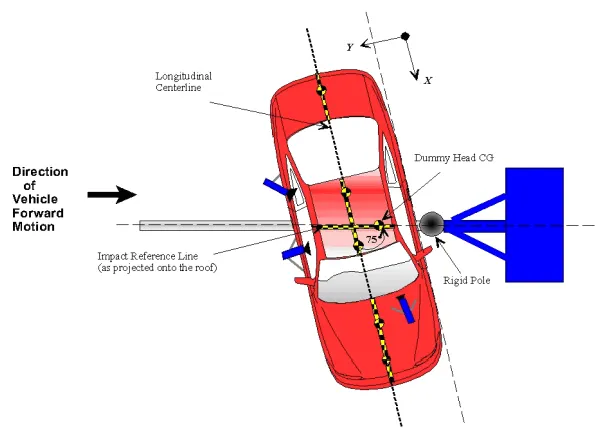
Here in this simulation, we are going to take the angle of inclination as 90 degrees instead of 75 degrees and initial velocity as 35 mph as per the given requirements.
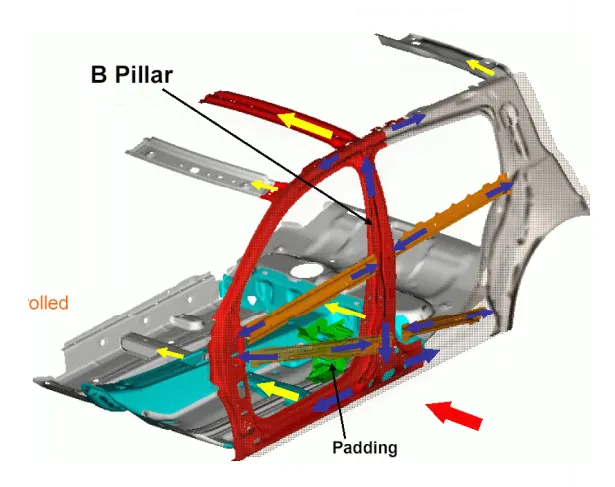
Load path for the side impact
PROCEDURE:
- Check for UNIT SYSTEM
- Import model in HYPERCRASH
- Check for penetration and intersection
- Add masses to reach a target weight of 700kg
- Export changes file and import in HYPERMESH
- Create Self Interface contact
- Create a rigid wall
- Add velocity to the nodes
- Create cross-section's
- Create springs to check deflection
- Assign property to springs
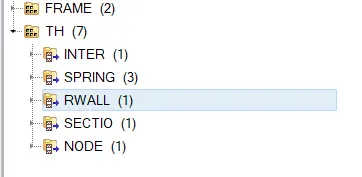
- Create TH for section forces, intrusion springs, interface contacts
- Create cards
- Model checker
- Run the model
CHECK FOR UNIT SYSTEM:
In the data, we have two files
1. Neon_side_reduced_0000.rad ( Starter input file) :
The starter file stores information about:
- Nodes
- Load Conditions
- Velocity
- Boundary Conditions, etc.
- Basically, it is an ASCII (American Standard Code for Information Interchange) file that contains the model information.
- The starter file should always end with 0000.rad.
2. Neon_side_reduced_0001.rad ( Engine input file) :
The engine File stores information about:
- Simulation Runtime
- Simulation Speed control parameters, such as No. of Animation Files, No. of Time History File, Size of the history file and Animation frequency, etc.
- Basically, it is an ASCII (American Standard Code for Information Interchange) file that describes the run controls.
- We can also edit the Engine File directly through the Control Cards.
- The starter file should always end with 0001.rad.
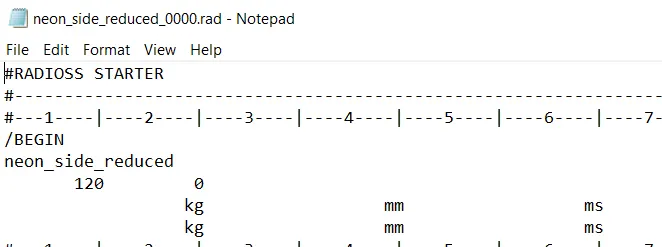
To check unit ,Go to Neon_side_reduced_0000.rad file >> Open >> check the unit system
IMPORT STARTER FILE IN HYPERCRASH:
- Here some setup is done by Hypercrash and the remaining setups are done in Hypermesh.
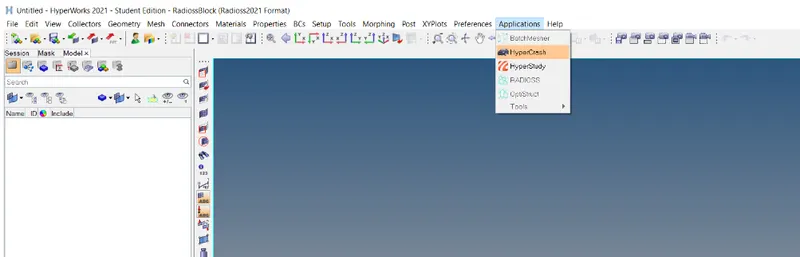
- To open hypercrash we have to first open hypermesh
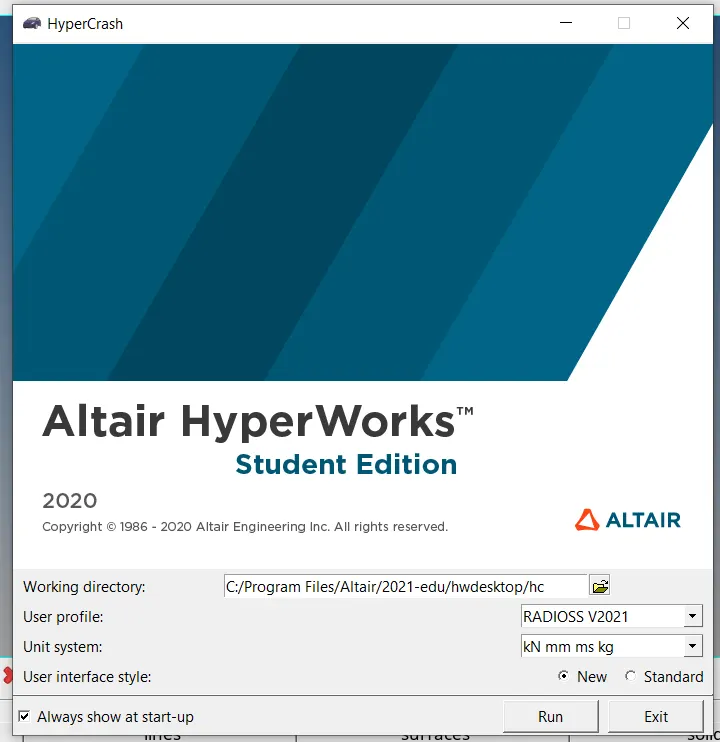
- Now go to Application >> Hypercrash>> Select the unit system >> open
- Opening hypercrash
- Selecting Proper UNIT SYSTEM
- Select Neon starter file and drag it to hypercrash application to open the model
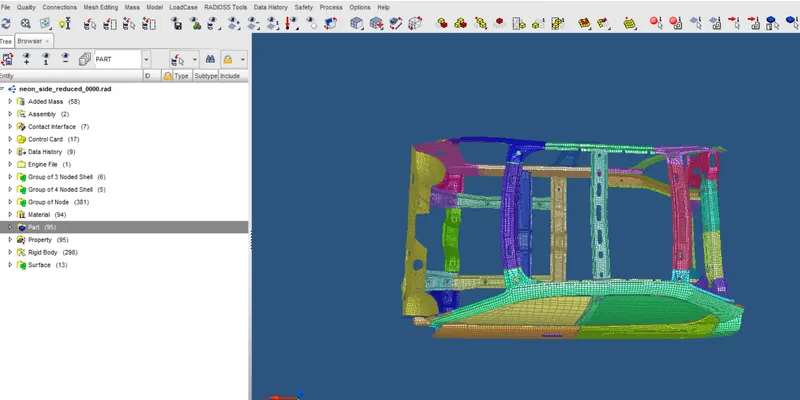
CHECK FOR PENETRATION AND INTERSECTION:
- Penetration is defined as the overlap of the material thickness of shell elements, while Intersection is defined as elements that actually pass completely through one another. All models and especially impact models should be checked for penetrations and intersections and De penetrated to ensure the integrity of the model. Penetrations adversely affect results and should be removed.
- To check penetration and intersection ,Got to Quality>> Check Intersection on tree >> Select parts > Click on check penetration
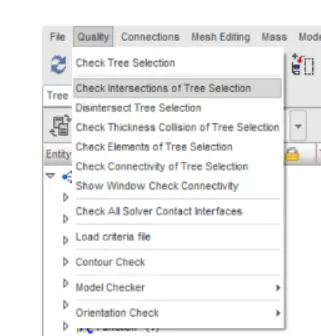
- Checking for intersection and penetrations
- No intersection and penetrations present
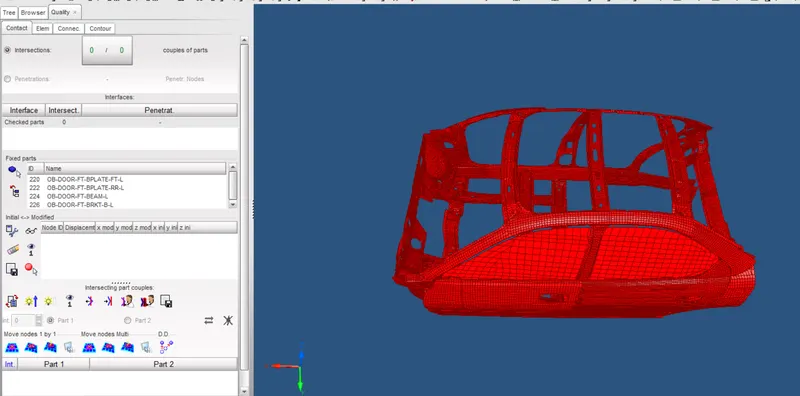
- We can clearly see from the above figure there are no penetrations and intersections are present in the model.
Compare the model weight with the full-scale 300k nodes model and use added masses to reach a target weight of 700kg while getting CG about the required range.
- A vehicle’s center of gravity, or CG, is the theoretical point where the sum of all of the masses of each of its individual components effectively acts. In other words, from a physics perspective, a vehicle behaves as its entire weight resides at this one point. Carrying weight up high, such as a panoramic sunroof will raise a vehicle’s CG while placing heavy subsystems low in a vehicle, such as a battery pack, will work to lower it. Lower is better from a handling standpoint, as it reduces weight transfer during cornering and braking, and it also reduces the propensity to roll over.
ADD MASSES:
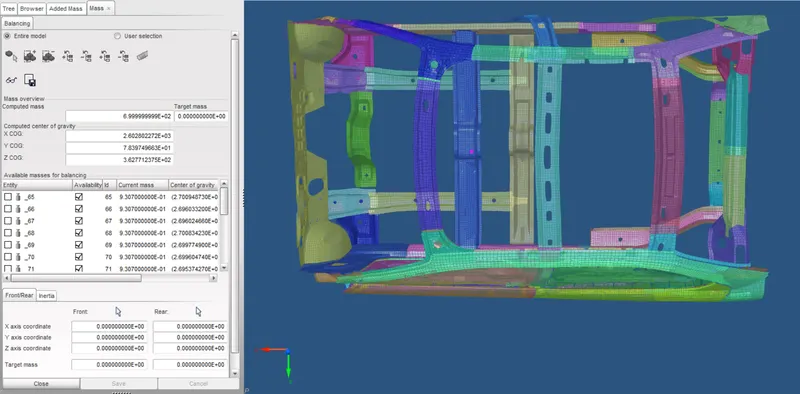
Mass balancing: In order to maintain the CG of a car we have to add mass for the given components, In the given model here are so many parts are missing because of the node limits in the student version
- To check the CG ,Go to menu >> Mass >> Balancing >> Show CG point
- Before adding mass check the CG
Total mass when we imported 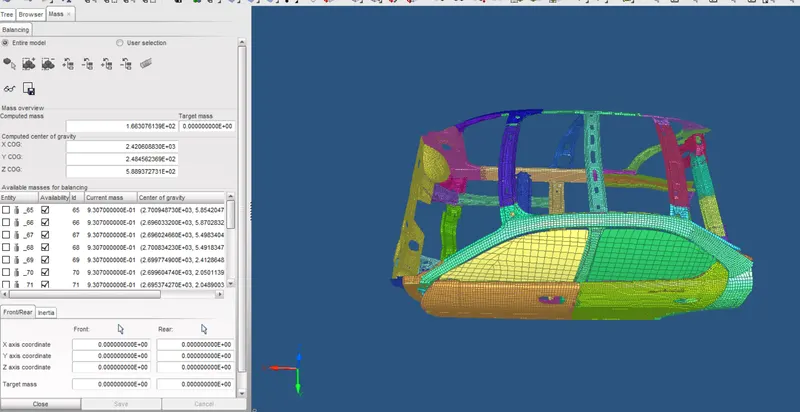
- CG before adding mass
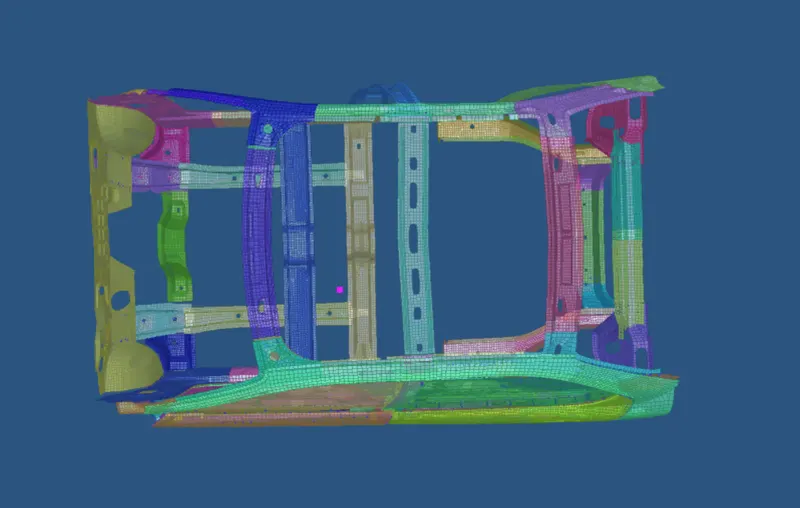
Current weight: 166 kg
Target weight: 700 Kg
- We have to add the mass in such a way that the Centre of gravity is exactly in the middle of the Cross Beam to simulate the real-time model.
- We are only worried about the position of the COG (X and Y axis) and not the height (Z-axis).
- We use Type 1 Mass, where mass is distributed on each node of the selected group.
Added Mass > Create New >> Type =1 >> Enter the Value (ex. 40kg) >>right click to pick nodes >> Select the group node by selecting in the graphics >> Select Add/Remove nodes by picking selection >> After selected hit YES >> Save
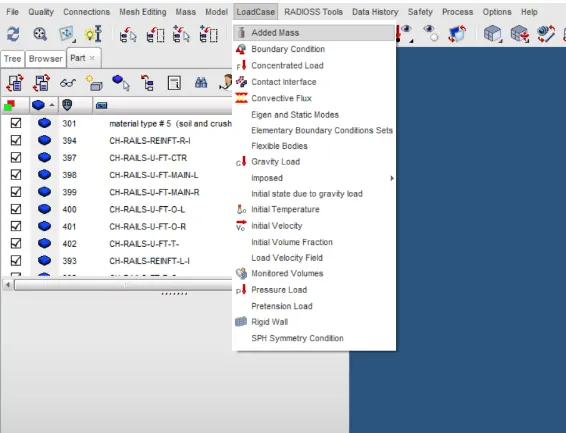
- Adding mass , Selecting mass type as 1
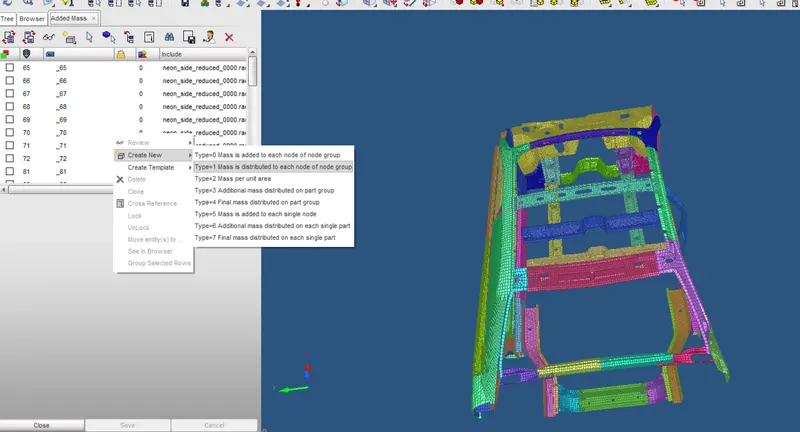
- selecting nodes by graphics
- Mass added for the particular selected
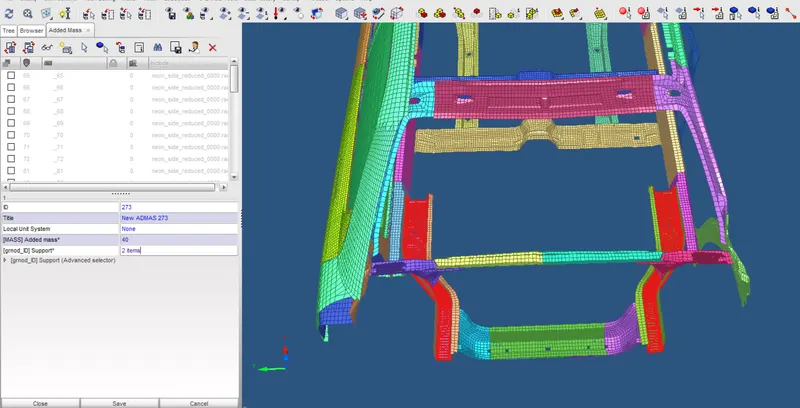
- After balancing the mass, we achieve our target mass that is 700kg as shown in the figure below
EXPORT HYPERCRASH FILE:
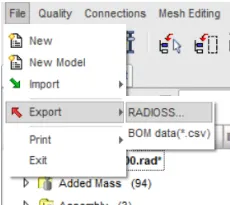
- Export the changes made in hypercrash and import the same file in hypermesh to make other changes
- For that ,Go to File >> Export >> RADIOSS
- Now import the same file in hypermesh to do other changes
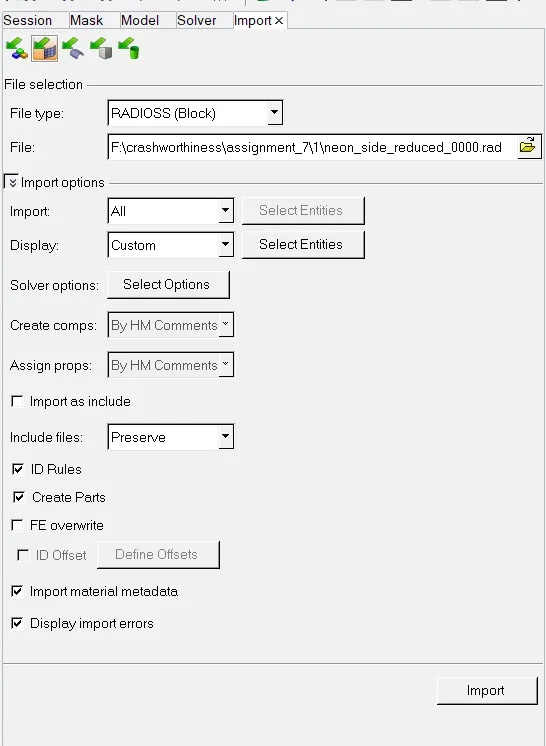
- For that open hypermesh
- Go to file >> Import solver deck >> Select Neon_side_reduced_0000.rad file >> Import
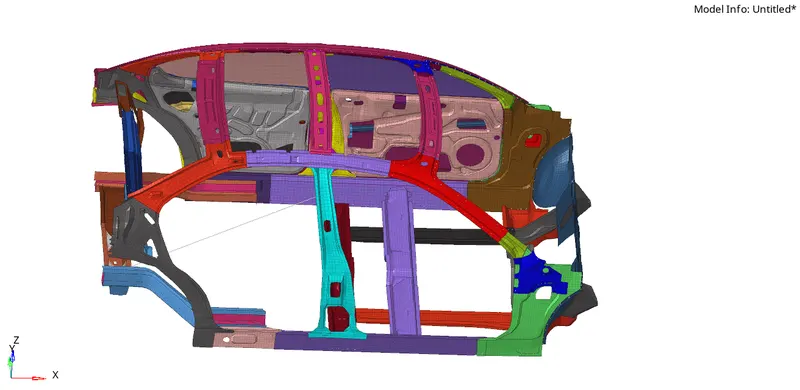
Model imported
CREATE SELF CONTACT:
In this case, the Type 7 Contact Interface is defined. Interface TYPE7 is a multi-usage impact interface, modeling contact between a master surface and a group of slave nodes. It is also possible to consider heat transfer and heat friction.
All limitations that were encountered with interfaces TYPE3, TYPE4, and TYPE5 are solved with this interface:
- A node can at the same time be a slave and a master node.
- Each slave node can impact each master segment; except if it is connected to this segment.
- A node can impact more than one segment.
- A node can impact on the two sides, on the edges, and on the corners of each segment.
- It is a fast search algorithm without limitations.
The main limitations of this interface are:
- Time step is reduced in case of high impact speed or contacts with a small gap.
- It does not work properly if used with a rigid body at high impact speed or a rigid body with a small gap.
It does not solve edge-to-edge contact (to solve this, /INTER/TYPE11 should be used along with TYPE7).
The recommended properties are as following:
1.Igap = 2 (Variable Gap took into account.)
2.Gapmin ≥ 0.5mm (minimum thickness to avoid the numerical issue.)
3.Inacti = 6 (remove initial penetrations wherever possible, else reduce to less than 30% of the defined gap)
4.Istf = 4 (Stiffness based on softer Segment)
5.Stmin = 1 kN/mm (Minimum stiffness in contact to avoid too soft contact.)
6.Idel = 2 (remove slave nodes from contact because of element deletion)
7.Iform = 2 (Frictional Forces are calculated on the basis of Stiffness parameter.)
- Delete existing contacts and create new contacts with recommended properties
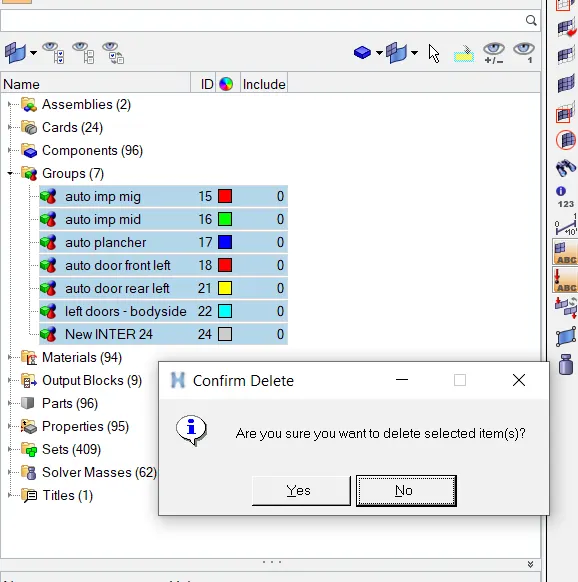
- Now create a new contact
- Goto model browser >> Right-click >> Create >> Contact >> Rename as Self contact >> Select slave node and master components >> Enter Type 7 recommended properties
- We can select slave and master as a component and as well as node selection
- For that, we just have to right-clicked where selecting nodes are components there is one option called create/Edit select and proceed with nodes or components
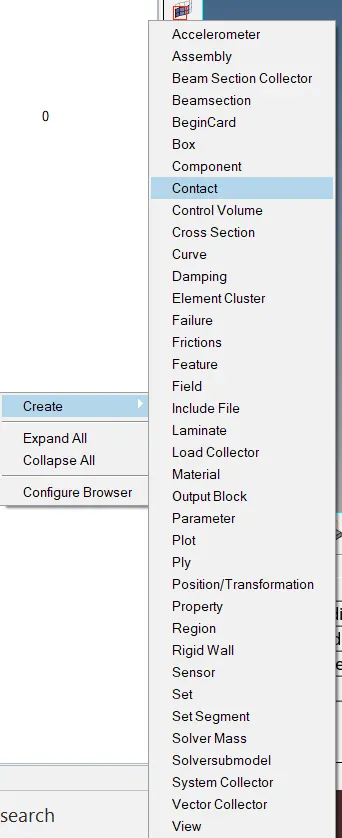
- Creating new self-contact
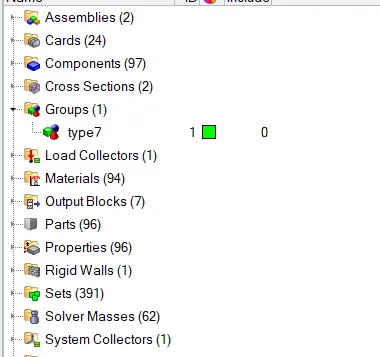
- Then after this step, we simply need to give in the Slave nodes and the master segment. Since we are defining a Self-Impact in the model, the Slave and Master segments for this contact will be the entire given model. So, we then select the slave and master in the graphics area.
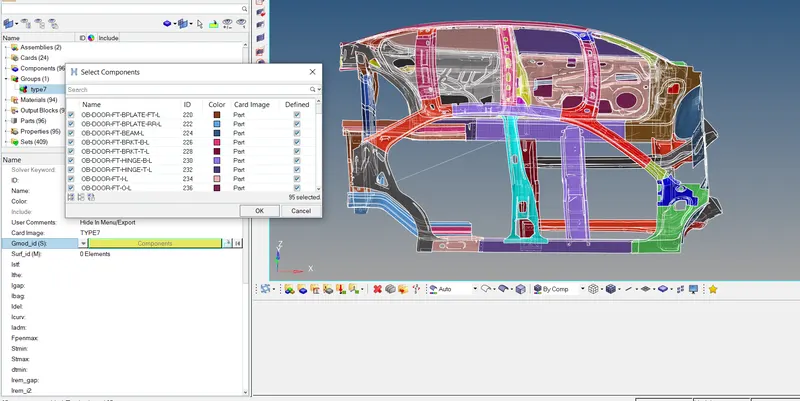
Recommended properties
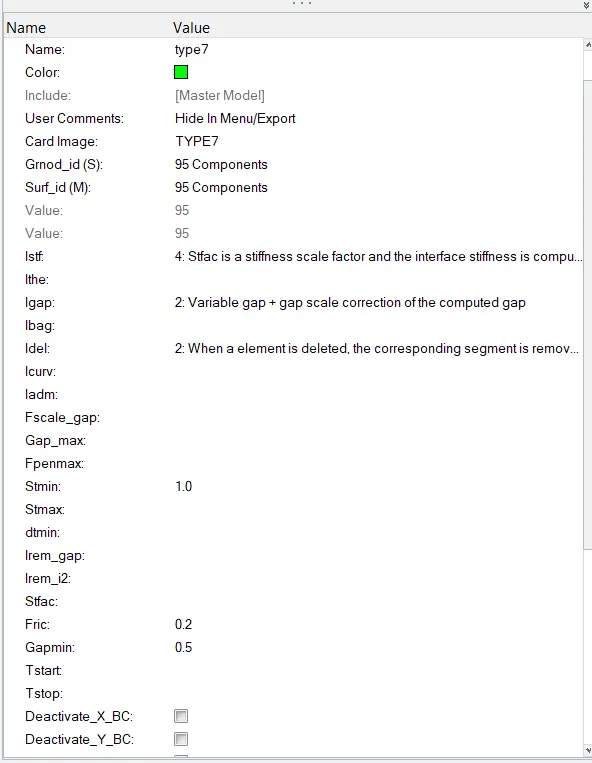
- check whether master and slave nodes selected proper
- For that Simply right-click on self-contact >> Review
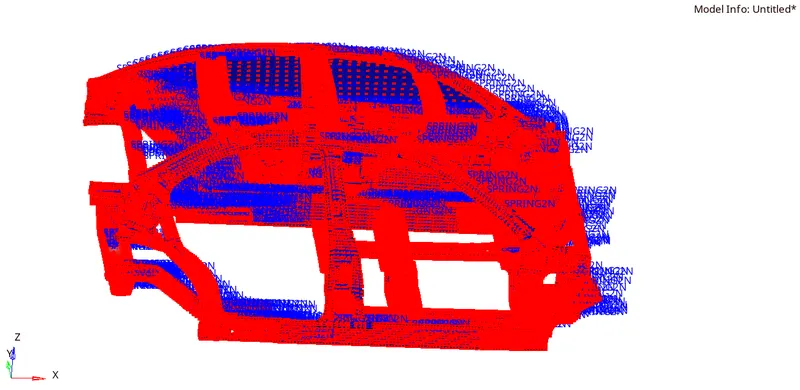
CREATE RWALL CYLINDER:
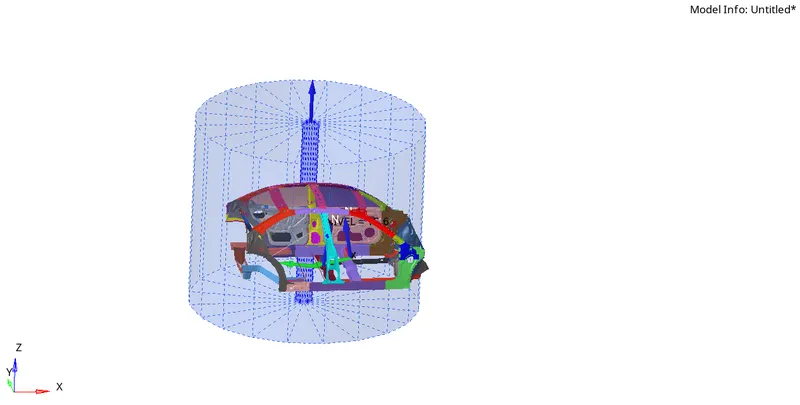
- A rigid wall is a nodal constraint applied to a set of slave nodes in order to avoid the node penetration to the wall. If contact is detected, then the slave node acceleration and velocity are modified. Mainly to constrain the movement of a moving body after impact, we will be using a plane wall. An infinite plane wall is a plane that extends to infinity. It is defined with two points.
- Rigid wall entities provide a method for treating a contact between a rigid surface and nodal points of a deformable body. In the Radioss user profiles, a rigid cylinder is created in the Model and Solver browsers.
- To create an RWALL Cylinder ,Go to Slover browser >> Create >> Rwall >> Cylinder
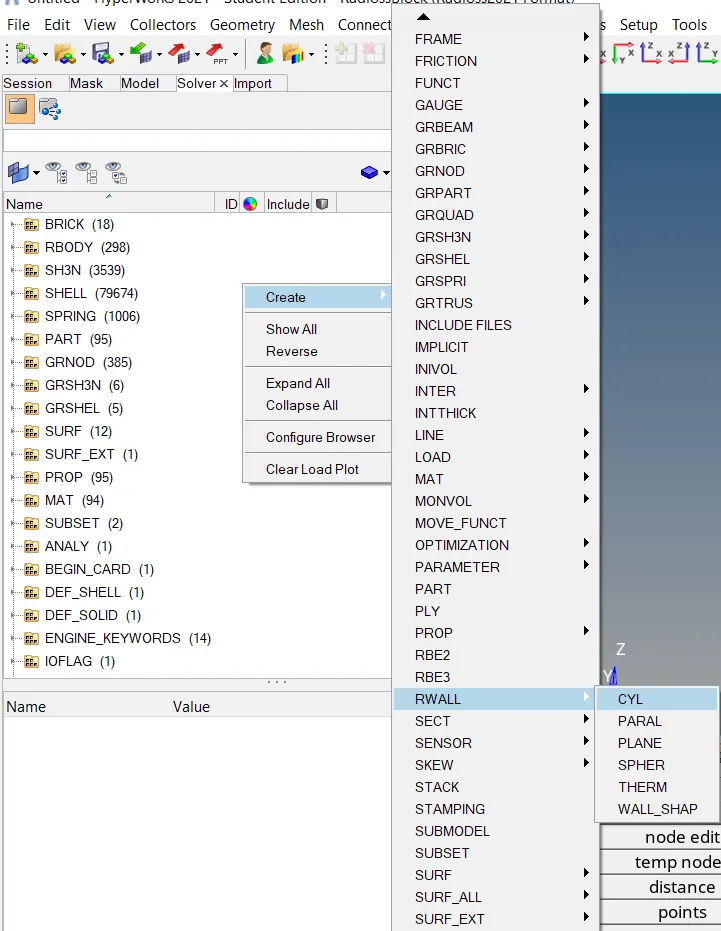
- We need a reference node to create an RWALL Cylinder so, for that, we are creating a temp node in the mid of B-Pillar
- Now translate this node to some distance with the reference of this translate node we have to create an R-wall Cylinder with respect to that CO-ORDINATES
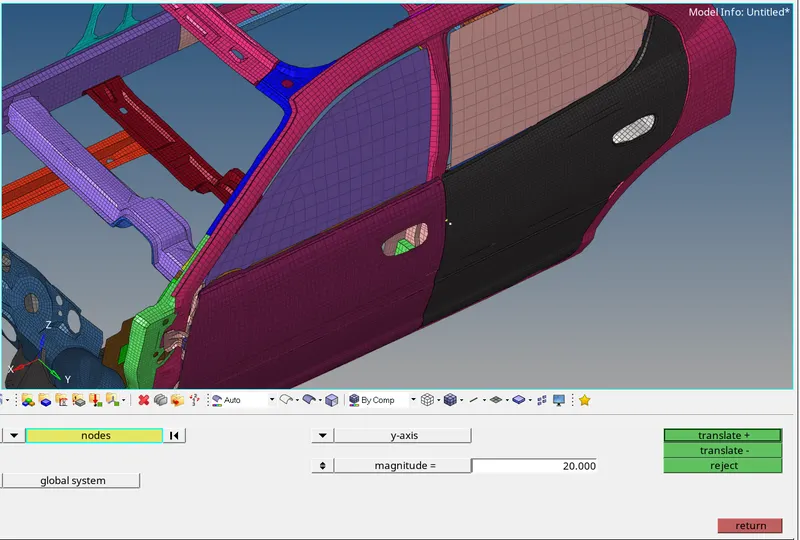
- It is a Shell element with no thickness (gap) and infinite thickness.
- A search tolerance is given (optional) so that the nodes within the range will be taken as slaves.
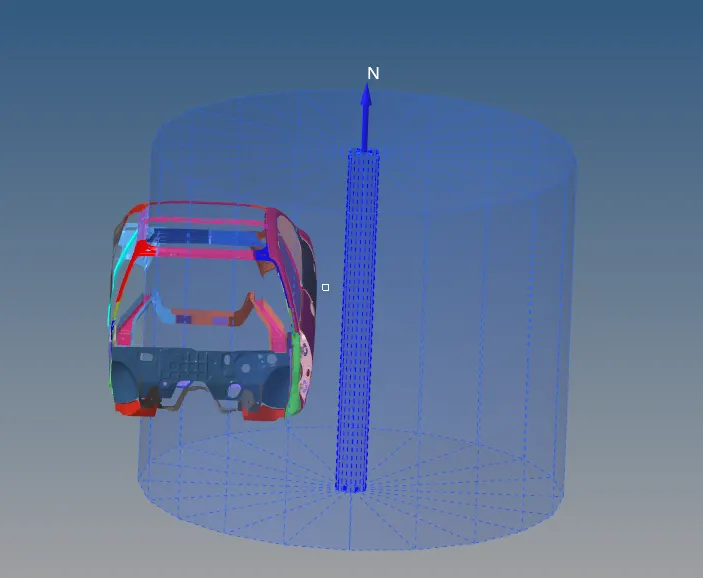
- We are going to create an Infinite Cylinder-type Rigid wall.
Enter the coordinates of the Temp node [XM, YM, ZM] >> Enter the Direction of the Normal [0, 0, 1] >> Select GRNOD_ID 1: set of displayed nodes >> Dsearch : 1000/1500 >> ok
The rigid wall is facing in the direction of the Y-axis.
- We have to provide frictional parameters for the rigid wall Cylinder when the slave nodes come in contact
- Friction type [Slide] = 2: Sliding with friction
- Frictional Coefficient [FRIC] = 0.1
- The D-search distance we can use around the range of 1000 mm. All the Nodes within this distance will be considered as salve nodes for the contact between the car and the Rigid Wall Cylinder.
- We can add a separate set of nodes to this Rigid wall Cylinder that the system should consider for Slave nodes in the option of [grnod_ID1]as shown below figure. We can use this option and add all the nodes in the model to the Slave nodes.
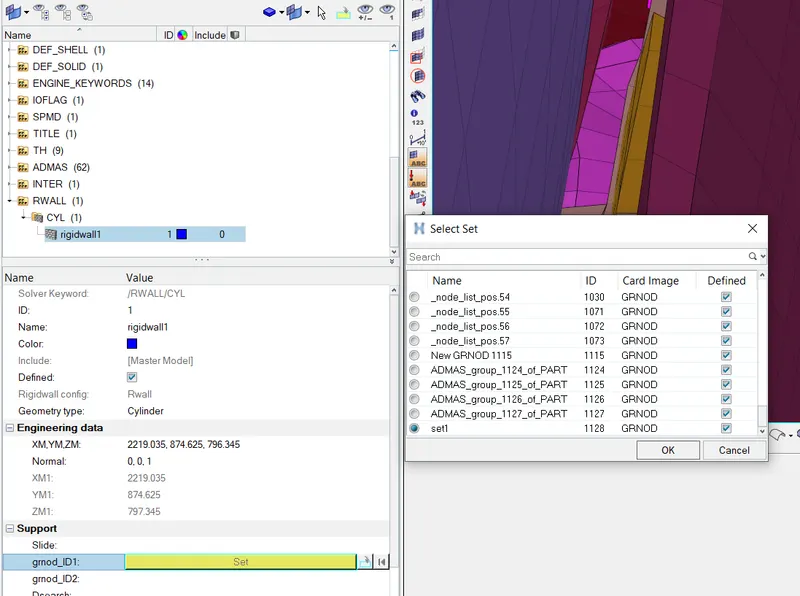
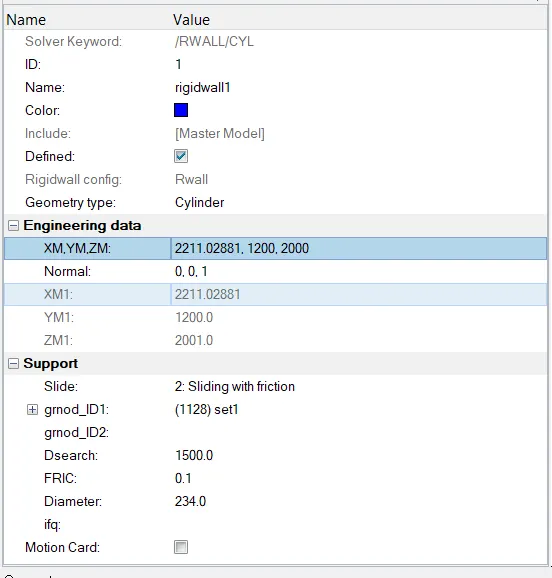
- Rigid wall with infinite Cylinder created
CREATE VELOCITY:
- Initial velocity 35 mph.
- Converting 35mph into ms
- 1mph = 0.447 ms
So, 35mph = 15.6464 ms
- The initial velocity (Vi) is the velocity of the object before acceleration causes a change. After accelerating for some amount of time, the new velocity is the final velocity (Vf).
- Initial velocity = [Final velocity - (acceleration×time)]
- vi = vf - at.
- vi = initial velocity (m/s).
- To create a velocity ,Go to solver browser >> Create >> Boundary conditions (BC) >> Inivel
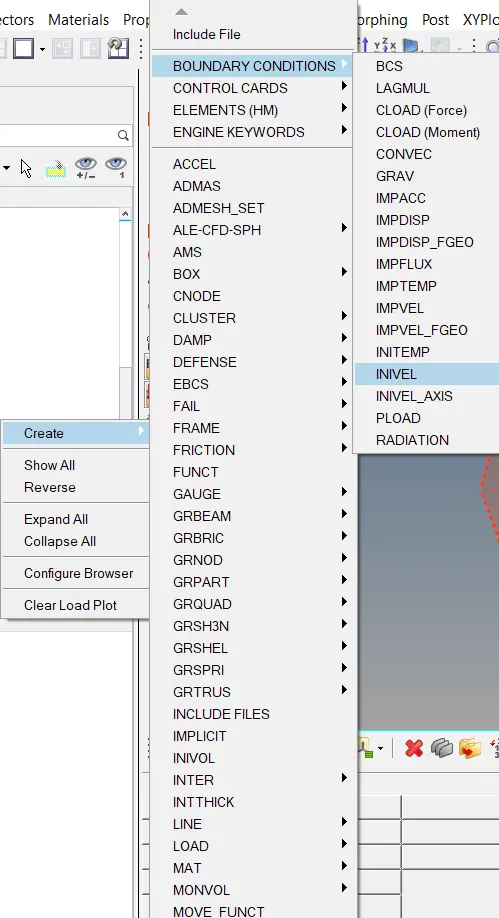
- Define the Node group on which specified initial velocities are applied(grnd_ID1).
- Define the Type of Velocity (Translational /Rotational).
- Since we need to apply the velocity in a translational Y-Direction, define the velocity 15.646m/s
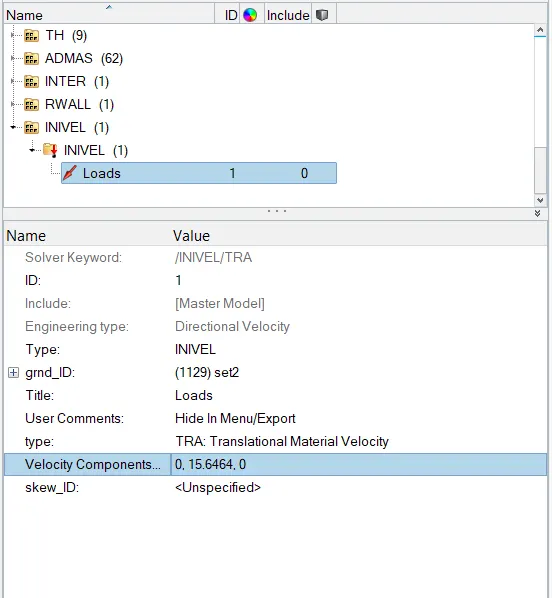
Review of inivel nodes
CREATE SECTIONAL FORCES:
- Creation of Sections at B-Pillar and Driver rail in order to Study the sectional forces
- We have to know how the forces are transmitted from the B-Pillar to the rails and the rate of deformation. It is done in order to ensure the safety of the passenger.
- Certain components have to crash (deform) more than the other so that the forces are distributed correctly leaving very little force left to transmit inside the cabin.
We are creating sections for the following parts:
|
Sl. no |
1 |
|
DRIVER SIDE SECTION |
Driver rail |
|
B-PILLAR SIDE SECTION |
B-Pillar rail |
- Create a moving frame: Use the Systems panel to create rectangular, cylindrical, and spherical coordinate systems. Use this function when you want to define nodes, loads, and constraints in a different coordinate system to create a section and Frame
- Go to Slover browser >> Create >> Section >> SEC >> Rename as Driver cross section
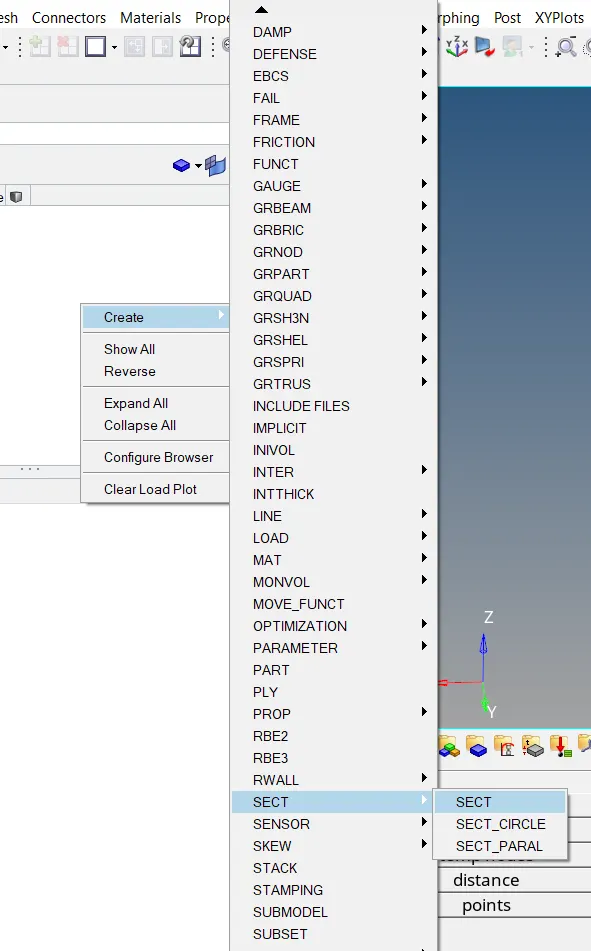
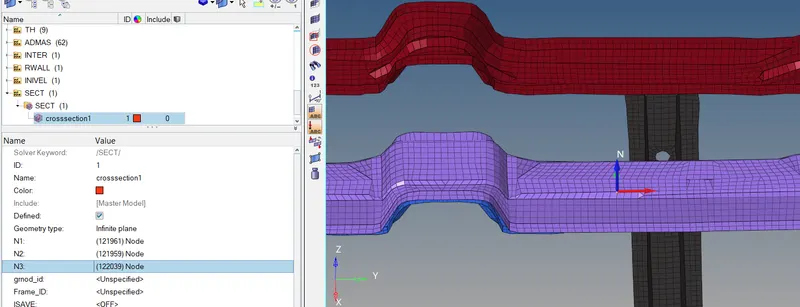
- Now when we create a section a new tab will display there, we have to select N1, N2, and N3 nodes
- We then need to select the three nodes on which we need the Frame system.
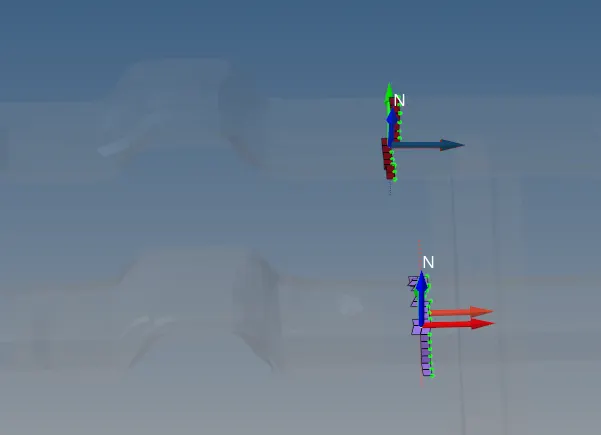
- In this case setup, we need to define around 6 sections.
- We need to make sure that the normal of all the sections defined need be in one particular direction. All the normal can be facing either the wall or even away from the wall. We need to make sure that they are in a single direction.
- We can create a Section just in the same way as we created a section system.
- We need to right-click in the solver browser and select frame
Creating moving frame
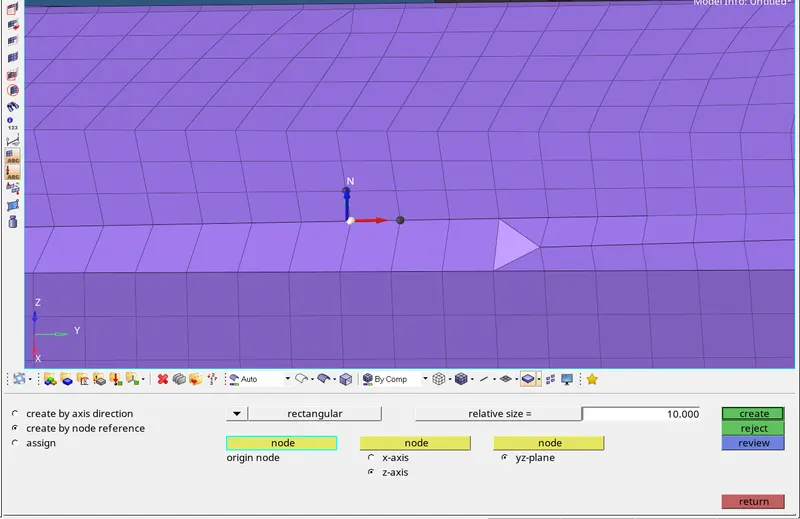
Now assign this frame system in section
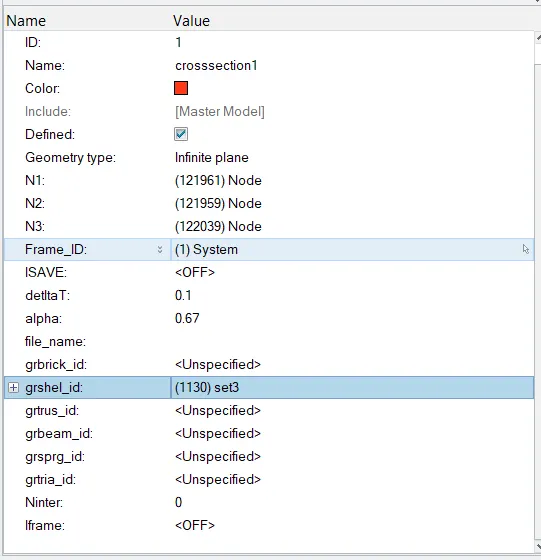
- Define the Nodes with reference to the Axis of the Frame.
- Enter the values of Delta T and Alpha Value as 0.1 and 0.67 respectively.
- Define the cutting plane by a group of elements and its orientation by a group of nodes(grshell_ID)
- Hence, the sections will be created.
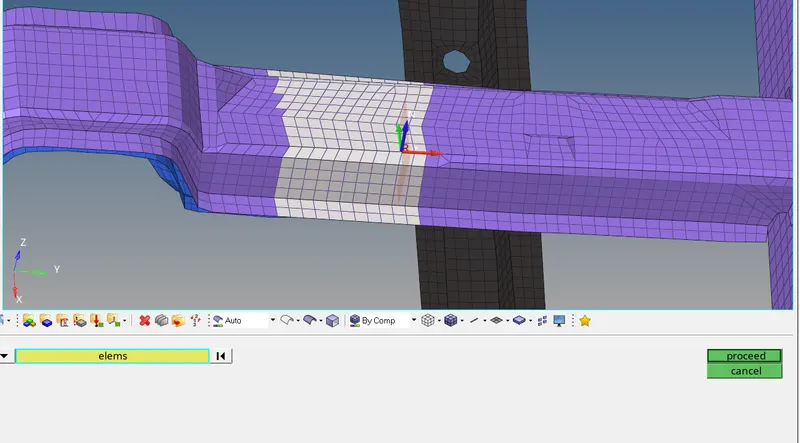
Section Tab
All Two section created
CREATE SPRINGS:
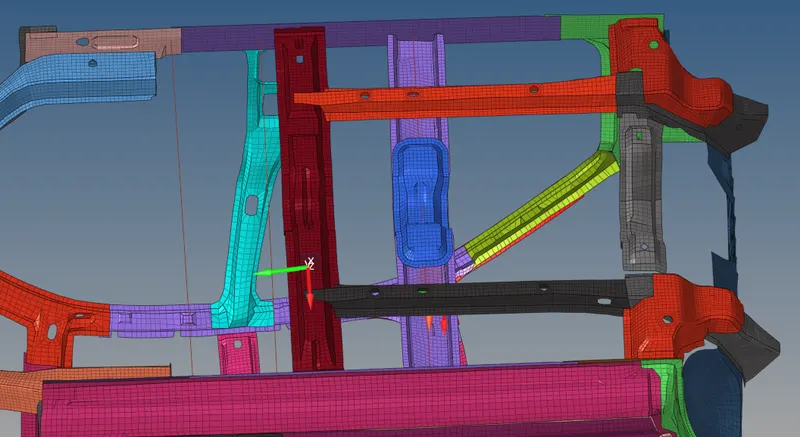
- We are planting Spring elements to study the intrusions (forces inside the cabin causing deformation/rupture).
- Create 3 parallel spring elements.
- Springs can be created from the 1D Panel > Springs
- To create a spring first as temp node at that particular selected node then select another node on other to see deflection after crash simulation
- After adding nodes now
- Go to 1D page >> Springs >> Select first and Second node >> Create spring
CREATE PROPERTIES TO SPRINGS:
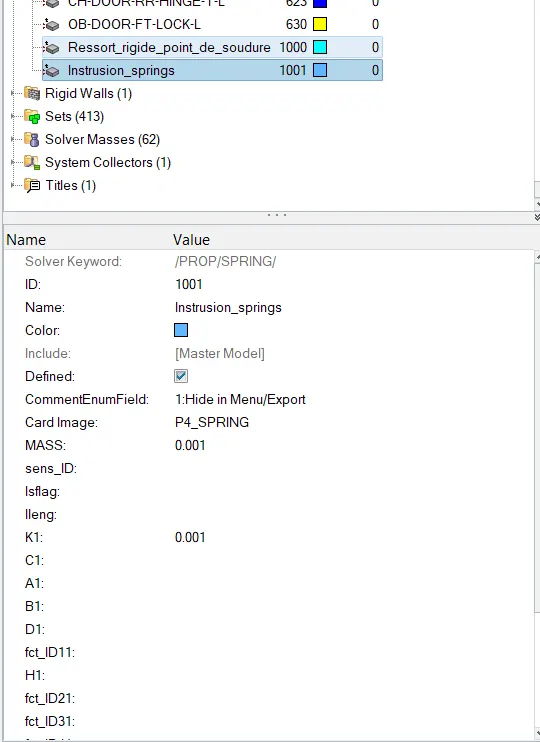
- To create spring property
- Go to model Browser >> Create >> Property >> Rename as Intrusion springs
- After creating a property, a new tab will open there we have to select CARD image as P4 SPRING and Mass as 0.001, and Stiffness as 0.001
REQUESTING TH FOR INTRUSION SPRINGS, PEAK VELOCITY NODE, SECTION FORCE:
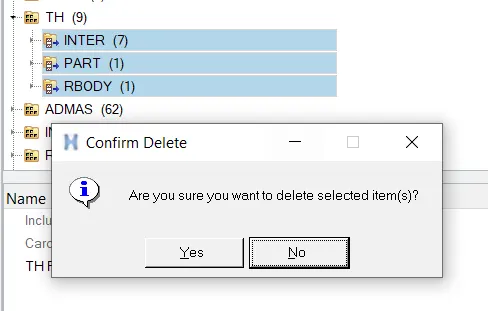
- Delete existing TH and create new
They are Output files that are requested in the Starter File.
- All the Global variables (Internal energy, Kinetic energy, Contact Energy, Hourglass Energy, etc.) are already requested by default.
- We have to call for additional Time History files for the boundary conditions that we have created for the frontal crash model.
- We can create the Output requests from within the Solver Browser:
- Solver Browser > Right Click > Create > TH > Select the Output Request
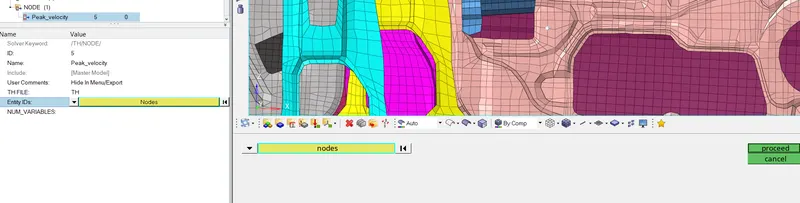
- To create TH ,Go to Slover browser >> Right-click >> Create >> TH >> Select node >> ok
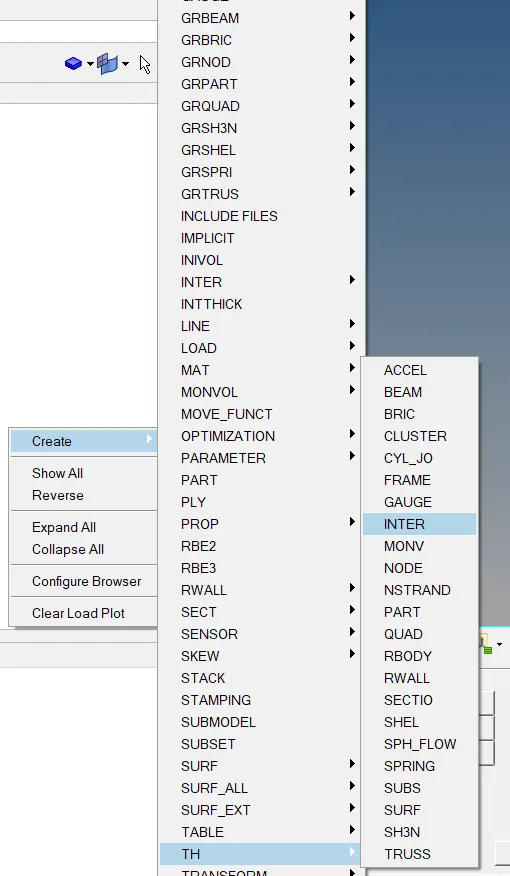
- Creating TH for node
- Follow the same steps to create other TH as well
CREATE REQUIRED CARDS:
TIMESTEP CONTROL
|
Engine Card |
T SCALE [Scale factor] |
Tmin [Critical Timestep] |
Description |
|
ENG_DT_NODA |
0.67 |
0.001 |
Mass is added to the node when the computed timestep becomes smaller than the critical timestep. |
|
ENG_DT_BRICK |
0.9 |
0.0001 |
Controls the timestep by small strain formulation on the elements if they cause the timestep to drop. |
|
ENG_DT_INTER |
0.9 |
0.0005 |
Uses the default constant timestep method. |
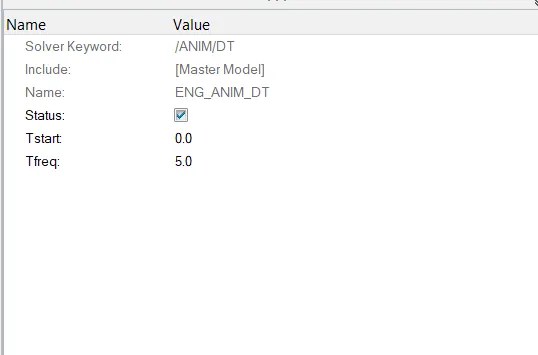
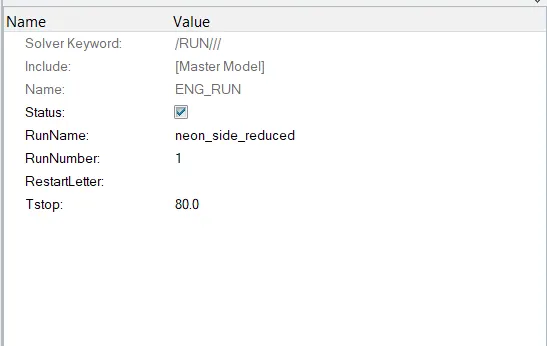
- Enter T stop as 80ms and T freq as 5
- Go to ENG_RUN enter T stop as 80ms
- For T freq
- Go to ENG_ANIM_DT enter T freq as 5
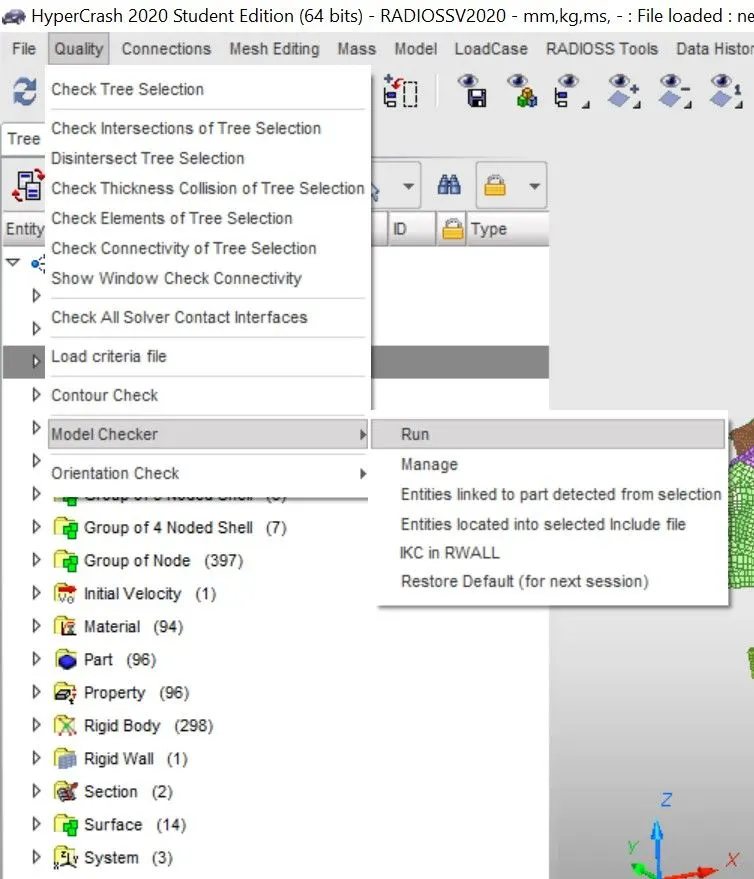
MODEL CHECKER:
Finally, before carrying out the RADIOSS analysis, an error check was run on the file through Hypercrash. The model check tool can be accessed through
Quality > Model Checker > Run from the upper toolbar.
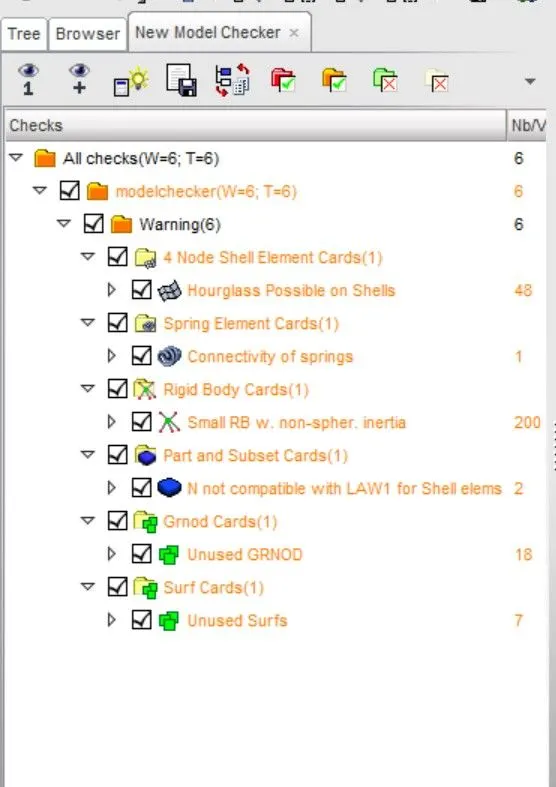
result is shown in figure below..there are no errors present in the setup only a few warnings that we can avoid
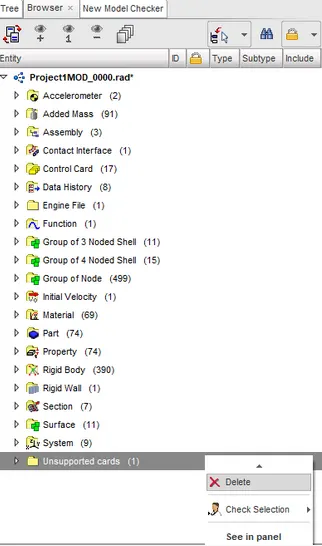
In addition to that, if there are any unsupported cards in the model browser, they can be deleted.
RUN THE ANALYSIS:
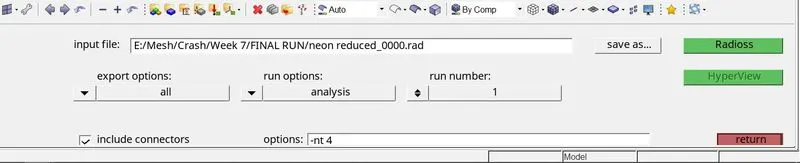
- Analysis >> Radioss >> Input File: (File Location) >> Hit Radioss
- The input file is the same Started file (contains model information) that we had just imported.
- The animation video along with the frames will be saved in the same folder where the starter file exists.
ANALYSING THE OUTPUT FILE
The next step is to carry out energy error and mass error checks and this is done by analyzing the RADIOSS engine output file. This can be accessed from the same directory as the starter and engine files and is denoted by the '.out' extension. The file in question contains '_0001.out' and can be accessed using any text editor - such as Notepad.
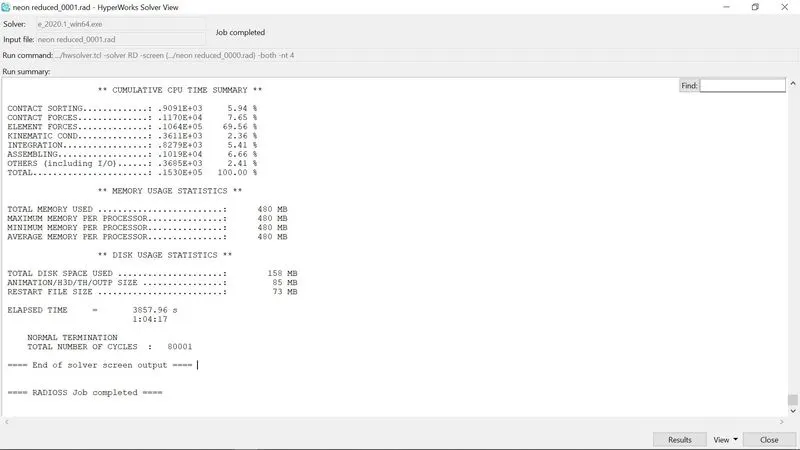
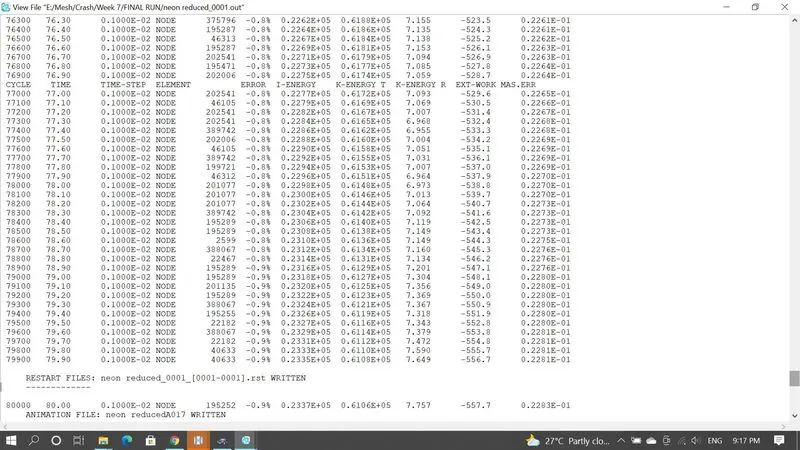
As we can see, the energy error is -0.9%. It is definitely acceptable due to its proximity to 0% error. In addition to that, the mass error is 0.0220%,only, which is acceptable.
Total Simulation Time: 3857.96 s
Total Number of cycles: 80001
SIMULATION ANIMATION
To view the simulation, we can switch to Hyperview through the client selector.
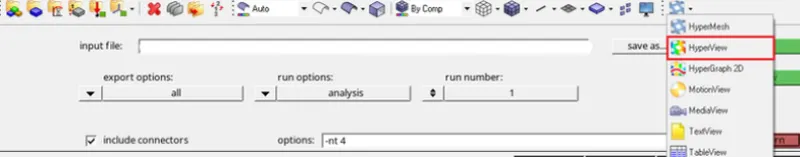
In Hyperview, we will need to import the h3d variant of the file. After importing, we can then select the 'contour' tool to switch to the Von Mises contour so we can analyze the stresses that form within the BIW in the simulation. This is what the simulation looks like:
In the above crash simulation of the vehicle, we can see the vehicle BIW is impacting on a Pole. After the impact, the frame of the vehicle deforms and the vehicle body gets contracted around the pole with left B-Pillar as the pivot point. The CG of the vehicle is in the same axis or direction of the pole, so we can see even deformation of the frame around the pole.
From the Von Mises stress plot, we can say that the stress distribution is quite good in the vehicle after the crash. There are very few areas where we can see stress concentration. Generally the stress is more in B-pillar and cross members as B-pillar takes the initial impact and then the impact is transferred to the cross members.
From the simulation, we can see that initially, the car is hitting the R-wall cylinder with a velocity of 35mph, while the first impact is with B-Pillar then the forces going to transferred to the left and right and front direction in the roof rail and cross members in the bottom as shown in below figure. In each stage, transfer of force is going to reduce because energy absorbed by the components
GENERATING OUTPUT PLOTS
After generating the simulation, we can then go ahead and generate the plots. Using the same client selector, we can switch to Hypergraph. In the Hypergraph client, we need to import time history file T01 file
On importing, we can build the plots using different variables. We shall first look at general plots of energies and rigid wall forces generated in and by the entire BIW respectively.
Global Variable - Energies
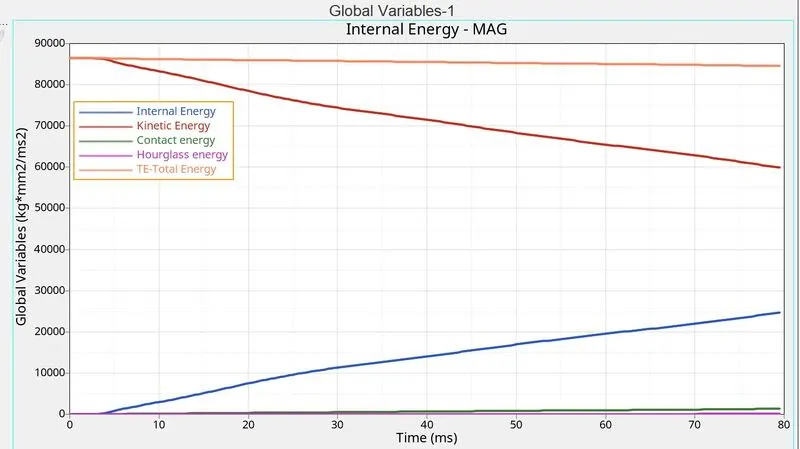
The changes in kinetic and internal energies occur at the exact moment the BIW makes contact with the rigid cylindrical wall. Understandably, the BIW loses kinetic energy throughout the simulation due to the obvious decrease in velocity. At the same time, it absorbs the forces, and this results in an increase in internal energies, and as a result, the deformations also occur.
Taking a look at the contact energy graph:
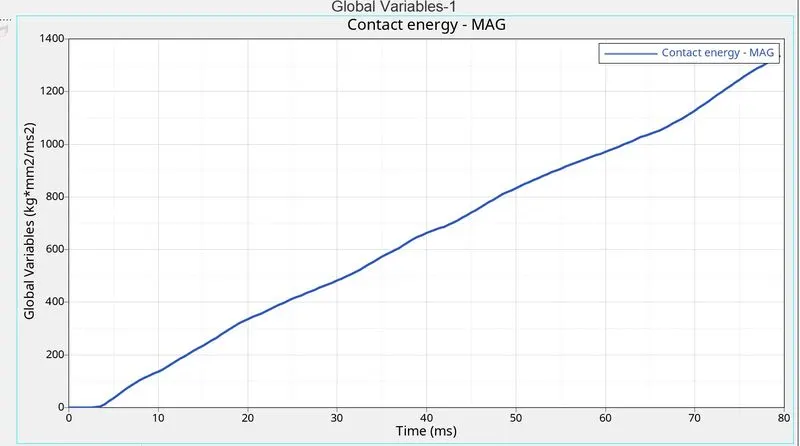
Contact energy is a type of energy that is formed when one element comes in contact with the other or neighboring elements. The opposing force created by this element forms the contact energy. In this case, it takes off after 7 ms, at this point the model starts deforming in such a way that penetration of nodes occurs. When certain regions of the model press on themselves, buckled elements are forced into contact.
The increase in contact energy affects the overall energy of this system, which is why there is a decrease in the total energy over the course of the simulation - it is a comparatively negligible decrease though. The magnitude of contact energy generated is much lower compared to that of the energies in the previous plot.
From the above graph, we can see that the Hourglass energy is almost negligible since we have used Improved integrated element formulation (QEPH).
Rigid Wall Forces
Taking a look at the rigid wall forces generated:
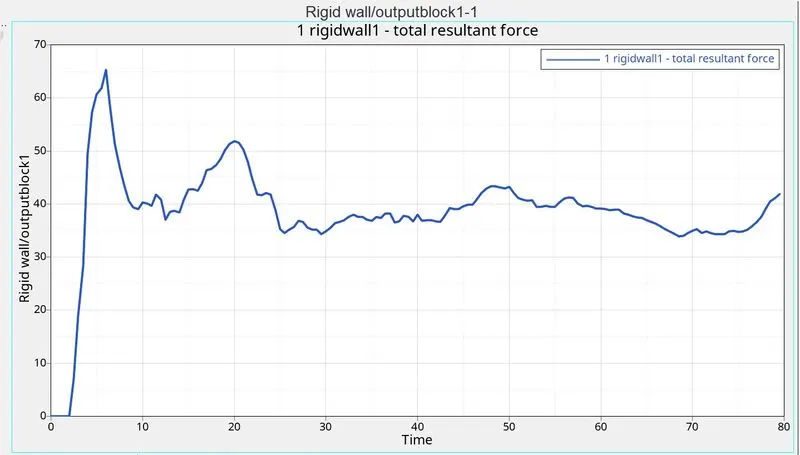
As it can be seen in the starting, rigid wall force generated is zero till 3 ms of simulation because of no contact, but at the 6 ms there is peak rise in the wall forces to a value of 65KN which is the point of first impact, Then rigid wall force decreases and stabilize to a constant value between 35 to 45 kN.
Sectional force on Cross-member:
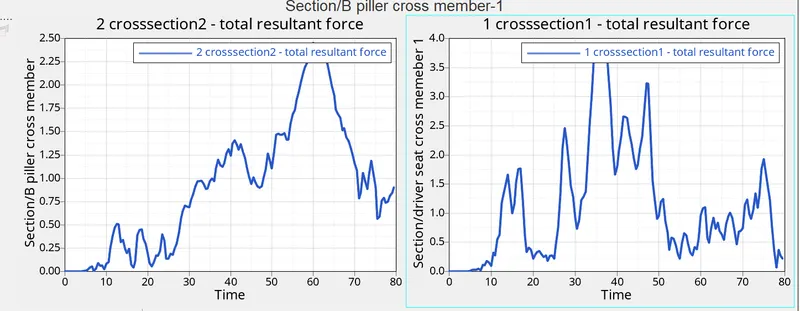
Cross-members are very crucial in the side-impact analysis as these components prevent the body to shrink or deform inward. When the car hits the rigid body maximum amount of forces will pass through the cross member of the base and roof. This component along with door bar and support, door outer, B pillar, and rocker are also involved in the majority to prevent deforming. But the forces acting on every other component eventually pass from the cross member.
The max sectional force at the B-pillar cross member is 2.45 KN at 60 ms and for the driver seat cross member it is 3.87 KN at 37 ms.
Peak velocity at Inner Door:
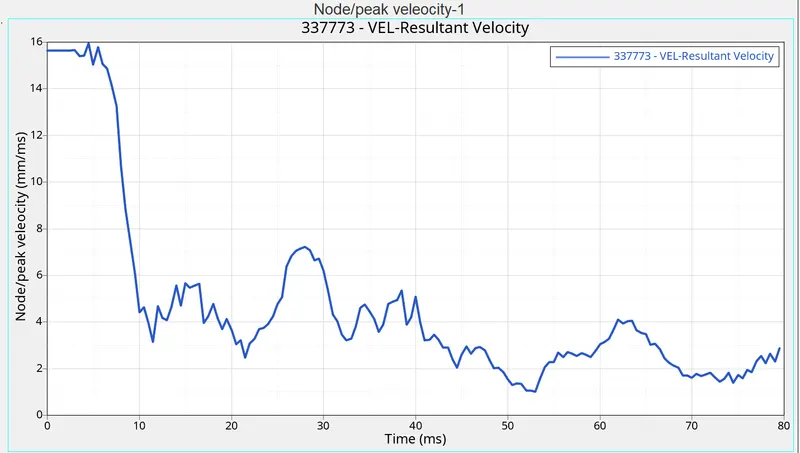
As we all know that when the car hits the pole first impact will be the door and due to the deformation, the inner portion of the door might hit the passengers inside the car and lead to injuries. Hence it is important that the Peak velocity at the door region is to be calculated.
From the Graph, the peak velocity of the node on the door is 15.94 mm/ms at 4.5 ms. The velocity of the node is almost constant before hitting the rigid cylindrical wall (up to 2 ms). After impact, there is a steep drop and then a small rise, probably due to the folding deformation created as the crash progressed (due to inertia). As time passes, we can see the velocity gradually decreasing.
Intrusion inside the car at B pillar, hinge pillar, and fuel tank:
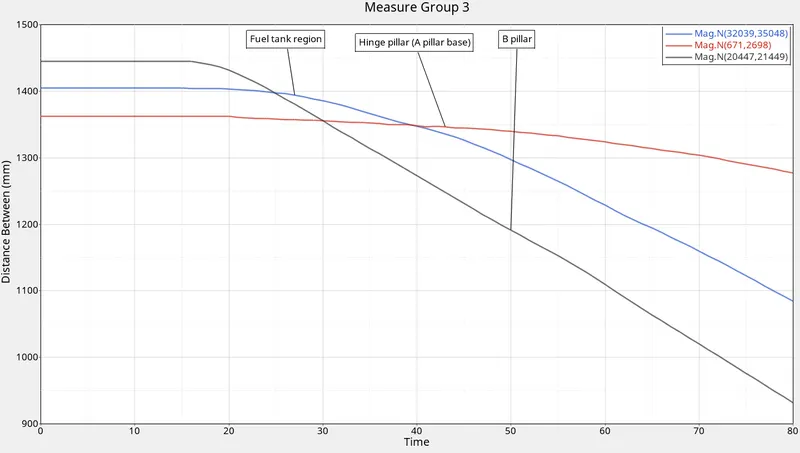
The intrusion or deformation of the component can harm the occupants and the inner part of the car like a fuel tank. From the above plot, it is obvious that intrusion near the fuel tank is 320mm and near the B pillar is 530 mm which are substantial.
The fuel tank region received the least displacement, followed closely by the B-Pillar, then the Hinge Pillar. Admirably, the B-Pillar was able to absorb a lot of the impact due to multiple reinforcement members attached to it and in its vicinity, despite being one of the first regions of impact in the crash. The hinge pillar did not have any reinforcements and hence suffered the most displacement.
This intrusion must be avoided by using some alternative method or by using any composite material which can withstand load near the fuel tank.
Alternative Method to reduce intrusion near fuel tank
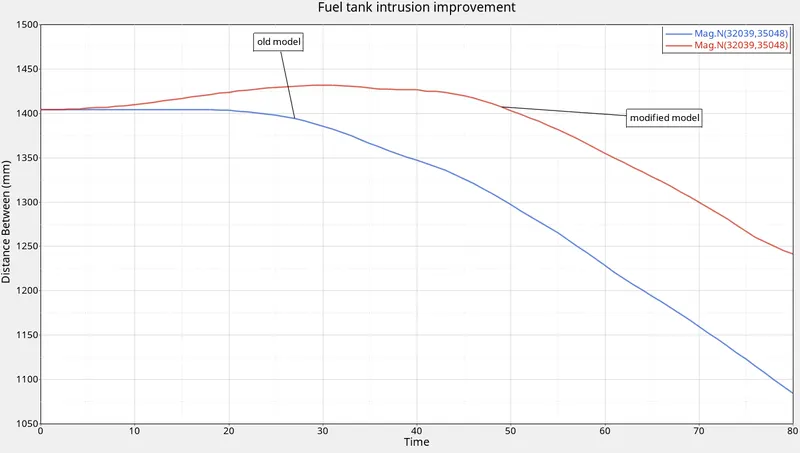
The alternative method used for reducing the intrusion near the fuel tank region is the additional crossbeam. The crossbeam is situated between the base C pillar as shown below:
The cross beam seems to reduce the fuel tank intrusion by 160 mm which is significant. The problem might be a material cost which will increase by adding an extra cross member . it shows that fuel tank intrusion can be reduced to some extent by adding an additional cross beam, The difference is shown in the plot below:
RESULT & CONCLUSION
Side crash analysis was carried out on the given BIW model of the Dodge Neon as per requirements. The output requests were also generated after the creation of cross-sections in each of those regions. Peak velocity and intrusion values were also measured at certain points of the model.
Fuel tank intrusion and intrusions, in general, could be reduced by using anti-intrusion beams (or side-impact beams) between the pillars. They increase the rigidity of the doors and distribute the energy in the event of a side-on crash. The model already does have such beams as shown:
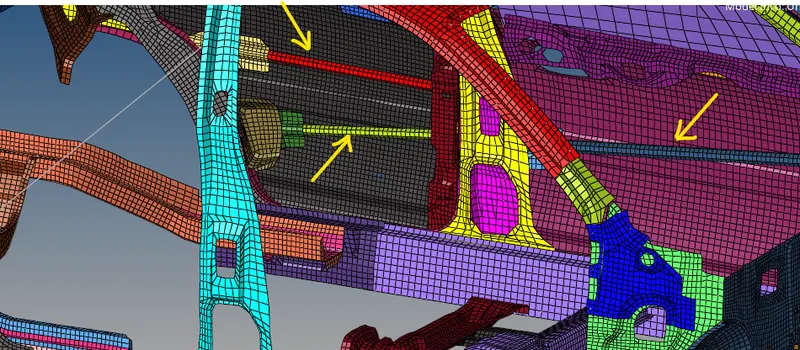
There may be stronger options for anti-intrusion bars but there is the weight-to-cost factor that might be a major factor. There are multiple materials other than steel such as aluminium and composites being tested that are lightweight but effectiveness is more or less comparable. If more bars can be used, that could be an option as well.
Otherwise, another option is to simply add an extra cross member next to the fuel tank to reinforce that region.