Assignment 7
AIM:
To do "SIDE CRASH ANALYSIS" for the given "Neon side crash -BIW" car model using "HYPERMESH AND HYPERCRASH".
OBJECTIVE:
Neon side crash -BIW
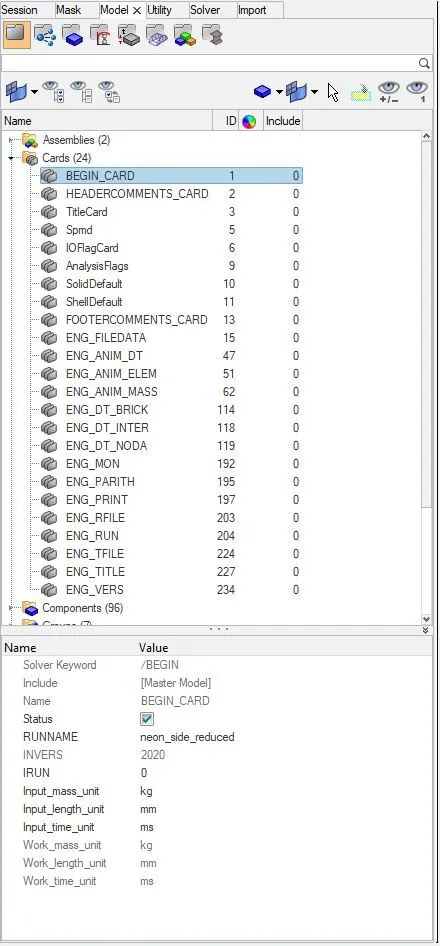
- To Check unit system and either follow [Mg mm s] or [Kg mm ms].
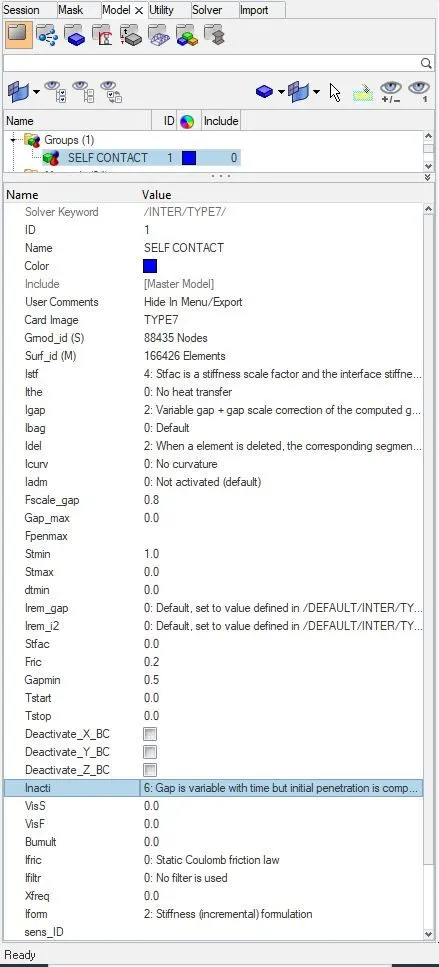
- To Create appropriate interface ,friction 0.2 and recommended parameters.
- To Make sure of no penetration and intersections.
- To Create rigid wall with friction 0.1 as per referance model.
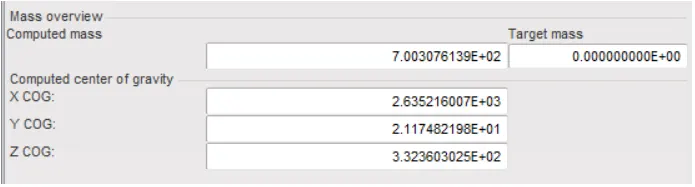
- To Compare the model weight with the referance model and use added masses to reach target weight 700kg while getting CG about the required range.
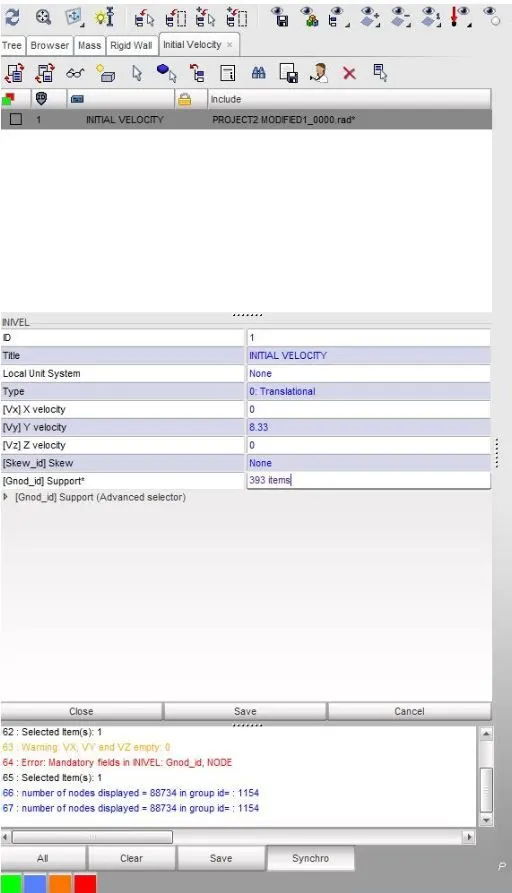
- To give Initial velocity as shown in picture.
- To Use model checker to ensure good quality.
- Timestep :0.5 to 0.1 microseconds.
- Run 80ms.
Output requests:
- Sectional force in the cross member.
- Intrusion at B pillar,hinge pillar and fuel tank region.Provide recommendation on what can help to reduce Fuel tank intrusion.
- Peak velocity of inner node of the door.
PROCEDURE:
IN NEON SIDE CRASH-BIW
1) WE HAVE TO CHECK "UNIT SYSTEM" AND WE HAVE FOLLOWED [Kg mm ms] AS SHOWN BELOW:
WE SHOULD ALSO CHECK FOR DENSITY AND YOUNG'S MODULUS OF THE COMPONENT'S MATERIAL:
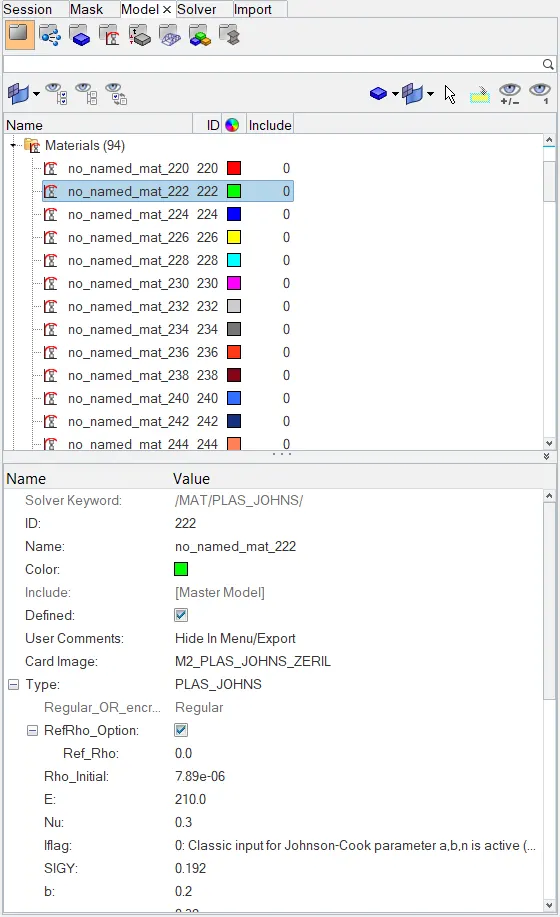
BY THE ABOVE IMAGE WE KNOW THAT:
DENSITY : 7.89E-06 `(Kg)/(mm^3)`
YOUNG'S MODULUS : 210GPA
2) WE HAVE TO CREATE APPROPRIATE INTERFACE FOR THE GIVEN CAR COMPONENT WITH ALL THE RECOMMENDED PARAMETERS AS SHOWN BELOW:
SELF CONTACT OF THE CAR BY USING "TYPE-7 INTERFACE":
3) WE SHOULD MAKE SURE OF NO "PENETRATION" AND "INTERSECTION" OF SLAVE NODE INTO MASTER SEGMENT:
IN HYPERMESH:
GOTO: "Tools" > "Penetration Check" > "Then hit CHECK"

IN HYPERCRASH:
GOTO = "Quality" > "Check all solver contact interfaces"
A) PENETRATION CHECK:
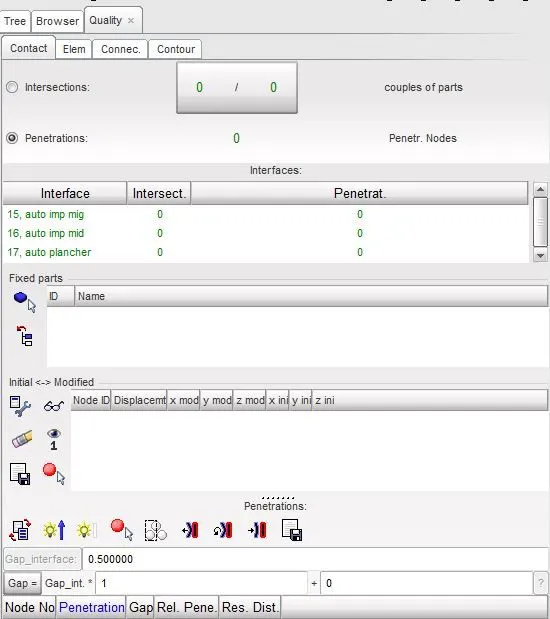
From the above image we can say that there are no penetrations happening in the given model.
B)INTERSECTION CHECK:
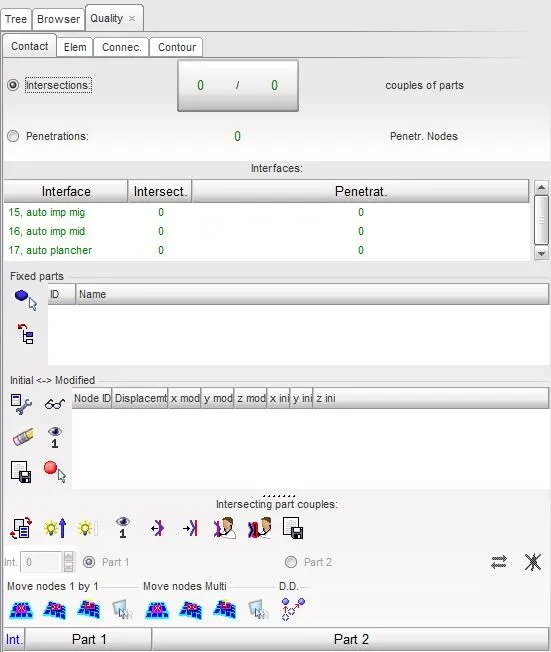
So, as per the above image, both "INTERSECTION" and "PENETRATION" are "0".
4) HERE IN THE ABOVE QUESTION THEY HAVEN'T ASKED FOR "CORRECTING RIGID BODIES", BUT BEFORE RUNNING ANY SIMULATION WE SHOULD CHECK FOR IF THERE IS ANY FREE PARTS, AND IF THERE ARE FREE PARTS WE NEED TO CONNECT
- But before running any simulation we need to check if there are any free parts in the given model.
- And if there are any free parts detected, we should connect them to the Parent body.
- If we don't connect these free parts, when we run the Crash simulation, these unconnected free parts will fly away from there intial position when the Parent body crashes into the RIGID WALL or RIGID CYLINDER.
IN HYPERMESH:
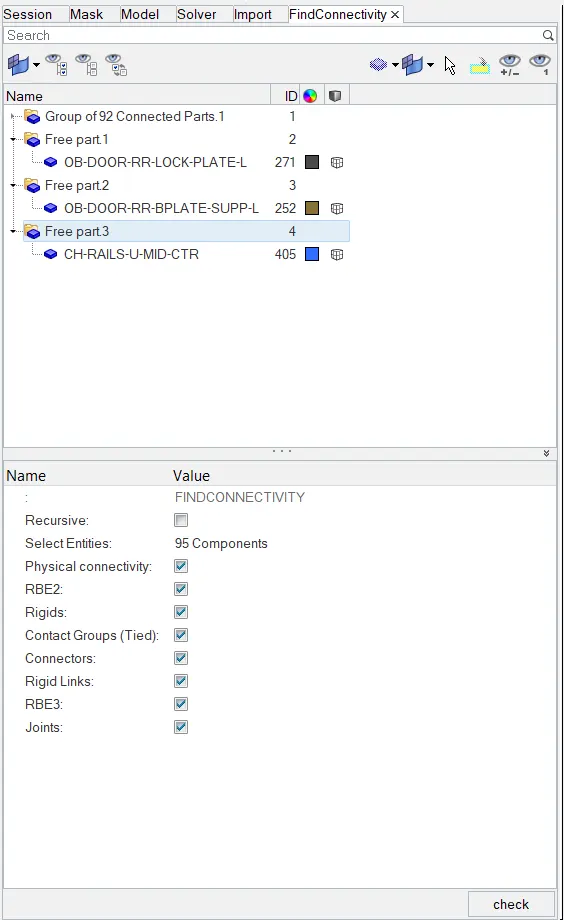
GOTO: "Tools" > "Find Connectivity" > "Check"
IN HYPERCRASH:
GOTO: "Quality" > "Check Connectivity of tree selection" (During this we need to goto tree and select the top most tree, which in turn selects all)
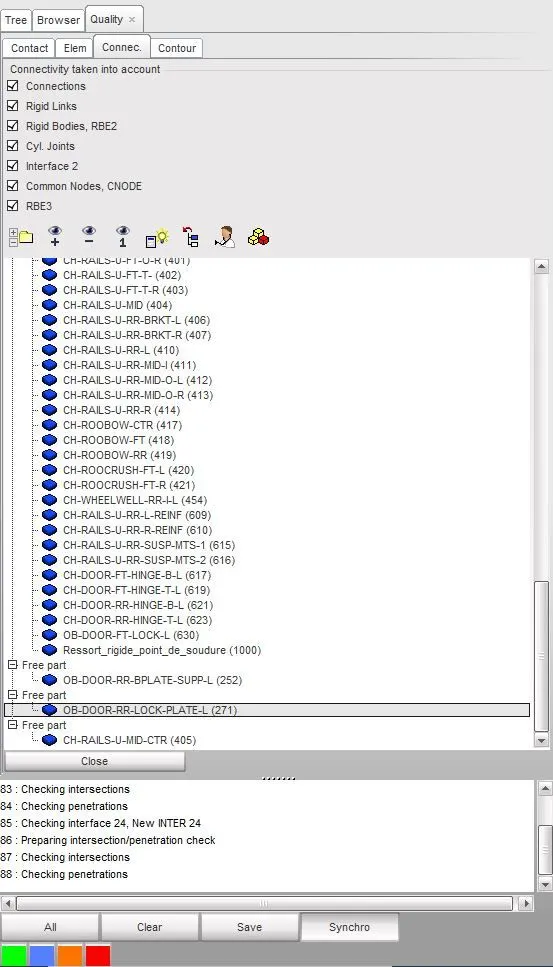
- As we see in both "HYPERMESH" and "HYPERCRASH", we see that "252", "271" and "405" are the free parts, we need to connect all those free parts to the main car body.
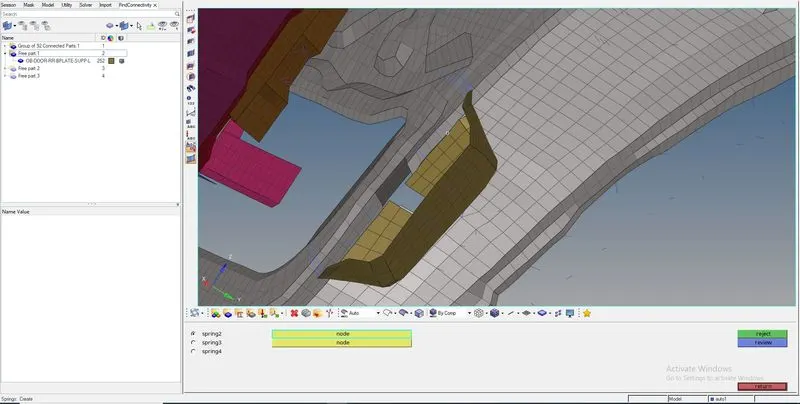
THE BELOW IMAGE SHOWS FREE PART "252" IS BEING CONNECTED TO THE MAIN CAR BIW STRUCTURE USING SPRINGS IS AS SHOWN BELOW:
THE BELOW IMAGE SHOWS FREE PART "271" IS BEING CONNECTED TO THE MAIN CAR BIW STRUCTURE USING SPRINGS IS AS SHOWN BELOW:
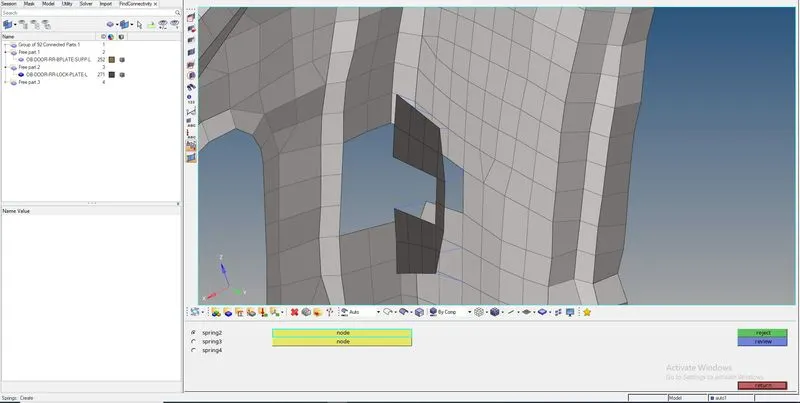
THE BELOW IMAGE SHOWS FREE PART "405" IS BEING CONNECTED TO THE MAIN CAR BIW STRUCTURE USING SPRINGS IS AS SHOWN BELOW:
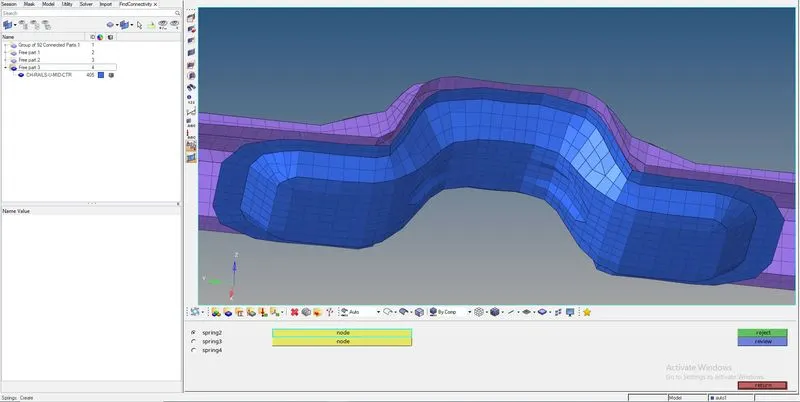
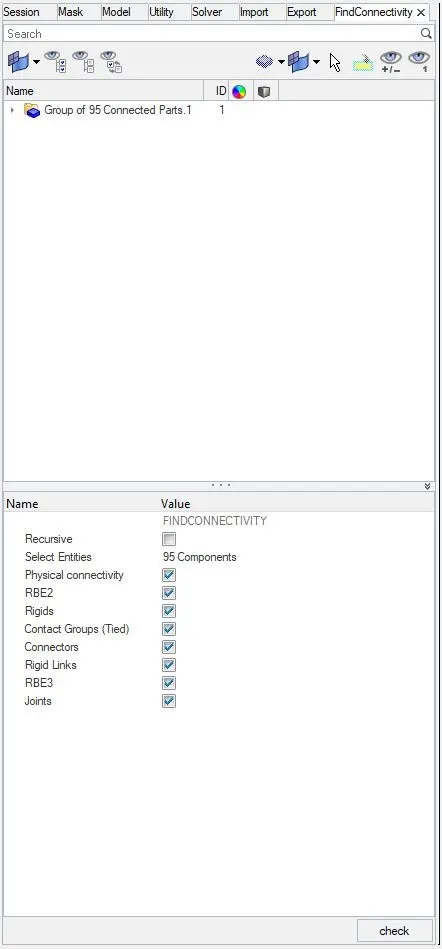
AFTER CONNECTING THOSE FREE PARTS, IF WE CHECK FOR "FIND CONNECTIVITY" IN "HYPERMESH", WE SEE AS IN THE BELOW IMAGE, THAT IS NO FREE PARTS ARE FOUND AFTER CONNECTING:
5) CREATING RIGID WALL WITH FRICTION 0.1
IN HYPERMESH:
GOTO: "View" > "Browser" > "Hypermesh" > "Solver" > "Right click and create new" > ""In GEOMETRY TYPE = INFINITE PLANE"
IN HYPERCRASH:
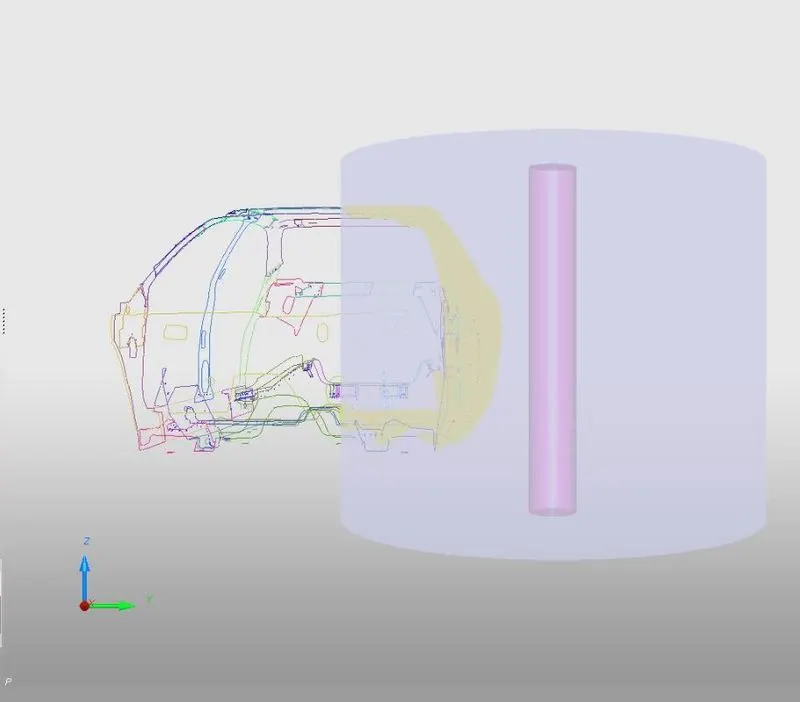
GOTO: "Browser" > "Right click" > "Create new" > "Rigid wall" > "Rigid walls" > "Cylinder" > "Dia of the cylider to be 254mm" > "With appropriate D_Search", as shown in the below image:
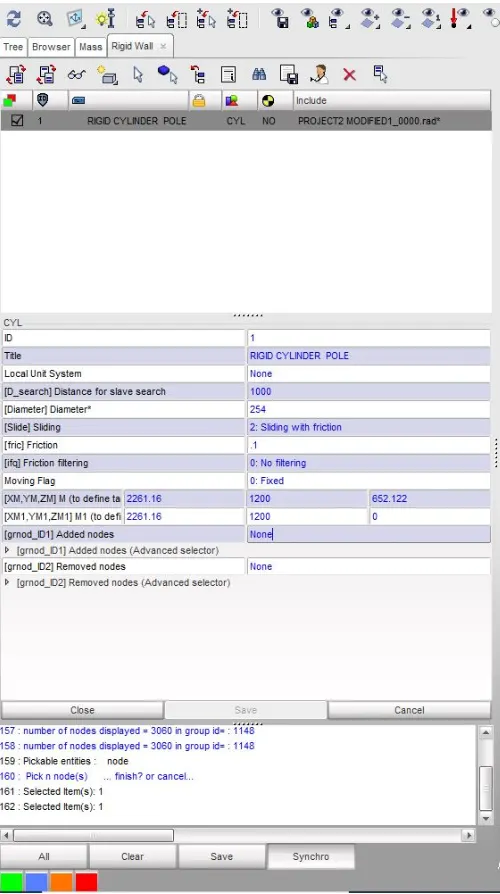
IMAGE OF RIGID CYLINDER AT THE SIDE OF THE CAR:
6) WE HAVE TO USE "ADDED MASSES" TO REACH TARGET WEIGHT OF "700KG" WHILE GETTING "CENTER OF GRAVITY" ABOUT THE REQUIRED RANGE AS SHOWN BELOW:
- We can't view "C.G" point in "HYPERMESH"
- So we use "HYPERCRASH" to view "C.G" point
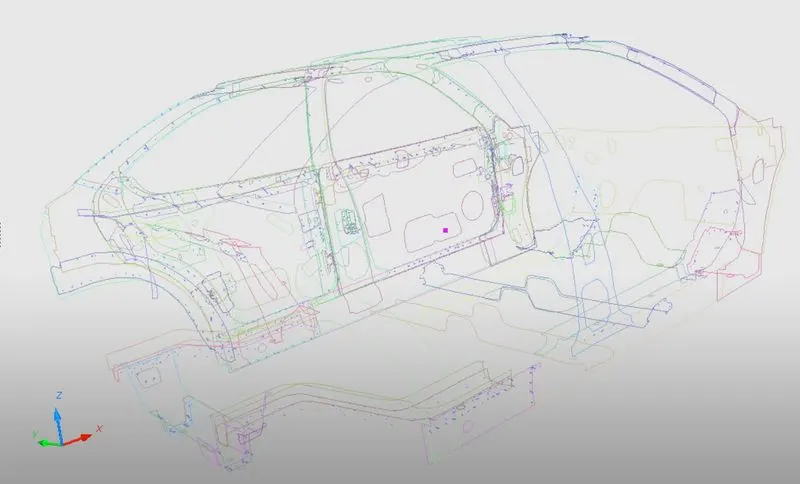
- To view "C.G" point in "HYPERCRASH", we have to GOTO: "Mass" > "Balancing" > "Click on the icon which represents View COG point".
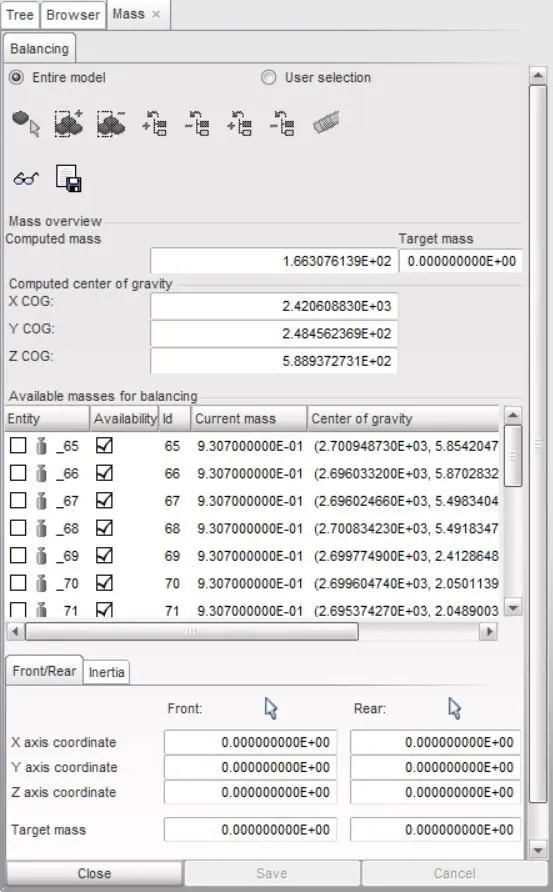
INITIAL MASS BEFORE ADDING ANY MASS:
COG POINT BEFORE ADDING MASSES IS AS SHOWN BELOW: "COG POINT IS REPRESENTED BY A PINK POINT IN THE MODEL" :
NOW WE HAVE TO MOVE THIS "COG" POINT TO THE CENTER OF THE CAR BY ADDING MASSES ON THE FLOOR OF THE CAR AS SHOWN BELOW:
GOTO: "Browser" > "Right click" > "Create new" > "Added Mass"
ADDED MASS ON BOTH LEFT AND RIGHT CROSS MEMBER OF THE CAR AS SHOWN BELOW:
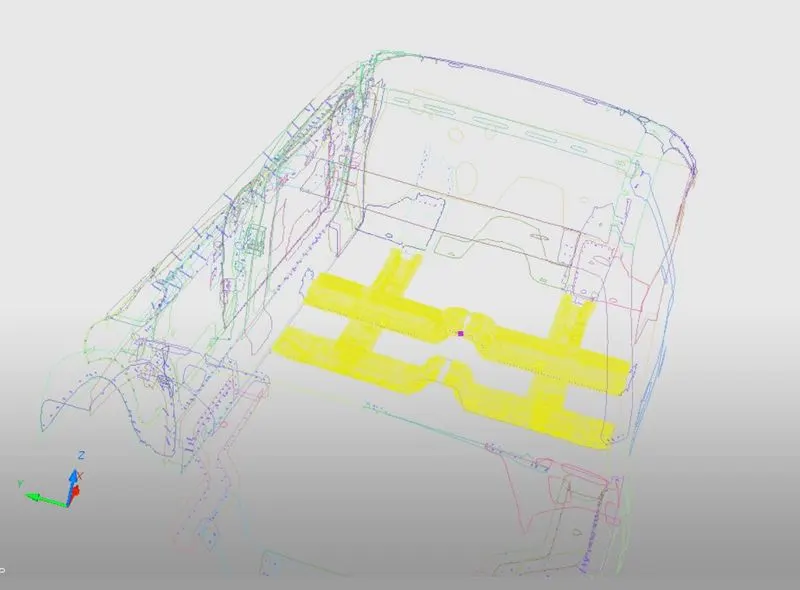
"COG" POINT AFTER ADDING MASSES AS SHOWN BELOW: "COG POINT IS REPRESENTED BY A PINK POINT IN THE MODEL:
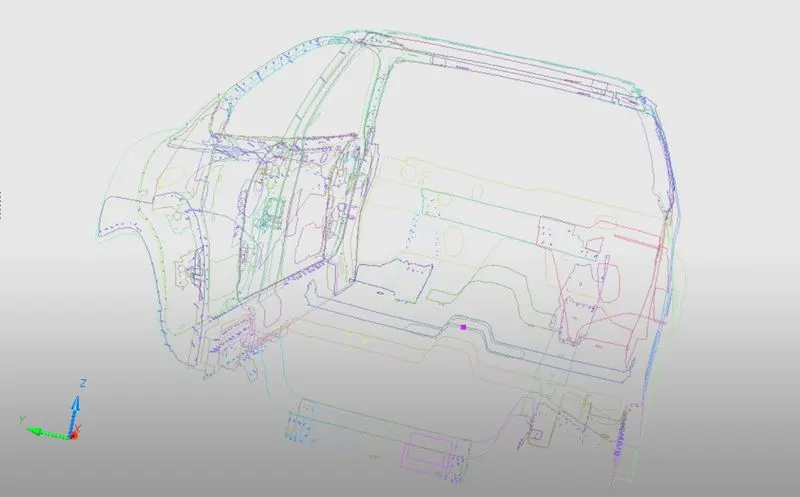
TARGET MASS OF 700KG AS SHOWN BELOW:
7) WE HAVE TO ASSIGN "INITIAL VELOCITY" TO CAR MODEL, AS SHOWN BELOW:
GIVEN: INITIAL VELOCITY OF "18MPH" OR "8.33mm/ms"
IN HYPERCRASH:
GOTO: "Browser" > "Right click" > "Create new" > "Initial Velocity"
INITIAL VELOCITY IS ADDED TO THE CAR MODEL AS SHOWN BELOW WITH GIVEN PARAMETERS:
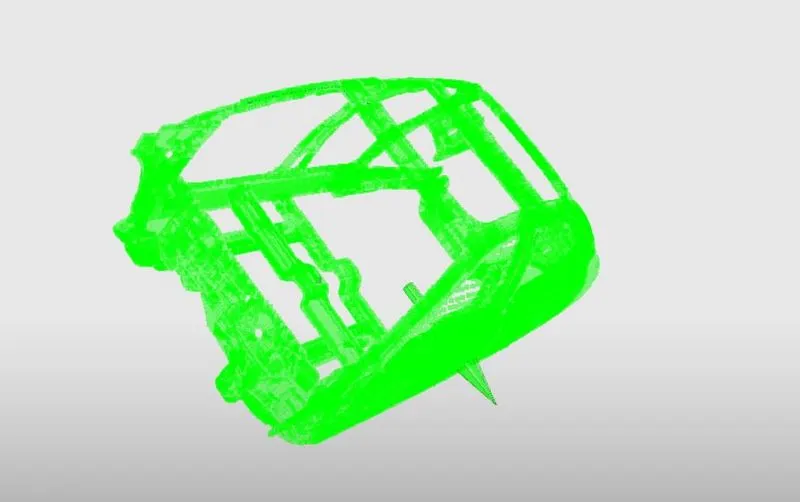
MODEL IMAGE AFTER IMPLYING INTIAL VELOCITY:
8) WE SHOULD USE MODEL CHECKER TO ENSURE GOOD QUALITY:
IN HYPERMESH:
GOTO: "Tools" > "Model Checker" > "RADIOSS BLOCK"
- usually when we do model checking in "HYPERMESH", errors are not detected and recognised properly as we see in "HYPERCRASH".
IN HYPERCRASH:
GOTO: "Quality" > "Model Checker" > "RUN"
AFTER RUNNING MODEL CHECKER, ERRORS ARE DETECTED AS SHOWN BELOW:
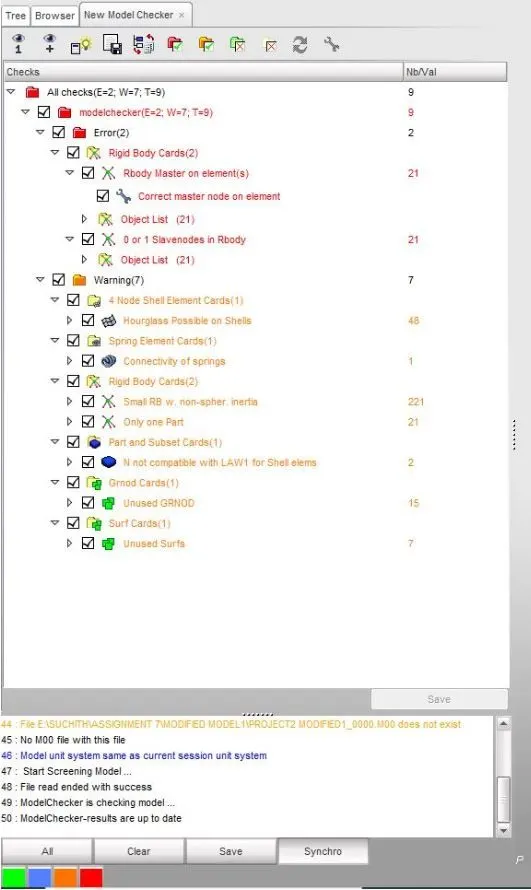
- Here we see "RIGID BODY CARDS" as ERRORS, so this is due to too occurs due to "TOO MUCH OF RIGIDNESS" in the model.
- In "HYPERCRASH", we can convert these ERRORS into WARNING.
- We can do this by "Right clicking on ALL CHECKS at the top" > "And click on RUN ALL AUTOMATIC CONNECTIONS", after doing this , we can see all these ERRORS getting converted to "WARNINGS".
AFTER DOING THE ABOVE STEPS, WE CAN SEE ALL ERRORS GETTING CONVERTED TO WARNINGS AS SHOWN IN THE BELOW IMAGE:
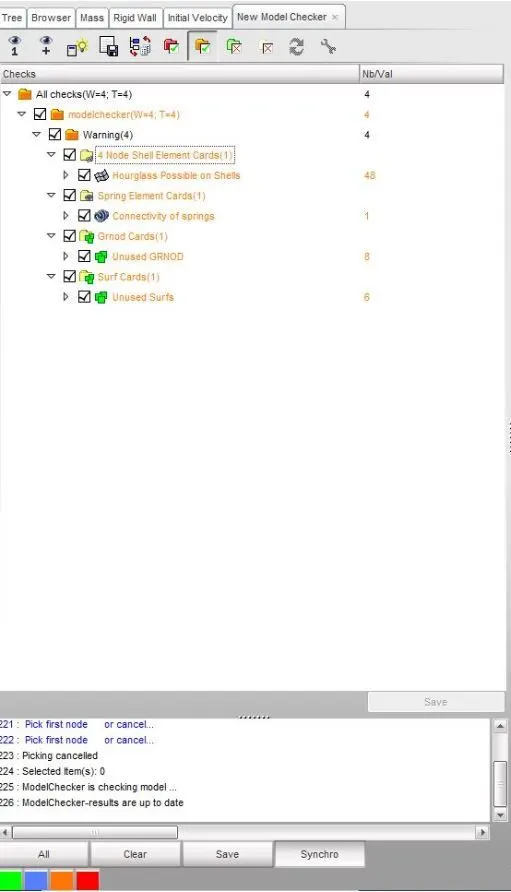
Now it is safe to run the given MODEL without any ERRORS.
9) TIME-STEP TO BE BETWEEN :0.5 to 0.1 microseconds
IN HYPERMESH:
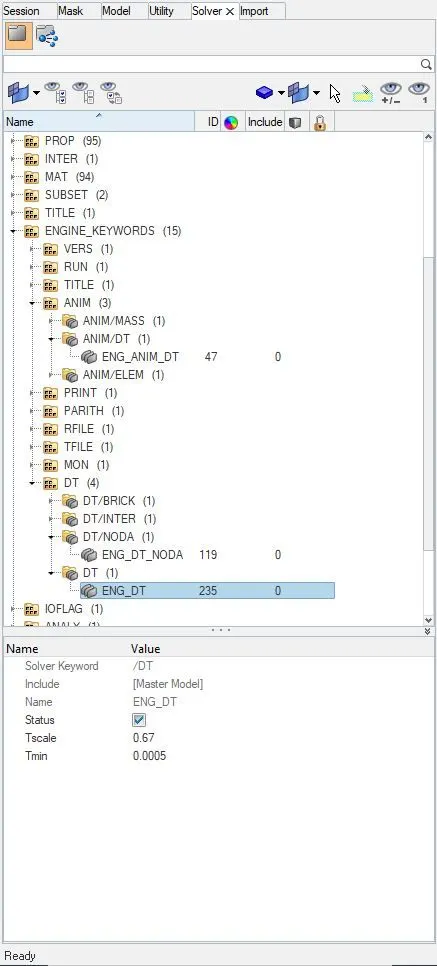
GOTO: "Solver" > "Right click" > "Create" > "ENGINE KEYWORDS" > "DT"
- "Tscale" = 0.67
- "Tmin" = 0.0005ms (Here we have used 0.5 microseconds)
IN HYPERCRASH:
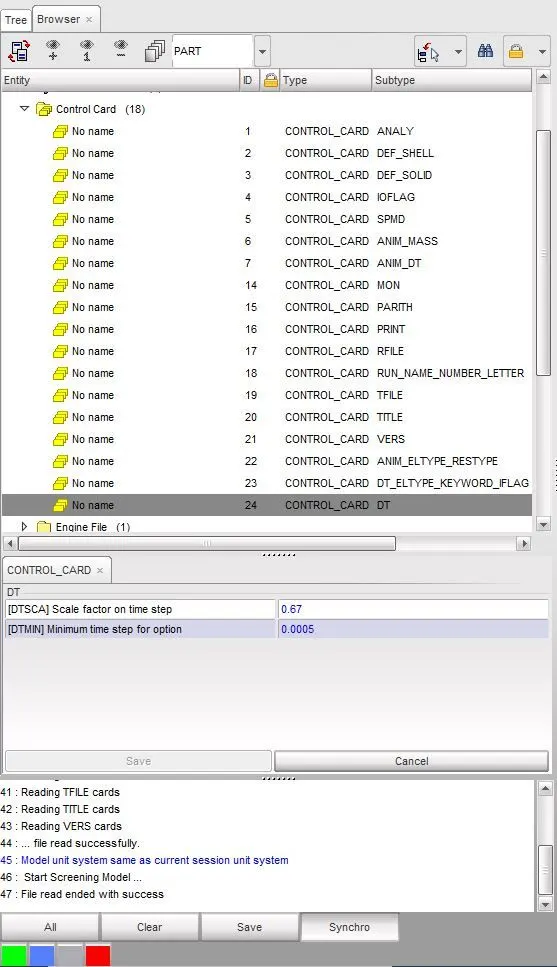
GOTO: "Browser" > "Create new" > "Control cards" > "ENGINE" > "DT"
- "Tscale" = 0.67
- "Tmin" = 0.0005ms (Here we have used 0.5 microseconds)
THE BELOW IMAGE REPRESENTS THE TIME-STEP IN "HYPERMESH":
THE BELOW IMAGE REPRESENTS THE TIME-STEP IN "HYPERCRASH":
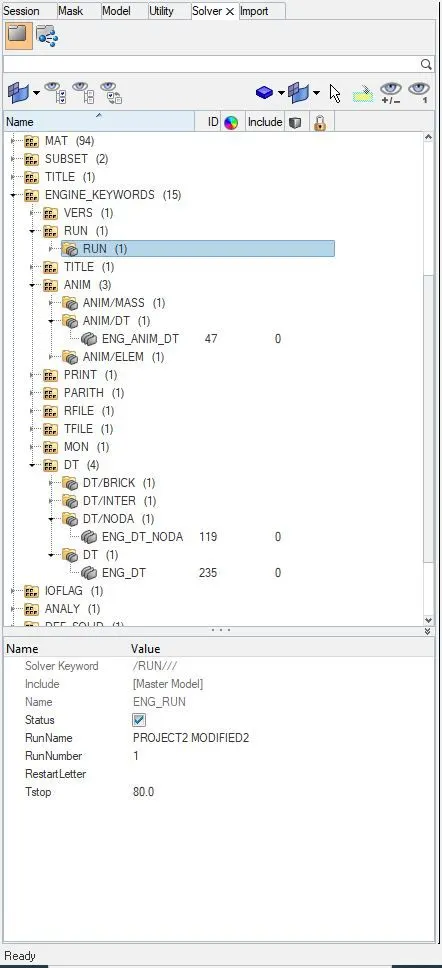
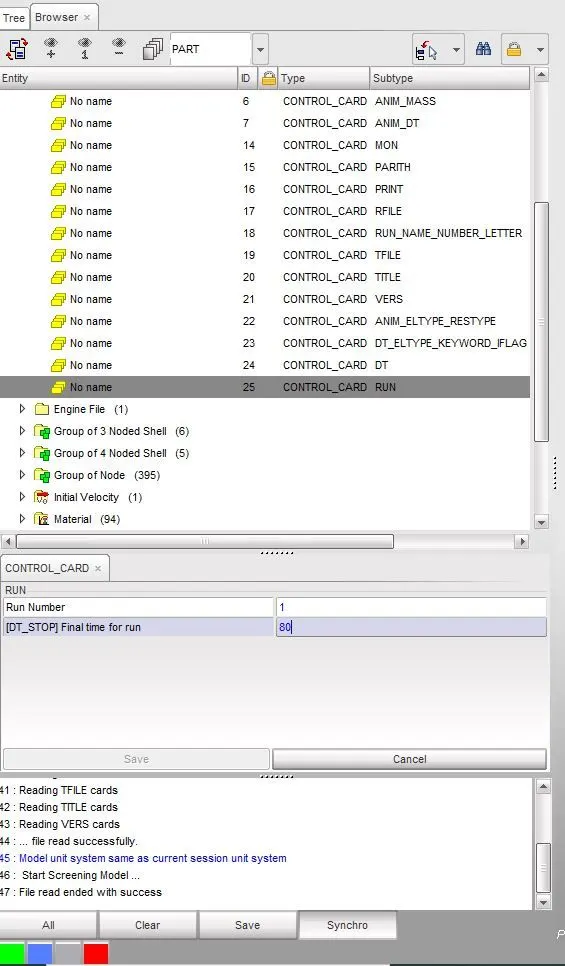
10) RUN TIME SHOULD BE "80 MILLI SECONDS"
IN HYPERMESH:
GOTO: "Model" > "Cards" > "ENG_RUN" > "Tstop = 80"
IN HYPERCRASH:
GOTO: "Browser" > "Right click" > "Create new" > "Control cards" > "ENGINE" > "RUN" > "[DT_STOP] Final time for run = 80"
THE BELOW IMAGE REPRESENTS THE "RUN TIME" IN "HYPERMESH":
THE BELOW IMAGE REPRESENTS THE "RUN TIME" IN "HYPERCRASH":
OUTPUT REQUESTS: ALL DONE IN "HYPERCRASH"
PROCEDURE FOR OBTAINING SECTIONAL FORCE AT A PARTICULAR SECTION USING MOVING FRAMES IS AS EXPLAINED BELOW: "IN HYPERCRASH"
- For Sectional forces we have to create a new "SECTION" at that node.
- To do that, GOTO: "Browser" > "Right click" > "Sections" > "Default section".
- Another method To do that is, GOTO: "Data History" > "Sections" > "Sections" > "Click on the icon which represents Create new object" > "Default section".
- Mode of Creation = "Basic all Fields".
- [Dt] Time step for saving the data = 0.1 milli seconds.
- [alpha] Filtering coefficient = 0.67.
- [Frame_ID] Frame = "Right click" > "Create frame".
- And in [Frame_ID] TYPE = MOV: Moving frame.
- Here we have to select "3 NODES" : N1, N2 AND N3.
- Where N1 and N2 DEFINE: X-AXIS.
- The 3rd node N3 DEFINE: Y-AXIS.
- Note that Z-AXIS should always be in parallel with [FN] FORCE or "OPPOSITE" to the direction of the moving component.
- [Iframe] Skew center : "0: center of the local skew".
- Now we should copy all the "NODE ID" of N1, N2 AND N3 to [node_ID1], [node_ID2] and [node_ID3] for representing [FN] and sections.
- [node_ID1] Node 1 (to define tail of local X-axis of the section).
- [node_ID2] Node 2 (to define head of local X-axis of the section).
- [node_ID3] Node 3 (to define local plane XY of the section).
- In [grshel_ID] Shell group identifier : Select all the "SHELLS" in that particular section where we have created the "MOVING FRAME".
- In [grtrianID] Triangle group identifier : Select all the "TRIAS" in that particular section where we have created the "MOVING FRAME".
- Then click on "SAVE".
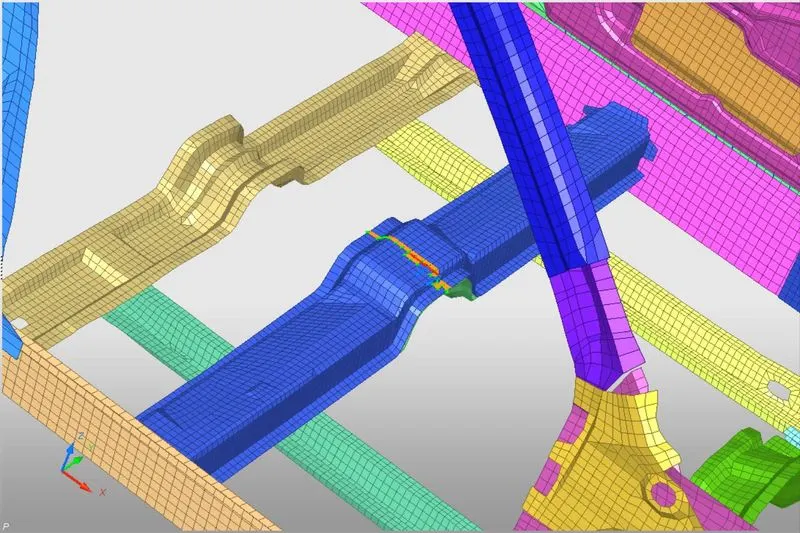
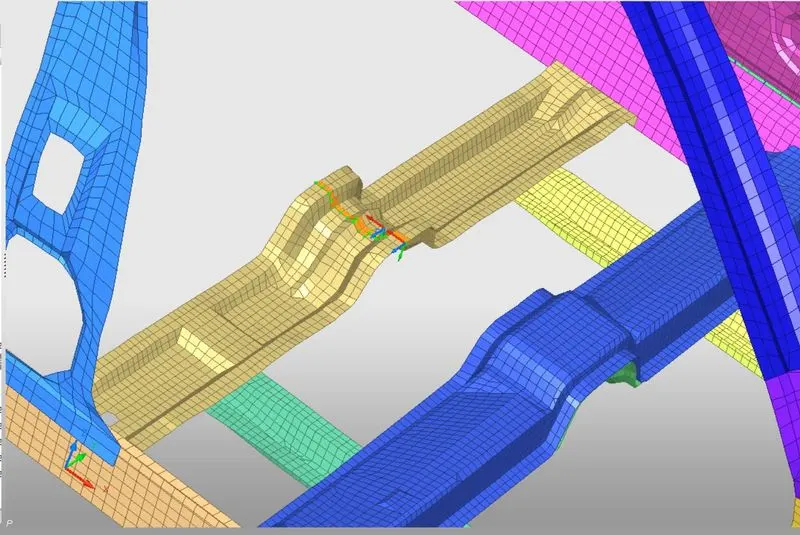
1) WE SHOULD CREATE A SECTIONAL FORCE IN "CROSS MEMBERS":
- Using the above procedure, we'll obtain the "SECTIONAL FORCE" at a particular section using "MOVING FRAMES", as shown below.
A] "FRONT CROSS MEMBER":
THE BELOW IMAGE REPRESENTS THE CREATION OF SECTION FRONT CROSS MEMBER:
B] "REAR/BACK CROSS MEMBER":
THE BELOW IMAGE REPRESENTS THE CREATION OF SECTION REAR/BACK CROSS MEMBER:
PROCEDURE FOR PLACING A NODE AT GIVEN NODE_ID FOR FINDING OUT "INTRUSION" ON DASH WALLS USING MOVING SKEWS IS AS EXPLAINED BELOW:
IN HYPERMESH:
- GOTO: "Solver" > "Right click" > "Create new" > "TH" > "Nodes" .
- GOTO: "Model" > "Output blocks" > "Right click" > "Create new" > "In ENTITY_ID, select NODES, and select the same node as we selected in the model above or select the same NODE_ID" > "Assign a new skew system by creating a new "SKEW" first in the given model, And select that particular SKEW in this SKEW_ID" > "So now we can get that output when we are ploting the graph".
IN HYPERCRASH:
- GOTO: "Data history" > "Time history" > "Right click and create new" > " Click on TH of nodes" > "In [NODid] Nodes*, select a particular node using the given NODE_ID" > "In [Iskew] Skews (associated to nodes), right click and select 'create new' " > "In TYPE*, select MOVING SKEW".
- Here we have to select "3 NODES" : N1, N2 AND N3.
- Where N1 and N2 DEFINE: X-AXIS.
- The 3rd node N3 DEFINE: Y-AXIS.
- Note that Z-AXIS should always be in parallel with [FN] FORCE or "OPPOSITE" to the direction of the moving component.
- [Iframe] Skew center : "0: center of the local skew".
- Now we should copy all the "NODE ID" of N1, N2 AND N3 to [node_ID1], [node_ID2] and [node_ID3] for representing [FN] and sections.
- Then click on "SAVE".
- There is no need to create a seperate output block as we did in HYPERMESH, since we have directly created in "TIME HISTORY", we get this output directly.
2) WE SHOULD CREATE INTRUSIONS ON THE SPECIFIED AREAS MENTIONED IN THE ABOVE QUESTION:
- Using the above procedure, we'll obtain the "DISPLACEMENT" of a particular "NODE" with respect to skew after the crash.
A] "INTRUSION AT "B-PILLAR":
THE BELOW IMAGE REPRESENTS THE PLACING OF NODE FOR INTRUSION IN B-PILLAR:
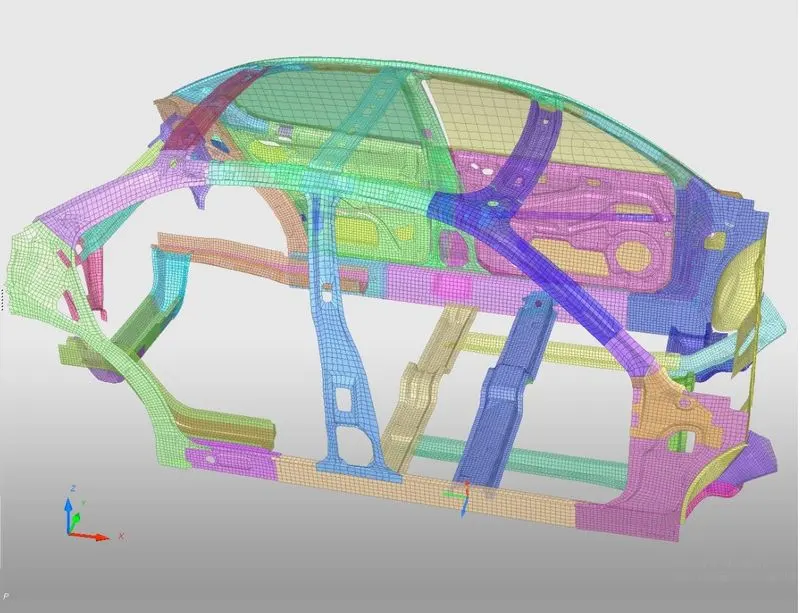
B] "INTRUSION AT "HINGE PILLAR":
THE BELOW IMAGE REPRESENTS THE PLACING OF NODE FOR INTRUSION IN HINGE PILLAR:
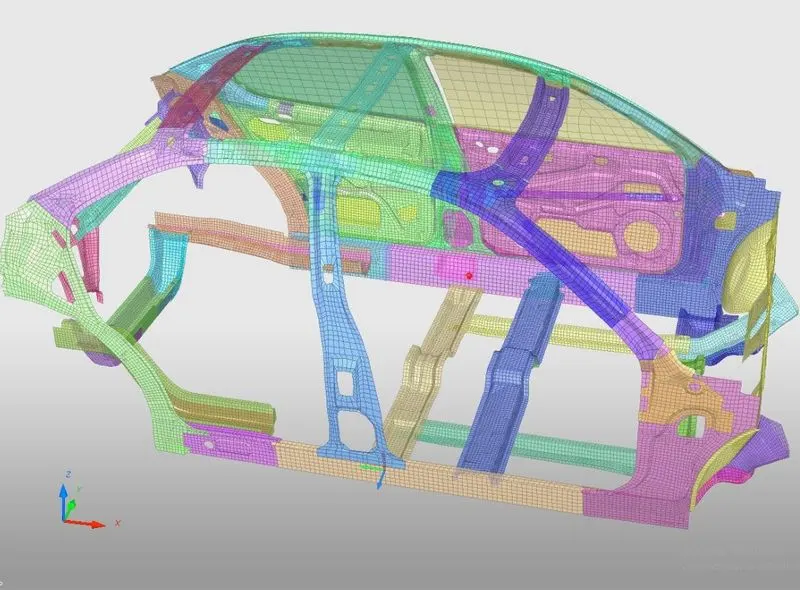
C] "INTRUSION AT "FUEL TANK":
THE BELOW IMAGE REPRESENTS THE PLACING OF NODE FOR INTRUSION IN FUEL TANK:
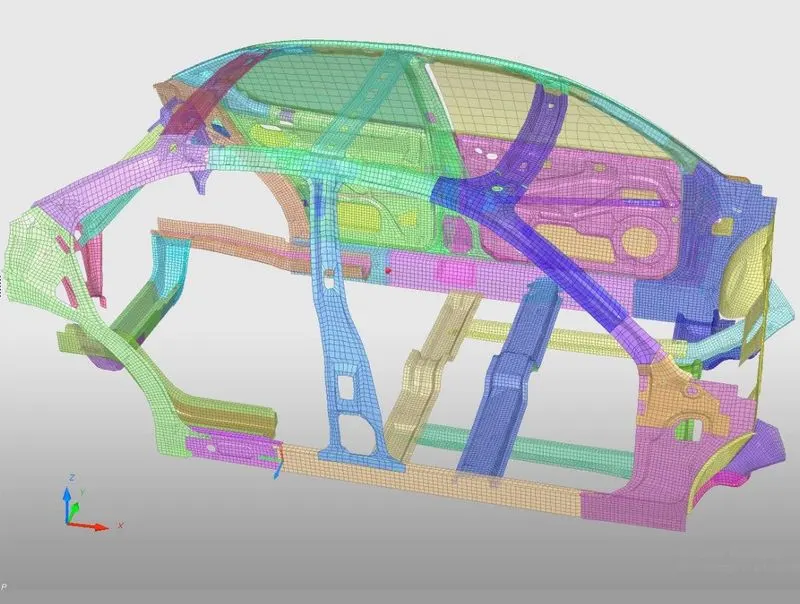
PROCEDURE TO FIND THE PEAK VELOCITY OF THE INNER NODE OF DOOR:
IN HYPERMESH:
- GOTO: "Solver" > "Right click" > "Create new" > "TH" > "Nodes" .
- GOTO: "Model" > "Output blocks" > "Right click" > "Create new" > "In ENTITY_ID, select NODES, and select the same node as we selected in the model above or select the same NODE_ID" > "Here no need to assign the SKEW" > "we need to assign the variable in VY: Y TRANSLATIONAL VELOCITY", This is done by assigning in NUM_VARIABLES as 1 and then select "VY: Y TRANSLATIONAL VELOCITY" in NODE.
IN HYPERCRASH:
- GOTO: "Data history" > "Time history" > "Right click and create new" > " Click on TH of nodes" > "In [NODid] Nodes*, select a particular node using the given NODE_ID" > "GOTO: VARIABLES, click on default, we see "[var1] Variables*", in this we have to select "VY: Y TRANSLATIONAL VELOCITY.
- Here we have to select "3 NODES" : N1, N2 AND N3.
- Where N1 and N2 DEFINE: X-AXIS.
- The 3rd node N3 DEFINE: Y-AXIS.
- Note that Z-AXIS should always be in parallel with [FN] FORCE or "OPPOSITE" to the direction of the moving component.
- [Iframe] Skew center : "0: center of the local skew".
- Now we should copy all the "NODE ID" of N1, N2 AND N3 to [node_ID1], [node_ID2] and [node_ID3] for representing [FN] and sections.
- Then click on "SAVE".
- There is no need to create a seperate output block as we did in HYPERMESH, since we have directly created in "TIME HISTORY", we get this output directly.
3) WE SHOULD FIND PEAK VELOCITY ON THE SPECIFIED AREA, THAT IS ON THE INNER NODE OF THE DOOR MENTIONED IN THE ABOVE QUESTION:
- Using the above procedure, we'll obtain the "PEAK VELOCITY" of a particular "NODE".
PEAK VELOCITY PARAMETERS:
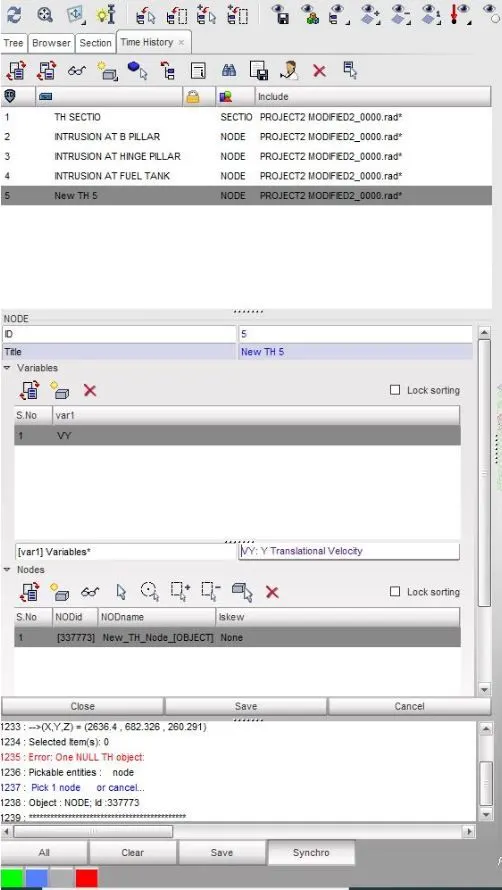
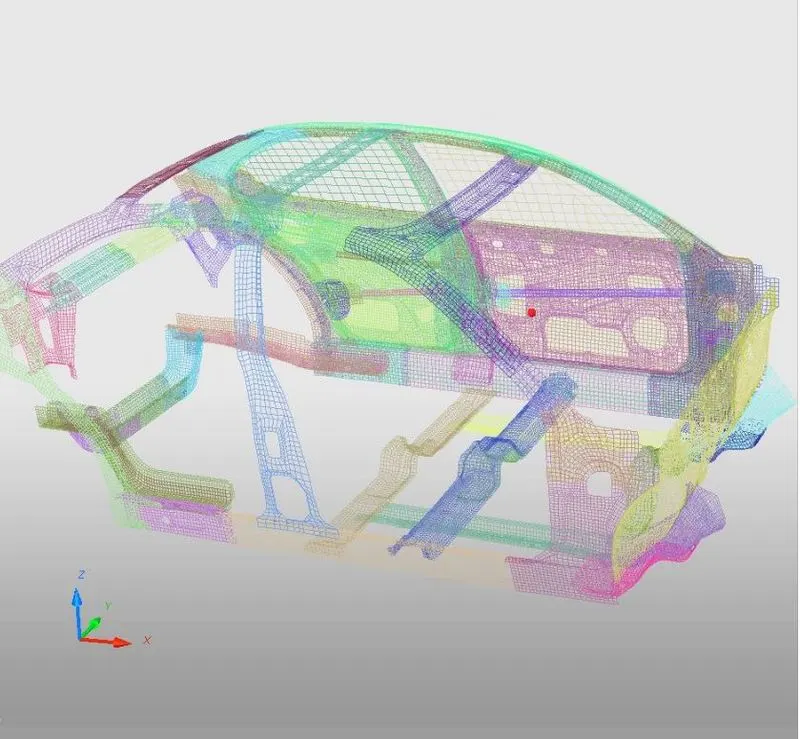
THE BELOW IMAGE REPRESENTS THE PLACING OF NODE ON THE INNER DOOR FOR PEAK VELOCITY:
NOW WE SHOULD RUN THE SIMULATION :
TO DO THAT
- First import the model from "HYPERCRASH"
- GOTO: "Analysis" > "Radioss" > "Save the RESULTS by directing it from SAVE AS" > "IN option type = -nt 4" > "NOW HIT RADIOSS"
RESULTS, GRAPHS AND CONCLUSIONS:
SHOWN BELOW IS THE GIF SIMULATION OF THE FRONTAL CRASH OF THE CAR:
IMAGE:1 :SHOWN BELOW IS THE GIF SIMULATION OF THE SIDE CRASH OF THE CAR:
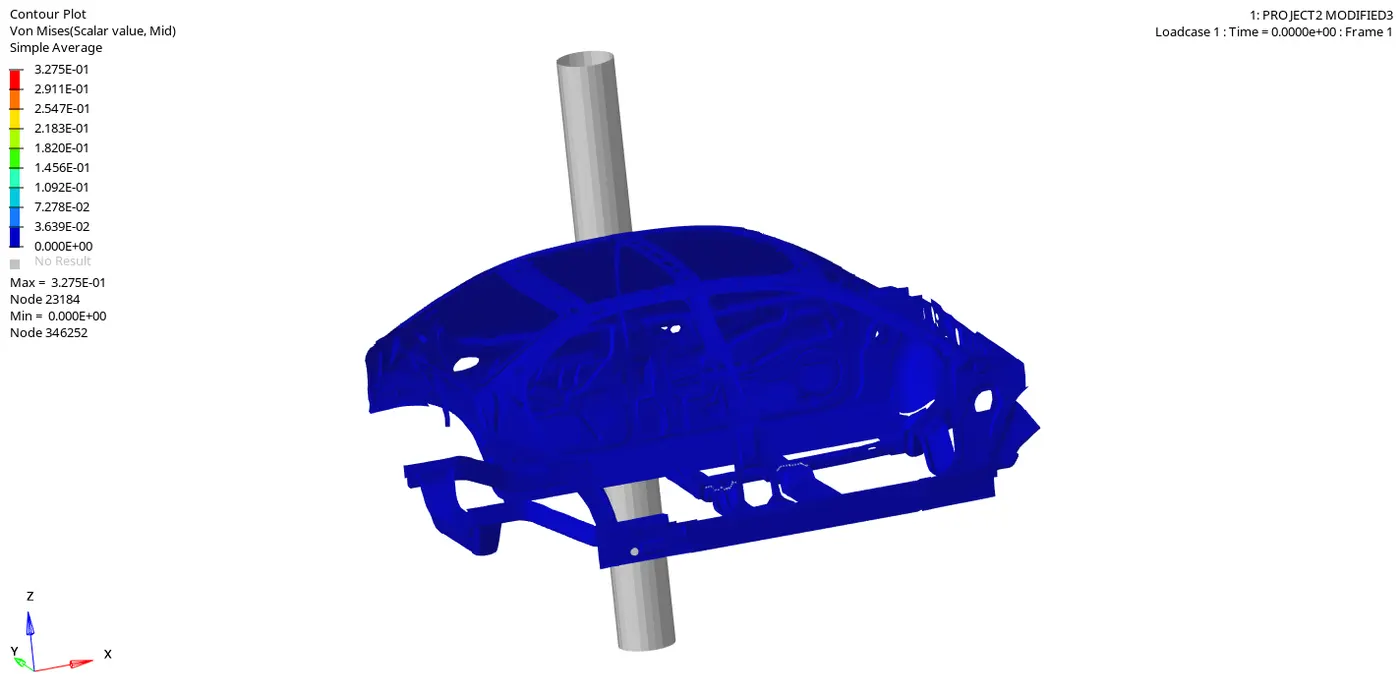
IMAGE:2 :SHOWN BELOW IS THE GIF SIMULATION OF THE SIDE CRASH OF THE CAR:
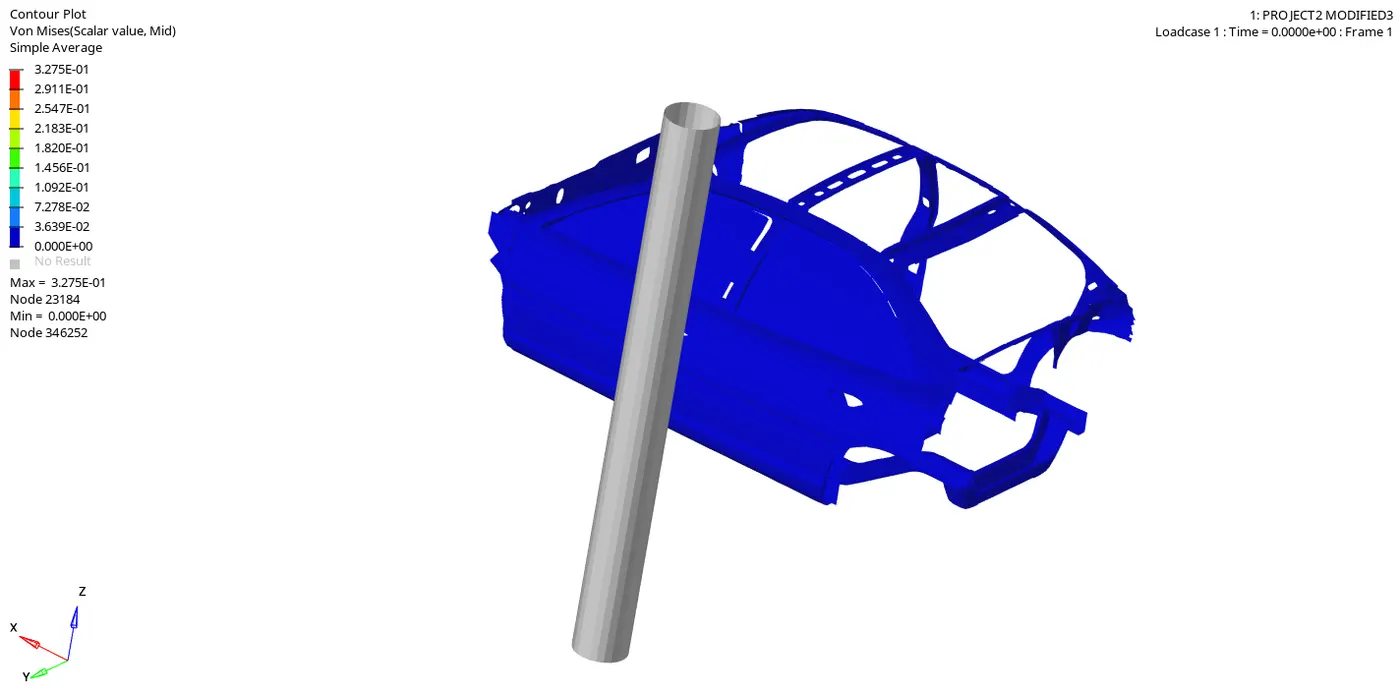
OUTPUT OF SIMULATION:
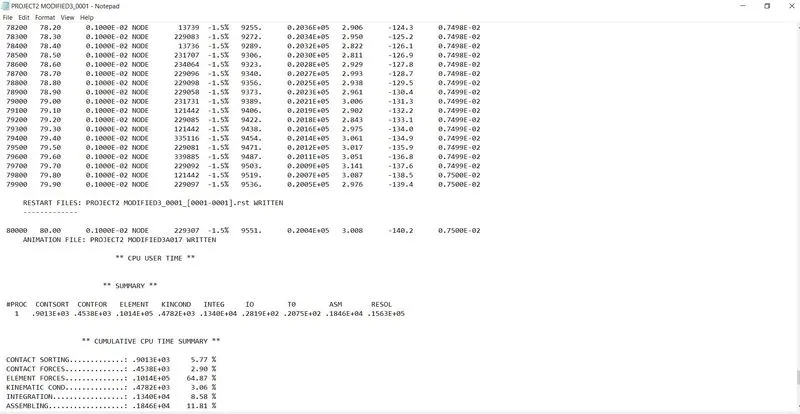
OUTPUT GRAPHS:
1) CROSS-SECTIONAL FORCES IN "CROSS MEMBER":
A] CROSS-SECTIONAL FORCES IN "FRONT CROSS MEMBER":
THE BELOW IMAGE REPRESENTS "RESULTANT FORCE" THROUGH THAT PARTICULAR SECTION IS AS SHOWN BELOW:
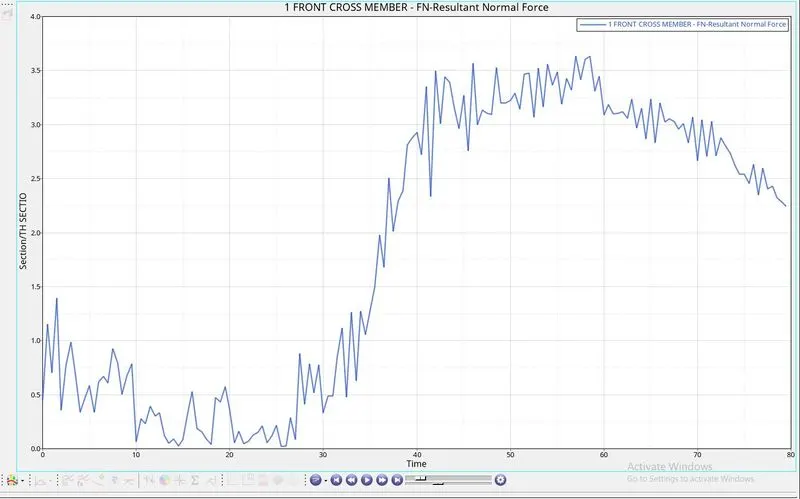
From the above graph the "FRONT CROSS MEMBER" at an indicated node receives a maximum Resultant force of 3.25KN through that particular section.
B] CROSS-SECTIONAL FORCES IN "REAR/BACK CROSS MEMBER":
THE BELOW IMAGE REPRESENTS "RESULTANT FORCE" THROUGH THAT PARTICULAR SECTION IS AS SHOWN BELOW:
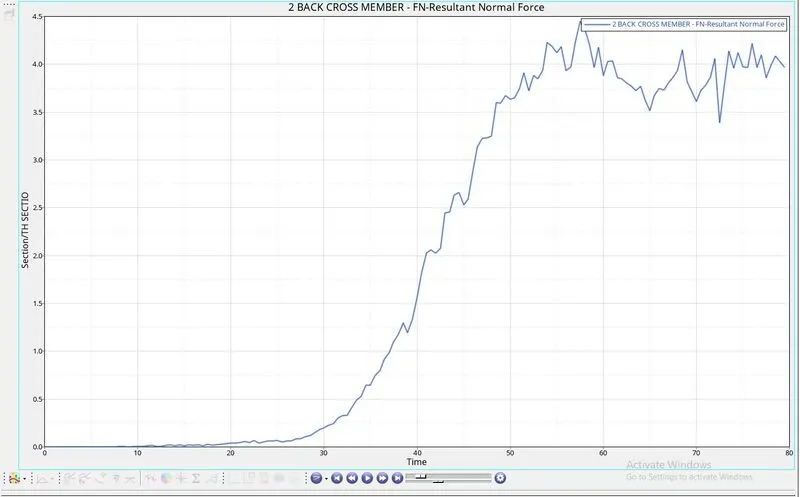
From the above graph the "REAR/BACK CROSS MEMBER" at an indicated node receives a maximum Resultant force of 4.45KN through that particular section.
2) INTRUSION FOR THE GIVEN NODES:
A] THE BELOW IMAGE REPRESENTS THE DISPLACEMENT/INTRUSION OF THE NODE NEAR THE "B-PILLAR" THROUGH LOCAL "Z-AXIS" WHICH IS DEFINED BY A "MOVING SKEW" ON THE B-PILLAR ROCKER WHICH IS ON THE OPPOSITE SIDE OF THE NODE DUE TO THE SIDE CRASH IS AS SHOWN BELOW:
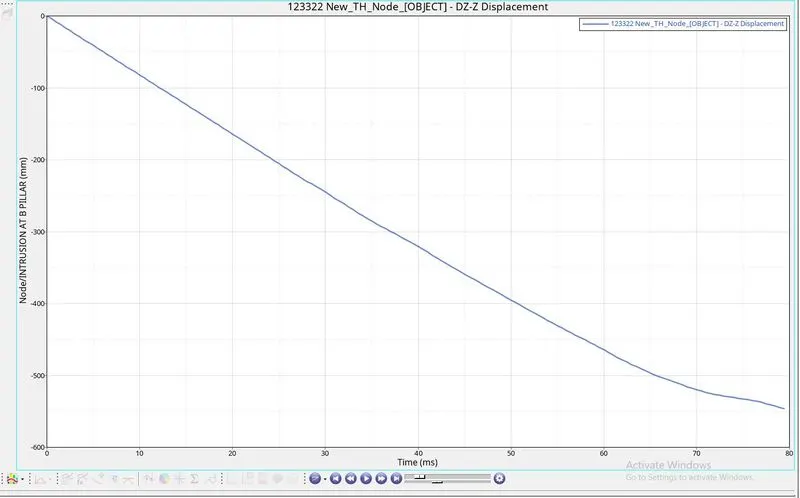
From the above graph we can say that the NODE has been displaced to 550mm in distance.
B] THE BELOW IMAGE REPRESENTS THE DISPLACEMENT/INTRUSION OF THE NODE NEAR THE "HINGE PILLAR" THROUGH LOCAL "Z-AXIS" WHICH IS DEFINED BY A "MOVING SKEW" ON THE B-PILLAR ROCKER WHICH IS ON THE OPPOSITE SIDE OF THE NODE DUE TO THE SIDE CRASH IS AS SHOWN BELOW:
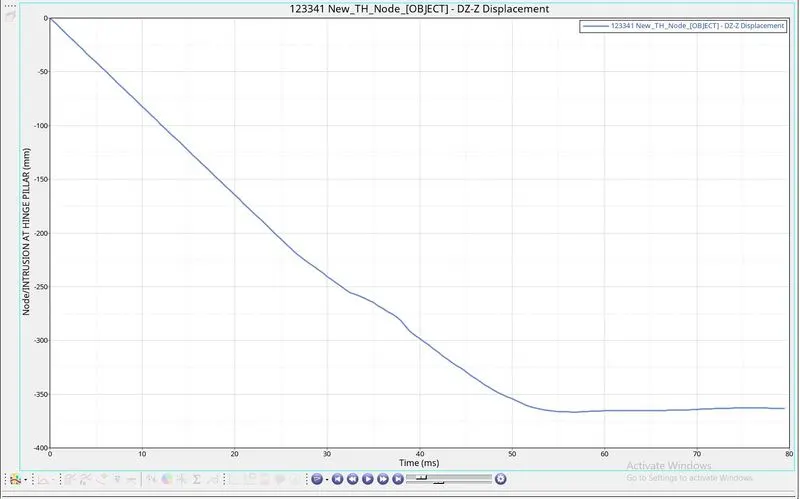
From the above graph we can say that the NODE has been displaced to 360mm in distance.
C] THE BELOW IMAGE REPRESENTS THE DISPLACEMENT/INTRUSION OF THE NODE NEAR THE "FUEL TANK" THROUGH LOCAL "Z-AXIS" WHICH IS DEFINED BY A "MOVING SKEW" ON THE B-PILLAR ROCKER WHICH IS ON THE OPPOSITE SIDE OF THE NODE DUE TO THE SIDE CRASH IS AS SHOWN BELOW:
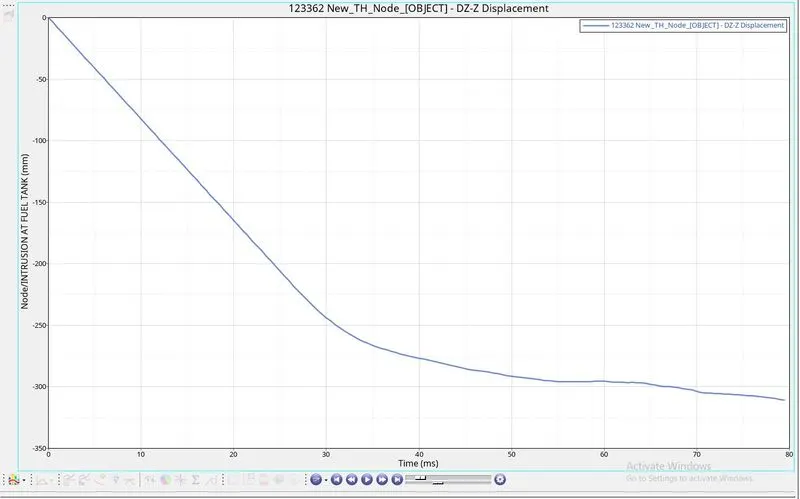
From the above graph we can say that the NODE has been displaced to 325mm in distance.
3) PEAK VELOCITY AT INNER NODE OF THE DOOR:
THE BELOW IMAGE REPRESENTS THE "PEAK VELOCITY" OF THE NODE THROUGH "VY : Y TRANSLATIONAL VELOCITY" IN "GLOBAL-Y" DIRECTION WHICH WE HAVE PLACED ON THE INNER SIDE OF THE NODE AS SHOWN IN THE ABOVE PEAK VELOCITY IMAGE:
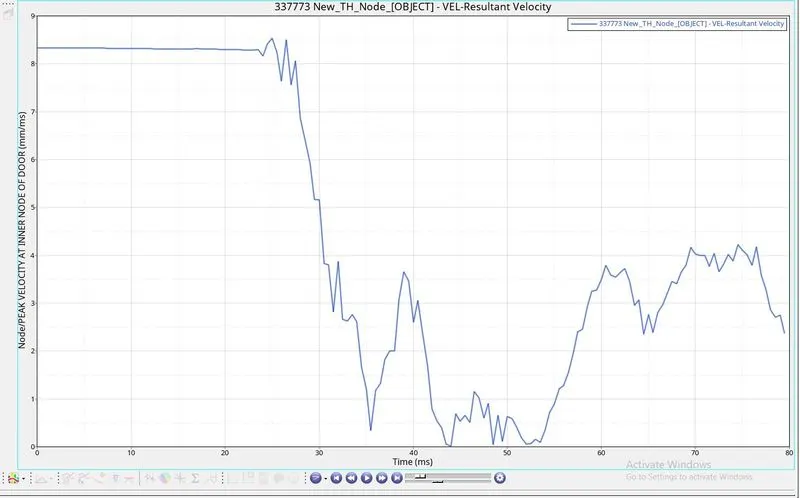
Here we can see that there there is a constant velocity of 8.33mm/ms for 24 seconds, after that the side of the car is getting CRASHED to a POLE, and the velocity of that node decreases and varies as shown in the above graph.
4) ENERGY PLOTS:
THIS INCLUDES:
- INTERNAL ENERGY
- KINETIC ENERGY
- HOURGLASS ENERGY
- CONTACT ENERGY
- TOTAL RESULTANT ENERGY
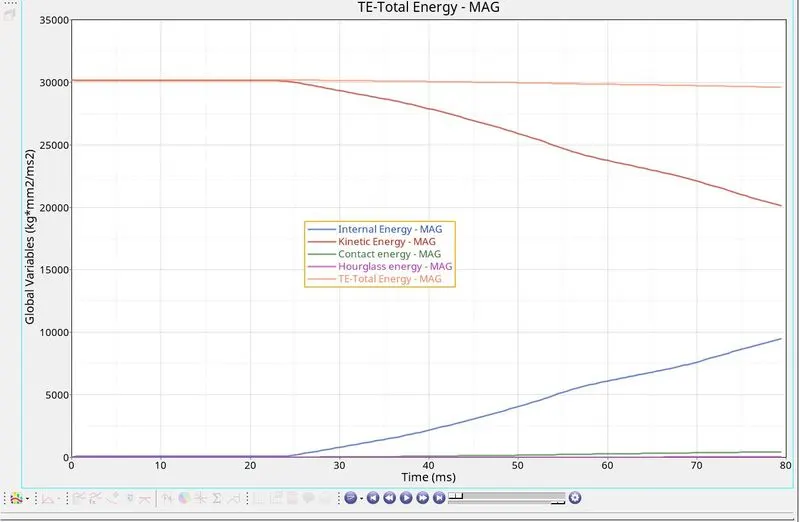
INTERNAL ENERGY:
- In the above graph "INTERNAL ENERGY" is constant and is "0" for "24 seconds", this is because the car is still moving towards the "RIGID POLE" and has not yet crushed, so there will be no "ENERGY ABSORPTION" untill and unless the car is being CRASHED to the RIGID POLE.
- We can see that "INTERNAL ENERGY" increases as the car is getting crushed, which means the car is absorbing the energy induced by the molecular movements in the component, this is because of crushing of the elements in the components.
KINETIC ENERGY:
- Initially the "KINETIC ENERGY" is "HIGH" and "CONSTANT" for "24 seconds", that is because the car is moving without facing any obsticle or it has not reached the "RIGID WALL" yet, as soon as the car hits the RIGID WALL, the "KINETIC ENERGY" of the car keeps on decreasing, but from the above graph we can see that the "KINETIC ENERGY" is still high at the end of cycle, this tells that the car still did'nt come to rest.
HOURGLASS ENERGY:
- Since we are using "QEPH" as our shell element, which is also a "IMPROVED UNDER INTEGRATED ELEMENT" which has "PHYSICAL HOURGLASS STABILIZATION", so from the above graph we can say that "HOURGLASS ENERGY" experienced by the car is very less.
CONTACT ENERGY:
- Since we have defined the contact interfaces between the car and the impactor by "TYPE-7" with "FRICTION" = 0.2, from the above graph we can see that there is a slight "CONTACT ENERGY" experienced at "CONTACT" between the two.
TOTAL RESULTANT ENERGY:
- From the above graph we can see that "TOTAL RESULTANT ENERGY" is decreasing very slightly, this is due to the slight increase in the "CONTACT ENERGY". so, "TOTAL RESULTANT ENERGY" depends on "CONTACT ENERGY", Since it is the SUM of all the energies that are listed above the graph.
CONCLUSION:
Hence the "SIDE CRASH" simulation is done for the given model by using the given appropriate parameters and the respective results are analysed and plotted.