Assignment 6-Frontal Crash Simulation Challenge
Frontal Crash test
AIM:
Frontal car crash simulation of Dodge Neon BIW using RADIOSS solver and Preprocessing using HyperMesh / HyperCrash.
OBJECTIVE:
SETUP REQUESTS:
- Check the unit system and either follow [Mg mm s] or [Kg mm ms].
- Create an appropriate interface, friction 0.2, and recommended parameters.
- Make sure of no penetrations and intersections.
- Correct rigid bodies if any issues.
- Create a rigid wall with friction 0.1.
- Compare the model weight with the full-scale 300k nodes model and use added masses to reach the target weight of 700kg while getting CG about the required range.
- Initial velocity 35 mph.
- Use a model checker to ensure good quality.
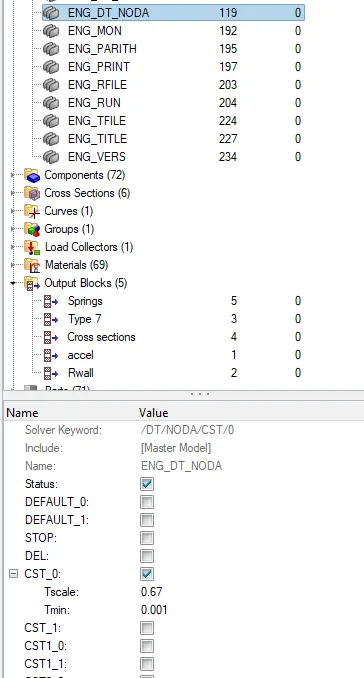
- Time-step: 0.5 to 0.1 microseconds.
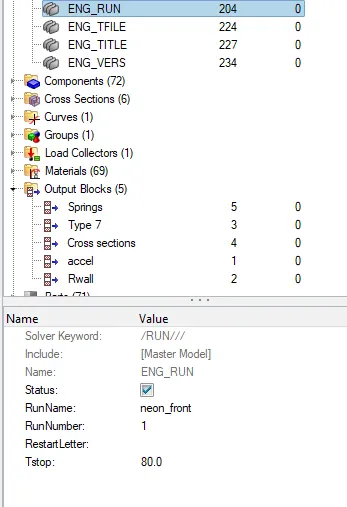
- Run 80 ms
OUTPUT REQUESTS:
- Sectional force in the rails at the location of indicated node 174247.
- The axial force received on the rails from the bumper.
- Shotgun cross-sectional forces.
- A pillar cross-section.
- Acceleration curve received on the accelerometer at base of B pillar (on B pillar rocker).
- Intrusions on the dash wall 66695, 66244.
PROCEDURE:
We will be using Hypercrash and Hypermesh to set up the model. Some checks will be done in Hypercrash and some in Hypermesh. First, we will import the model into Hypercrash and check for Penetration and make sure the units are in Kg mm ms.
The unit check can be done without opening the model. We can just open the Neon_front_0000.rad in a notepad where we will be able to check the units.
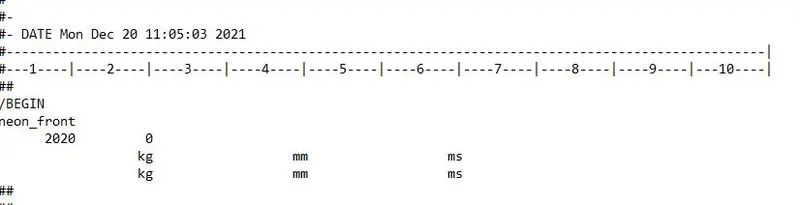
We can see that the Units are in Kg mm ms. Now we will open Hypercrash and perform a penetration check and also will be adding mass to the body.
To open hyper crash we have to first open hyper mesh.
Now go to Application >> hyper crash>> Select the unit system >> open
Once Hypercrash is opened we will be checking for Penetration and Intersection.
Penetration is defined as the overlap of the material thickness of shell elements, while Intersection is defined as elements that actually pass completely through one another.
All models and especially impact models should be checked for penetrations and intersections to make sure there is no penetration and intersection. Penetrations adversely affect results and should be removed.
To check penetration and intersection
Got to Quality>> Check Intersection on tree >> Select parts > Click on check penetration
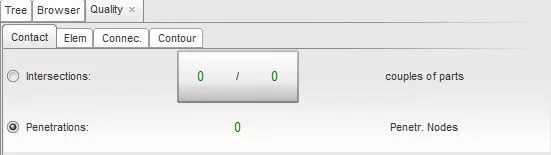
We can clearly see from the above figure there are no penetrations and intersections are present in the model.
COG and Additional Mass:
In the next step, we will be adding masses to the setup. Since this is a reduced model the vehicle's weight and COG are not at the required point. So we will be adding some masses keeping the full model as a reference and will be bringing the COG at the required point.
The reduced model's weight while importing was 188kg so we will be adding massed to bring it up to 700kg in the appropriate places so that the COG is at the center of the model betweent the seats
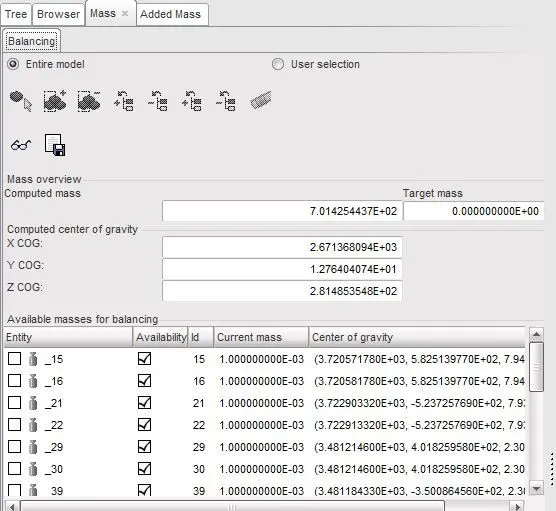
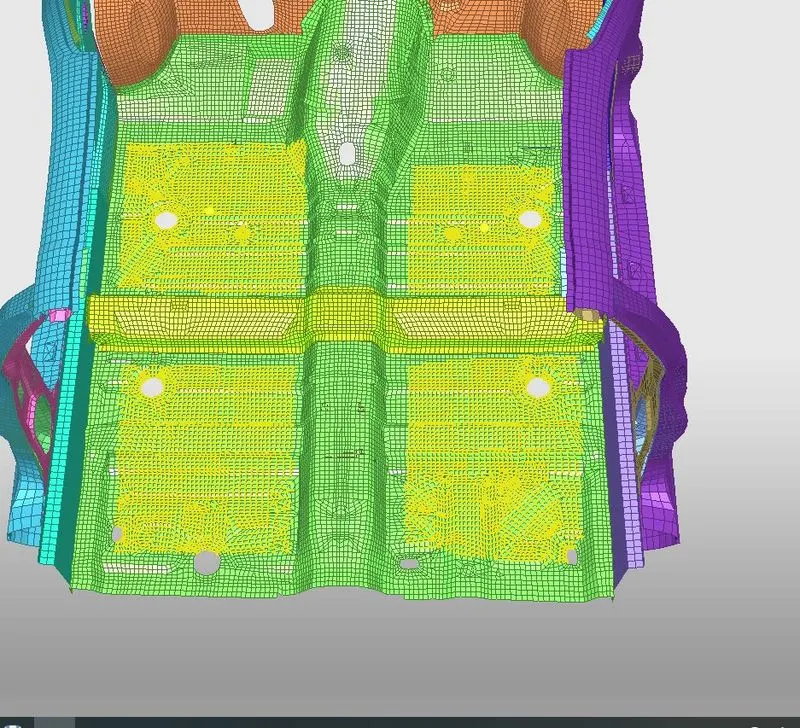
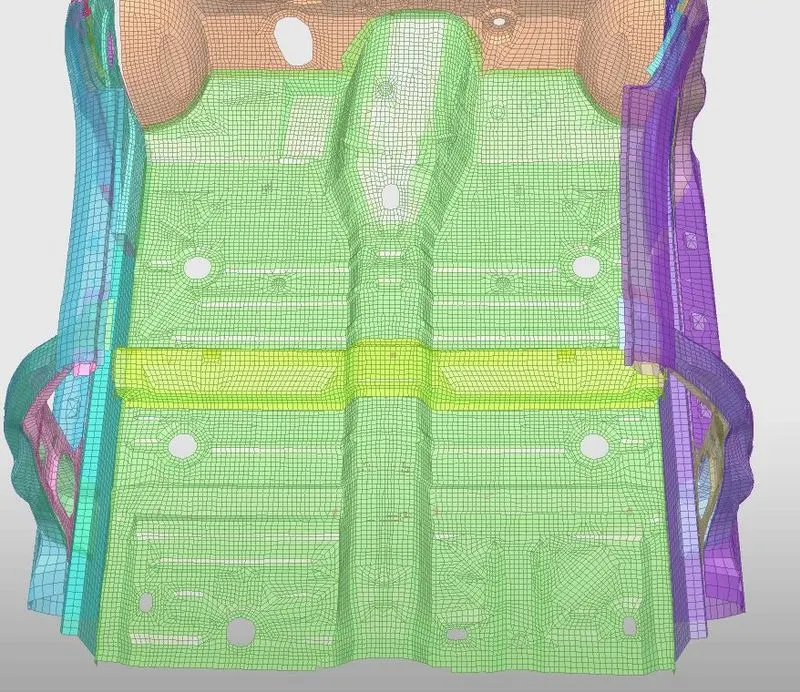
From the below image you can see the Weight and the position of the COG in the reduced Model.
Once the Additional masses are added we can see that the total weight is 700kg and the correct position of the COG.
Export the changes made in the Hypercrash and import the same file in Hypermesh to make other changes.
Go to File >> Export >> RADIOSS
Now import the same file in hyper mesh to do other changes. So open the imported .rad file and we can start with providing the connections.
Type 7 contact
Type-7 Node to surface contact is used in this model. Both the Slave nodes and the Master nodes will be the same for this simulation since there is self-intersection between the parts while it simulates.The recommended properties are as follows
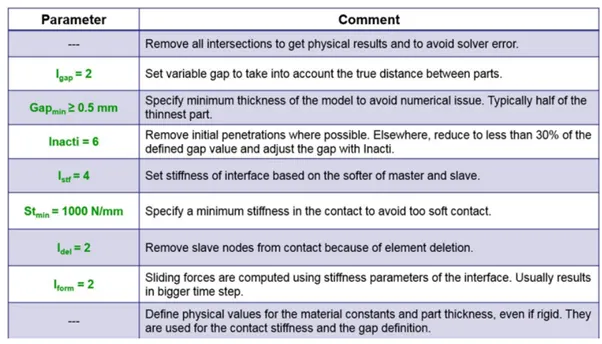
Delete the other contact groups.
RIGID WALL:
A rigid wall is a nodal constraint applied to a set of slave nodes in order to avoid the node penetration to the wall. If contact is detected, then the slave node acceleration and velocity are modified. Mainly to constrain the movement of a moving body after impact, we will be using a plane wall. An infinite plane wall is a plane that extends to infinity. It is defined with two points.
Rigid wall entities provide a method for treating a contact between a rigid surface and nodal points of a deformable body. In the Radioss user profiles, rigid walls can be created in the Model and Solver browsers.
To create an RWALL
Go to Solver browser >> Create >> Rwall >> Plane
We need a reference node to create an RWALL so we can select a node at the center of the bumper.
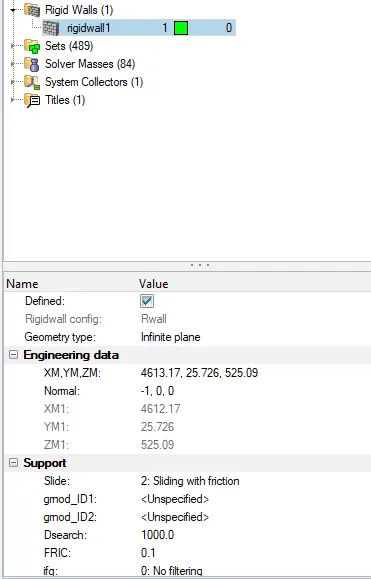
Based on the reference node we can just adjust the wall in such a way that it is not in contact with the car and there is a small gap between the wall and the vehicle.
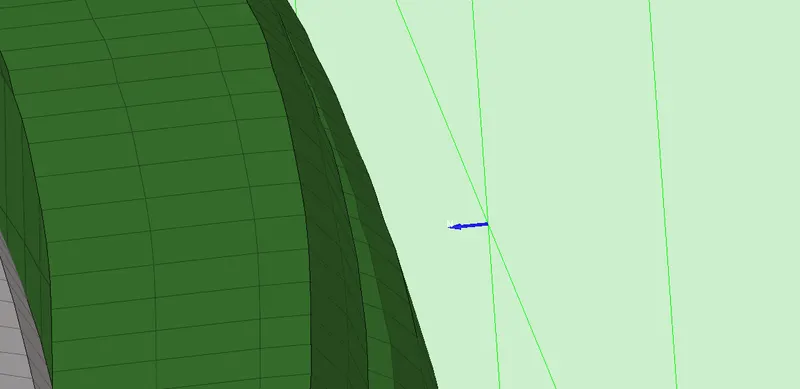
Make sure the Normal of the Rigidwall is facing the Vehicle as shown in the above image. We will be providing the contact interface as Sliding with friction with a frictional coefficient of 0.1.
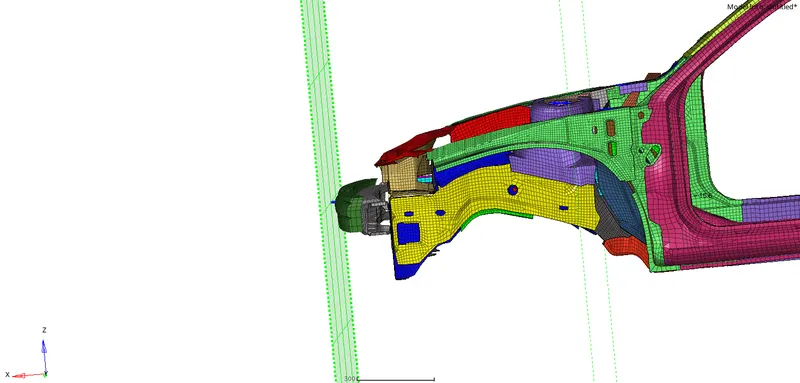
The D-search distance we can use around the range of 1200 mm. All the Nodes within this distance will be considered as salve nodes for the contact between the car and the Rigid Wall.
INPUT VELOCITY:
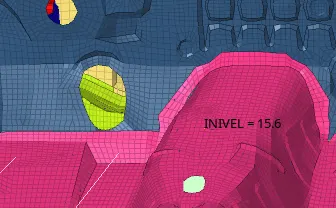
The velocity input for this simulation as per the Standards is 35mph so when we convert it to m/s the input velocity is 15.6464m/s.
To create initial velocity
Go to solver browser >> Create >> boundary conditions (BC) >> Inivel
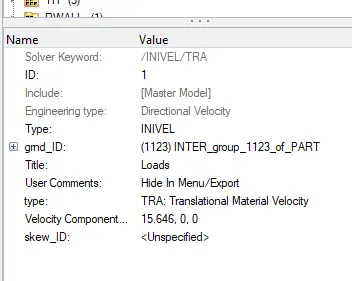
Define the Node group on which specified initial velocities are applied (grnd_ID1). For our simulation, we will be selecting the whole vehicle setup.
The velocity type is selected as Translation velocity and it is provided in the x-direction .
CREATE SECTIONAL FORCES:
We need to Create Sections at A-Pillar, Shot Gun, rails and the Bumper in order to Study the sectional forces
We should know how the forces are transmitted from the Bumper to the Dashboard and the rate of deformation. It is done in order to ensure the safety of the passenger.
Certain components will crash (deform) more than the other so that the forces are distributed correctly leaving very little force left to transmit inside the cabin.
To create a section and Frame Go to Slover browser >> Create >> Section >> SECT
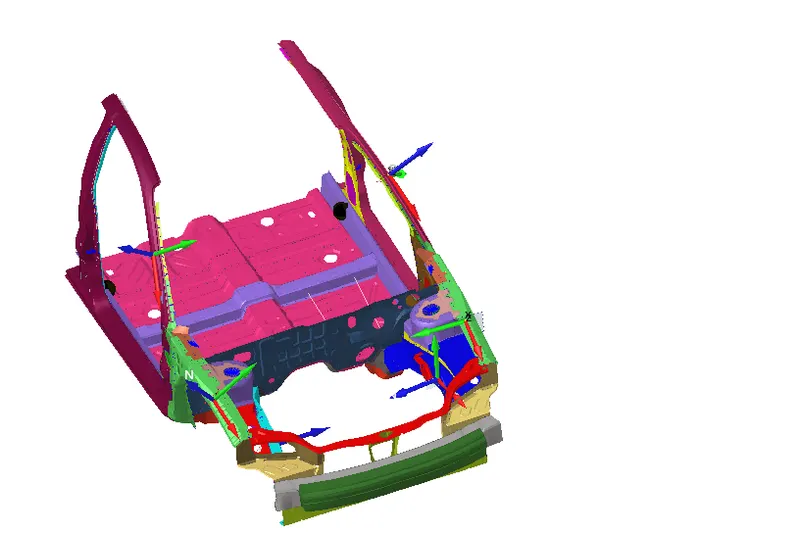
FRAME CREATION:
Before creating sections, we should create frames. The Frame is created to make local coordinates of the section.To create the Frame, Right Click on the Tab Area in the Solver Browser >> Click Create >> FRAME >> MOV >> Select the Nodes So Create an Axis >> Create.Remember, while creating local coordinates, select the nodes in such a way that the Z- Axis should be in the direction of the initial velocity applied
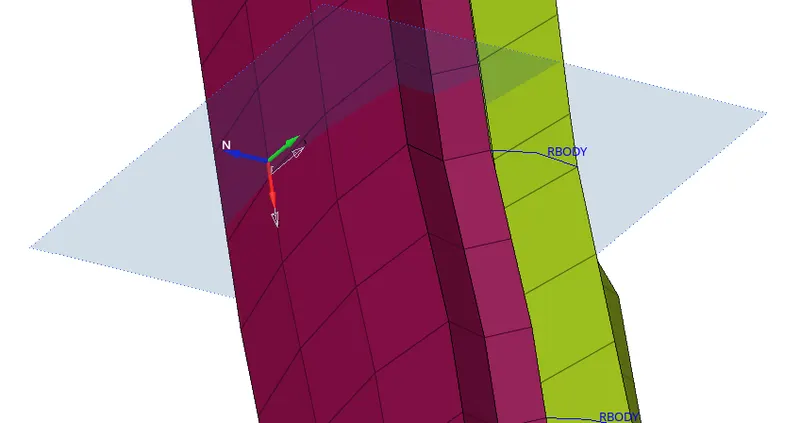 .
Now create sections and assign each FRAME to each Section accordingly , grshel_id select a section of elements on a component where we should calculate forces going through them.
Remember, the plane created at the section must be perpendicular to that component
CREATE ACCELERATION NODES:
Creating Accelerometer at both sides of the B pillar.
An accelerometer is a basic technology that converts mechanical motion into an electrical signal. It is an electromechanical device that measures acceleration forces, whether caused by gravity or motion.
To create accelerometer Go to Model browser >> Create >> Accelerometer >> Select Node_ID >> Select node >> Proceed
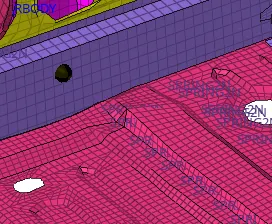
This is done to get the Acceleration output of the Crash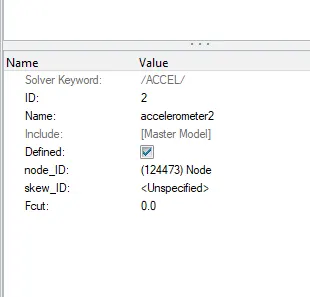
Make sure to create a Time History file for these Accelerometers Individually so that we can view the intrusions.
CREATING SPRINGS:
We are planting spring elements to study the intrusions , Create 2 parallel spring elements from the indicated nodes (66695, 66244) till the Crossbeam.
Springs can be created from the 1D Panel > Springs
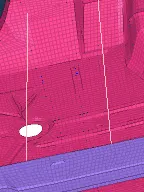
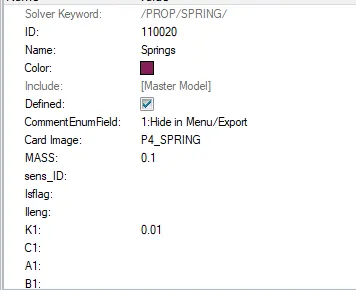
We have to provide the springs with their respective properties.
Go to model Browser >> Create >> Property >> Rename as Springs
After creating a property, a new tab will open there we have to select CARD image as P4 SPRING and Mass as 0.001, and Stiffness as 0.001 and assign all these properties to the spring.
Make sure to create a Time History file for these Springs Individually so that we can view the intrusions.
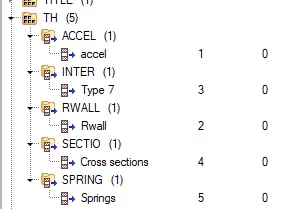
Delete existing TH and Create New Cards
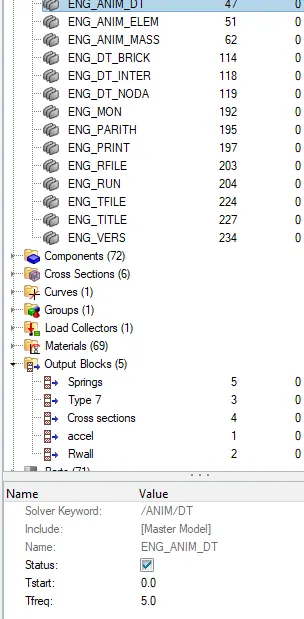
Delete all the unnecessary TH files and create the Time History files for the boundary conditions that we have created for the frontal crash model.
This will help us reduce some time for simulation as the solver only calculates TH for required outputs
Edit Cards:
Before running the simulation check all these cards and assign the values accordingly
CHECKS:
These checks can be done via both Hypermesh and Hypercrash but it is recommended to check via the Hypercrash module. Before exporting the model we will be checking for Unused and Empty, make sure all the parts are connected, or once the simulation is done the results will be wrong with parts flying.
Tools>>Unused and Tools>>Empty and delete the unwanted data in the model and export them.
The Model checker will give us any warnings and Errors regarding the model definition and, the boundary and Kinematic conditions, etc.
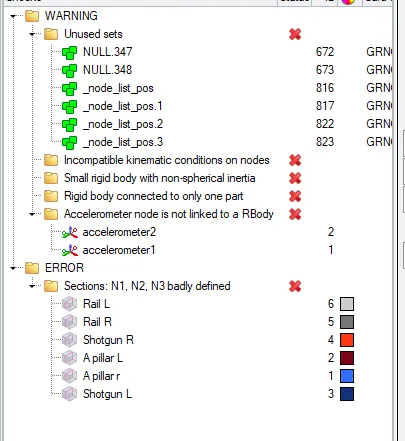
- Boundary Condition is not defined properly
- Incompatible Kinematic Condition
- The Part Property or material is not defined properly, etc.
- We can avoid the Warnings as the solver will automatically autofix
But we must fix every Error in order to get a successful simulation free of problems
RUN THE ANALYSIS:
Analysis >> Radioss >>save file >> select Radioss
The input file is the same Started file that we had just imported.
The h3d file and T01 file will be saved in the same folder.
RESULTS:
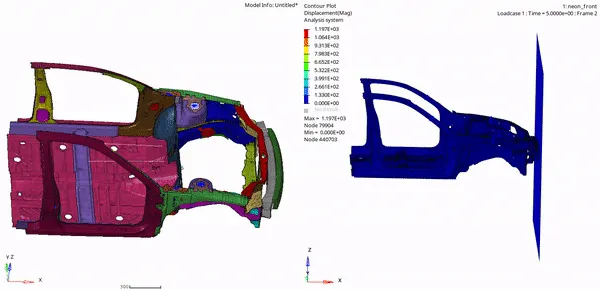
DISPLACEMENT
VON MISES
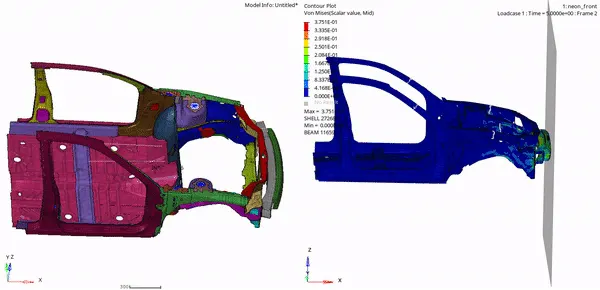
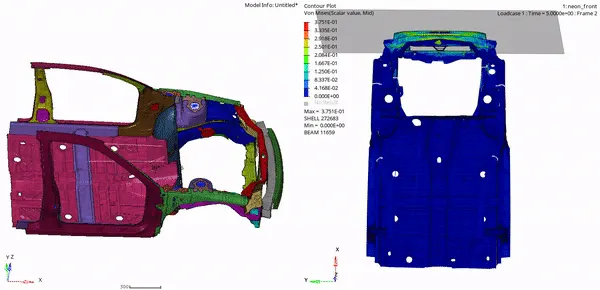
Initially, the bumper starts crushing then the bumper forces are transferred to the left and right rail from the rail forces are transferred to A-Pillar LH and RH. In each stage, the forces are going to decreasing because energy is absorbed in each stage.
Since this is a reduced model the car is deforming in an unrealistic manner so when the model is simulated with all the other transmission and engine components the simulation will be more realistic.
Once the simulation is run we can check the Output files for Energy errors and Mass errors in out file.
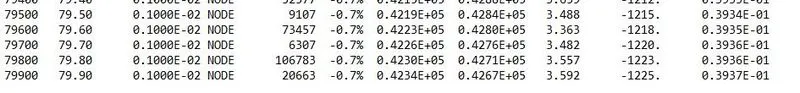
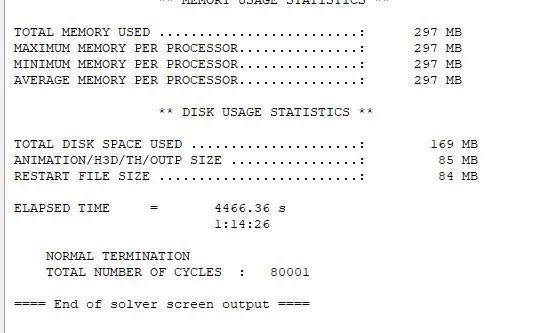
OBSERVATION:
The Energy Error is Negative and has been linearly increasing up to -0.7% only, which is acceptable. Mass error is very low which is acceptable range. Total number of cycle is 80001. Total time to run the simulation is 1hr14mins.
Energy and Force Graphs:
The tools to plot the graph are available on Hypergraph as T01 file.
Hypergraph 2D >> FIRST_RUNT01 >> Apply
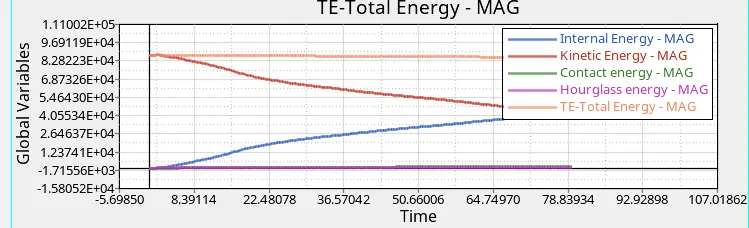
As the vehicle is moving with a velocity 15.646 m/s , the initial kinetic Energy will be High . Once the car is hit by the rigid wall, the vehicle starts deforming results in absorbing the Energy and stored it. Thus, internal Energy starts increasing. At the Maximum deformation, the Velocity will become Zero and thus the kinetic energy will also be dropping down to zero resulting there is no energy to absorb in the system. Thus, Internal Energy Remains Constant thereafter.
Contact energy is a type of energy that is formed when one element meets the other or neighbouring elements. The opposing force created by this element forms the contact energy. In this case, it increases after 5 ms, at this point the model starts deforming in such a way that penetration of nodes occurs. When certain regions of the model press on themselves, buckled elements are forced into contact.
The increase in contact energy affects the overall energy of this system, which is why there is a decrease in the total energy over the course of the simulation.
RWALL
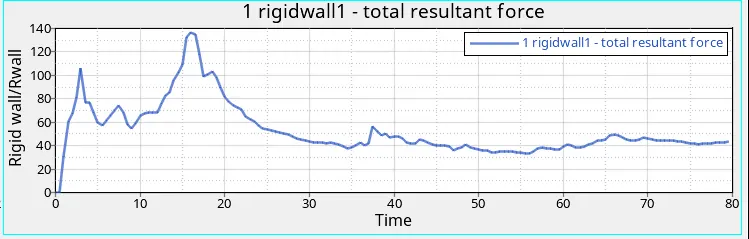
There are two peaks in forces at 2ms and 15ms respectively, these peaks are due to the force caused at the bumper at the beginning of the simulation. As the simulation goes on the RWALL forces decreases and again it increases slightly at the end of the simulation.
SECTIONAL FORCES:
FORCES EXPERIENCED IN THE RAILS:
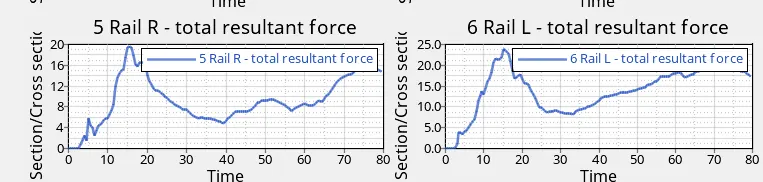
The maximum cross-sectional force at Left Rail is 20.54 kN. The force acting on the rail is the force transmitted by the bumper during the crash. The force transmitted by the bumper to the rail is not equal as some of the force will be absorbed by the Bumper resulting in deformation.
After the Maximum force, the force will decrease until 35ms after which it again increases as it comes into contact with the Rigid wall due to the large deformation.
FORCES EXPERIENCED IN THE SHOTGUNS:
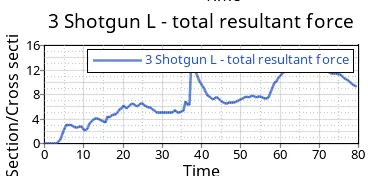
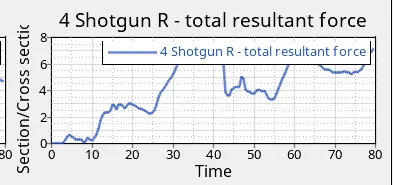
The maximum cross-sectional force at Left Shotgun is 13.17 kN whereas the maximum cross-sectional force at Right Shotgun is 7.8 kN. The Force that occurred at the shotgun is the force transmitted from the rail section. The force propagation is not the same at both the rails and hence the amount of deformation at both the shotgun sections are different. Once the Compressive force reaches its maximum value it starts to deform rapidly.
Therefore, the force is decreasing as referred from the graph. As the crash happen continuously, the shotgun will come into contact with the rigid wall as found in Animation, the rigid wall also exerts the force directly onto the shotguns, and hence there is an increase in the Sectional force as seen in the graph.
FORCES EXPERIENCED IN THE A-PILLARS:
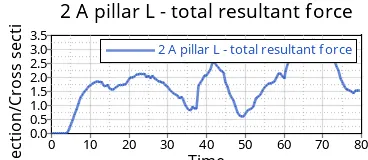
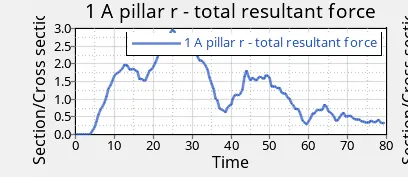
The maximum cross-sectional force at Left A-Pillar is 3.6 kN whereas the maximum cross-sectional force at Right A-Pillar is 2.8 kN. when the car hits the rigid wall, there will be some amount of force coming into the A-pillar at both sides. These forces coming to the A-pillar are nothing but the force transmitted from the rail and the shotgun. The force flowing into the LH and RH of the A-pillars will not be equal and hence the deformation of the elements will differ accordingly.
During a frontal crash, the sectional force reaching the A-pillars is coming in from the rails and shotgun, hence the force at the A-pillars will be less when compared to the front sections. When the compressive force between the wall and car is maximum, the rail and shotgun get in contact with the rigid wall which causes the shotgun and rail to exert more force. This force then propagates to the A-pillars and hence the force reaching the A-pillar increases again.
SPRINGS:
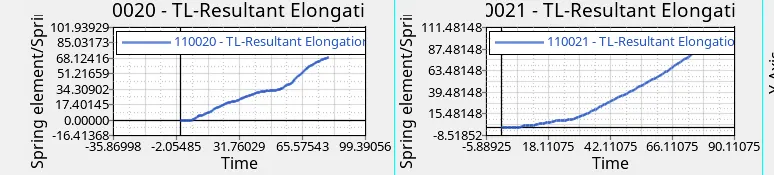
From the above graph, we can see that the maximum intrusion that occurred in the spring (Node 66695) during a crash is 92.67 mm, and the maximum intrusion that occurred in the spring (Node 66244) during a crash is 68.47 mm. Practically this elongation referred to which extent the foot pedal or the passenger's legs will move once the crash is happening. From the animation, we can notice that there is not much deformation that occurred at this location and the elongation is also low. Hence the impact on passenger will be very low.
ACCELEROMETER:
As we all know that an Acceleration is the rate of change of velocity. To measure the acceleration, we have placed the accelerometer near the Rocker of B-Pillar on both sides.
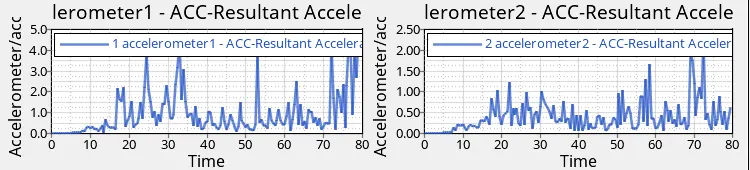
Once the Car hits the rigid wall with the initial velocity, the acceleration of the vehicle during the crash is not constant across the structure. The front of the vehicle slows down immediately as it hits the rigid wall, while the rest of the structure decelerates at a slower rate as seen in the graph.
As seen from the graph there is a sudden increase in the acceleration, this might be because of some vibration that occurs during the crash with respect to the point where the accelerometer is placed.
Learning Outcome:
- Learned how the rigid wall interface works and can lead to incompatible Kinematic conditions.
- Learned to set up load cases
- Learned how the distribution of forces among the components during a frontal crash.
- Learned how components are designed to deform in such a way to ensure the safety of the passengers inside the cabin.
- Learned how to Debugging errors in order to get the right results.
CONCLUSION:
The given model was simulated for the frontal crash using Radioss and the results obtained were observed. The graphical results were plotted for all the test cases. From the simulation, it can be observed that there was minimum deformation in the cabin, and also minimum intrusion was found in the driver’s seat area.
T01FILE
https://drive.google.com/file/d/1yFxpxsOrJv-4PXb6IYdPHTRWgH6_bP2A/view?usp=sharing