AIM: simulate the forward kinematics of a 2R Robotic Arm.
theory:
taken that Q1 ans Q2 are given.
Q1 being theta1,
Q2 being theta2,
step1: calculate position of link1
which has two end points, starting point which is attached, and the end point.
given below respectively,
x0= 0; y0=0,
x1=l1 x cos Q1; y1=l1 x sin Q1
step2: calculate position of link2
x2= x1+l2xcosQ2
y2= y1+l2xsinQ2
lentgh of link 1= l1 = 1,
length of link 2= l2= 0.5,
angle between surface and link 1 = theta1
angle between surface parallel and link2= theta2,
coordinates of starting point of link 1= x0, y0
where x0= 0
y0= 0;
coordinates of end point of link 1= coordinates of starting point of link 2= x1, y1
where x1= l1*cosd(theta1)
y1= l1*sind(theta1);
coordinates of end point of link 2= x2, y2
where x2= x1+l2*cosd(theta2)
y2= y1+l2*sind(theta2);
PROCEDURE:
- write down the code accordingly, starting from, clear all, close all and clc.
- code down the inputs, including l1,l2,theta1, and theta2. (where theta is taken by linspace)
- we code ct, as 1
- and then we code for loop, for i=1:length(theta1), THETA1= theta1(i).
- in next for loop, we code j= 1:length(theta2), THETA2= theta2(j).
- on the next step, we code down the coordinates, x0,y0,x1,y1,x2 and y2.
- and then we give the plot commands for l1 aand l2, by coding "plot", give the pause interval and then save the frames by getframe(gcf)
- and then we end it with commands for the resulting video.
CODE:
clear all
close all
clc

%inputs
l1= 1;
l2= 0.5

theta1= linspace(0,90,10);
theta2= linspace(0,90,10);

ct=1;
for i=1:length(theta1);
    THETA1= theta1(i);

  for  j=1:length(theta2);
    THETA2= theta2(j);


%coordinates
x0=0;
y0=0;

x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);

x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);

%plotting
plot([x0 x1], [y0 y1], [x1 x2], [y1 y2], 'linewidth' , 3);
axis([-0.1 1.5 0 1.5]);
pause(0.03)
M(ct)=getframe(gcf);
ct=ct+1;


  end
end
movie(M)
videofile = VideoWriter('forward_kinematics.avi', 'uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)
RESULT:
the required outcome was achieved.
https://www.youtube.com/watch?v=Qr6Osm7V1DU
ERROR FACED:
1.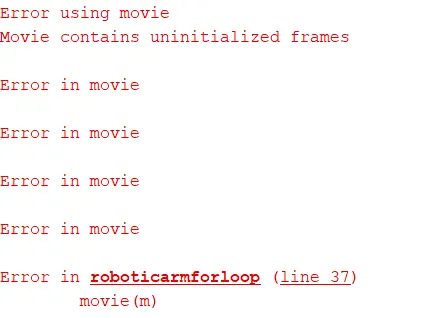
to correct this error simpy, "ct=ct+1" had to come after m(ct)=getframe(gcf).
2.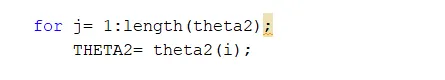
for this error, a simple correction was made in the second line,where instead of "i" j was replaced.
3.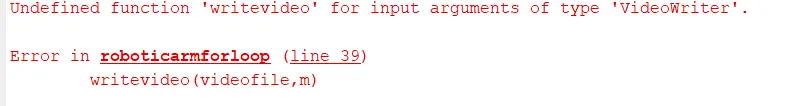
for this the a basic correction was made, the V in "writevideo" was done capital.
END