ADAMS - Project - Hardpoint tuning to achieve pitch gradient targets using suspension “anti” characteristics
Problem Objective:-
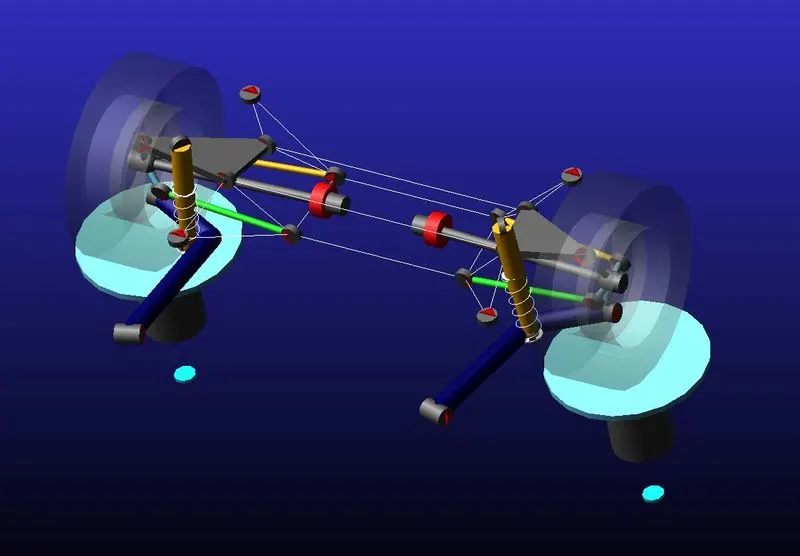
- Perform hardpoint tuning to achive the target accelaration and braking pitch gradient, to simulate this take Double wishbone suspension at the front & multilink suspension at the rear.
- Adams plot showing effect of tuning (overlay curves).
- Completed Excel Sheet.
Project Target & Constraints:-
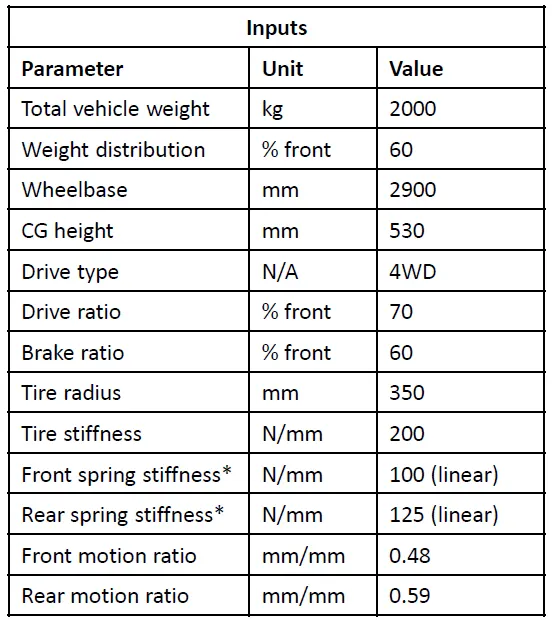
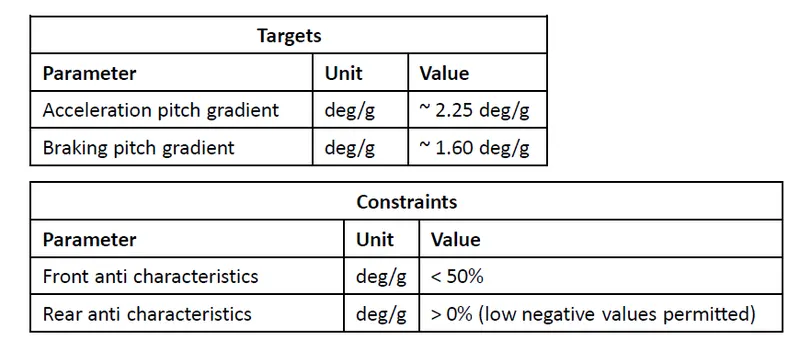
Introduction:-
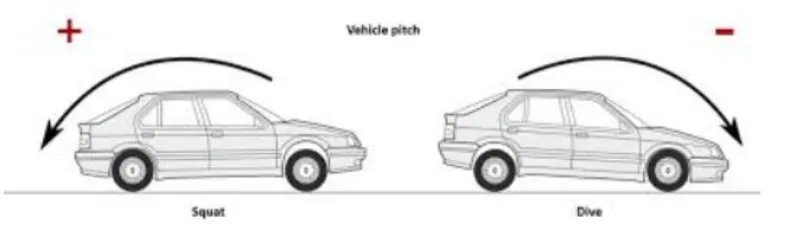
- Pitch:- Pitch is a dynamic output of vehicle suspension in which a couple when we apply braking or accelaration, some amout of load trafer to rear when we accelarate & vise-versa to the rear when we braking.
- Anti:- Anti geometry consisit of anti-dive, anti-squat, anti-lift. it refers to the amount of suspension travel in compression or rebound when we braking & accelaration.
Dive:-
- When the vehicle is braking, a longitudinal couple generate & some amount of the RAW(Rear Axle Weight) weight tranfer to front axle, so the front wheel is in compression & the rear wheel will rebound.
Squat:-
- When the vehicle is accelarate, a longitudinal couple generate & some amount of the FAW(Front Axle Weight) weight tranfer to rear axle, so the front wheel is in rebound & the rear wheel will compression.
Simulation part:-
1) SLA front suspension
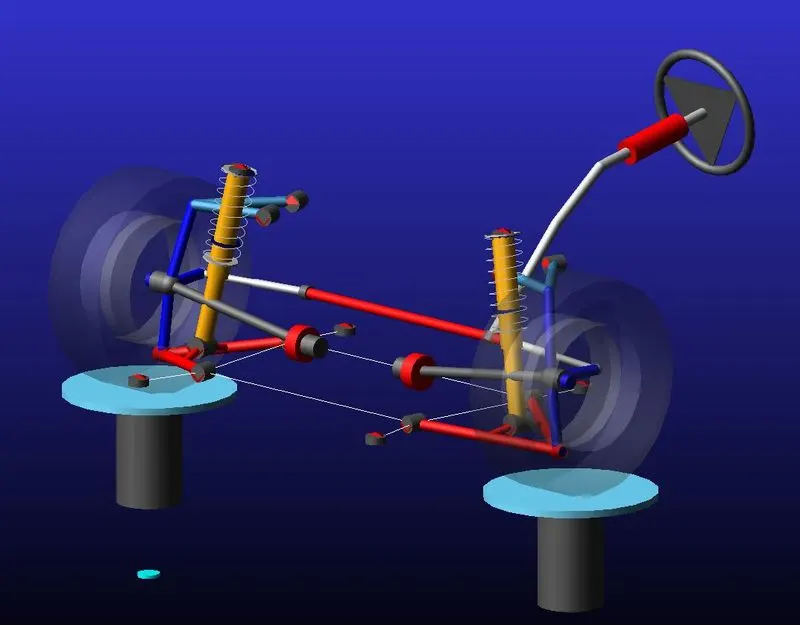
2) Multilink rear suspension
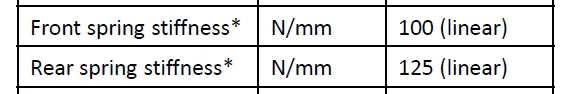
3) Modified spring stiffness for Front & Rear
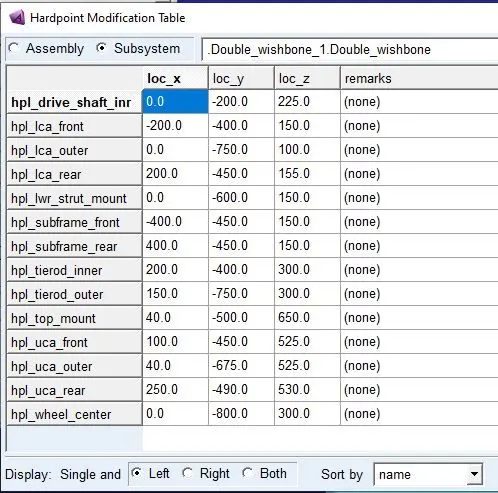
4) Hard point tuned both front & rear to achive the motion ratio target,
a) Default hard point table-Front Suspension
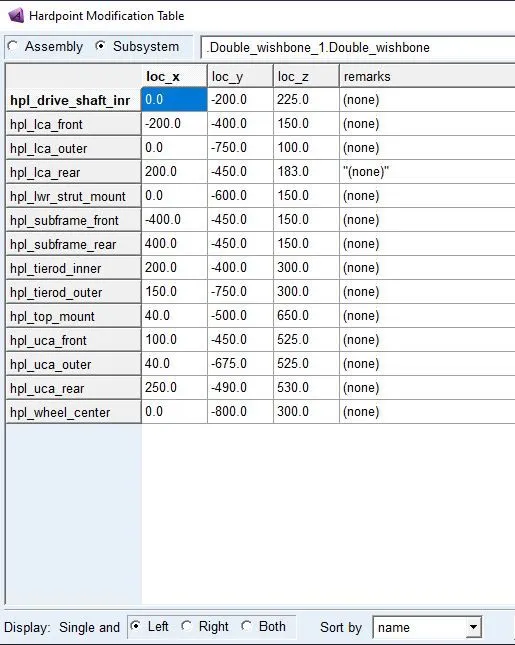
b) Modified hard point table-Front Suspension
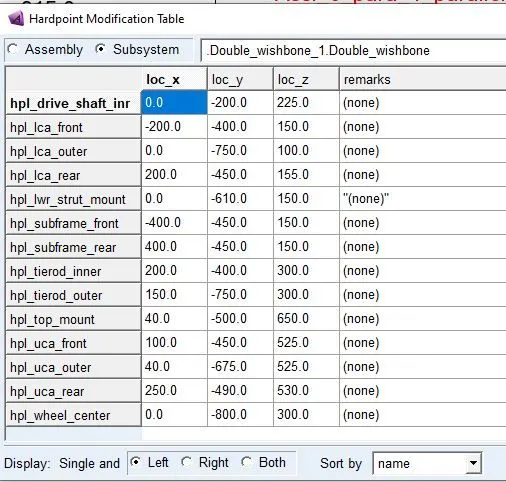
c) Default hard point table-Rear Suspension
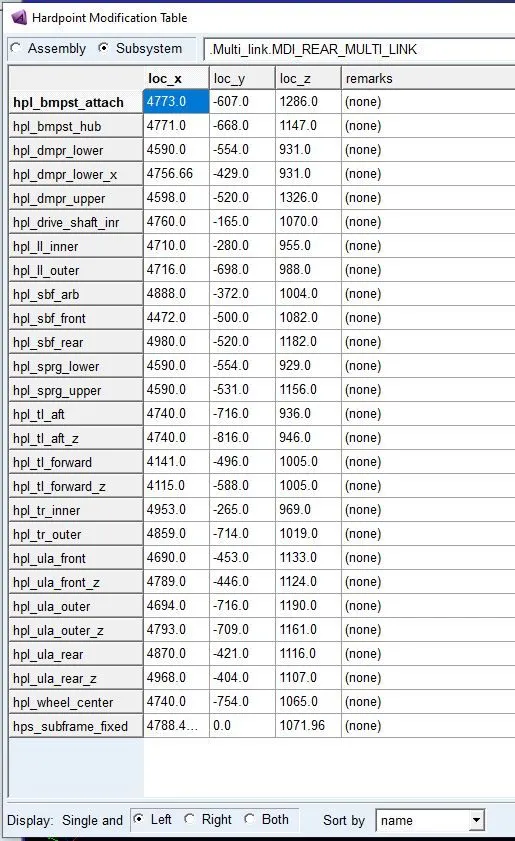
d) Modified hard point table-Front Suspension
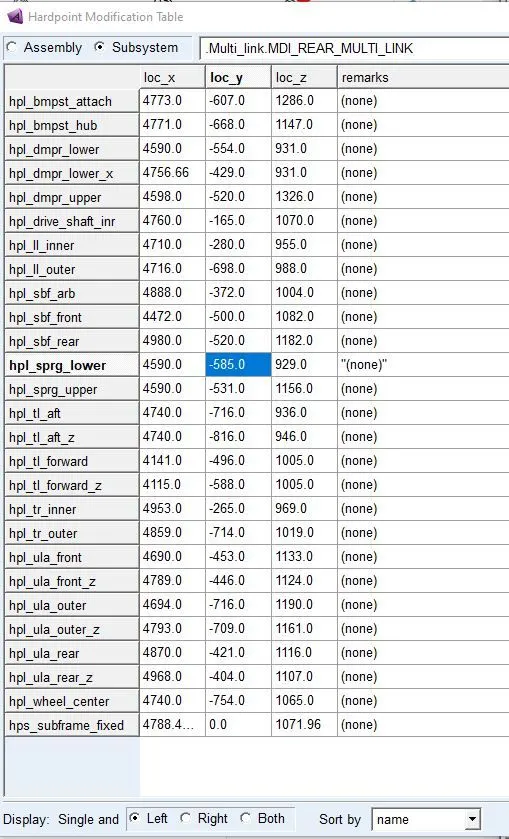
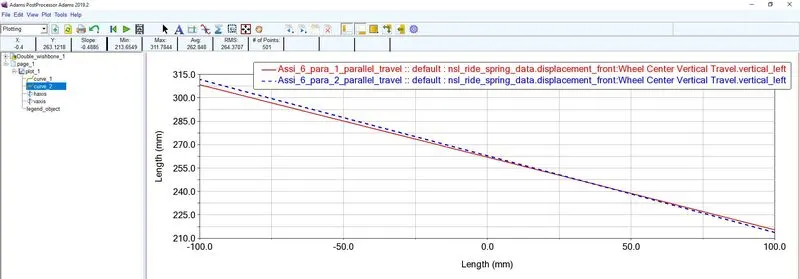
e)Front suspension motion ratio=0.48
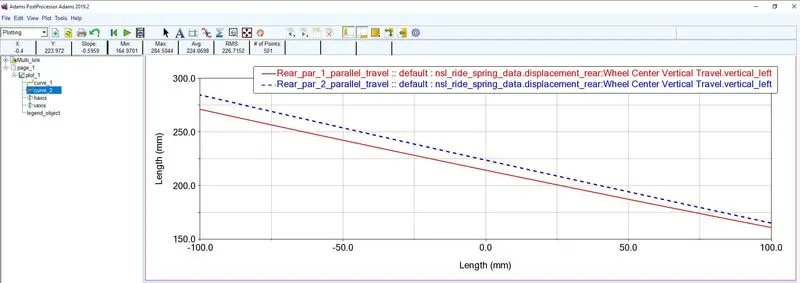
f)Rear suspension motion ratio=0.59
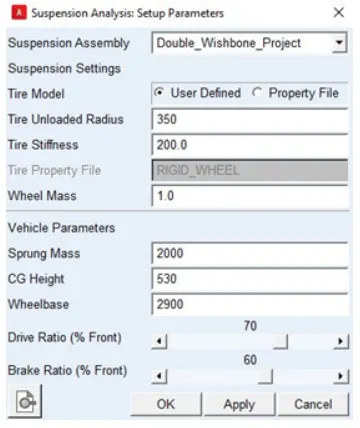
5)Front & Rear Suspension as per given data
a)Front
b)Rear
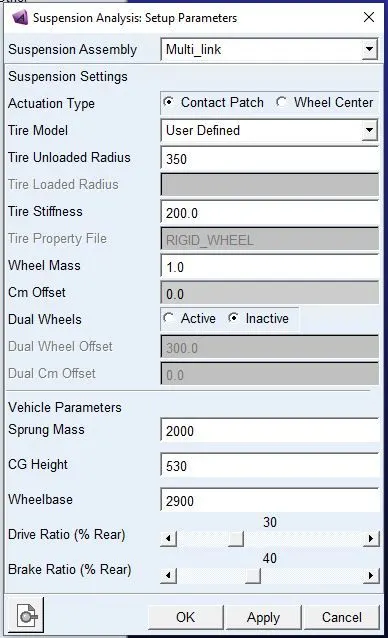
c) Parallel wheel simulation run for both front & rear
d) Modify hard point
Front
Rear
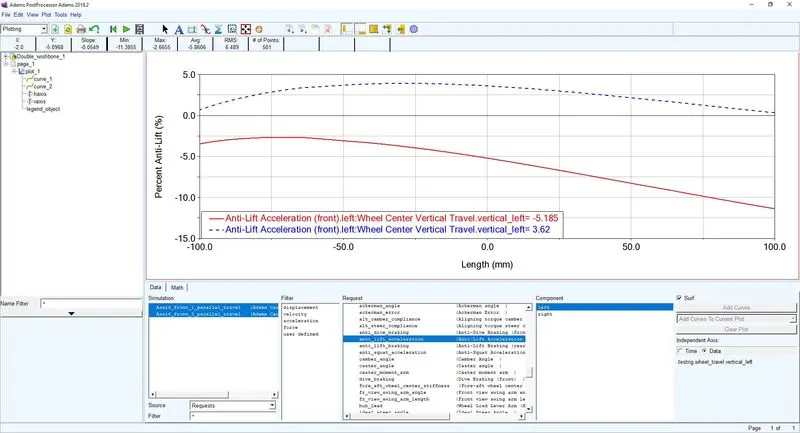
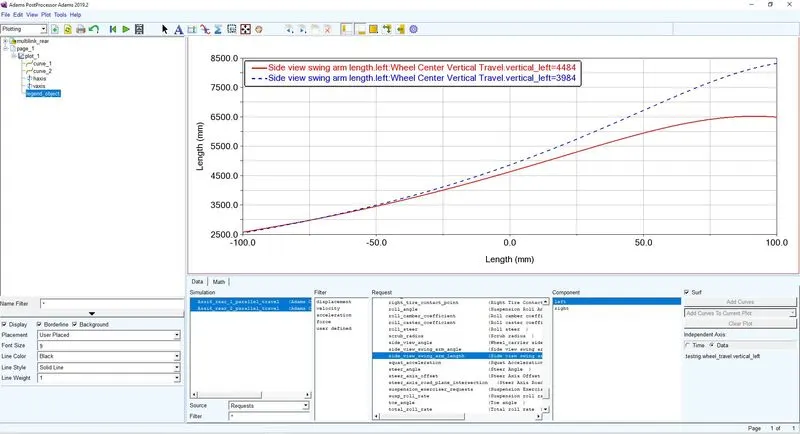
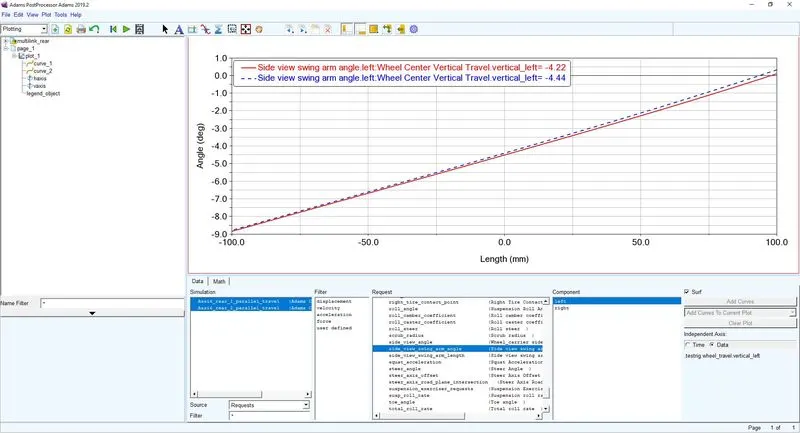
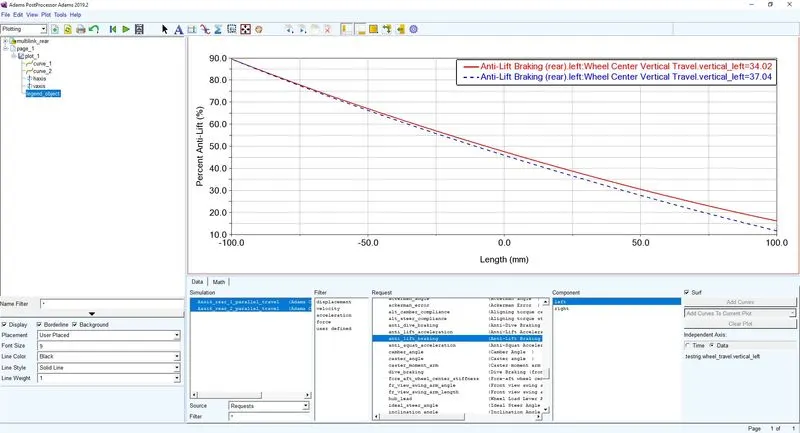
6)Postprocessor Result
a) Front
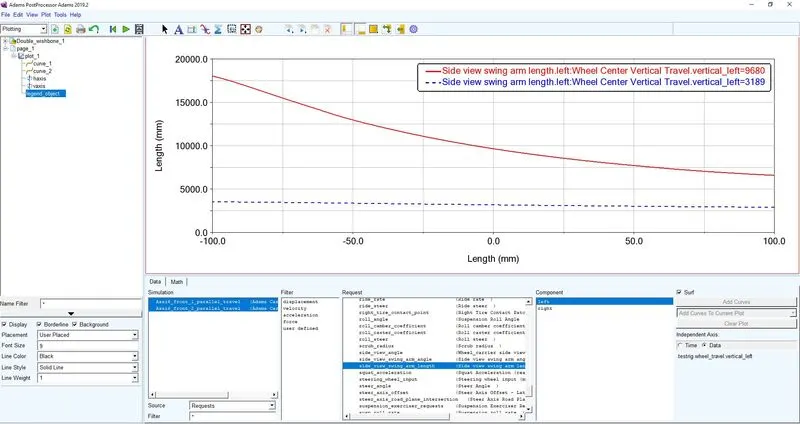
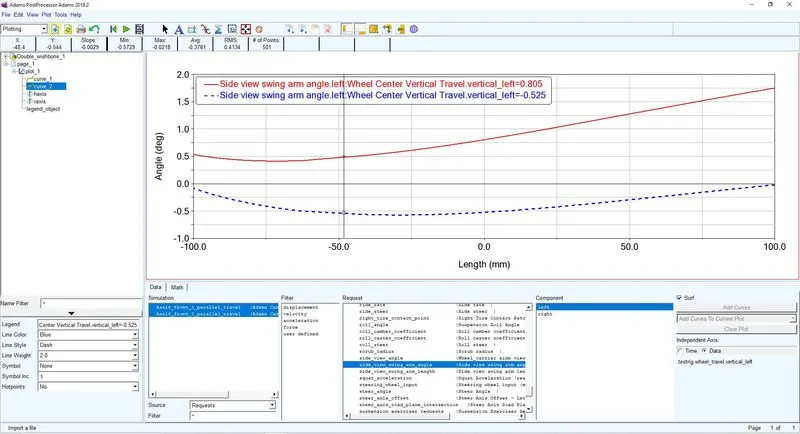
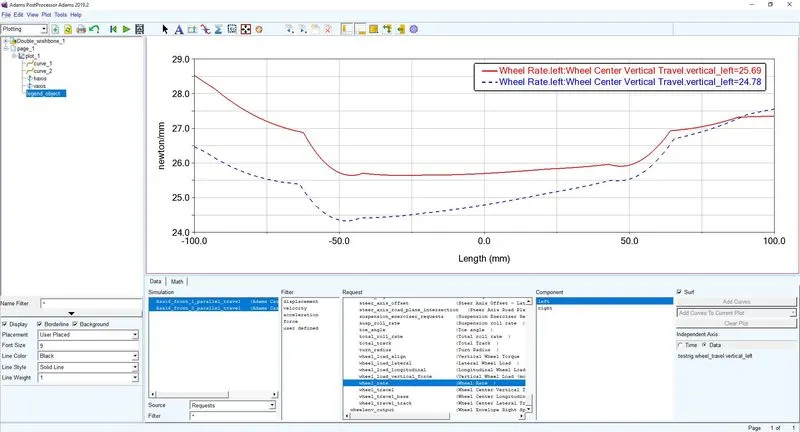
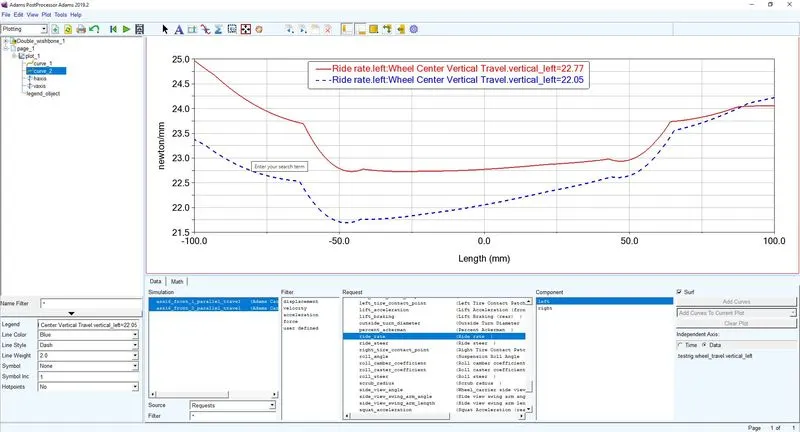
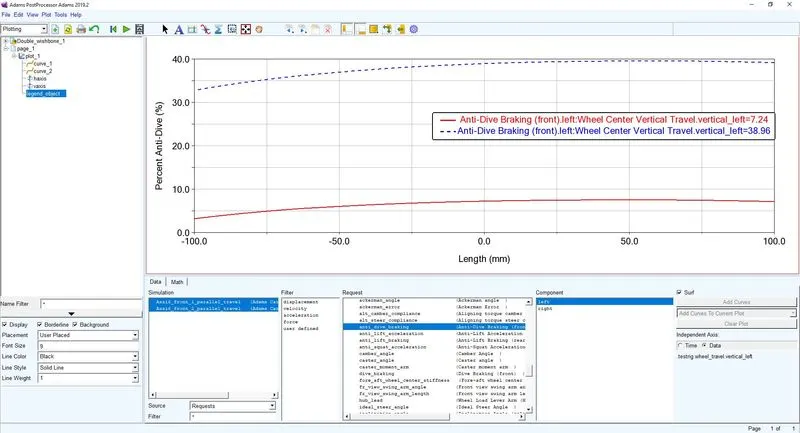
b) Rear
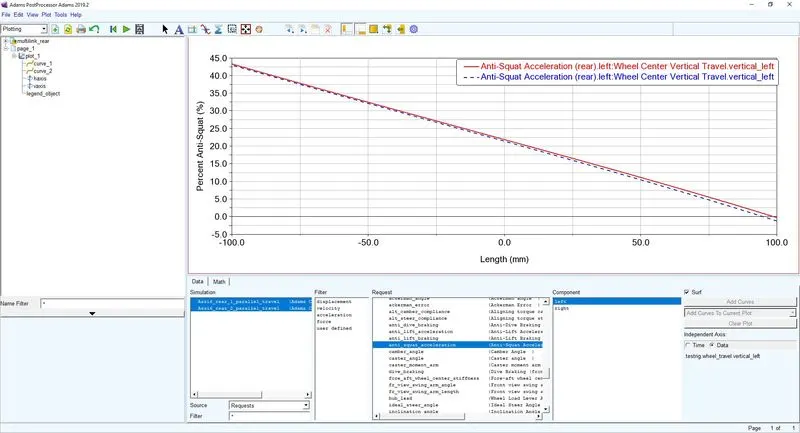
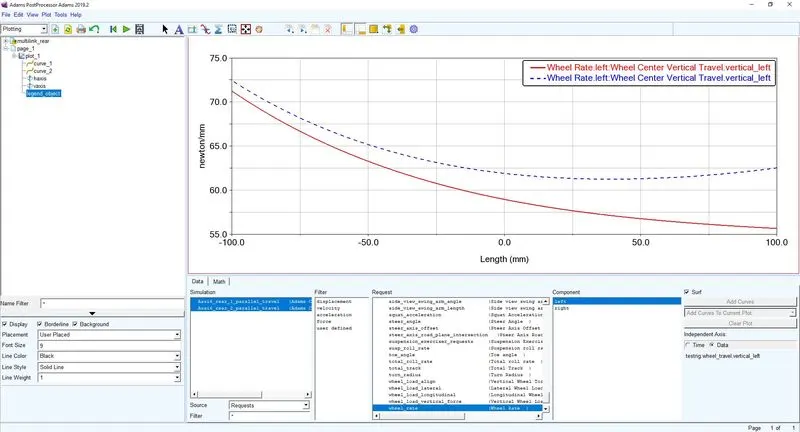
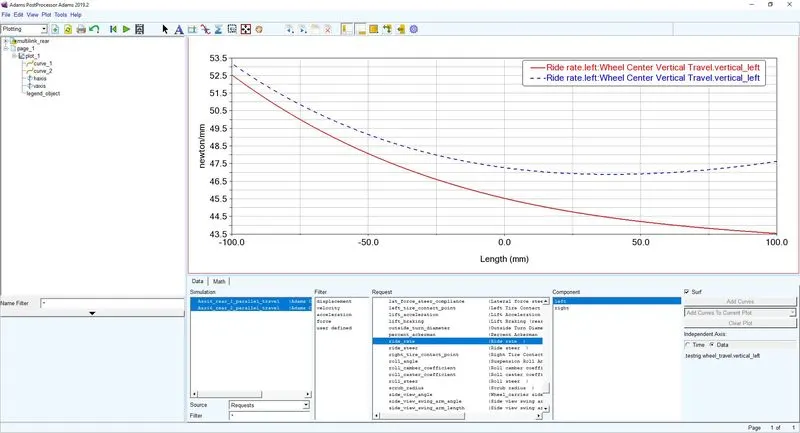
7) Calculation sheet
https://docs.google.com/spreadsheets/d/1_ARe08YbG1mUBOIzVsutw6mBqNoLuPr2/edit?usp=sharing&ouid=112320063003967917340&rtpof=true&sd=true