Week 8 Challenge: Thermal Management
Week 8 Challenge: Thermal Management
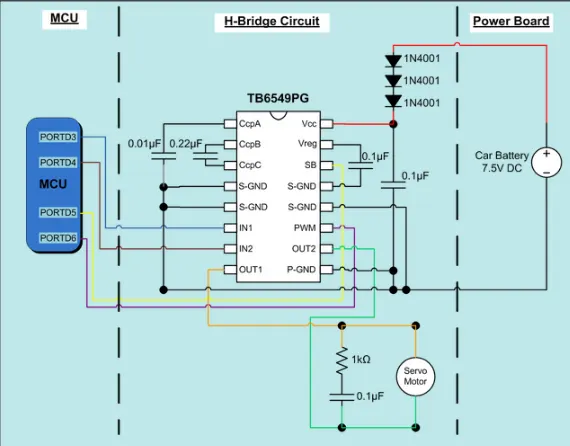
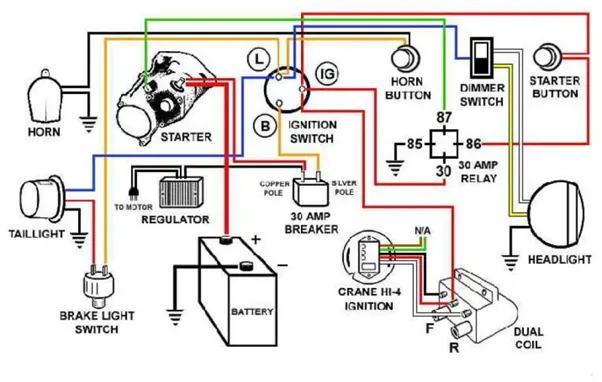
- Draw a high-level schematic of remote controller toy car system. What are the differences for an actual car?
- What are the cooling requirements of a power converter? Take an example system and assume efficiency and other parameters. Suggest suitable solution to keep temperature below limit.
- Refer to below link and estimate thermal management system power requirement.
https://teslamotorsclub.com/tmc/threads/tesla-thermal-management-system-explanation.88055/
- Draw a high-level schematic of remote controller toy car system. What are the differences for an actual car?
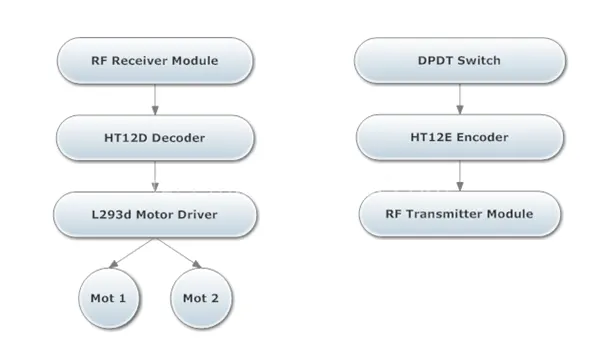
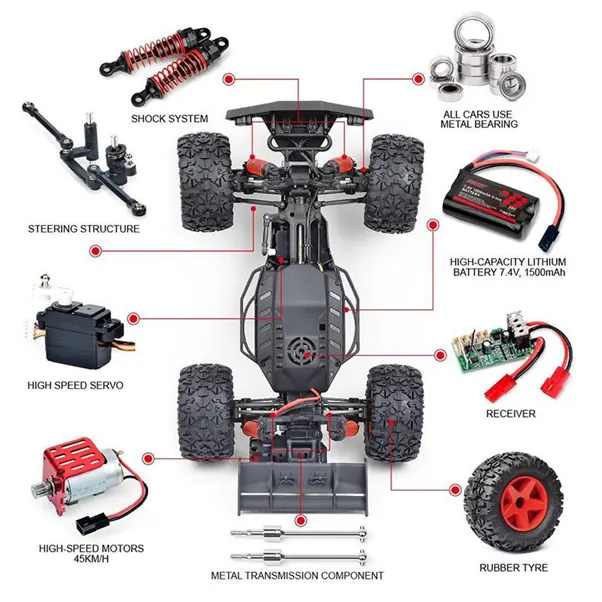
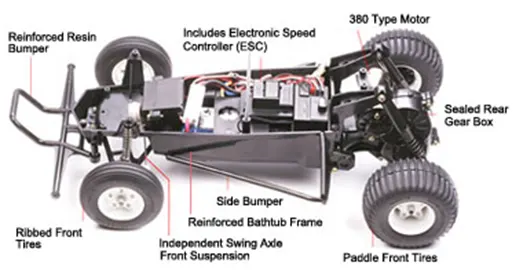
Radio-controlled or remote-controlled toys, popularly called RC toys, are self-powered and can be controlled from a distance using a remote that works with radio waves.
1. When we push the control, the transmitter sends a specific number of electrical pulses corresponding to that action through the air. The transmitter has its own power source, usually in the form of a 9-volt battery. Without the battery, the transmitter will not be able to send the radiowaves to the receiver.
- Once the RC toy receives the radio waves, the motors kick into life to cause a specific action to occur. The power source sends power to all working parts, including the motor. The transmitter enables control through radio waves and the receiver activates the motors. When we press a button on the transmitter to make the RC toy go forward or backward, a pair of electrical contacts touch. Receiver identifies signals, sends it to circuit.
Circuit board translates the number of electrical pulses (signals) into action. Full-function controllers have six controls and these works through following the pulse sequences:Forward: 16 pulses
1. Reverse: 40 pulses
2. Forward left: 28 pulses
3. Forward right: 34 pulses
5. Reverse left: 52 pulses
5. Reverse right: 46 pulses
Parts of an RC toy -
 Transmitter: The remote control contains a radio transmitter which operates on a particular frequency that the receiver is designed to receive.
 Receiver: The receiver is fixed within the car and constantly receives signals from the transmitter. When a transmission is identified, it translates the number of electrical pulses into action.
 Power source: All remote control cars require a power source. Rechargeable batteries power small electric motors. Alternatively, some use small internal combustion engines.
Motor and Circuit Board: The motor is responsible for the turning motions of the toy while the circuit board works like a pool through which all commands go on to specific parts.
remote controlled toy car circuit, consisting of an infrared transmitter-receiver pair, uses IR beam transmission to switch the toy car ‘on’ or ‘off ‘. To operate the toy car, you need to hold the transmitter in your hand, keeping it pointed at the toy car which has the receiver fitted inside, and simply press a switch provided on the transmitter.
The transmitter works off 9V DC, while the receiver needs 6V DC. Fig. 1 shows the transmitter circuit. It is built around two BC558 transistors (T1 and T2), ,three BC548 transistors (T3, T4 and T5), IR LED1 and a few discrete components.
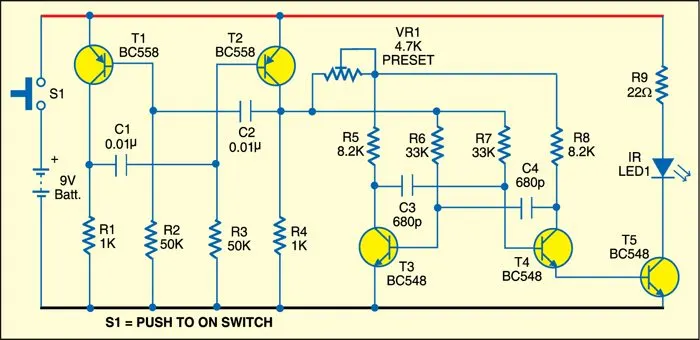
Fig. 1: Transmitter circuit
Fig. 2 shows the receiver circuit. It is built around IR receiver module TSOP1738, two BC548 transistors (T6 and T7) and a few discrete components. In the transmitter circuit, there are two stable multivibrators. The first, built around transistors T1 and T2, produces a frequency of about 1.2 kHz. The second, built around transistors T3 and T4, produces about 38 kHz. IR LED1 is used to transmit the 38kHz frequency.
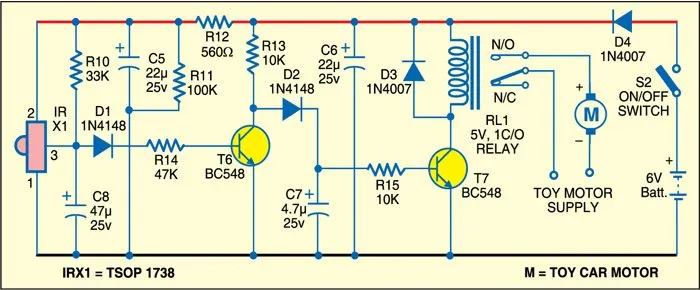
Fig. 2: Receiver circuit
In the receiver circuit, TSOP1738 receives the IR signal transmitted by IR LED1 of the transmitter circuit. The output of TSOP1738 is fed to transistor T6 via diode D1. The amplified signal is further given to relay-driver transistor T7. Relay RL1 energises to control the toy car.
Working of the circuit is simple. Initially, when no IR beam is falling on sensor TSOP1738, the relay remains de-energised and the toy car doesn’t move. When switch S1 is pressed, the IR beam falls on TSOP1738 and its output goes low. Transistor T6 cuts off and transistor T7 conducts to energise relay RL1 and move the toy car.
Assemble both the circuits on separate PCBs. Enclose the transmitter PCB in a suitable cabinet, with IR LED1 affixed on the front side and switch S1 on the top of the cabinet. Keep the 9V battery inside the cabinet.
Enclose the receiver PCB inside the toy car, with TSOP1738 fitted such that the transmitted IR beam directly falls on it. Fix switch S2 on the body of the car and the relay inside the car. Use a 6V battery to operate the toy car receiver unit.
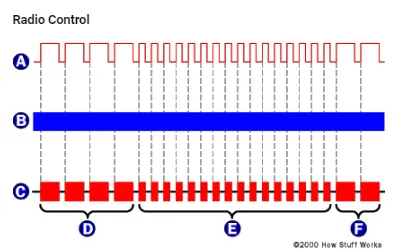
Here is the sequence of events that take place when you use the RC transmitter.
- You press the trigger to make car go forward.
- The trigger causes a pair of electrical contacts to touch, completing a circuit connected to a specific pin of an Integrated Circuit.
- The completed circuit causes the transmitter to transmit a set sequence of electrical pulses. Each sequence contains a short group of synchronization pulses followed by the pulse sequence.
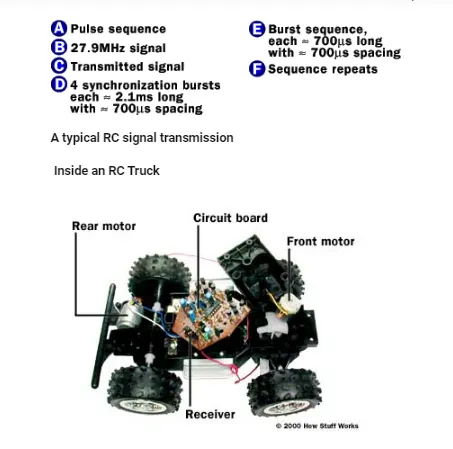
- The synchronization segment which alerts the receiver to incoming information is 4 pulses that are 2.1 milliseconds (thousands of seconds) long, with 700 microseconds (Millionths of seconds) interval. The pulse segment which tells the antenna what the new information is, uses 700 microsecond pulses with 700 microsecond intervals.
How actual car is different than toy car?
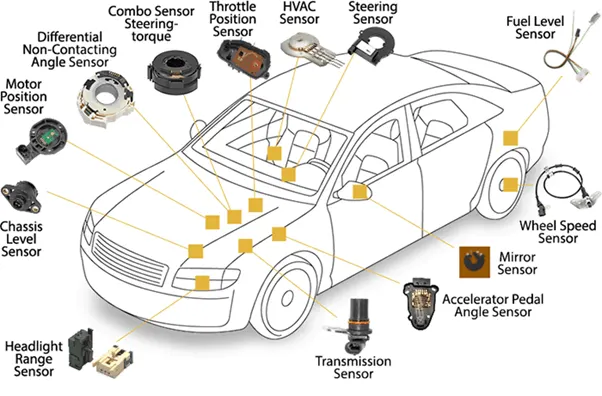
Actual car is made up of 2 main components 1) Adjoining and supporting components 2) Automobile Sensors.
- Adjoining & Supporting components consist of –
Chassis and Frame - The chassis is formed by the frame with the frame side members and cross members. The frame is usually made of box, tubular and channel members that are welded or riveted together. In addition to this, it comprises of the springs with the axles and wheels, the steering system and the brakes, the fuel tank, the exhaust system, the radiator, the battery and other accessories. Along with this the frame supports the body.
Engine or Power Plant - The engine is the power plant of the vehicle. In general, internal combustion engine with petrol or diesel fuel is used to run a vehicle. An engine may be either a two-stroke engine or a four-stroke engine. An engine consists of a cylinder, piston, valves, valve operating mechanism, carburettor (or MPFI in modern cars), fan, fuel feed pump and oil pump, etc. Besides this, an engine requires ignition system for burning fuel in the engine cylinder.
Transmission System (Clutch and Gear Box) - The power developed by the engine is transferred to the wheels by transmission system. Transmission system must do three jobs: (a) It must provide varying gear ratios. Number of gear ratios are equal to number of gears in a vehicle. (b) It must provide a reverse gear for moving vehicle in reverse direction. (c) It must provide a neutral or disconnecting arrangement so that the engine can be uncoupled from the wheels of the vehicle. In a conventional transmission system, there is a clutch, a manually operated transmission (gear box), a propeller shaft and a differential or final drive.
Clutch - The purpose of the clutch is to allow the driver to couple or decouple the engine and transmission. When clutch is in engaged position, the engine power flows to the transmission through it (clutch). When gears are to be changed while vehicle is running, the clutch permits temporary decoupling of engine and wheels so that gears can be shifted. In a scooter, the clutch is operated by hand where as in a car the clutch is operated by foot. It is necessary to interrupt the flow of power before gears are changed. Without a clutch, it will be very difficult.
Final Drive - Final drive is the last stage in transferring power from engine to wheels. It reduces the speed of the propeller shaft (drive shaft) to that of wheels. It also turns the drive of the propeller shaft by an angle of 90o to drive the wheels. The propeller shaft has a small bevel pinion which meshes with crown wheel. The crown wheel gives rotary motion to rear axles. The size of crown wheel in bigger than that of bevel pinion, therefore, the speed of rear axles (or crown wheel) in lower than the speed of pinion. Final drive is of two types, i.e. chain type and gear type.
Braking System - Brakes are used to slow down or stop the vehicle. Hydraulic brakes are generally used in automobiles, where brakes are applied by pressure on a fluid. Mechanical brakes are also used in some vehicles. These brakes are operated by means of 9 Introduction to Automobile Engineering leavers, linkages, pedals, cams, etc. Hand brake or parking brake is usually a mechanical brake. These are used for parking the vehicles on sloppy surfaces and also in case of emergency.
Gear Box Gear box contain gearing arrangement to get different speeds. Gears are used to get more than one speed ratios. When both mating gears have same number of teeth, both will rotate at same number speed. But when one gear has less teeth than other, the gear with less number of teeth will rotate faster than larger gear. In a typical car, there may be six gears including one reverse gear. First gear gives low speed but high torque. Higher gears give progressively increasing speeds. Gears are engaged and disengaged by a shift lever.
Steering System - In front wheels can be turned to left and right by steering system so that the vehicle can be steered. The steering wheel is placed in front of driver. It is mechanically linked to the wheels to provide the steering control. The primary function of the steering system is to provide angular motion to front wheels so that vehicle can negotiate a turn. It also provides directional stability to vehicle when the vehicle moves ahead in straight line. Now-a-days, many vehicles are equipped with power steering which uses pressure of a fluid to reduce steering effort. When driver turns the steering wheel, a hydraulic mechanism comes into play to provide most of the effort needed to turn the wheel.
Front Axle - Front axles are mounted at the end of front axle. A part of the weight of vehicle is transmitted to the wheels through this axle. The front axle performs several functions. It carries the weight of the front of the vehicle and also takes horizontal and vertical loads when vehicle moves on bumpy roads. When brakes are provided on front wheels, it endures bending stresses and torsional stresses. It is generally made from steel drop forging. It is robust in construction.
Suspension System - Suspension system of an automobile separates the wheel and axle assembly of the automobile from its body. Main function of the suspension system is to isolate the body of the vehicle from shocks and vibrations generated due to irregularities on the surface of roads. Shock absorbers are provided in the vehicles for this purpose. It is in the form of spring and damper. The suspension system is provided both on front end and rear end of the vehicle. A suspension system also maintains the stability of the vehicle in pitching or rolling when vehicle is in motion.
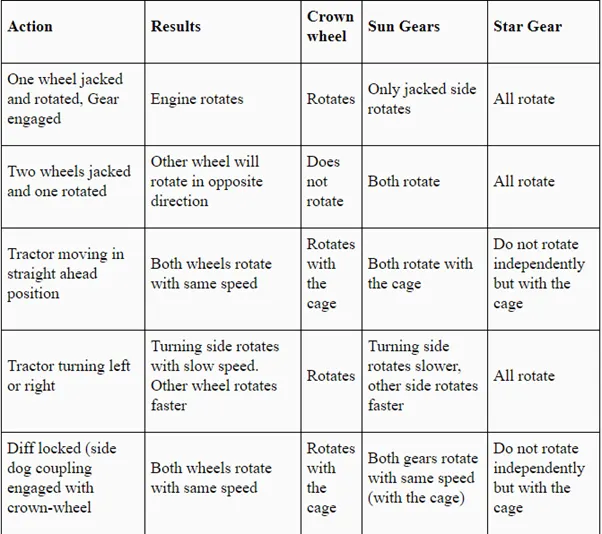
Differential -
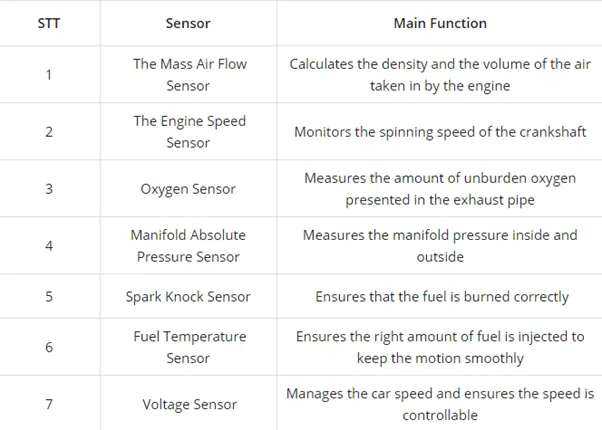
- Automobile Sensors –
- What are the cooling requirements of a power converter? Take an example system and assume efficiency and other parameters. Suggest suitable solution to keep temperature below limit.
A high-density dc-dc converter can deliver substantial power, but only if excessive heat is removed by transferring internal heat through a number of material interfaces to a surface exposed to the surrounding air.
Historically, dc-dc converters rated less than 25 W have been treated like most other pc board mounted components because they are typically rated for a given amount of power up to a certain ambient temperature. Converters classified as “high density,” however, are more closely associated with power levels above 25 W and range up to a few hundred watts. These high-density converters, unlike their lower power predecessors, are specified like power semiconductors and are rated in terms of their maximum allowable baseplate temperature, regardless of the ambient.
With LED lamps and fixtures, the heat removal challenges are more complex because of the required form factors. That means even at power levels as low as 7-10 watts, these designs need more attention so that LED chips do not overheat.
From a thermal management standpoint, a high-density dc-dc converter, like virtually all power supplies, can deliver substantial power, but only if excessive heat is removed by transferring internal heat through a number of materials to a surface exposed to surrounding air. Heat from that outer surface is then transferred to the surrounding air in proportion to the air turbulence immediately adjacent to that surface, whether that “turbulence” results in the form of fast-moving air (active cooling) or very tiny air “eddy currents” in a passively cooled system.
The reference to “outer surface” needs a further comment because no mention was made of a “metal” surface. The reason for this is that in a perfect situation all of the internal heat would originate from every cubic millimeter within the module and would be evenly distributed to all parts of the outer surface. Whether the outer surface is plastic or metal makes no difference as long as there is no effort to attach one of the hot surfaces to a heat sink; that is, as long as there is only (surface-to-air) convection cooling.
In a real world power module or light fixture, specific components (which can be either traditional power semiconductor or power LEDs) are the principal heat generators. The area adjacent to these components is usually hotter than other areas. An outer metal case or plate spreads the heat and reduces point-to-point temperature variations. With a high-density converter having a metal baseplate, the thermal conductivity of the plate material is an indispensable link to a cooling technique, which is better than simple surrounding air.
The baseplate has two functions: to spread the heat generated by small-surface-area power semiconductors and to conduct that heat to a cooler place. For the remainder of this discussion, the concentration will be on heat removal from the power semiconductors within the converters (or light fixtures) because they usually represent over 85% of the internally generated heat.
The process which final surface-to-air heat makes transfer is what determines the ultimate ability of a converter to deliver its maximum possible power. The barrier to perfect heat transfer is defined as “thermal resistance,” that is, the lower the thermal resistance, the better the heat transfers. Stated another way, the higher the thermal conductivity, the better.
However, it has become the convention in addressing power semiconductor and power supply thermal management to talk in terms of “thermal resistance” instead of thermal “conductivity.”
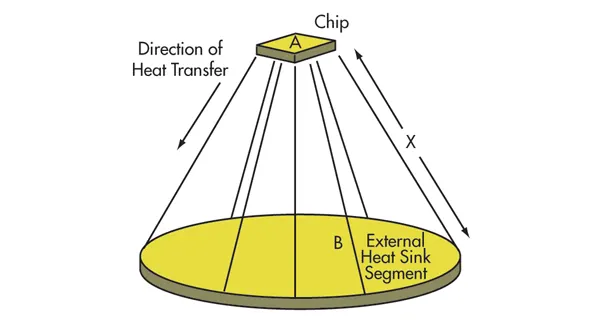
Fig. 1. Thermal transfer cone.
In practice, internal heat is never perfectly distributed and there are hot spots. Fig. 1 shows how heat from a point source, such as the chip within a MOSFT or power rectifier package reaches its destination. Heat travels outward in a conical path that is rarely a perfect cone because of the physical configuration of heat generators. Fig. 2 depicts the same process in a way that reflects the typical arrangement for heat removal from the power semiconductor in a dc-dc converter.
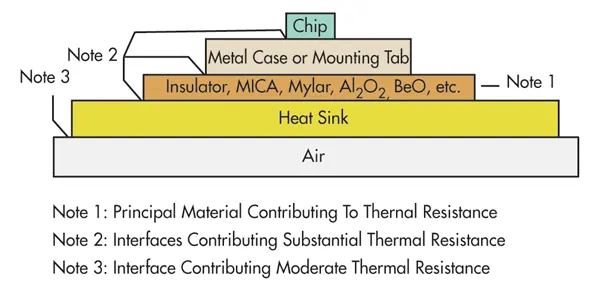
Fig. 2. Typical dc-dc converter thermal transfer path.
In an LED light fixture there is typically another set of thermal barriers between the chip tab or substrate and the heat sink. It is usually in the form of a metal-core PC board and related thermal interface material.
The ability of heat to get from one place (such as the chip) to another (the surrounding air) is determined by:
- The distance (thickness)
- The area (a large glass window transfers or loses heat faster than a small windoww.
- Thermal resistance of the various materials and interfaces through which the heat must pass.
Often not appreciated is the fact that a material of given thermal resistance has a more adverse effect the closer it gets to the point source of heat. Conversely, the actual thermal resistance of a given thickness of material becomes less important the more it is at the wide end of the het travel cone. This means that an infinite amount of heat sinking and airflow cannot keep the chip cool if the chip-to-case and case-to-heat sink surfaces have excessive thermal resistance. In some applications, the simple change to a chip of larger area and correspondingly lower junction-to-case thermal resistance could have more effect than an exotic fan and heat sink system.
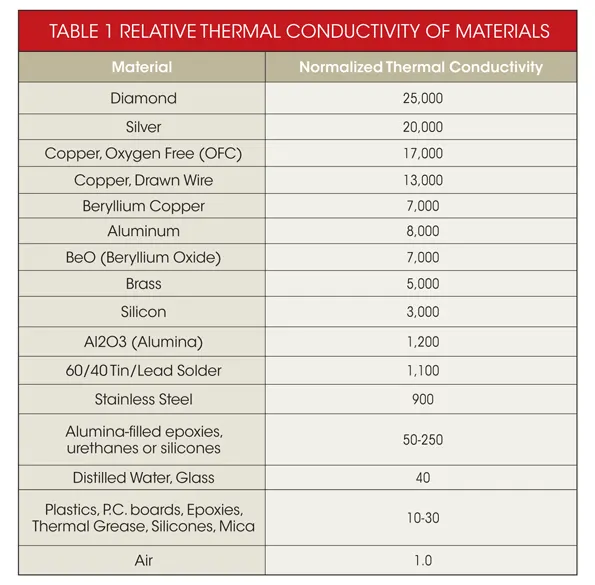
Table 1 compares a number of materials that often play a role in thermal management. It may be surprising that all epoxies, plastics and silicones fall into a narrow band from 10 to 30. There are no units for thermal resistance. The figures are normalized, using air as 1.0. Thermal resistance, unlike electrical resistance has a few conditions attached to it. It is influenced by the thickness and area of material, so Table 1 shows the relative difference in thermal resistance for different materials to be employed in an identical physical configuration.
Also, there is no such thing as a “thermally conductive” epoxy unless it is filled with a material higher up on the scale, such as aluminum oxide. One epoxy might be relatively more thermally conductive than another, but the thickness and area can often outweigh the actual material type.
Cooling Methods
A converter’s heat transfer can be enhanced by using one or more of the following techniques to lower the thermal resistance, i.e., the thermal conductivity from the internal converter heat sources to the outer air:
- Use a large metal enclosure to expose more of the heated metal surface to the air, essentially enlarging the conical heat pipe diameter at the open end of the thermal cone. This option is not really available in a high-density converter because by definition, the high-density module footprint is probably small.
- Blow air across the baseplate or metal surfaces of the case. The additional air turbulence at the metal surface speeds up the heat removal process by enlarging the cone’s large-end diameter. With converters, the degree of cooling for specific air speeds and area for the metal surface has been characterized. Typically, an air speed of 200 linear feet per minute (lfm), readily achieved with standard fans, is desired across the heat surface or heat sink fins in order to achieve substantial cooling. Air speeds much above 400-500 lfm are usually difficult to achieve in constricted areas and at the same time become marginally effective in removing much more heat.
- Attach the case to a larger metal surface (spreading the heat) to expose more surface area to the surrounding air (similar to item 1). Often, this is not feasible unless there is a large aluminium chassis to which the unit can be attached.
- Attach the baseplate to a finned heat sink across which air is blown. In the presence of air flow, the extra surface of the fins just like additional external unfinned metal surface area, as in item 3, but confines the extra within a more compact volume. It is important to understand that fins do not have much effect unless there is airflow in the direction of the fins. Cooling with finned heat sinks is generally the most effective practical cooling scheme for converters. For a given air flow, one-inch-high fins can double the cooling effect over a baseplate without fins.
Fin spacing, fin height, air speed and air direction all contribute to the final effectiveness. A common mistake by designers is to dwell on the cubic-feet-per-minute (cfm) rating of fans when making assumptions about system cooling. The cfm of the fan tells us about the volume of air that is to pass immediately over the surface of the hot metal surface. It is the speed in linear feet per minute that is important.
A small fan, in a creative configuration with a finned heat sink, can dramatically outperform a large fan with a poorly thought-out fin arrangement. In the same way a small battery-operated hand-held fan six inches from one’s face can cool far better than a giant fan 50 feet away.
An infinite number of possible schemes can be conceptualized, but there are a number of basic finned heat sink configurations, which, if used conservatively, will ensure proper cooling.
In cooling a converter, it is always understood that system assembly practices, unexpected changes in available air, or ambient temperatures may result in the converter being cooled a little less optimally than thought. Nevertheless, using the recommended finned heat sinks will prevent catastrophic failures under normal conditions.
Heat Sink Types
Heat sinks for the popular “half brick and “full brick” converter configurations are available from several vendors for what is called “longitudinal” air flow (along the same axis as the input-to-output power flow) or “lateral” air flow (across the unit). Fig. 3 shows a finned heat sink for longitudinal airflow and Fig. 4 shows a finned heat sink for lateral flow. That is, fins for lateral or longitudinal air flow are 90 degrees apart in terms of the flow axis. This means that fins must line up with airflow direction in order to be effective.
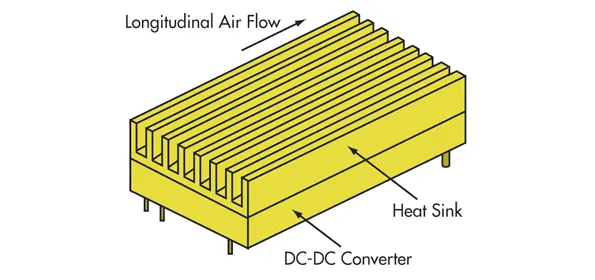
Fig 3. Finned heat sink for longitudinal airflow.
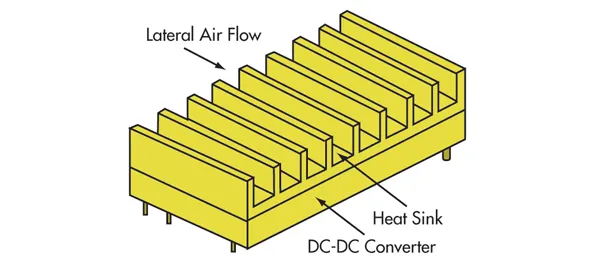
Fig. 4. Finned heat sink for lateral airflow.
It is always important to have either thermal grease or a thin, thermally conductive, compliant material (thermal gap filler) between the heat sink and converter baseplate. Compliance allows the material to fill in surface irregularities. The greater the mismatch in flatness between the converter and the heat sink, the thicker the compliant material must be.
The most popular options are as follows.
- Thermal grease is excellent for mating relatively flat surfaces and even some poorly matched surfaces (as long as there is a very thick layer of grease). Their disadvantage is that it is fairly messy and time consuming to get it right.
- Thin (0.002-0.003-in.) aluminium foil with or without thin paraffin coating on both sides. The wax coating enhances the filling in of “micro” surface irregularities. Its disadvantage is that aluminium can sometimes develop “wrinkles” that adversely affect mating and heat transfer. Also, this approach means that there are two metal-to-compliant material interfaces. Every interface is, to a degree, an impediment to heat transfer.
- Same as item 2, but the coating is on a thin layer of insulation typically a special (more thermally conductive) type of Kapton so that electrical isolation is also provided. Its disadvantage is that it is not as thermally effective as item 2.
- Silicone-type elastomer materials are available from a number of suppliers. Typically used 0.005-0.012-in. thickness, they are among the most popular converter-to-heat sink thermal interface materials. Although easy to use, with no mess, they are not as good as grease or waxed aluminium, but are often acceptable. Generally, they are preferred when there is some doubt about the relative flatness of the surfaces. Their disadvantage is that their thermal resistance is pressure dependent so care must be taken in the assembly process or unexpected failures can occur in power semiconductors operating close to their rated limits.
- Very thick silicone elastomers (0.020-0.030-in. thickness or more) are designed for a poorly matched surface where simple where mounting would result in large air gaps and extremely poor heat transfer. A disadvantage is relatively poor heat transfer, but better than air.
- “Change of state” or “phase change” materials are specifically formulated thin paraffin layers identical to the coating on items 3 and 4, except that the paraffin is processed as a thin paper-like material, not as a coating. These materials are available from several firms in sheet form or as die-cut shapes. When placed between two metal surfaces, the material melts at a pre-determined temperature (typically 60-70 C) and fills in the “micro cracks” between the metal surfaces in a near ideal manner. Once the first melting occurs, the interface material is almost perfectly compliant thereafter. When two flat metal surfaces are involved, this method is second to none other than metallic bonding (such as soldering) of two surfaces involved in heat transfer.
- Thin, graphite-based films. These are increasingly popular select small-area applications, such as with chip-on-board (COB) LED arrays, since they exhibit excellent thermal resistance properties without much need for mounting pressures.
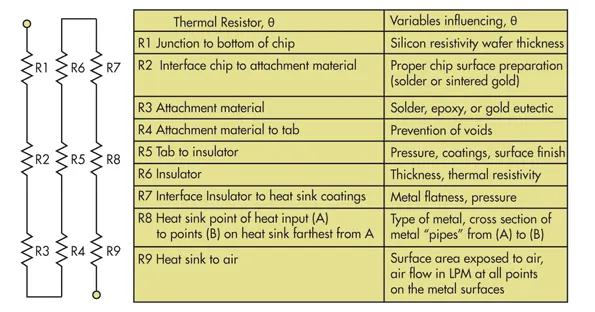
Fig. 5. Thermal resistance: chip to air.
There are some guidelines designers should keep in mind when designing a cooling system and choosing the type of thermal interface. The first rule is not to forget the thermal circuit of Fig. 5. The tiniest chip could handle thousands of watts if it were not for the many thermal “resistors” between it and the external air. Knowing the techniques and associated cost and difficulty of reducing these “resistor” values is the key to success. (In Fig. 5, for an LED system, one might add an R7A and R7B for the added metal core PC board and its mounting interface material).
The second rule is to know which interface materials are most appropriate for a particular application. Fig. 6 shows a converter module/heat sink configuration that could typically represent 10 or more square inches of surface area. Depending on whether the heat sink surface is that of a stamped, extruded or precision-milled metal surface, each of the two mating surfaces might have undulations that vary 0.010-in. over the complete area, resulting in gaps as much as 0.020-in. Admittedly, this is a worst-case scenario, but it does happen.
Such air gaps could guarantee failure during overheating of the module. In such cases, a thick elastomer interface material, while not a particularly good thermal conductor (but operating better than air (but operating in the large diameter end of the “cone”) is still dramatically better than air (Table 1). There might be some reduction in module capability, but reasonable performance can still be obtained.
Employing an interface material under the TO-220 tab is another matter (Fig. 6). Here, the relative undulations, across an area well under one square inch, will be minimal. The “micro” surface irregularities begin to dominate, and we are in the small diameter of the cone. What are needed are the thinnest possible material and the maximum filling of the “micro voids.” 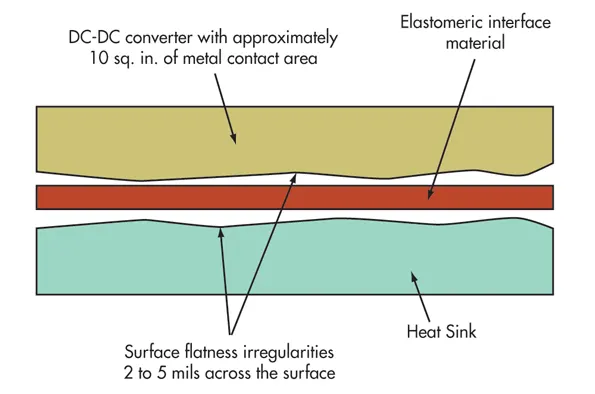
Fig. 6. Small area thermal interface.
Other than soldering, little is better than the thermal grease or thin phase-change material and substantial pressure so that these materials can flow into the void and eliminate every cubic micron of air space. For this reason, a very thin, coated insulator is likely to be very effective as an insulator/heat conduction for a small area, and a thick, compliant elastomer material can be very effective if the heat can first be spread to a larger area.
Compressing the interface material (pad, grease, waxed aluminium, or 100% paraffin) ensures that it does the job for which it is intended: helping to fill in of any surface irregularities or flatness variations that could impede heat transfer. At higher power, even a thousandth of an inch of air space can dramatically affect maximum rating power capability.
Finally, mention should be made of other insulating materials historically found in military and some industrial applications. Aluminium oxide (Al2O3), beryllium oxide (BeO) and aluminium nitride are superior to plastic type materials but usually require a more sophisticated approach to assembly and therefore typically reflect additional cost. More recently a technology known as insulated metal substrate (IMS) has gained some popularity in dc-dc converters. The IMS approach involves a copper foil/polyimide (plastic/aluminium) laminate to achieve electrical isolation and thermal conductivity. This process can have additional cost, manufacturing nuances and capacitance considerations, but if applied appropriately, it can provide excellent results. Regardless of the approach taken, the heat must travel from its source through many materials and interfaces as noted.
To calculate how much power is dissipated in the converter, input voltage, output power together with DC/DC converter efficiency must be known.
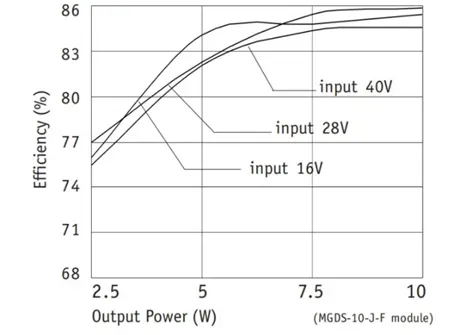
Fig. Typical Efficiency Vs. Load at various input
Example: - The power dissipated in this MGDS module at 28Vdc input voltage & used at full load power 10 W is -
The efficiency of this module at full load 10W & 28Vdc input voltage is 86%.
The power dissipation is the function of the power used & DC/DC converter efficiency.
P-Dissipation = (P-used/efficiency – P-used)
In this example we find P-Dissipation = 1.6 W.
The power dissipated is transformed into heat.
Heat Transfer –
The primary gaol in the thermal design is to predict and control the converter’s heat so that it doesn’t exceed the maximum rating of temperature admissible by the DC/DC converter.
Eat energy is transferred from regions of high temperature to regions of low temperature via three basic mechanisms –
Radiation – Electromagnetic transfer of heat between masses at different temperatures.
Conduction – Transfer of heat through a solid medium (For e.g. – Heat Sink).
Convection – Transfer of heat through the medium of fluid (Typically air from ventilation).
All three of these heat transfer mechanisms are active to some degree in every application. All three of these mechanisms should be given consideration when developing thermal management systems.
- Radiation Transfer –
Thermal radiation is transfer of heat by electromagnetic radiation (Primarily in the infra-red wavelengths). Radiation is the only means of heat transfer between bodies separated by a complete space vacuum. Many factors contribute to thermal radiation efficiency, such as temperature differentials, surface area & Surface emissivity.
Black anodized aluminium is a good thermal medium to take advantage of radiated heat.
A heatsink with a large area for a given volume will take maximum advantage of radiation. But radiation is minor contributor to the overall thermal link in most power converter applications and counts in majority of cases for less than 5% of total heat transfer. It is best to use the effects of radiation as a safety margin in the thermal design, since its contributions to heat transfer will normally be small & is difficult to quantify & requires relatively larger heatsink area to be efficient.
- Conduction Transfer -
Heat is transferred through a solid medium by conduction and it is most fundamental of all thermal mechanisms. Thermal conduction can be understood as analogue as conduction of electrical current in a wire. As the electrical current in a wire is a function of the different electrical current resistances and voltage drop, the thermal transfer is a function of the different thermal resistances and temperature drop from one point to another.
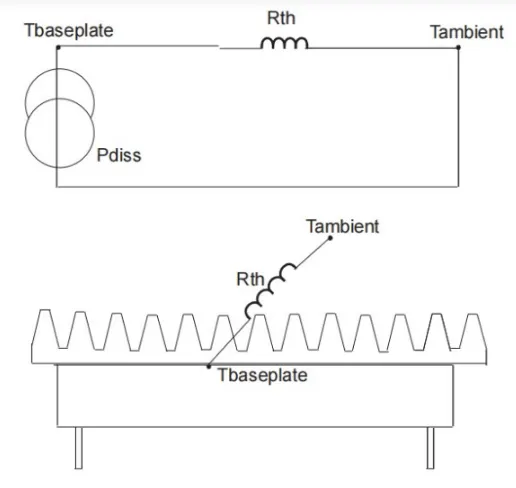
Fig – Thermal Resistance for Heatsink, DC/DC Converter
The thermal resistivity of a uniform conducting membrane can be defined as – Rth = L/K*A
Where,
Rth = Thermal Resistance (Degree Celsius/Watt).
L = Length or width (Inch or mm).
A = Cross Sectional Area (Inch2 or mm2).
K = Material Thermal Conductivity (Watt/inch degree Celsius or mm degree Celsius).
- Convection Transfer -
Heat transfer by convection (Natural or Forced) involves the transfer of heat to a surrounding fluid by conduction, typically air. This mode of heat transfer is dependent on a number of variables and is somewhat complex to calculate. Surface area, Temperature Gradient, Thermal conductivity, of fluid (Air), Velocity of fluid (Air) density & other variables affect convection.
Natural Convection –
Natural convection is sometimes also referred as free convection. Natural convection is easier to implement than forced convection, but at the expense of increased thermal resistance.
Natural convection produces its own air velocity. due to the local heating of air at the heatsink surface. The air density is reduced when heated. Causing it to rise, thus causing the air movement. Natural convection is not as effective at higher altitudes due to air density reduction. Free air movement across a thermal dissipater is required to perform adequately. Confined air would not conduct natural convection & the following rules apply –
- Mount heat sinks so the max. length of convection surfaces (Fins) are in the vertical plane.
- Place the heat sink above the converter, allowing air to rise above.
- Provide sufficient enclosure ventilation for natural convection of the air.
- Note that heatsink fin spacing will reduce the effectiveness of the heatsink.
- Due to complexity to calculate heat transfer for only free air convection, majority of DC/DC converter manufacturers are given their thermal resistance performances in free air convection condition (which will include conduction and natural convection).
Forced Convection
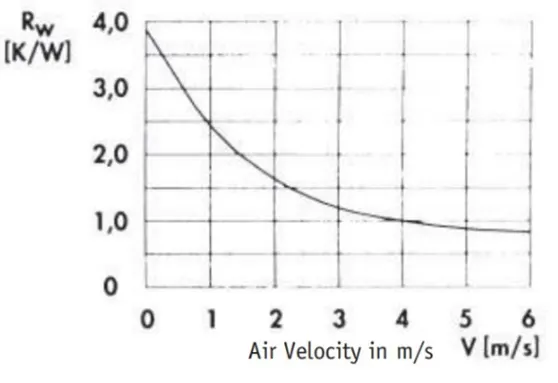
Fig – Thermal resistance as a function of air velocity
Forced convection implies the use of fans to increase the air movement across the heatsink area. Heatsink to air thermal resistivity can be improved by a factor of 10 when compared to natural convection. This may be the way to go when operating at high ambient temperatures, operating at high power levels, or when space is at premium. Of course fans are not without their problems as they are noisy and in dirty environments they often require filters. They can also cause an unreliable power system if the filters are not changed frequently or the fan itself fails. Therefore, proper care must be exercised when fans are used.
- Refer the Tesla Thermal Management System and estimate thermal management system power requirement.
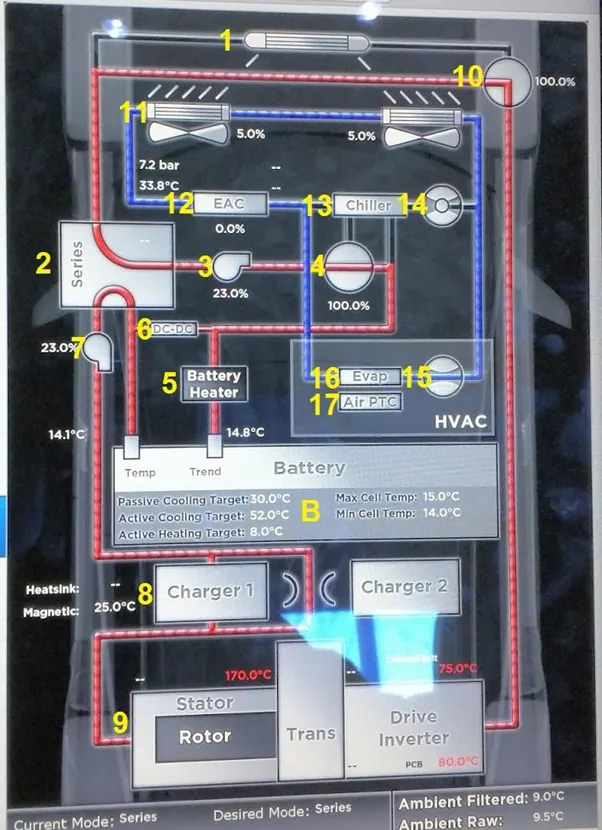
Systems Functions –
- Cooling –
Due to inefficiency, battery cells will not only generate electricity but also heat. This heat should be moved from the battery pack when battery temperature reaches the optimum temperature or even in advance. Thus, a cooling function is required in BTMS.
- Heating -
In cold climates, battery pack temperature probably falls below the lower temperature limit. Hence, a heating function, such as PTC heater, is required to assist the battery pack to reach the proper temperature range in a shorter time.
- Insulation –
In extreme cold or hot weather, the temperature difference between the inside and outside of the battery pack is much larger than that in mild weather. Battery temperature will thus fall (cold) or rise (hot) sooner out of the proper temperature range. To prevent this, good insulation can slow down the falling or rising of battery temperature, especially when the vehicle is parked outdoors.
- Ventilation –
Ventilation is required to exhaust the hazardous gases within battery pack. In some systems, such as air systems, this function is combined with cooling and heating functions.
Technologies of BTMS –
Forced air systems (passive and active).
Forced air system with heat recovery.
Passive liquid cooling system.
Active liquid cooling system.
Direct refrigerant cooling system.
Thermoelectric cooling/heating system.
Combined Colling Systems –
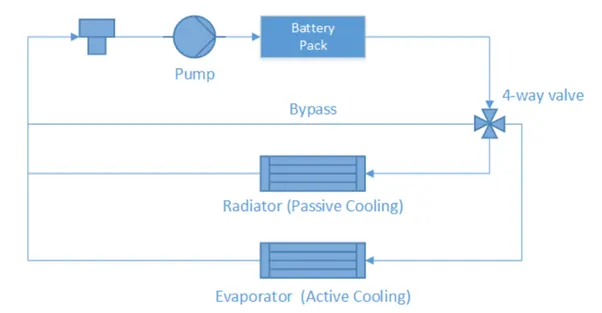
The first is the liquid cooling system, which has four working modes: bypass with heater working; bypass without heater working; passive cooling system; and active cooling system.The cooling system takes advantage of both passive cooling system and active cooling system. Passive cooling system has simple structure and is able to dissipate heat under normal conditions with low energy consumption. Under extreme condition, active cooling system has good thermal performance to keep battery temperature in the required range.
- Initial inputs and thermal cycles settings –
Starting with the battery unit, physical parameters such as thermal capacity and mass were defined as fixed parameters. When the PCM is located close to the battery cell, these two parts could be treated as one integrated part. Thus the PCM in this case could be considered a part within the battery unit. Focusing on the thermal issues of the battery pack, there are two main parts of heat transfer flows that influenced the battery temperature. One was the heat generation internally. This part depended on driving behaviour, battery features and other vehicle parameters, such as vehicle mass and aerodynamic performance. Since this thesis focused on thermal rather than electro-thermal issues, this interior heat was generated by exterior electro-thermal model. The other part was the external heat dissipation. This part of the heat was from the different thermal cycles which took away certain amounts of heat from the battery or in some cases brought heat to the battery. The amount of heat depended both on which thermal cycle was chosen and surrounding thermal conditions. Therefore, some parameters were collected from the battery unit and testing conditions for calculation. After this step the required battery thermal model was built.
- Control strategy development –
Normally, there are more than two thermal cycles designed in battery thermal models. To decide which cycle to operate, some characteristic parameters were required, such as battery temperature and ambient temperature. According to these parameters, an operation state was chosen. The state corresponding to the thermal cycle that was active and some related components, for example, the pump would change their operating state as well. In some cases a sub-state under the main operation state could be introduced in order to achieve better operation feature.
- Simplification and decoupling –
Some complex calculation cases would give endless loops thus a simplified or approximate calculation method should be adopted to solve the endless loops and to accelerate the simulation. In other cases, decoupling was an alternative solution. For example, the activated thermal cycle consumes electricity, causing additional load and consequently additional heat. This coupling between the thermal model and electro-thermal model would cause unexpected programming issues. Thus, it was better to decouple these two models at the beginning and connect them later when both of them worked well.
- Data process and output –
Not all output parameters were meaningful. Only parameters which represented the outcome of the model were recorded. Some raw data was processed into performance parameters in order to evaluate different results with a common standard. For a better visual understanding, some figures were also plotted based on numerical data.
Modelling Parameters -
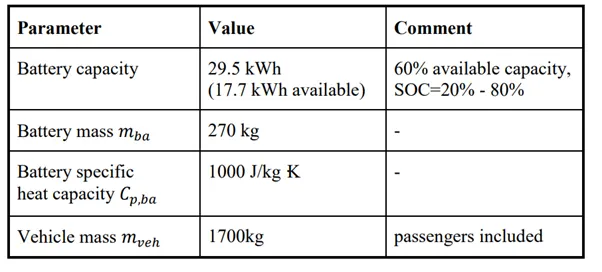
Also, a few parameters varied in order to represent different situations. The most important variable parameters were:
- Ambient temperature (𝑻𝒂𝒎𝒃) -
This temperature represented the climate conditions of the atmosphere around the driving vehicle. When it ranged from -20°C to 10°C, it was considered to be a cold climate. When it ranged from 10°C to 20°C, it was considered to be a mild climate. When it ranged from 20°C to 40°C, it was considered to be a hot climate.
- Battery initial temperature (𝑻𝒃𝒂,𝒊𝒏𝒊) -
It’s normally considered that battery initial temperature is exactly equal to ambient temperature. But when pre-conditioning is applied, these two temperatures are not the same. Battery initial temperature is higher than ambient temperature when the battery is pre-heated in a cold climate. Battery initial temperature is lower than ambient temperature when the battery is pre-cooled in a hot climate. Different levels of pre-conditioning could be adopted.
- Desired temperature (𝑻𝒅𝒆𝒔) -
The desired temperature represents the temperature that the control unit of the BTMS aims for, i.e. the optimum operating temperature point stated by the manufacturer. With different thermal cycles the BTMS will try to control battery temperature as close as possible to the desired temperature. In most cases of this work 𝑇𝑑𝑒𝑠 is 25°C, but some special cases with 𝑇𝑑𝑒𝑠= 20°C were also tested.
- Testing driving cycle -
this model focuses more on the BTMS feature during driving. Two driving cycles were chosen to represent two different driving behaviours: One was US06 whose vehicle speed profile. This driving cycle lasts 596 seconds per single cycle. It has an aggressive driving behaviour with maximal speed of 129 kph and an average speed of 77.9 kph. The other is the NEDC (New European Driving Cycle) representing a mild driving behaviour. It lasts 1180 seconds per single cycle with maximal speed of 120 kph and an average speed of 33.9 kph. For testing, each was chosen as a testing condition input and the vehicle was driven following the speed profile until the available battery capacity (17.7 kWh) was exhausted. This complete cycle is called Testing Driving Cycle (TDC) which consisted of several driving cycles. The whole TDC NEDC lasted 16229 seconds and TDC US06 5139 seconds. According to the different TDC, the corresponding heat generation rate profile was calculated through exterior electro-thermal model and the profile of the NEDC. Another heat generation rate profile by US06 was generated in the same way.
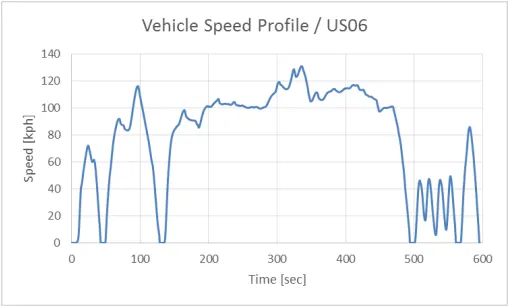
Figure - Vehicle speed profile of driving cycle US06.
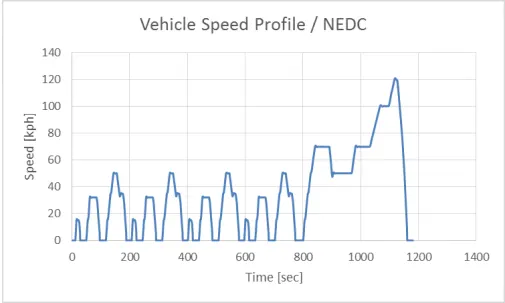
Figure - Vehicle speed profile of driving cycle NEDC.
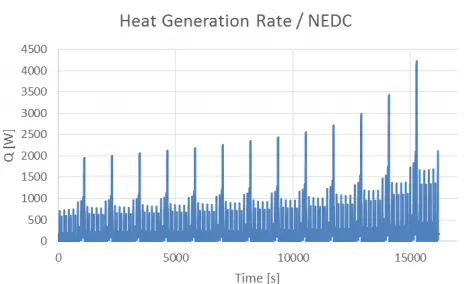
Figure - Heat generation rate profile of NEDC
CLS Model Based on the system layout of, a MATLAB/Simulink model was developed following the four steps mentioned at the beginning of this chapter. A basic model layout is shown in the following Figure. In the basic layout, the temperature flow of heat transfer fluid connects the main parts together. In initial step, testing data was loaded. Then starting with the battery unit the fluid was heated up. Afterwards, the fluid flows through different parts, but only one outcome was chosen by control unit. The flow rate of the pump was also governed by control unit. Lastly, the coolant returned to battery pack. This calculation process was repeated until the driving cycle ended.
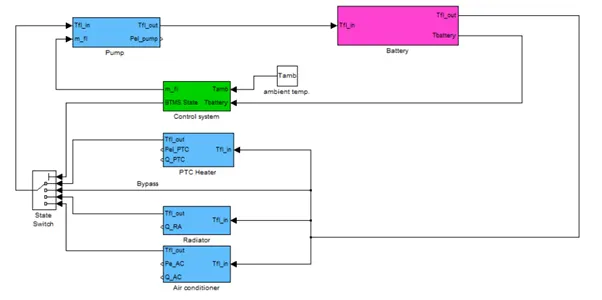
Figure - Basic Simulink model layout for CLS
Battery Unit It was assumed that the parts of battery cells were homogeneous and the interior heat conductivity between cells approaches infinity so that the heat transferred between cells very quickly and that all points on the battery cells had the same temperature, called battery temperature 𝑇𝑏𝑎. The differential of battery temperature over time is stated with the following equation:
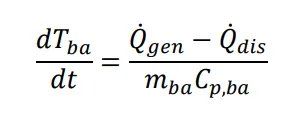
𝑄̇ 𝑔𝑒𝑛 and 𝑄̇ 𝑑𝑖𝑠 states respectively heat generation rate and heat dissipation rate. The former is set up by the program interior signal generator or by heat generation rate profile of either US06 or NEDC. This heat represents the heat generated through battery electro-thermal effects. The later one was calculated by sub-system of the battery unit, which is expressed in Equation. This heat represents the heat dissipated through thermal cycle(s). The value is positive when thermal cycle is in cooling operation. The value is negative when thermal cycle is in heating operation. 𝑚𝑏𝑎 and 𝐶𝑝, 𝑏𝑎 is battery mass and specific heat capacity of battery in the battery pack, three discrete copper tubes are jointed very closely to the battery cells in order to transfer heat to and from the battery. Overall heat transfer co-efficient 𝑈 will be. 𝐴 represents the contact area which is the total inner area of the three tubes. 𝑇ft. − 𝑇𝑏𝑎 represents the approximate mean temperature difference. 𝑇ft. is the mean temperature of fluid inlet and outlet temperature.
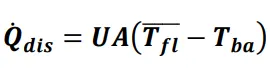
Air Conditioner (Active Cooling) –
When heat transfer fluid flows through air conditioner, the fluid temperature differential is expressed as the following equation -
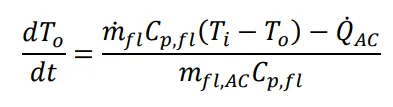
The air conditioner always takes heat from the fluid, thus 𝑞̇ is always negative. Here 𝑞̇ is replaced by −𝑄̇ 𝐴𝐶 where 𝑄̇ 𝐴𝐶 means cooling load of air condition and is always positive. 𝑄̇ 𝐴𝐶 can be calculated by the following equation:
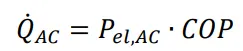
𝑃𝑒𝑙, 𝐴𝐶 is the electricity consumption by air conditioner and COP is Co-efficient of Performance which is dependent on working condition of air conditioner.
Radiator (Passive Cooling) –
Similar to the air conditioner, the fluid temperature differential in the radiator can be expressed as:
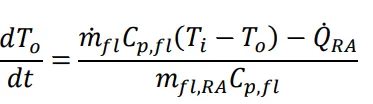
Where 𝑄̇𝑅𝐴 is the product of overall heat transfer co-efficient, contact area and temperature difference of inlet fluid temperature and ambient temperature:
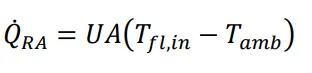
and the product 𝑈𝐴 is given by the technical performance maps of the chosen radiator. It is expressed as a function of fluid mass flow rate and air flow rate:
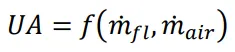
In other expression, 𝑄̇𝑅𝐴 is decided by temperature difference between fluid and ambient, fluid mass flow rate and air flow rate these three terms:
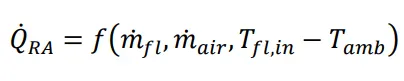
PTC Heater (Heating) –
Heater energy balance equation is expressed as:
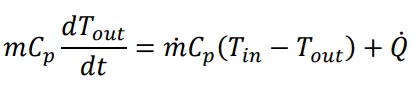
where 𝑄̇ is the heat provided by heater, 𝑇𝑖𝑛, 𝑇𝑜𝑢𝑡 is the temperature of coolant in and out, 𝑚̇ is the coolant mass flow rate, 𝑚 is the coolant mass in tubes. PTC heater is widely used as an electrical vehicle heater and it has two main characteristics
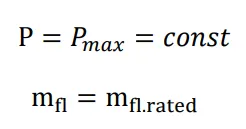
Where the heater power P is always equal to the maximum heater power𝑃𝑚𝑎𝑥, the mass of flow rate mfl is constant.
Pump –
The electrical energy consumption of the pump is expressed as the following:
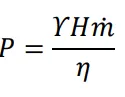
where the specific gravity 𝛶 is the multiplication of the coolant density and gravity and expressed as:
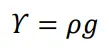
where 𝑚̇ is the mass flow rate, 𝜂 is the efficiency of the pump, 𝐻 is the total head and is related to the mass flow rate 𝑚̇,
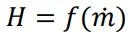
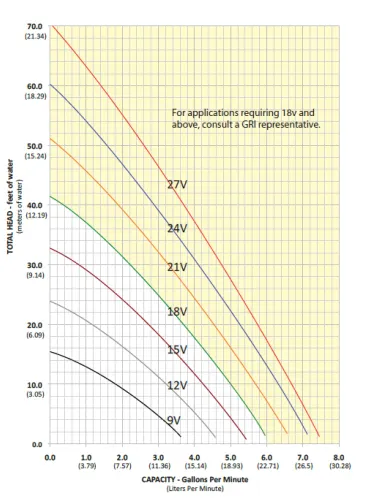
Figure -The relationship between flow rate and total head
The Figure shows the water pump performance and for other viscous coolant the correction is used to determine the performance
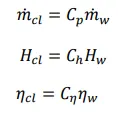
where 𝐶𝑝, 𝐶ℎ, 𝐶𝜂 are capacity correction factor, head correction factor and efficiency correction factor respectively. Due to the low viscosity and similarity to water of the coolant, the correction factors are chosen as:
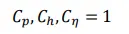
Control Unit Generally, a complex on-off control strategy is applied. Here three on-off controllers with different switching temperatures create four states and each state matches some operation modus. Controller I controls the switching between State 1(Heating) and State 2(Bypass). Controller II controls the switching between State 2 and State 3(Passive cooling). Controller III controls the switching between State 3 and State 4(Active cooling).
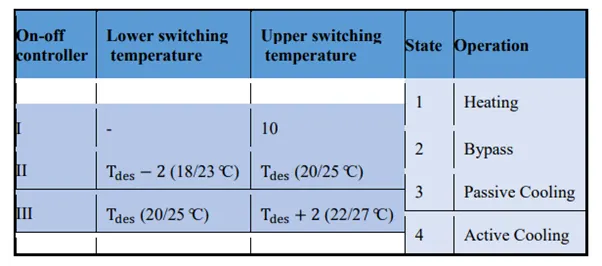
Table - Switching points of three on-off controllers (Tdes=20/25°C)
Note that, for controller I, there is no lower switching temperature or the lower switching temperature is the same as the upper switching temperature of 10°C. The reason to set up this on-off controller is to heat the battery with the PTC heater when the battery is below the lower temperature limit of 10°C and to switch the state into 2 (Bypass) when battery is heated up above 10°C. Since the focus is the driving cycle and the cooling load from ambient is negligible, the battery temperature will not drop below 10°C again after it has been above 10°C. Thus, the lower switching temperature is invalid here. For controller II and III, variable switching points are introduced in order to create a flexible control strategy. However, Tdes is set to 25°C in most cases. Only in a few cases Tdes was set to 20°C. Besides the basic strategy described above, there are two improvements for better performance: 1. Forced switching to active cooling There is one exceptional situation which the control unit has to face. It is that the ambient temperature is higher than desired temperature. In this case the passive cooling is invalid and even has a negative effort i.e. bringing heat to the battery. Thus, the state of passive cooling should be forced to switch to active cooling when ambient temperature is higher than Tdes − 4K. The reason to set this temperature point is that the radiator operates when battery temperature is from Tdes until to Tdes − 2𝐾. To make passive cooling efficient, a temperature difference between the battery and ambient temperature of an extra 2K is needed. Thus, the ambient temperature should below than Tdes − 4K (Tdes − 2K − 2K) to make sure that passive cooling works properly and efficiently.
Sub-states during active cooling Another improvement of control unit is achieved by dividing active cooling into three sub-levels. The higher the battery temperature, the more powerful the active cooling is. The switching points of the controller are shown in Table. With this improvement, electricity could be further saved when battery temperature is low and cooling is not so urgently required. Moreover, a high AC level offers more powerful cooling and ensures safety during high battery temperature.
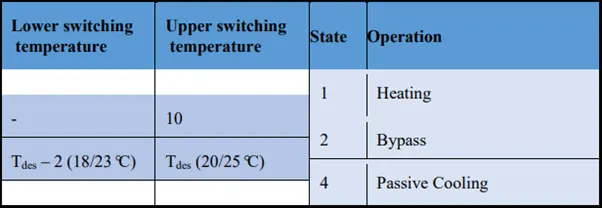
Table - Control strategy for the high ambient temperature (Tdes=20/25°C).
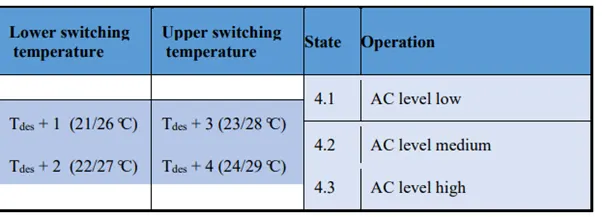
Table - Sub-states of active cooling (Tdes=20/25°C).