Week 3 - Solving second order ODEs
Aim : Solve ODE equation of motion of a simple pendulum with damping using matlab.
Governing equation: Equation of motion of a simple pendulum with damping:
d^2theta/dt^2 + b/m*dtheta/dt +g/L*sintheta = 0
where,
b = Damping coefficient
m = Mass of pendulum bob
L = Length of pendulum
g = Gravity
Code:
Ode_func code:
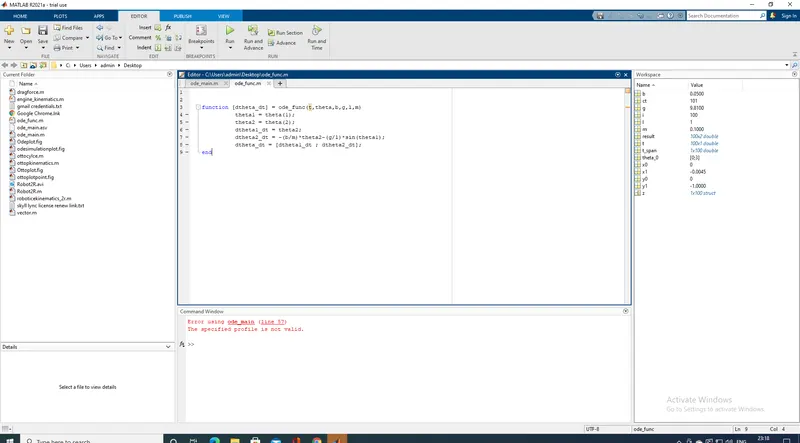
function [dtheta_dt] = ode_func(t,theta,b,g,l,m)
          theta1 = theta(1);
          theta2 = theta(2);
          dtheta1_dt = theta2;
          dtheta2_dt = -(b/m)*theta2-(g/l)*sin(theta1);
          dtheta_dt = [dtheta1_dt ; dtheta2_dt];
end
Main_ODE code:
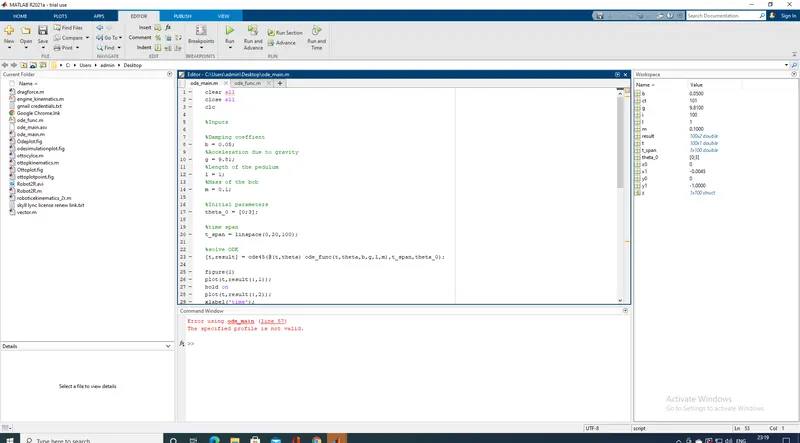
clear all
close all
clc

%Inputs

%Damping coeffient
b = 0.05;
%Acceleration due to gravity
g = 9.81;
%Length of the pedulum
l = 1;
%Mass of the bob
m = 0.1;

%Initial parameters
theta_0 = [0;3];

%time span
t_span = linspace(0,20,100);

%solve ODE
[t,result] = ode45(@(t,theta) ode_func(t,theta,b,g,l,m),t_span,theta_0);

figure(1)
plot(t,result(:,1));
hold on
plot(t,result(:,2));
xlabel('time');
ylabel('plot');

%Loop for animation

ct = 1;
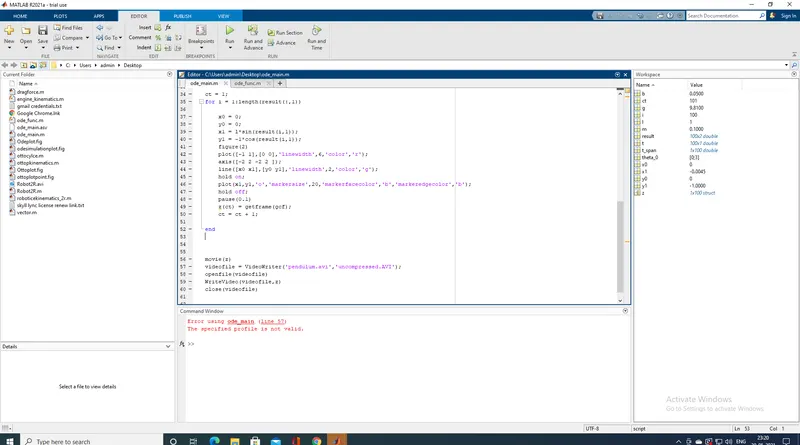
for i = 1:length(result(:,1))

    x0 = 0;
    y0 = 0;
    x1 = l*sin(result(i,1));
    y1 = -1*cos(result(i,1));
    figure(2)
    plot([-1 1],[0 0],'linewidth',6,'color','r');
    axis([-2 2 -2 2 ]);
    line([x0 x1],[y0 y1],'linewidth',2,'color','g');
    hold on;
    plot(x1,y1,'o','markersize',20,'markerfacecolor','b','markeredgecolor','b');
    hold off;
    pause(0.1)
    z(ct) = getframe(gcf);
    ct = ct + 1;

end


movie(z)
videofile = VideoWriter('pendulum.avi','uncompressed.AVI');
openfile(videofile)
WriteVideo(videofile,z)
close(videofile)
Matlab Execution:
 c
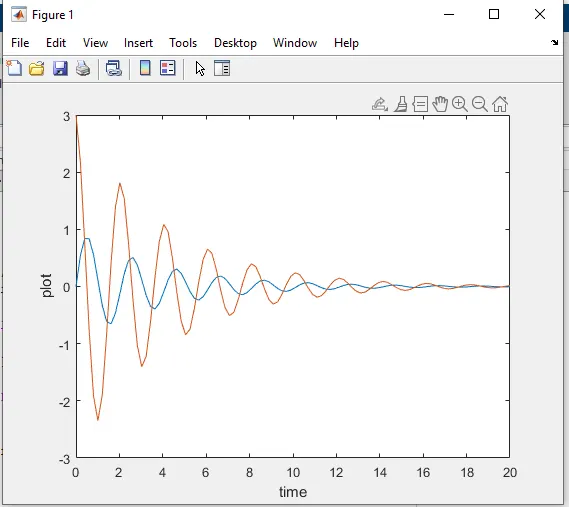
Graph:
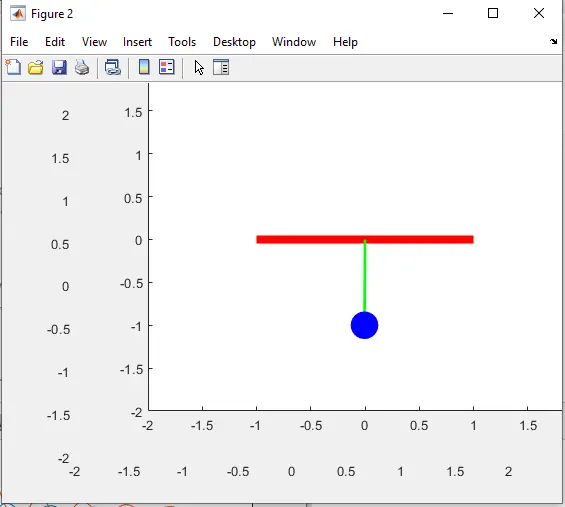
Result :
Finally we have solved the motion of a simple pendulum with damping ODE and funcion and plot the graph and simulation of the pendulum.