Week 2- 2R Robotic Arm Challenge
% Foward Kinematics of a 2R Robotic Arm Manipulator
clear all
close all
clc
% Inputs
l1 = 2;
l2 = 5;
theta1 = 40;
theta2 = 30;
%coordinates
x0 = 0;
y0 = 0;
x1 = l1*cosd(theta1);
y1 = l1*sind(theta1);
x2 = x1 + l2*cosd(theta2);
y2 = y1 + 12*sind(theta2);
%plotting
line([x0 x1],[y0 y1],'linewidth',3,'color','b')
line([x1 x2],[y1 y2],'linewidth',3,'color','r')
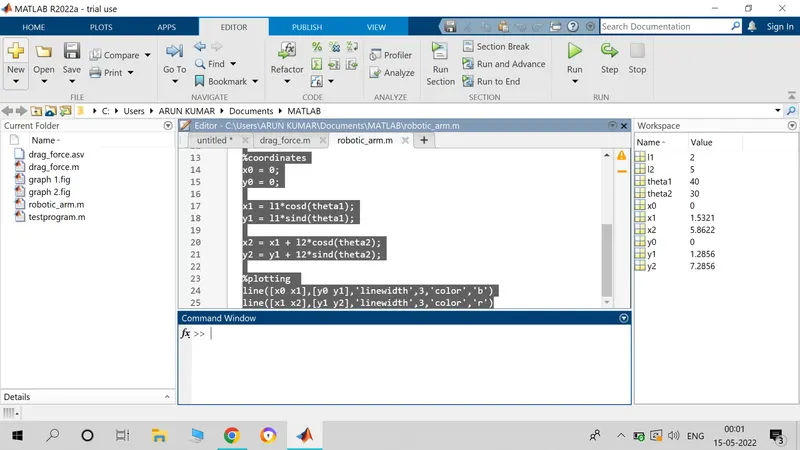
% Foward Kinematics of a 2R Robotic Arm Manipulator
clear all
close all
clc
% Inputs
l1 = 2;
l2 = 5;
theta1 = 40;
theta2 = 30;
%coordinates
x0 = 0;
y0 = 0;
x1 = l1*cosd(theta1);
y1 = l1*sind(theta1);
x2 = x1 + l2*cosd(theta2);
y2 = y1 + 12*sind(theta2);
%plotting
line([x0 x1],[y0 y1],'linewidth',3,'color','b')
line([x1 x2],[y1 y2],'linewidth',3,'color','r')