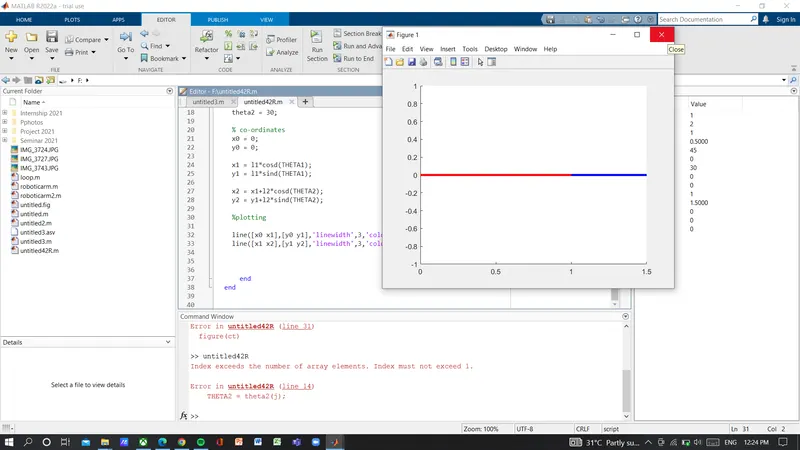
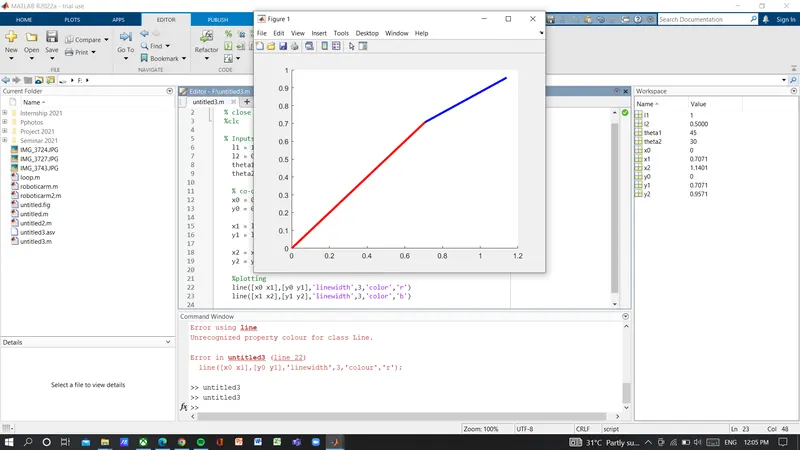
AIM:
Write a program in Matlab to simulate the forward kinematics of a 2R Robotic Arm

OBJECTIVES:
To get a exact valves of eacg position of the robotic arm

BODY OF THE PROGRAM:

%clear all
% close al
%clc

% inputs
l1=1;
l2= 0.5;
theta1 = linspace(0,90,4);
theta2 = linspace(0,90,4);

ct=1;
for i = 1:length(theta1)
    THETA1 = theta1(i);
    for j = 1:length(theta2)
    THETA2 = theta2(j);
  x0 = 0;
  y0 = 0;

  x1 = l1*cosd(THETA1);
  y1 = l1*sind(THETA1);

  x2 = x1+l2*cosd(THETA2);
  y2 = y1+l2*sind(THETA2);

  %plotting

  line([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
  axix([-0.1 1.5 0 1.5])
  pause(0.1)
  ct=ct+1;


    end
end