Week 2- 2R Robotic Arm Challenge
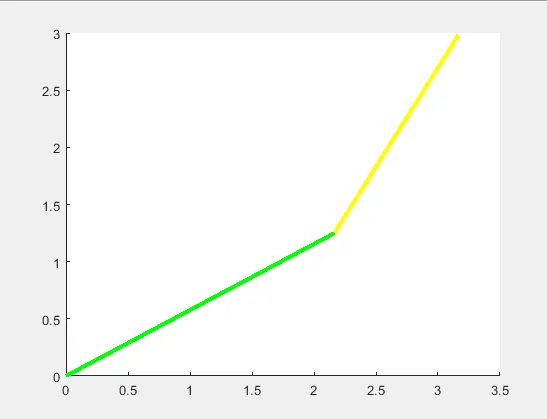
for kinamatics robotic arm i have used l1 as link-1 and l2 as link-2. theta-1 taken as starting point angle in x-axis and theta-2 taken as link-1 another end in x-axis and calculate the position of link-1 and link-2
% forward kinamatics of a robotic arm
clear all
 close all
 clc

 %inputs of L & theta
 l1 = 2.5;
 l2 = 2;

 theta1 = 30;
 theta2 = 60;
 %coordinates for the X&Y
 x0 = 0;
 y0 = 0;

 x1 = l1*cosd(theta1);
 y1 = l1*sind(theta1);

 x2 = x1 + l2*cosd(theta2);
 y2 = y1 + l2*sind(theta2);

 %plotting of line 1 & 2
 line([x0 x1], [y0 y1], 'linewidth', 3 ,'color', 'g')
 line([x1 x2], [y1 y2], 'linewidth', 3 ,'color', 'y')
clear all
close all
clc

% inputs of link-1,2 & theta-&2
l1 = 2.5;
l2 = 2;
theta1 = linspace(0,90,25);
theta2 = linspace(0,90,25);

ct=1
for i = 1:length(theta1)
    THETA1 = theta1(i);
    for j = 1:length(theta2)
        THETA2 = theta2(j);
        x0 = 0;
        y0 = 0;

        x1 = l1*cosd(THETA1);
        y1 = l1*sind(THETA1);

        x2 = x1 + l2*cosd(THETA2);
        y2 = y1 + l2*sind(THETA2);
        %plotting

        plot([x0 x1], [y0 y1], [x1 x2], [y1 y2], 'linewidth', 3 )
        axis([-1 3.5 0 3.5])
        pause(0.03)
        M(ct) = getframe(gcf);
       ct=ct+1


    end
end

movie(M)
videofile = videowriter('forward_kinamatics.avi','uncompressed avi');
open(videofile)
videowriter(videofile,M)
close(videofile)