Week 2- 2R Robotic Arm Challenge
% Robotic Arm Simulator using for loop

% inputs

l1 = 1;
l2 = 0.5;

theta1 = linspace(0,90,4);
theta2 = linspace(0,90,4);

% Initial counter
ct=1;
% Introducing for loop
for i= 1:length(theta1)
    THETA1 = theta1(i);
% For each value of theta1 for loop for theta2
    for j= 1:length(theta2)
        THETA2 = theta2(j);

% inputs
% Origin
x0 = 0;
y0 = 0;

% Cordinated of Arm 1
x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);

% Cordinates of Arm 2
x2 = x1+l2*cosd(THETA2);
y2 = y1+l2*sind(THETA2);

% Plotting Lines

plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3);

%Setting limits
axis([-0.1 1.5 0 1.5])


% Calling current frame
M(ct) = getframe(gcf);

% Incrementing Counter
ct = ct+1;

    end
end

% Generating movie
movie(M)
videofile = VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)

close(videofile)
Forward Kinematics of 2R Robot output
ERROR Faced
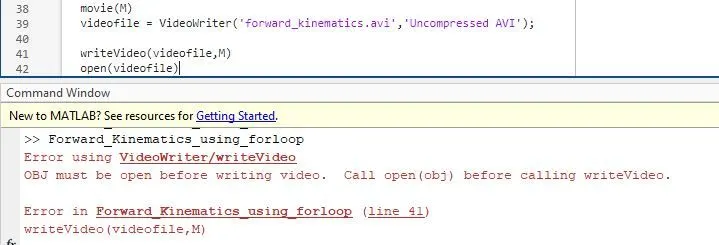
open(videofile) was types before writeVideo(videofile,M)
ERROR2
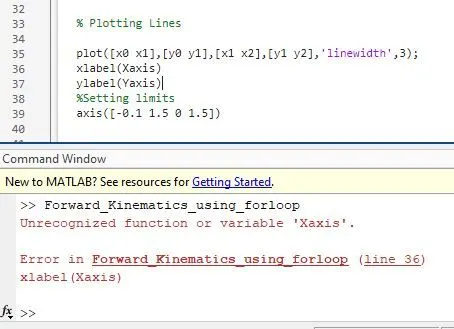
xlabel and ylabel not suitable for movies was removed from program