Week 2- 2R Robotic Arm Challenge
Program for 2R robotic arm is as follows
% inputs
l1 = 1;
l2 = 0.5;
theta1 = linspace(0,90,10)
theta2 = linspace(0,90,10)
for i = 1:length(theta1)
  THETA1 = theta1(i);
  for j = 1:length(theta2)
    THETA2 = theta2(j);
    x0 = 0;
    y0 = 0;

    x1 = l1*cosd(THETA1);
    y1 = l1*sind(THETA1);

    x2 = x1 + l2*cosd(THETA2);
    y2 = y1 + l2*sind(THETA2);

    %PLOTTING
    line([x0 x1],[y0 y1], 'linewidth',3,'color','b')
    line([x1 x2],[y1 y2], 'linewidth',3,'color','r')

  end
end
Screenshot of the programming and execution has been attached below:
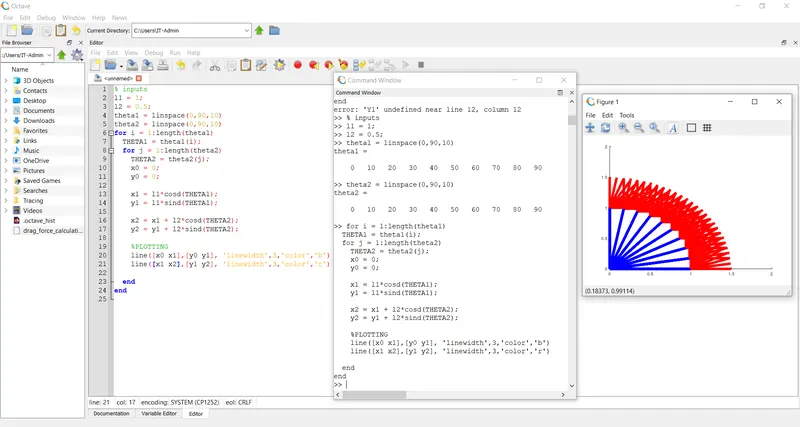
Answer:
In order to solve the problem for 2R robotic arm following steps i followed:
1.By taking the correct values and commands into consideration so that program can be executed without any error.
2.Important commands such as linspace,Theta values has to be entered without any false input or missing input.
3.In this program FOR loop was used in order to attain the desired output.