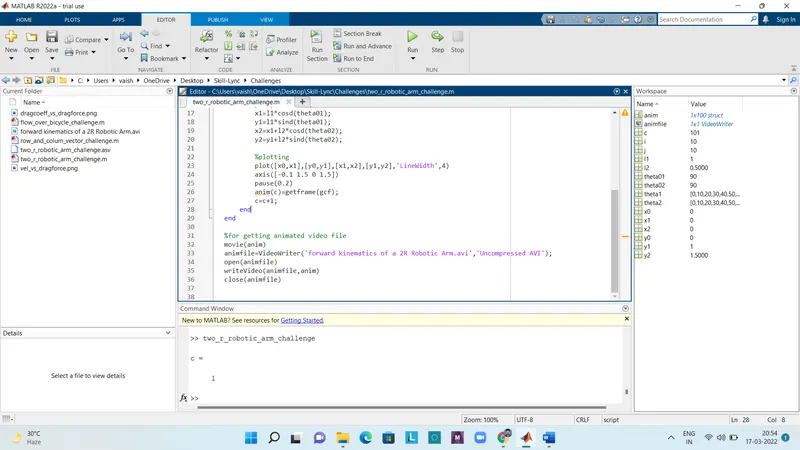
%program for simulation of forward kinematics of a 2R Robotic Arm

%inputs
l1=1;
l2=0.5;
theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
c=1;
for i=1:length(theta1)
    theta01=theta1(i);
    for j=1:length(theta2)
        theta02=theta2(j);

        %cordinates
        x0=0;
        y0=0;
        x1=l1*cosd(theta01);
        y1=l1*sind(theta01);
        x2=x1+l2*cosd(theta02);
        y2=y1+l2*sind(theta02);

        %plotting
        plot([x0,x1],[y0,y1],[x1,x2],[y1,y2],'LineWidth',4)
        axis([-0.1 1.5 0 1.5])
        pause(0.2)
        anim(c)=getframe(gcf);
        c=c+1;
    end
end

%for getting animated video file
movie(anim)
animfile=VideoWriter('forward kinematics of a 2R Robotic Arm.avi','Uncompressed AVI');
open(animfile)
writeVideo(animfile,anim)
close(animfile)