Week 2- 2R Robotic Arm Challenge
% Forward kinematics of a 2r robotic arm
let us consider a 2r Robotic arm as showen in the figure below, for which length of first link is given by 'l1', the length of second link is given by 'l2' , theta1(θ1) and theta2(θ2) are the angles made by the links 'l1' and 'l2' respectively
let us consider l1= 1m
l2=0.5m
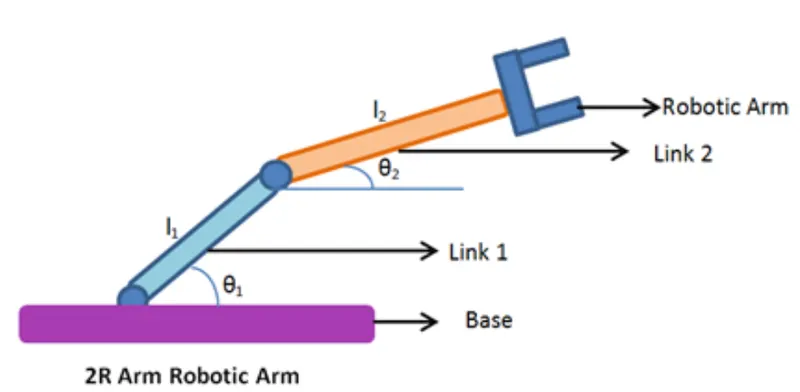
- THE FOLLOWING IS THE PROGRAM FOR FORWARD KINEMATICS OF 2R ROBOTIC ARM
% Forward kinematics of a robotic arm

clear all
close all
clc

% Inputs

% length of first link
l1=1;
% length of second link
l2=0.5;

theta1=linspace(0,90,10)
theta2=linspace(0,90,10)

ct=1;
for i=1:length(theta1)
    THETA1=theta1(i);
    for j=1:length(theta2)
        THETA2=theta2(j);

        x0=0;
        y0=0;

        x1=l1*cosd(THETA1);
        y1=l1*sind(THETA1);

        x2=x1+l2*cosd(THETA2);
        y2=y1+l2*sind(THETA2);

        % plotting
        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
        axis([-0.1 1.5 0 1.5])
        pause(0.3)
        M(ct)=getframe(gcf);
        ct=ct+1;
    end
end

movie(M)
videofile=VideoWriter("forward_kinematics.avi",'Uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)