Project - Position control of mass spring damper system
Transfer Fuction of spring mass damper system.
X_ddot=(f(t)-cxdot-kx)/m
As per given data of m,c,and k
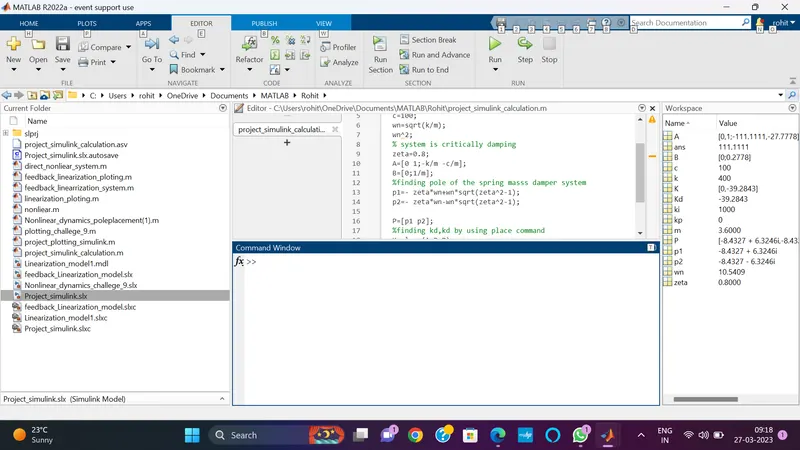
finding the poles and kp kd gain , ki gain takes manually to requird output
clear
clc
m=3.6;
k=400;
c=100;
wn=sqrt(k/m);
wn^2;
% system is critically damping
zeta=1.001;
A=[0 1;-k/m -c/m];
B=[0;1/m];
%finding pole of the spring masss damper system
p1=- zeta*wn+wn*sqrt(zeta^2-1);
p2=- zeta*wn-wn*sqrt(zeta^2-1);
P=[p1 p2];
%finding kd,kd by using place command
K=place(A,B,P);
kp=K(1);
Kd=K(2);
%manually taken ki value
ki=1200;
Model as per TF and its PID controller ;
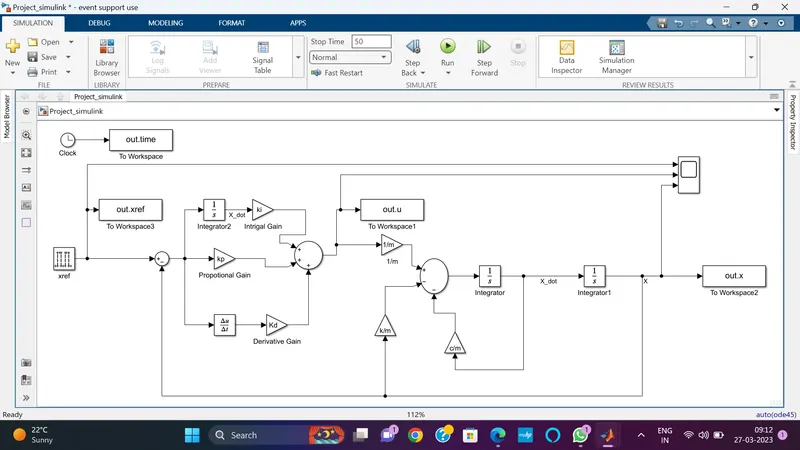
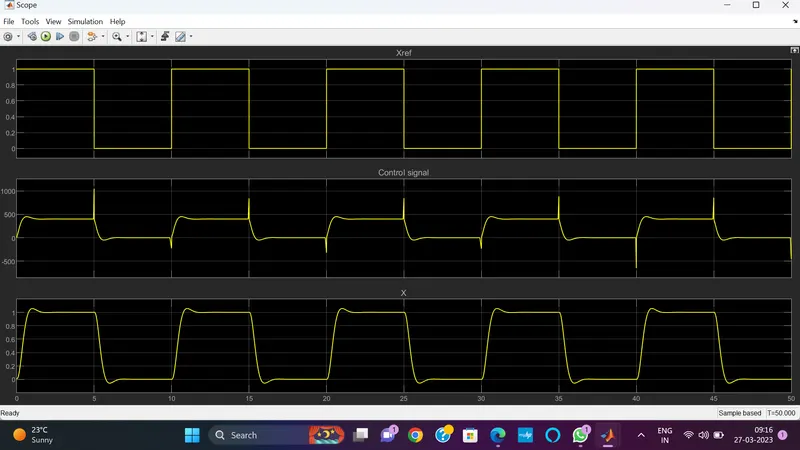
Out put at Ki= 1200;
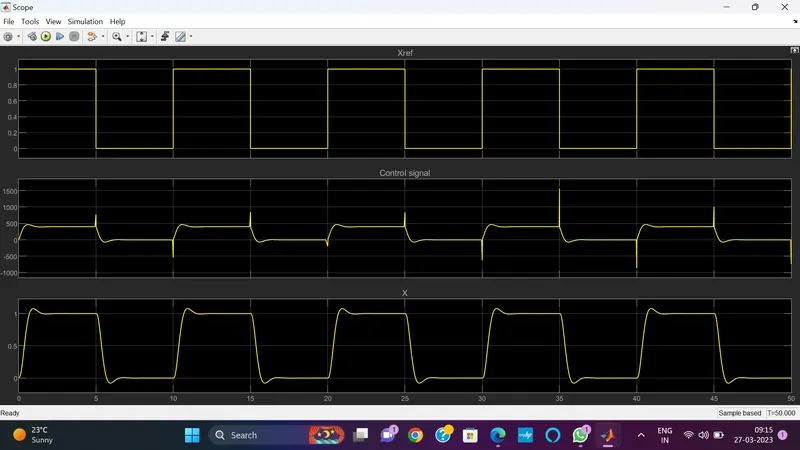
At Ki gain=1100;
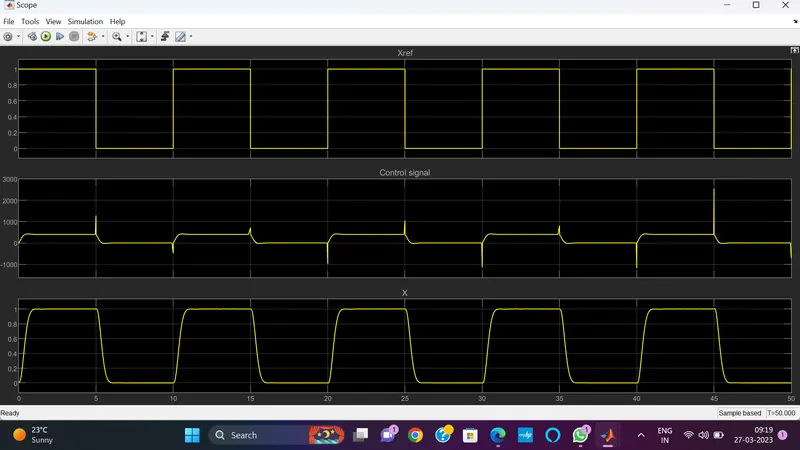
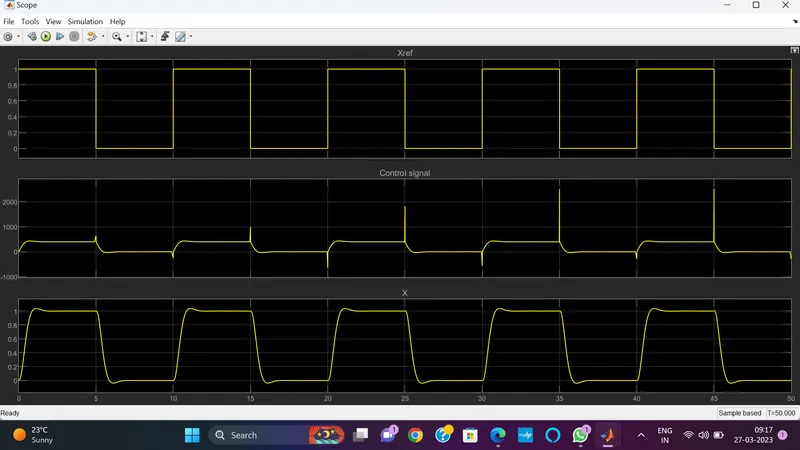
At ki=1000;
Changing the value of zeta =0.8;
result: