Project
BAJA-All Terrain Vehicle
Aim:
To model and design BAJA ATV with Continuously Variable Transmission and study the simulation under various conditions.
Objective:
To carry out system level simulation and make a report on BAJA -ATV explaining the model parameters,effcts on their change,proterties etc.
Software used:
MATLAB Simscape and Simscape Driveline
BAJA All Terrain Vehicle
All Terrain Vehicle is defined as motorized off road vehicle that can be used in all terrains like forests,mountains,deserts,varied landscapes.It is rugged in construction and can move in any conditions.
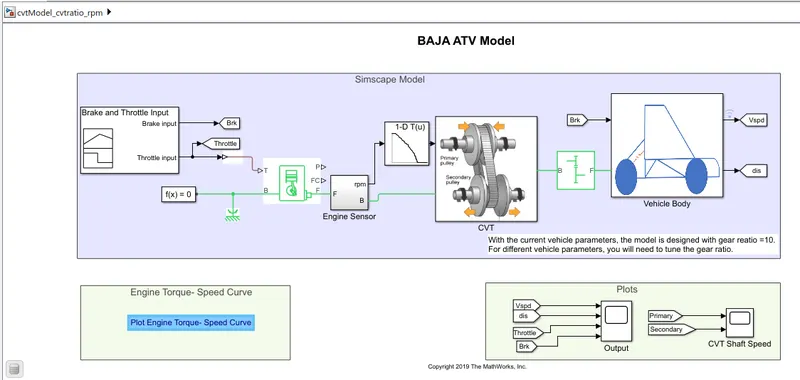
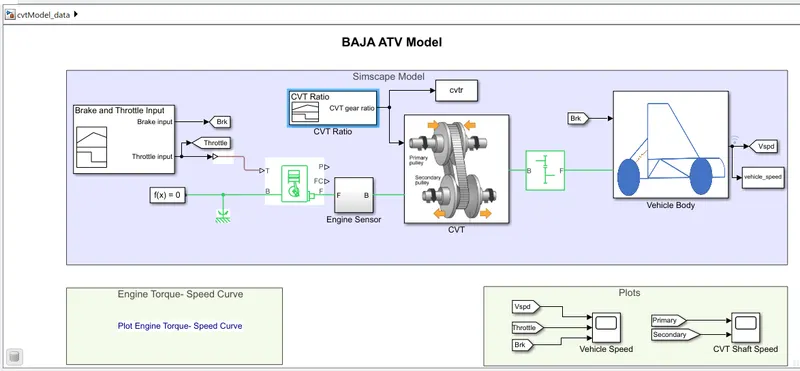
The BAJA ATV is implemented as below
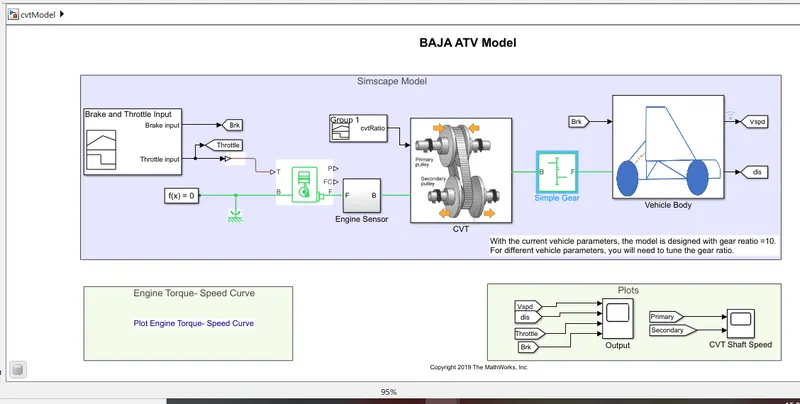
Components of BAJA ATV
Engine:
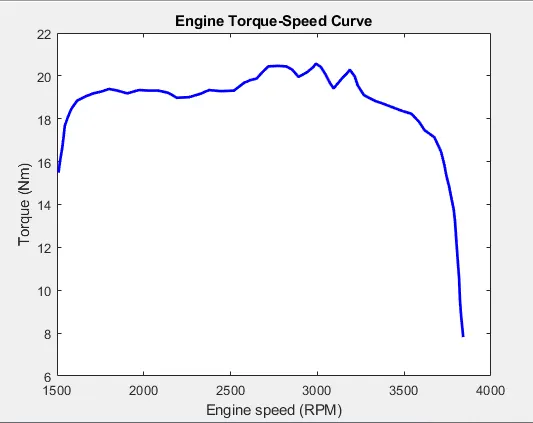
Generic Engine is used as the model.Data is fed to the engine by extracting the data points from the image using GRABIT tool.

The engine speed(rpm) vs Torque curve is shown below
Continuously Variable Transmitter(CVT)
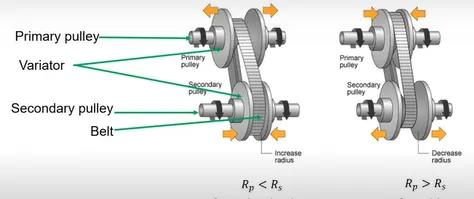
More gears enables the better performance and transmission of the vehicle.At low gears it can provide better accelaration and high gears we can maximise the feul economy.
Unlike traditional gear mechanism of shifting the gears in steps,In CVT we shift gear continuously by varying the diameters and cone shaped pulleys are connected by steel belt.They form a V shaped groove where connecting belt is placed.One side of pulley is fixed and the other side is actated by a hydraulic cylinder.
The cylinder can increase or decrease the amount of a space between the pullies and makes the belt to ride between low and high gears enbling the change in gear ratio.
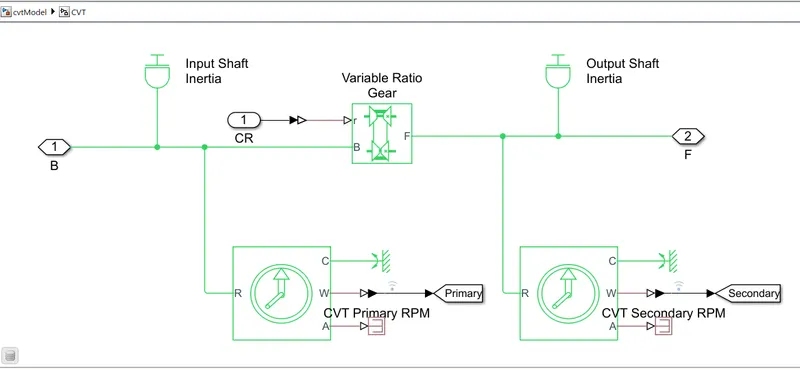
The CVT model is modeled as below
Vehicle Body:
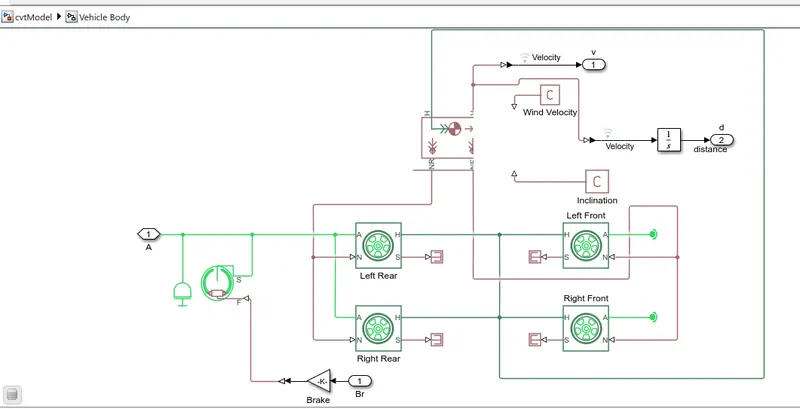
Vehicle body is modelled with front and rear tyre as shown below.
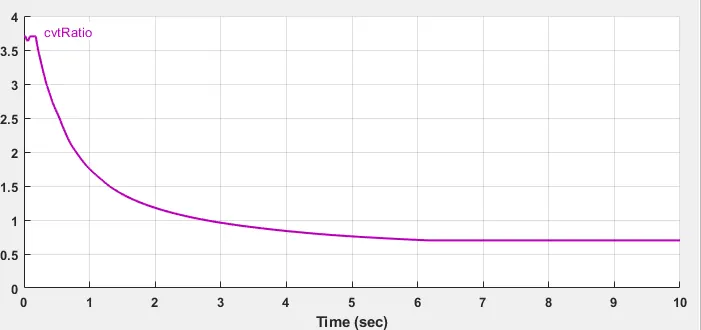
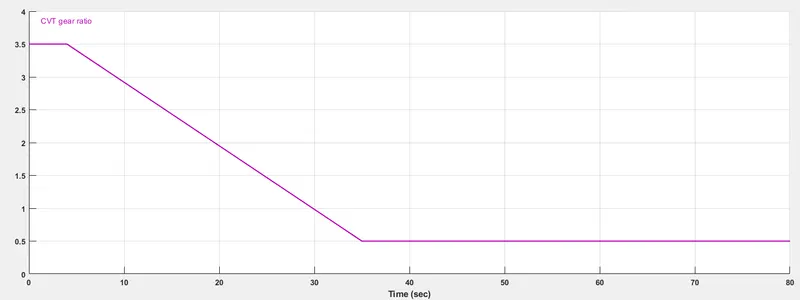
The CVT ratio using the signal builder is
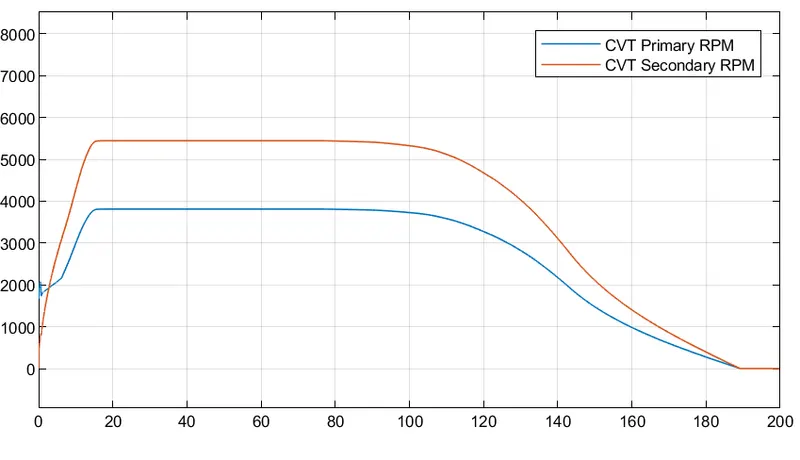
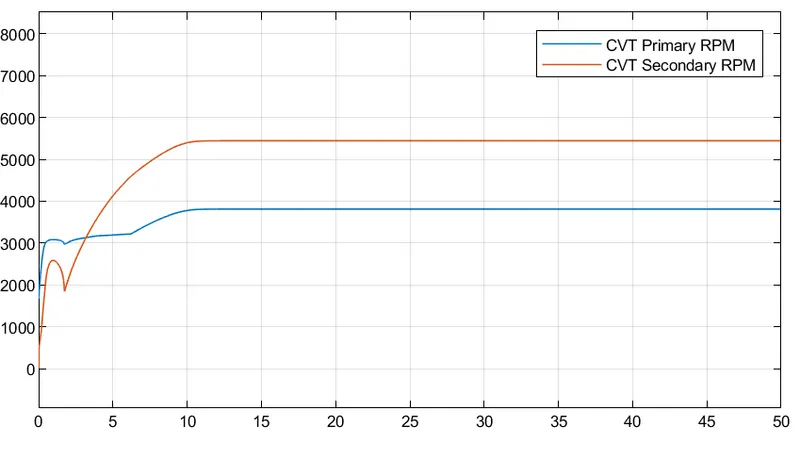
Corresponding CVT shaft speed is
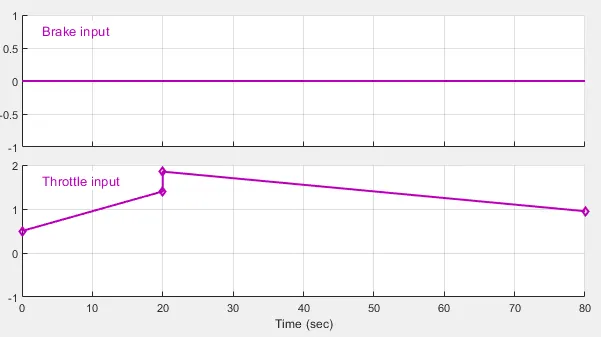
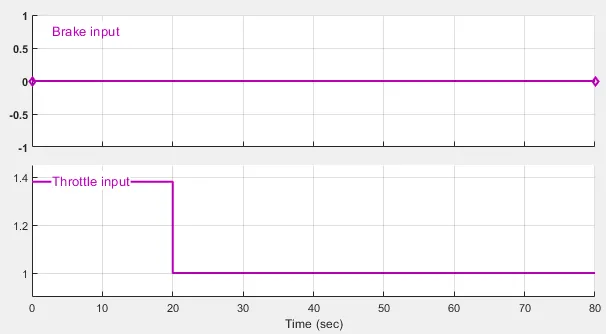
For the given Throttle and brake input using signal builder
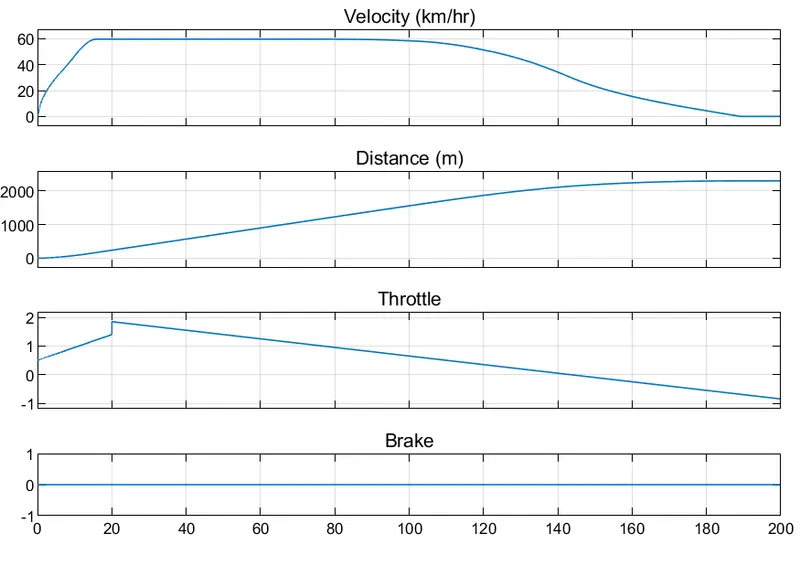
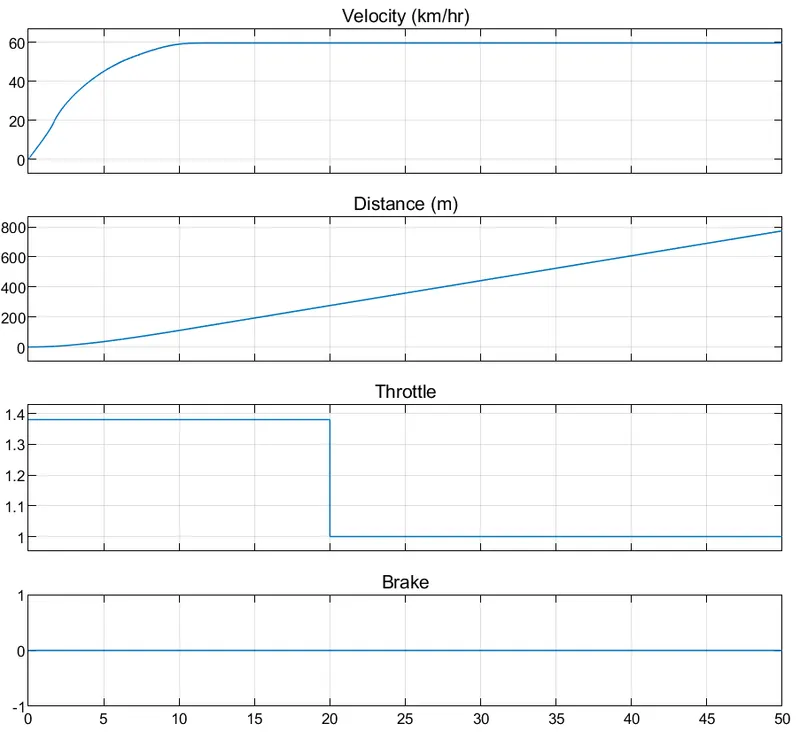
The Result is
ATV Speed and the distance moved in given time is plotted as below.
BAJA ATV with CVTratio and 1D Lookup table
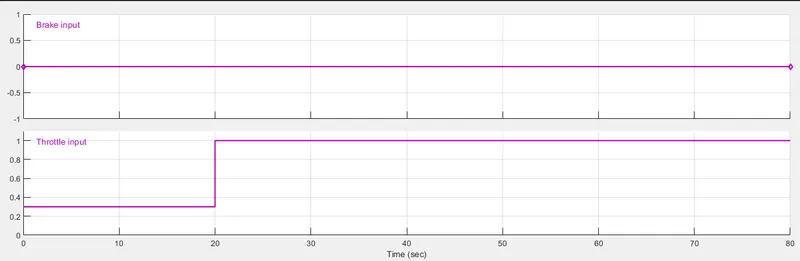
The Throttle and brake values set using signal builder as below
The CVT Shaft speed is
The Result is
BAJA ATV data based CVT model
Brake and throttle input using signal builder as below
The CVT ratio specified using signal builder
Result
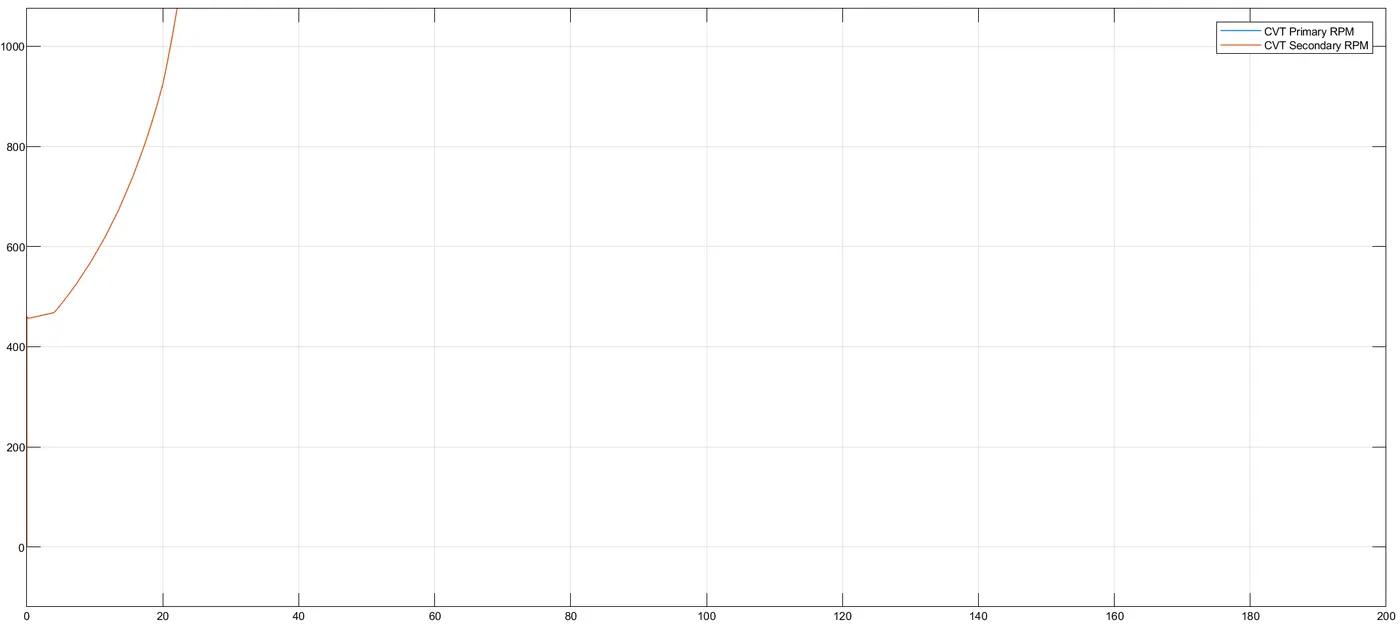
The CVT Shaft speed is
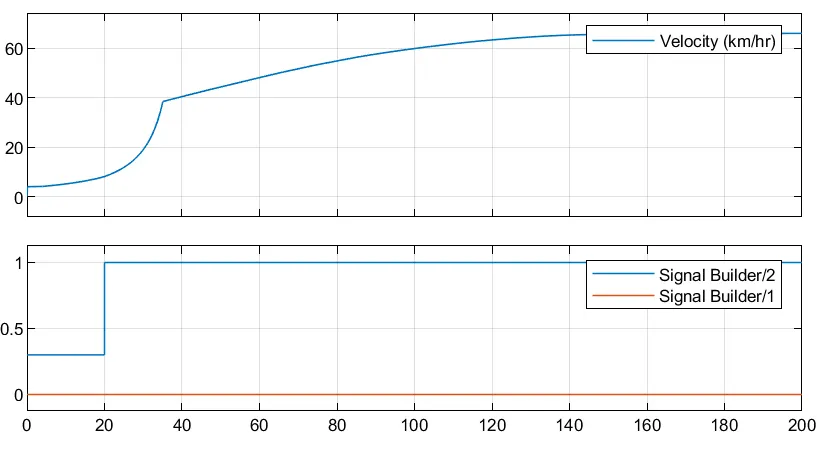
The Vehicle speed coresponding to given input is
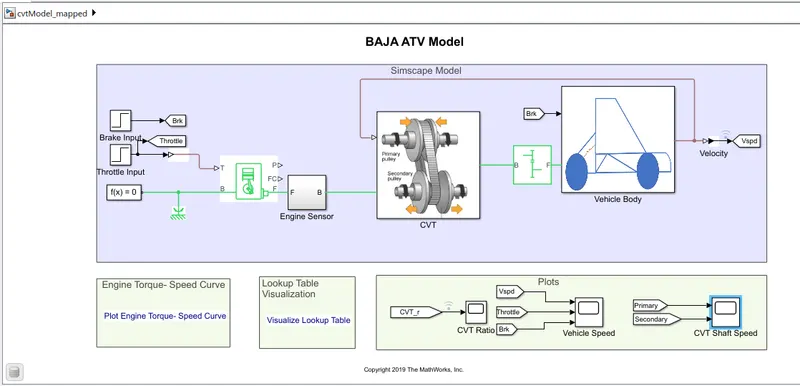
BAJA ATV model using closed loop mapping
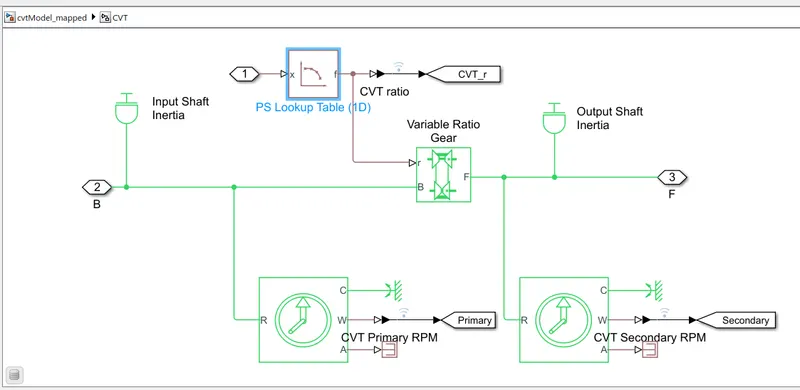
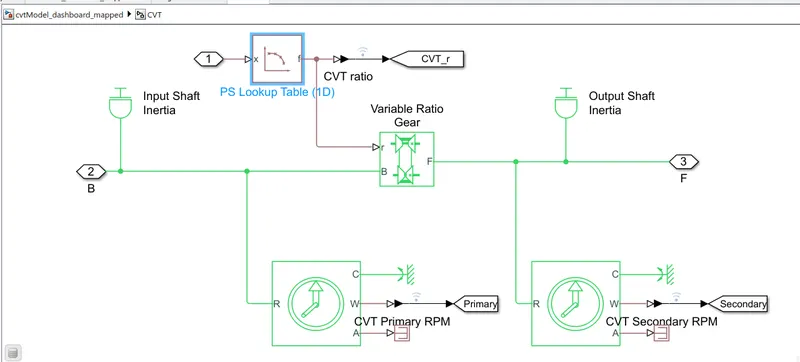
1 Dimensional PS Lookup table is used in CVT for implementation
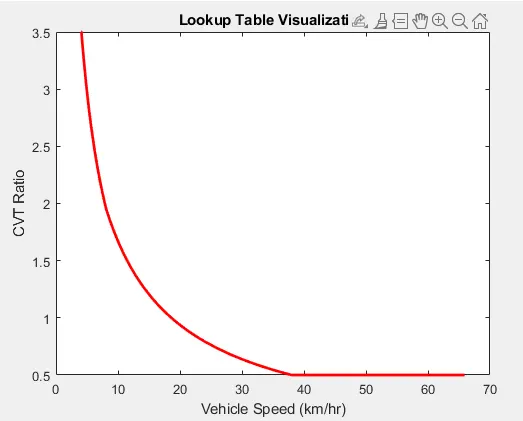
Lookup table visualization
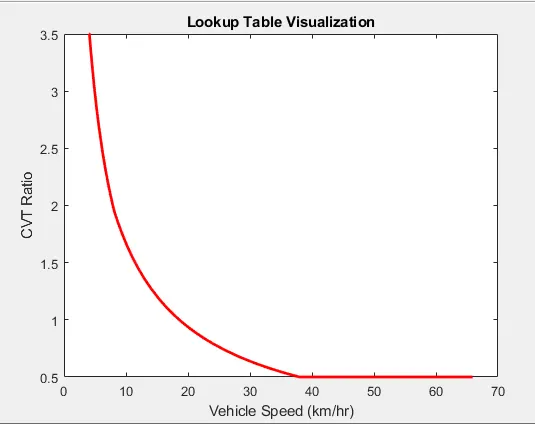
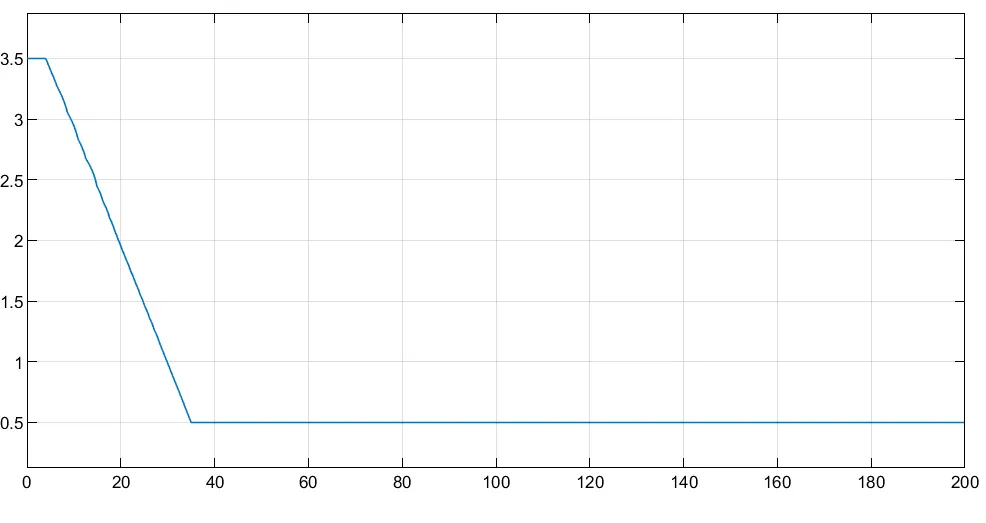
CVT Ratio is
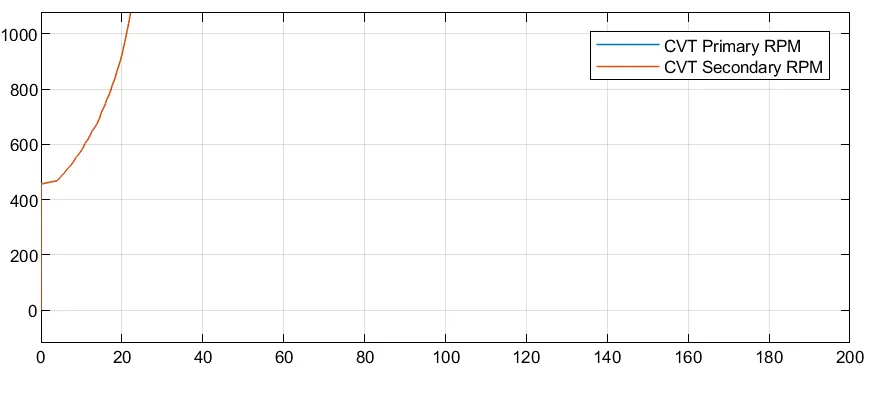
The Result:
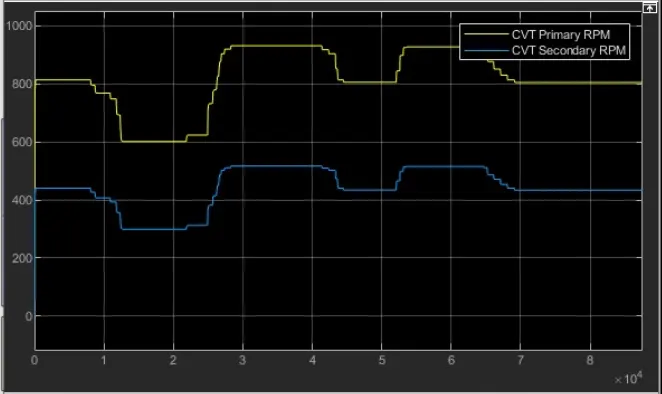
The CVT Shaft speed is given below
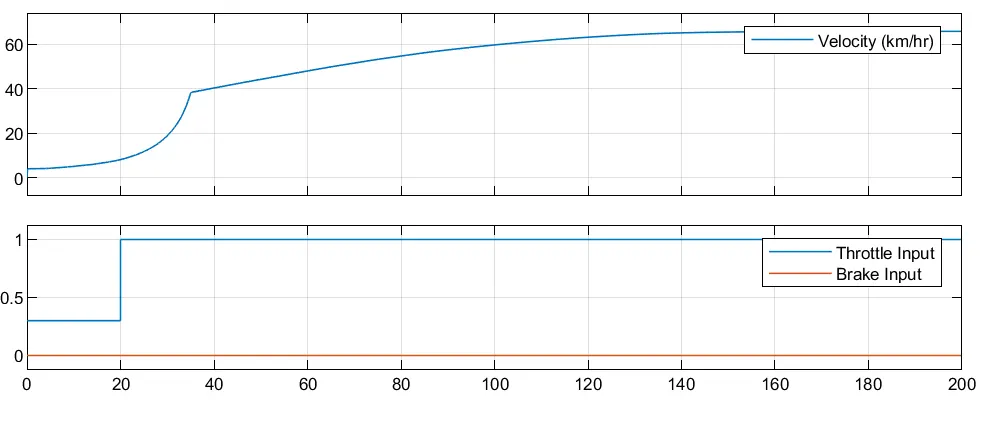
The velocity of ATV coresponding to the given throttle and brake inputs is
BAJA ATV Model with Dashboard and closed loop mapping
Using dashboard we can adjust the Throttle and brake input with the knobe provided
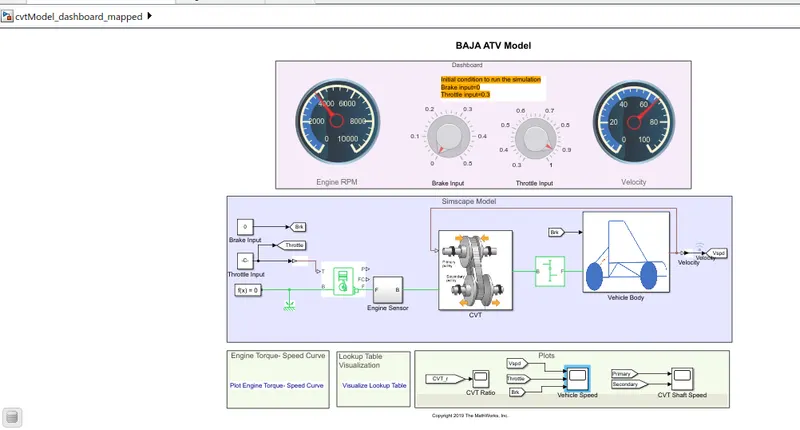
I dimensional PS lookup table is used in CVT
The lookup table visulization is as below
Result
The CVT Shaft speed is as given below
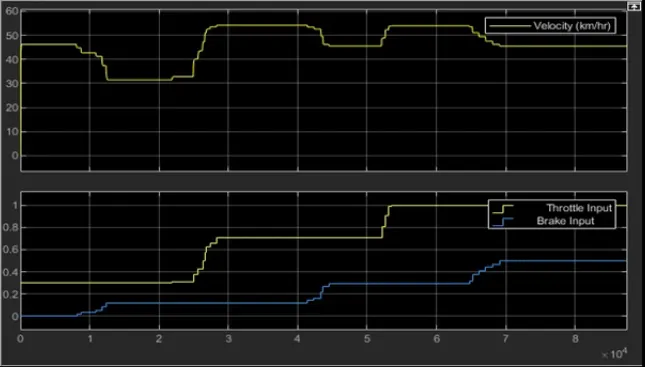
The velocity of BAJA ATV Coresponding to the change in the Throttle and brake input is as shown below.
Conclusion:
System level simulation of All Terrain Vehicle is carried out successfully using Simscape and Simscape Driveline.BAJA ATV is analysed by incorporating the real component data of engine,CVT,Vehicle dynamics etc for different models.