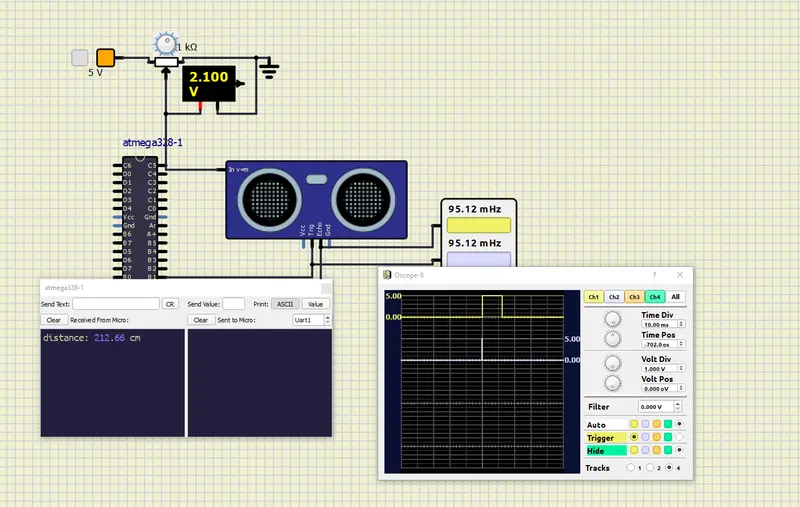
Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
Program:
#include <avr/io.h>
#include "avr/interrupt.h"
#define F_CPU 16000000
#include <util/delay.h>
#define Baudrate 9600
#define UBRR ((F_CPU / (16 * Baudrate)) - 1)

enum status {
	ON,
	OFF
};

enum status counterStatus = OFF;
uint16_t counterValue = 65000;


void initTriggerPulse()
{
	DDRB |= (1<<DDB1);
	PORTB |= (1<<PORTB1);
	_delay_us(10);
	PORTB &= ~(1<<PORTB1);
}

void initTimerSettings()
{
	// timer/counter normal mode and ICES1 set to zero to set falling edge as trigger
	TCCR1B = 0;
	TIFR1 |= (1<<ICF1);
	TIMSK1 |= (1 << ICIE1);
	sei();
}

void startTimer()
{
	TCCR1B |= (1 << CS12);
	counterStatus = ON;
}

void stopTimer()
{
	TCNT1 = 0;
	TCCR1B &= ~(1 << CS12);
	counterStatus = OFF;
}

void calculateAndPrintDistance()
{
	// pre scale value 256
	// speed of sound 343 * 100 cm/s
	// ((1 / (F_CPU / 256)) * 343 * 100) / 2  = 0.2744
	float distanceInCM = 0.2744 * counterValue;

	char str[25];
	sprintf(str, "distance: %.2f cm", distanceInCM);
	//sprintf(str, "u: %" PRIu16 " ", counterValue);
	uartPrintString(str);
}

void Uart_Init()
{
	UBRR0H = UBRR >> 8;
	UBRR0L = UBRR;

	UCSR0B = 1 << TXEN0;
	UCSR0C = (1 << UCSZ01) | (1 << UCSZ00);
}

void UartSend(uint8_t data)
{
	while (!( UCSR0A & (1<<UDRE0)));
	UDR0 = data;
	_delay_ms(500);
}

void uartPrintString(char *str)
{
	int i = 0;
	while (str[i] != '\0') {
		UartSend(str[i++]);
	}
}

int main(void)
{
	initTimerSettings();

	initTriggerPulse();
	startTimer();

	while(1) {
		if (counterStatus == OFF) {
			calculateAndPrintDistance();

			_delay_ms(1000);
			initTriggerPulse();
			startTimer();
		}
	}
}

ISR(TIMER1_CAPT_vect) {
	counterValue = ICR1;
	stopTimer();
}
Output: