Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Implementation of problem
To start the project coding we need the states with their respective functions.
Here we are using the switch states, Direction of valves with respect to gear.
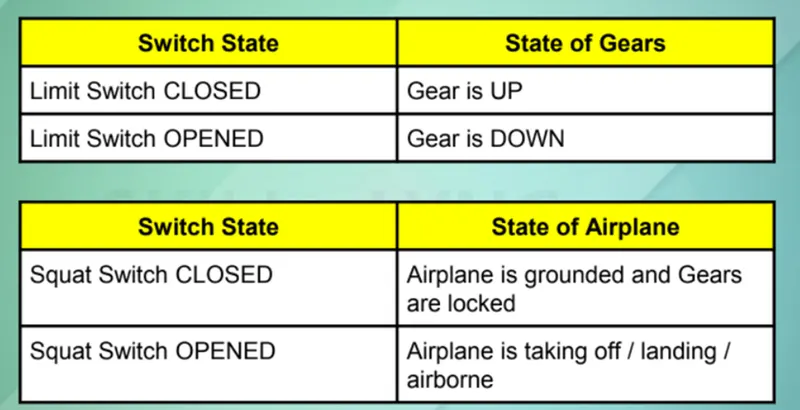
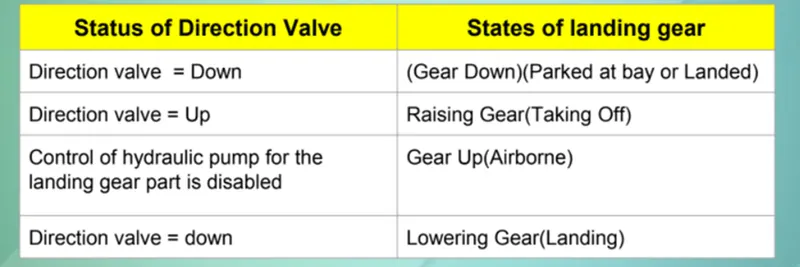
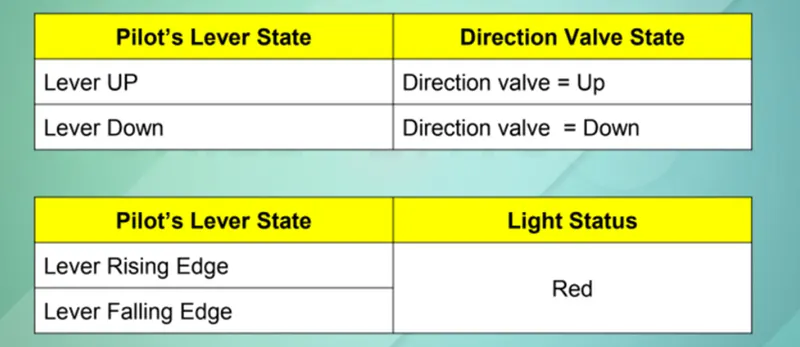
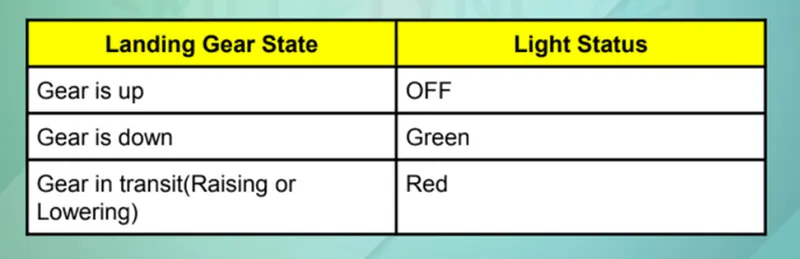
STATE DIAGRAM:
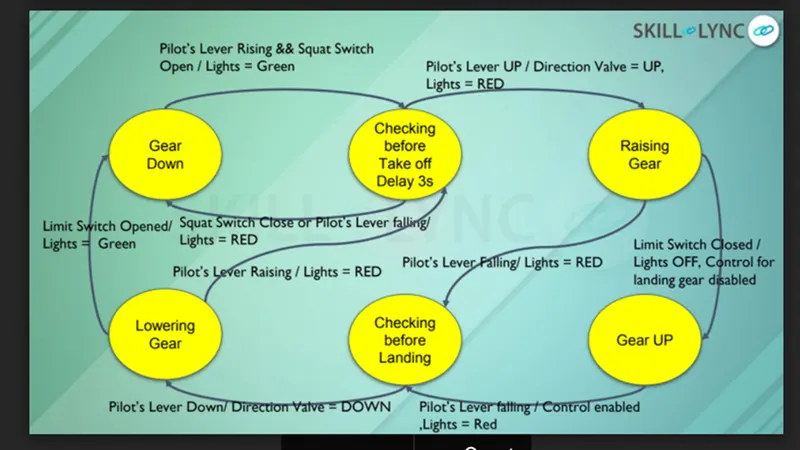
The above State diagram coding program is creating
three different files.
1.Main.c
2.Airplane.c
3.Airplane.h
AIRPLANE.h FILE EXPLANANTION:
Step1: .h file contain functions and structures and Enum definitions and state tables.
Step2: whenever enter following created function into the array of 6 element to access the function based on requirement. In the name of static table.
Step4: Creating the four Enum functions for this project for the inputs given above
1.State types
2.Switch status-limit switch and squat switch
3.Pilots_lever
4.Hydraulic pump status.
Step5: create the object name for the Enum structures to use the input value In the project and mentioned in name static and Volatile because these inputs use anywhere and input values are changing the every stage of the program.
Step6: creating the structure
Structure name: state_table.
Structure Object name: state_machine.
In this program structure members arranged in array structure having 6 different types of output as per state table.
In main program to access the structure member from state table using dot(.) operator.
AIRPLANE.c FILE EXPLANANTION:
Six State functions:
IN THE GEAR DOWN FUNCTION
Step 1: pilot give inputs as raising and squat switch on ie: raising=0 and switch on=0; current state is gear down to changing the state as checking before take off
All other inputs possible status(0,1 or 1,0 or 1,1) state is geardown.
Output:
The Finite State Machine is Intialized and current the program is: GearDown State
The Finite State Machine is Intialized and current state Light is:Green
Enter the status of pilot's lever and squat switch:0 1
present state is: Geardown
Enter the status of pilot's lever and squat switch:1 0
present state is: Geardown
Enter the status of pilot's lever and squat switch:1 1
present state is: Geardown
Enter the status of pilot's lever and squat switch:0 0
current state:CheckingBeforeTakeOFF
Light is :Green
STEP2: IN THE CHECKING BEFORE TAKEOFF FUNCTION:
1.pilot lever give inputs as falling and squat switch off : raising=1 and switch on=1; current state is checking before take-off gear down to changing the state as gear down.
Output:
Enter the status of pilot's lever and squat switch:1 1
present state is: Geardown
- pilot lever give inputs as raising and squat switch on and hp start I e: raising=0 and switch on= 0;
Output:
Enter the status of pilot's lever and squat switch and hydraulic pump:0 0
Current State:RaisingGear
Light is:Red
Status of Direction valve:Up
STEP3: IN THE RAISING GEAR FUNCTION:
1.pilot lever give inputs as falling and limit switch on: falling=1 and limit switch on=0; current state is Raising gear to changing the state as checking before landing
Output:
Enter the status of pilot's lever and limit switch:1 0
Current State:CheckBeforeLanding
Light is:Red
Landing Gear Hydraulic Control:Enabled
- pilot lever give inputs as Raising and limit switch off : Raising=0 and limit switch on=1; current state is Raising gear to changing the state as Gear Up.
Output:
Enter the status of pilot's lever and limit switch:0 1
Current State:GearUp
Light is:Off
Landing Gear Hydraulic Control:Disbled
Enter the status of pilot's lever:
- All other inputs possible status(0,0 or 1,1) state is Raising Gear.
Output:
Enter the status of pilot's lever and limit switch:0 0
present state is: Raising Gear
STEP4: IN THE GEAR UP FUNCTION:
1.pilot lever give inputs as falling: falling=1 current state is gear up to changing the state as checking before landing
Output:
Enter the status of pilot's lever:1
Current State:CheckBeforeLanding
Light is:Red
Landing Gear Hydraulic Control:Enabled
1.pilot lever give inputs as falling: falling=0 current state is gear up
Output:
Enter the status of pilot's lever:0
present state is: Gear Up
STEP5: IN THE CHECKING BEFORE LANDING FUNCTION:
1.pilot lever give inputs as falling: falling=1 current state is gear up to changing the state as checking before landing
Output:
Enter the status of pilot's lever and hydraulic pump status:1
0
Current State:LoweringGear
Light is:Green
Status of Direction valve:Down
1.pilot lever give inputs as Raising: Raising =0 current state is check before landing
Output:
Enter the status of pilot's lever and hydraulic pump status:0
0
present state is: Check before landing
STEP6: IN THE LOWERING GEAR FUNCTION:
1.pilot lever give inputs as falling and limit switch on: falling=1 and limit switch on=0; current state is Lowering Gear 1to changing the state as checking before take off
Output:
Enter the status of pilot's lever and limit switch:1 0
Current State:CheckingBeforeTakeOFF
Light is:Green
- pilot lever give inputs as raising and limit switch off: raising=0 and switch off= 1;
Output:
Enter the status of pilot's lever and limit switch:0 1
Current State:GearDown
Light is:Green
Landing Gear Hydraulic Control:Enabled
FULL PROGRAM OUTPUT:
The Finite State Machine is Intialized and current the program is: GearDown State
The Finite State Machine is Intialized and current state Light is:Green
Enter the status of pilot's lever and squat switch:0 0
current state:CheckingBeforeTakeOFF
Light is :Green
Enter the status of pilot's lever and squat switch and hydraulic pump:0 0
wait for 3 secs
Current State:RaisingGear
Light is:Red
Status of Direction valve:Up
Enter the status of pilot's lever and limit switch:0 1
Current State:GearUp
Light is:Off
Landing Gear Hydraulic Control:Disabled
Enter the status of pilot's lever:1
Current State:CheckBeforeLanding
Light is:Red
Landing Gear Hydraulic Control:Enabled
Enter the status of pilot's lever and hydraulic pump status:1 1
Current State:LoweringGear
Light is:Green
Status of Direction valve:Down
Status of gas pressurised Spring System:EP@
Enter the status of pilot's lever and limit switch:0 1
Current State:GearDown
Light is:Green
Landing Gear Hydraulic Control:Enabled