Project 2 Adaptive Cruise Control
The mini project is designed to implement the adas feature of adaptive cruise control.
The input constants and signals are created in the SLDD using model explorer.
The requirement 1 and requirement 2 are implement as simulink blocks where as the algorithm is a event driven scenario and hence developed using state machine logics.
The charts were created. Each of the states have a specified output. These were also implemented using en conditions. All of the transition conditions were also applied.
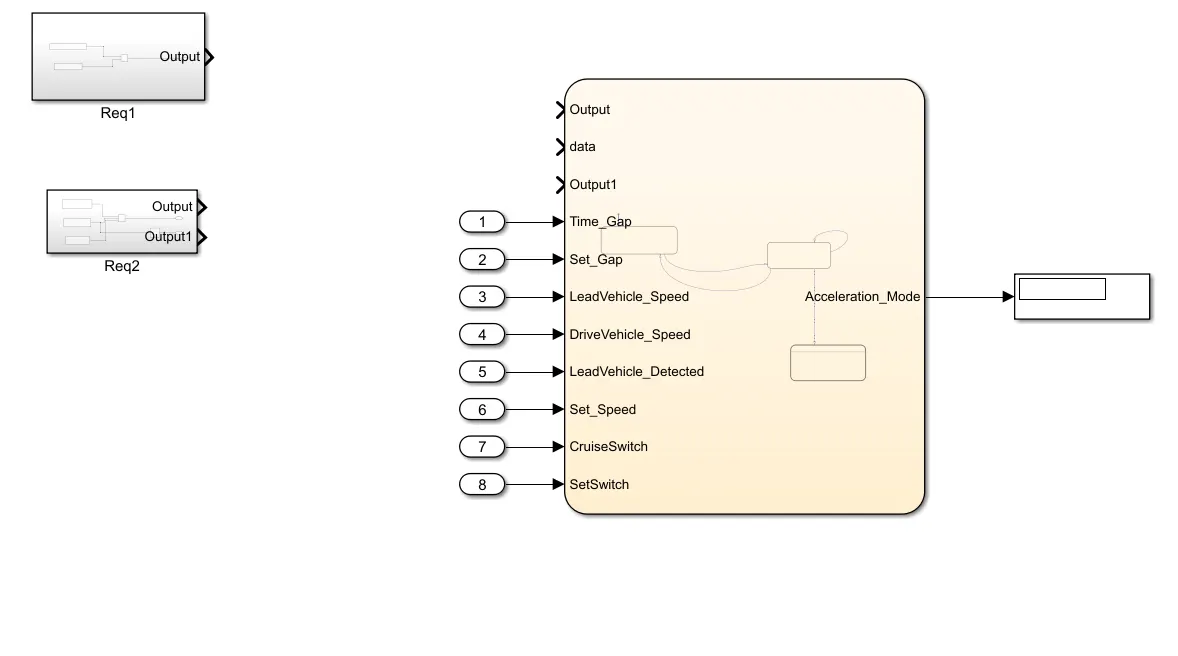
The output values form the req 1 and req 2 are accessed by the charts using SLDD. Hence no connections needed between the requirement subsystem and charts.
Hence the model was implemented using simulink state modelling.
P.S: Since the embedded coder is not available with my version of matlab, code could not be unfortunately generated.