Project 1 (Mini Project on Vehicle Direction Detection
Prerequisites:
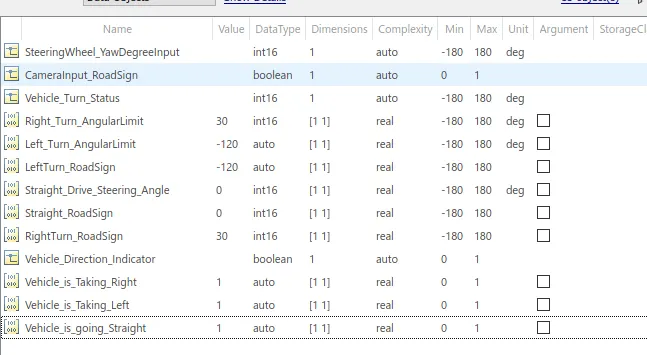
Updated the Signal and parameter values in ModelWorkspace.
Sample time is considered 0.01 for the signals.
NOTE: In the Objective, it is menetied as below, So haven't created sldd and model advisor steps and code generation.
"MBD compliant changes, Data Dictionary creation & code generation is added advantage, and that is not scope of this project."
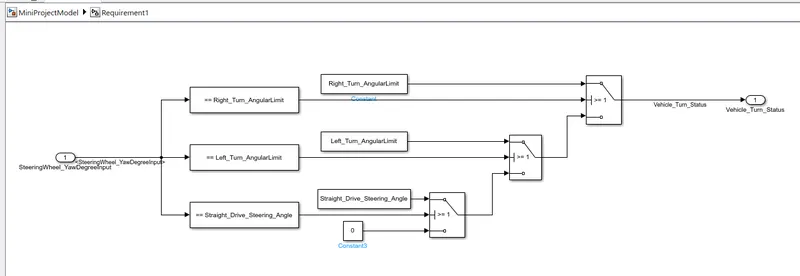
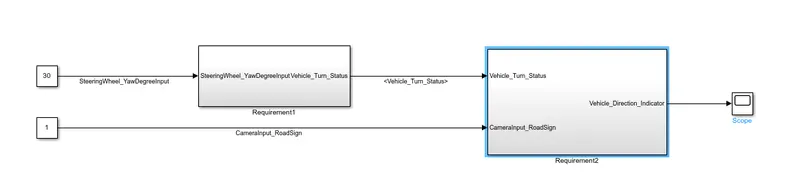
Requirement1: Determining the Vehicle turn status
Compared the Yawdegree input with the Left turn, Right turn, Straight Drive values. Accordingly Vehicle_Turn_Status is determined using Switch blocks
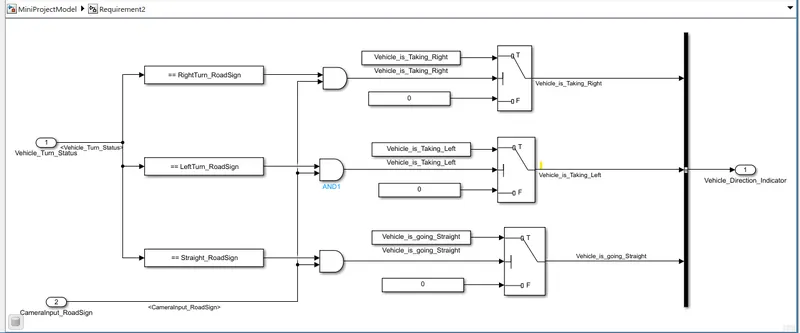
Requirement2:Compared the Vehicle turn status with CameraInput RoadSign using logical AND blocks. Used Switch blocks so that only one output is received.
Considered three new blocks, Vehicle_is_Taking_Right, Vehicle_is_Taking_Left, Vehicle_is_going_Straight for the display.
If there is no change in the direction, used delay block to show the same.
Tagged Both the subsystems. Shared the Requirement Word document.
Simulation:
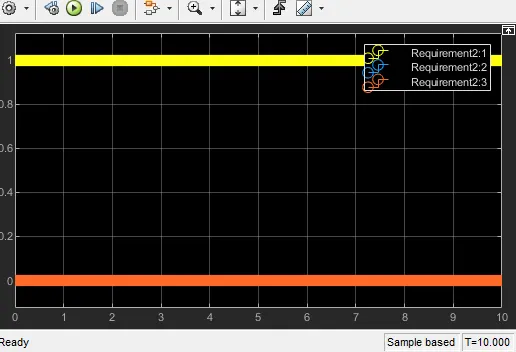
Simulated by Giving SteeringWheel_YawDegreeInput as 30 and CameraInput_RoadSign as 1.
Below is the scope showing vehicle taking Right [Requirement2.1]