Project 1 - Data Handling and Interpolation
Project 1 :
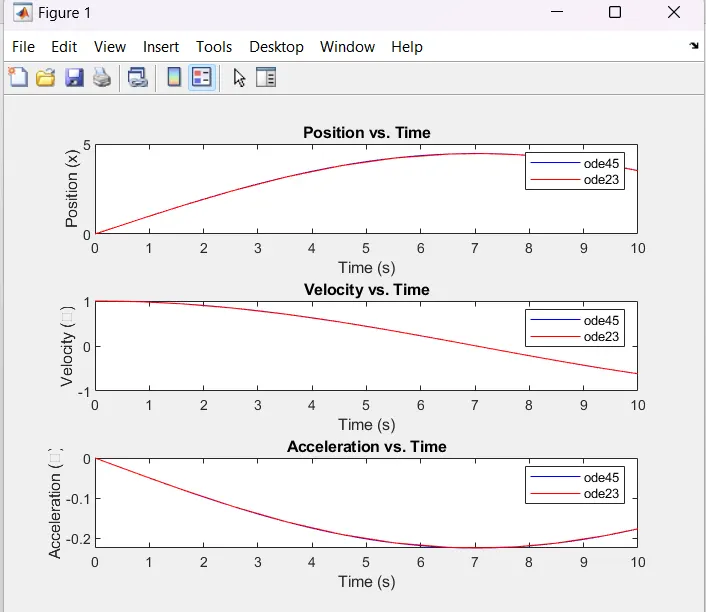
- Solve the simple harmonic oscillator equation [m . dx² / dt² = -k.x ] for a given m (mass) and k (spring constant) values using ‘ode45’ and ‘ode23’ solver in MATLAB.
- Plot x, x_dot (ẋ) & x_dot_dot (ẍ).
- Use the input dialog box to get ‘m’ & ‘k’ values from the user.
- Compare ‘ode45’ and ‘ode23’ plots and explain.
Solution
Matlab code
function simple_harmonic_oscillator()
% Get user input for mass (m) and spring constant (k)
prompt = {'Enter mass (m):', 'Enter spring constant (k):'};
dlgtitle = 'Input';
dims = [1 35];
definput = {'1', '1'};
input = inputdlg(prompt, dlgtitle, dims, definput);
m = str2double(input{1});
k = str2double(input{2});
% Define the differential equation
fun = @(t, y) [y(2); -k / m * y(1)];
% Initial conditions: x(0) = 0, x_dot(0) = 1
y0 = [0; 1];
% Time span for the simulation
tspan = [0, 10];
% Solve using ode45 and ode23
[t45, sol45] = ode45(fun, tspan, y0);
[t23, sol23] = ode23(fun, tspan, y0);
% Extract the solutions
x45 = sol45(:, 1);
x_dot45 = sol45(:, 2);
x23 = sol23(:, 1);
x_dot23 = sol23(:, 2);
% Plot the results
figure;
% Position vs. Time
subplot(3, 1, 1);
plot(t45, x45, 'b', t23, x23, 'r');
xlabel('Time (s)');
ylabel('Position (x)');
legend('ode45', 'ode23');
title('Position vs. Time');
% Velocity vs. Time
subplot(3, 1, 2);
plot(t45, x_dot45, 'b', t23, x_dot23, 'r');
xlabel('Time (s)');
ylabel('Velocity (ẋ)');
legend('ode45', 'ode23');
title('Velocity vs. Time');
% Acceleration vs. Time
subplot(3, 1, 3);
x_dot_dot45 = -k / m * x45;
x_dot_dot23 = -k / m * x23;
plot(t45, x_dot_dot45, 'b', t23, x_dot_dot23, 'r');
xlabel('Time (s)');
ylabel('Acceleration (ẍ)');
legend('ode45', 'ode23');
title('Acceleration vs. Time');
end
Result
Project 2 :
Write a program to perform the following steps
- load altitude vs temperature data from the tables International Standard Atmosphere (ISA) ((click on the link))
- use the ‘polyfit’ function to determine a regression model: T = f(h) for the above table.
- evaluate the model determined using the ‘polyval’ function
- determine the goodness of fit (goodnessOfFit function)
- Generate comparative plot for the loaded and evaluated data
- store polyval evaluated data into a text file.
solution
Project 3 :
Create a function to evaluate the following expression.
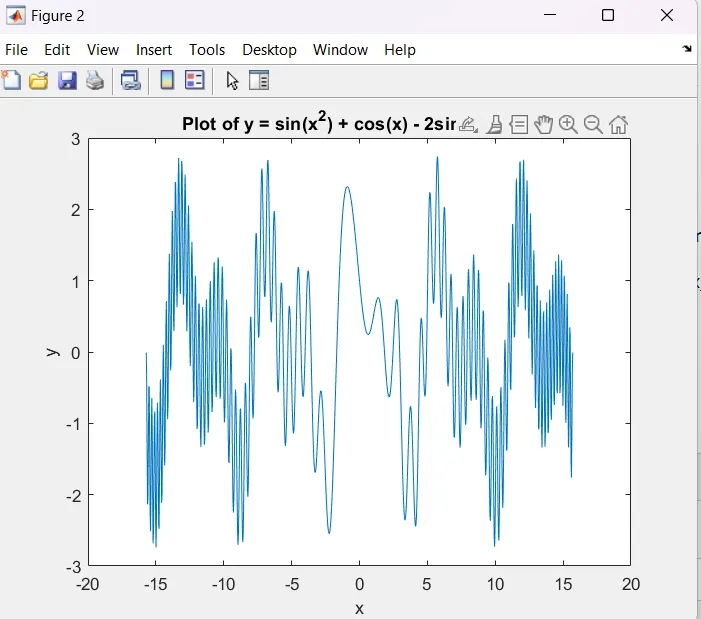
y= sin(x²) +cos(x) - 2 sin(x) cos(x)
- Generate the plot and determine all local minima and global maxima values.
- Use the ‘gtext’ command to highlight the local minima and global maxima value in the graph.
Hint: make use of 'fminsearch' & 'max' commands.
function find_extrema()
% Step 1: Create the function
f = @(x) sin(x.^2) + cos(x) - 2 * sin(x) .* cos(x);
% Step 2: Generate the plot of the function
x = linspace(-5*pi, 5*pi, 1000);
y = f(x);
figure;
plot(x, y);
xlabel('x');
ylabel('y');
title('Plot of y = sin(x^2) + cos(x) - 2sin(x)cos(x)');
% Step 3: Use 'fminsearch' to find local minima
local_minima_x = [];
local_minima_y = [];
for i = 1:length(x)-1
x0 = x(i);
x1 = x(i+1);
local_minima = fminsearch(f, [x0, x1]);
if local_minima(1) >= x(i) && local_minima(1) <= x(i+1)
local_minima_x(end+1) = local_minima(1);
local_minima_y(end+1) = f(local_minima(1));
end
end
% Step 4: Use 'max' to find the global maximum
[global_max_y, global_max_index] = max(y);
global_max_x = x(global_max_index);
% Step 5: Highlight the local minima and global maxima on the plot
hold on;
plot(local_minima_x, local_minima_y, 'ro', 'MarkerSize', 6, 'DisplayName', 'Local Minima');
plot(global_max_x, global_max_y, 'go', 'MarkerSize', 8, 'DisplayName', 'Global Maxima');
legend('Location', 'best');
% Add text labels near the points
text(local_minima_x + 1, local_minima_y, sprintf('Minima: x = %.2f, y = %.2f', local_minima_x, local_minima_y), 'FontSize', 8);
text(global_max_x + 1, global_max_y, sprintf('Maxima: x = %.2f, y = %.2f', global_max_x, global_max_y), 'FontSize', 8);
end
result
Project 4 :
Give a brief note on the “contour” command. Illustrate with an example.
Note :
- For example, take simple code and execute in MATLAB.
- Attach the same along with the answer body
contour(X, Y, Z)
where:
- "X" and "Y" are matrices or vectors representing the x and y coordinates of the data points.
- "Z" is a matrix representing the function or data values at each (x, y) point.
The "contour" command can also take additional arguments to customize the appearance of the contour plot, such as specifying the levels of contour lines, line colors, line styles, labels, etc.
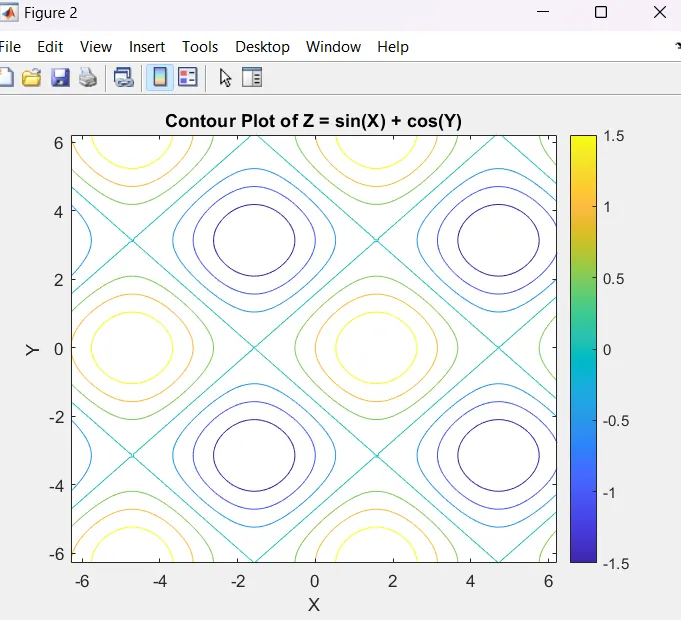
Example: Let's create a simple contour plot of the function Z = sin(X) + cos(Y) over a specified range of X and Y.
% Create data for X and Y
[X, Y] = meshgrid(-2*pi:0.1:2*pi, -2*pi:0.1:2*pi);

% Define the function Z = sin(X) + cos(Y)
Z = sin(X) + cos(Y);

% Plot the contour
contour(X, Y, Z);
xlabel('X');
ylabel('Y');
title('Contour Plot of Z = sin(X) + cos(Y)');
colorbar; % To display a color scale representing the contour levels