Final Project: Design of an Electric Vehicle
Electric Vehicle Model
This Model and project pertains to the modelling of a working Electric vehicle in Simulink and with the help of parameterisation in MATLAB.
The main aim of the project is to understand the Working of an Electric vehicle with the help of a DC motor and the various parts the electric vehicle would use for it to run perfectly.
The main software requirements is MATLAB 2019b and the main modelling is done Simulink using the simscape and the normal library.
LITERATURE
An electric vehicle (EV) is a vehicle that uses one or more electric motors or traction motors for propulsion. An electric vehicle may be powered through a collector system by electricity from off-vehicle sources, or may be self-contained with a battery, Solar panel or a Generator to convert fuel to electricity. EVs include, but are not limited to, road and rail vehicles, surface and underwater vessels, electric aircraft and electric spacecraft.
EVs first came into existence in the mid-19th century, when electricity was among the preferred methods for motor vehicle propulsion, providing a level of comfort and ease of operation that could not be achieved by the gasoline cars of the time. Modern internal combustion engines have been the dominant propulsion method for motor vehicles for almost 100 years, but electric power has remained commonplace in other vehicle types, such as trains and smaller vehicles of all types.
There are many ways to generate electricity, of varying costs, efficiency and ecological desirability.
1. Connection to Generator Plants
2.Onboard Generators and Hybrid EVs
3. Onboard Storage : Fuel Electric Vehicles and Batteries.
Lithium Ion Battery
Most electric vehicles use Lithium Ion Batteries (Li-Ions or LIBs). Lithium ion batteries have higher energy Density, longer life span and higher power density than most other practical batteries. Complicating factors include safety, durability, thermal breakdown and cost. Li-ion batteries should be used within safe temperature and voltage ranges in order to operate safely and efficiently.
Increasing the battery's lifespan decreases effective costs. One technique is to operate a subset of the battery cells at a time and switching these subsets.
In the past, Nickel Metal Hydride batteries were used among EV cars such as those made by General Motors. These battery types are considered out-dated due to their tendencies to self discharge in the heat. Also the batteries' patent was held by Chevron which created a problem for their widespread development. These detractors coupled with their high cost has led to Lithium-ion (Li-Ion) batteries leading as the predominant battery for EVs.
Lithium-ion batteries' price is constantly decreasing, thus, making electric vehicles more affordable and attractive on the market.
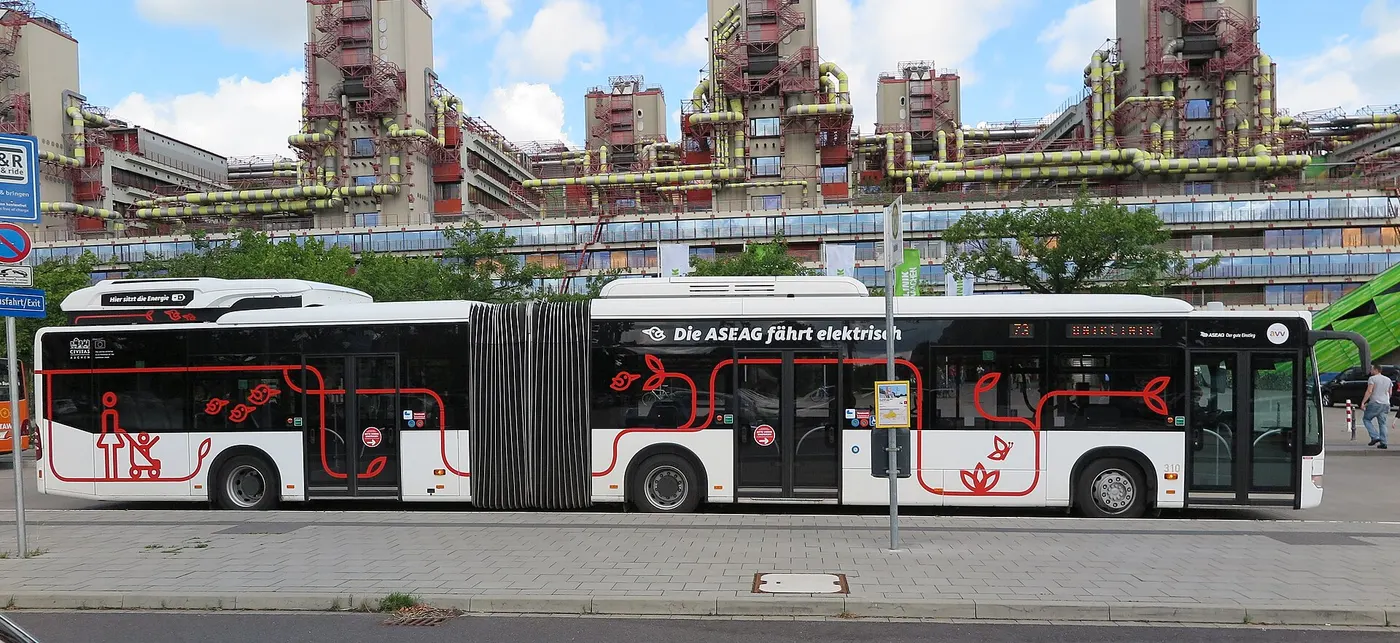
Figure 1: Electric Bus Powered by Lithium Ion Batteries
Electric Motor
The power of a vehicle's electric motor, as in other vehicles, is measured in kilowatts (kW). 100 kW is roughly equal to 134 HP, but electric motors can deliver their maximum torque over a wide RPM range. This means that the performance of a vehicle with a 100 kW electric motor exceeds that of a vehicle with a 100 kW internal combustion engine, which can only deliver its maximum torque within a limited range of engine speed.
Energy is lost during the process of converting the electrical energy to mechanical energy. Approximately 90% of the energy from the battery is converted to mechanical energy, the losses being in the motor and drivetrain.
Usually, direct current (DC) electricity is fed into a DC/AC inverter where it is converted to alternating current (AC) electricity and this AC electricity is connected to a 3-phase AC motor.
For electric trains, forklift trucks, and some electric cars, DC motors are often used. In some cases, universal motors are used, and then AC or DC may be employed. In recent production vehicles, various motor types have been implemented, for instance: Induction motors within Tesla Motor vehicles and permanent magnet machines in the Nissan Leaf and Chevrolet Bolt.
Configurations and Blocks Used
There are Numerous blocks used in this Model. Some of the blocks are joined together to make a Subsystem as well. These blocks can either be simscape or physical system blocks.
1. Vehicle Body Block
This is the basic Block that we have used in the Model. This block consists of 4 tyres of the electric vehicle and a vehicle body.
Figure 2: Model of the vehicle body.
In this model wehave used a simple gear to connect with the Axles. The tyre has 4 inputs for them. These are
A - Axles
S - Slip
H - Hub
N - Normal Force
These tyres are then connected to the vehicle body.
The vehicle body as we can see in the figure 2 has various inputs that can be modelled for the vehicle to have a basic setup. It consists of
1. NR - Normal force Rear
2. NF - Normal Force Front
3. H - Hub Connection
4. V - Speed of the vehicle Body
5. beta - The grade if the vehicle has
In this model i have put wind velocity at a constant of 2m/s and the grade to be a constant zero throughout the cycle.
In the vehicle body model we have connected a simple gear system to transmit the power from the motor to the wheels. This gear has a specific gear ratio that is predefined.
Figure 3:Gear Ratio
Figure 4: Vehicle Body Parameters
2. Motor
For this Model i have used a simple brushed DC Motor.
After researcching on the internet i found some documents that bhelped me understand the meaning of the terms that are important for a DC Motor.
a. Armature Inductance:
The inductance i.a. of armature is the reason why the power of a motor can be smaller than the product of RMS voltage and RMS current, and a power factor needs to be applied.
This basically means that the armature inductance governs the amount of power required by the motor to be delivered to the wheels. This power may be very small so as to move a vehicle or very high as to move the vehicle at top speed. Basically armature is the moving part of the motor that produces the emf which then turns to power the motor.
b. Torque constant:
This is basically the torque a motor is limited to produce in an hour.
Figure 5: DC Motor Parameters.
3. PWM Averaged Model
For any Motor to run we need a controller to control the voltage and current supply from the battery. For this model i have used a PWM averaged model that takes the input from the duty cycle and feedback from a longitudinal driver.
This averaged model also consists of ports for connections of the battery pack and the motor.
Figure 6: PWM Averaged Block
In this block we have used Controlled voltage and current source for the motor output. A voltage sensor has also been used here for sensing the battery voltage at any given point in time. One of the connection port leads to an output to the duty cycle through the driver model.
4. Longitudinal Driver
This Model consists of the commands that a driver will give to the vehicle and based on those commands the various scopes are added to monitor the output from the driver. This Block is called as a longitudinal Driver.
Figure 7: Longitudinal Driver
This block takes various parameters as reference to the vehicle. Like Velfdbk and velref.
VelRef takes the input from the drive cycle that we use for the simulation. For this simulation of the electric vehicle we have used a UDDS Cycle.
Figure 8: UDDS Cycle
5. Battery Pack
For this Electric Vehicle Model i have used a Lithium Ion discharge Charge Battery. This Battery has many sensors such as temperature Sensor SOC condition Etc.
Figure 9: Battery Pack Created
For this Battery Pack we have also some parameters set that make this battery pack suitable for our Electric Vehicle.
Figure 10: Battery Parameters
RESULTS
1. For the results we have attached many output capturing scopes in the model. For these outputs we need to make sure that we have the proper connections.
We have used a Normal Body subsystem that has two outputs connecting to the motor and to a feedback scope.
Figure 11: Body to motor Connection
In the above figure we can see that the body is connected to the motor via the rotor output. This R output is connected to the simple gear we have used in the body subsystem. The cage is connected to a mechanical reference so as to show the stationary nature of the motor. The speed connection of the motor is then connected to a scope and to a integrator and a divider block that gives us the distancce output that the vehicle will run for the given drive cycle.
NOTE: For the UDDS Drive cycle the Vehicle is running a distance of 12 Kms.
Figure 12: Distance the vehicle has travelled
2. When we move onto the Battery, there arer alot of areas where we can analyse the battery for better results.
Some of the areas i have covered in the results for this analysis.
I have used a temperature measurement block that takes the input of ambient temeperatures of the battery and applied a scope to the output to check the thermal management of the battery.
For an average battery under constant operation it should heat upto a maximum of 45 degrees for charging and 60 degrees for discharging. For this battery pack the discharging temperature reached upto a maximum for 52 degrees.
Pertaining to the fact that this result is more than sufficient for the analysis we need to consider that the result is for a particular drive cycle and a nominal speed.
We can check the varying discharge temperature using other drive cycles or using a signal builder where we can subject the battery to high speeds.
Figure 13: Battery Temperature Rise For the Drive Cycle.
3. For the State of charge, We can observe some dips and some constant regions. These Dips are mainly observed on acceleration feedback from the longitudinal driver to the PWM averaged block and to the Battery.
The constant regions in the SOC graph are the areas where the battery is in regenerative braking or in the deceleration feedback mode. The ups in the graphs are due to charging of the battery.
Regenerative braking is an energy recovery mechanism that slows down a moving vehicle or object by converting its kinetic energy into a form that can be either used immediately or stored until needed. In this mechanism, the electric traction motor uses the vehicle's momentum to recover energy that would otherwise be lost to the brake discs as heat. This contrasts with conventional braking systems, where the excess kinetic energy is converted to unwanted and wasted heat due to friction in the brakes, where the energy is recovered by using electric motors as generators but is immediately dissipated as heat in resistors. In addition to improving the overall efficiency of the vehicle, regeneration can significantly extend the life of the braking system as the mechanical parts will not wear out very quickly.
Figure 14: Battery SOC Reading
From the battery block we can also observe the current profile for the UDDS Cycle.
Figure 15: Cycle Current Profile
4. When we talk about the acceleration and deceleration of the graph cycle we know that the vehicle has accelerated or decelrated at many time stamps. Basiclly the driver has pressed the accelerator and the decelerator many times during the drive cycle. May be he was in a traffic situation where he needed to brake and move forward on simultanious occasions.
Figure 16: Acceleration and Deceleration data from the drive cycle
We can observe that the data is scattered due to the multiple uses of the throttle and brake.
Figure 17: Closer view of the acceleration and deceleration data
5. For the main output we have put a scope with two inputs. One input is the vehicle feedback and the other is the speed of the vehicle. For our simulation of the vehicle to run perfectly we need a match on the drive cycle for the position and the speed.
The maximum speed the drive cycle can attain is 93 Kmph.
Figure 18: Output Graph
From the graph we can see that the Drive cycle (Upper window) is almost identical to the speed output we get from the simulation.
We can also observe some noise in the speed graph.
Figure 19: Noise in speed graph in comparison to the cycle graph
This noise is observed due to the wind speed we have mentioned in the vehicle body subsystem. For a normal drive cycle the wind velocity is neglected but we have taken into account a 2 m/s wind velocity for our simulation. Due to the hinderence caused by the wind in the motion, our vehicle tries to keep the graph at a constant with compliance to the drive cycle. This is the reason why we observe such noise in the graph for our vehicle speed.
The model has been analysed in the simulation and the results have been mentioned.
Figure 20: Electric vehicle Model
CONCLUTIONS
The model has been made and the simulation has also been run. We can conclude that the model is depended on many factors like drive cycle, Battery modelling, Vehicle parameters etc.
These factors can be altered in the future to make a even more efficient electric vehicle that would run on more complex cycles with better battery management systems and an even more powerful motor.
A Note Of Thanks
I would like to take this moment and thank Ms. Shilpa Murali Maam who was by my side at every step of the way. She guided me through all the problems and doubts i faced during the modelling of this vehicle. The knowledge that i have gained from her is something that i once thought was difficult to grasp for a Mechanical engineer but with her guidance it all looked simple and easy at times. I wish to work with her in all my future EV Projects.
I would also like to thank Mr Vatsal Shah Sir for clearing our doubts and helping us create a better understanding of the Electric vehicle and its various components. Not only did he gave Repeated sessions but took indivisual doubts so that we can work with our best knowledge.
The Link For the files is : https://drive.google.com/open?id=1FWLaQ0ZPkBjA3cORB4vIf9VANfn-hkRg
- Aamer ShaikhHello, Link for file is not valid