FINAL INDEPENDENT PROJECT
3D Robotic arm forward kinematics using MATLAB with data parsing by user input:
The robotics is one of the emerging technologies in current world . robots are widely implemented in different fields like manufacturing , medical , construction , defence , teaching , hospitality , managementnuclear plant , azardous places etc.
The robots are backbone of automation hence study of motion of robot is necessary . study of motion of a robot is prity easier by using MATLAB.here we use matlab to calculate forward kinematics of 3 link robotic arm manipulator.
AIM OF PROJECT:
the aim of project is to take geometry data 3dof arm from user input also range of angel as well as precision of simulation and give output as movie file.
which is more feasible.
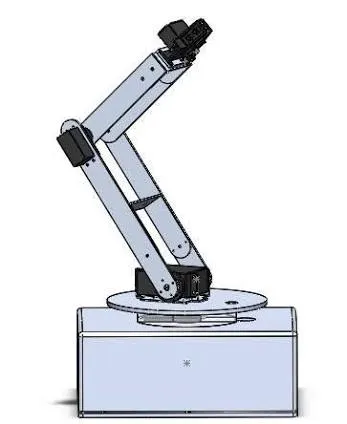
Construction of robotic manipulator:
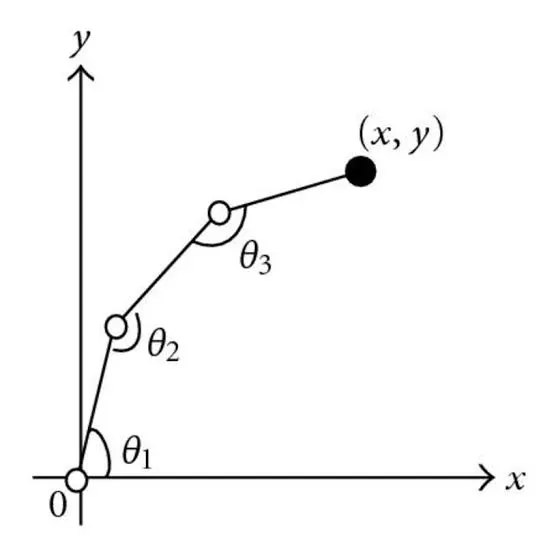
1. Long link L1 = 1mtr
Angle from x axis = theta1
2. Short link L2 = 0.5mtr
Angle from x axis = theta2
3 end effector length L3=0.25
Angle from x axis=theta3
Geometry:
Mathematical calculation:
x0 =0
y0 =0
x1 = l1*cosd(Theta1)
y1 = l1*sind(Theta1)
x2= x1 + l2*cosd(Theta2)
y2= y1 + l2*sind(Theta2)
x3= x2 + l3*cosd(Theta3)
y3= y2 + l3*sind(Theta3)
MATLAB PROGRAM TO REPRESENT FORWARD KINEMATICS OF ROBOTIC MANIPULATOR:
clear all
close all
clc
%input
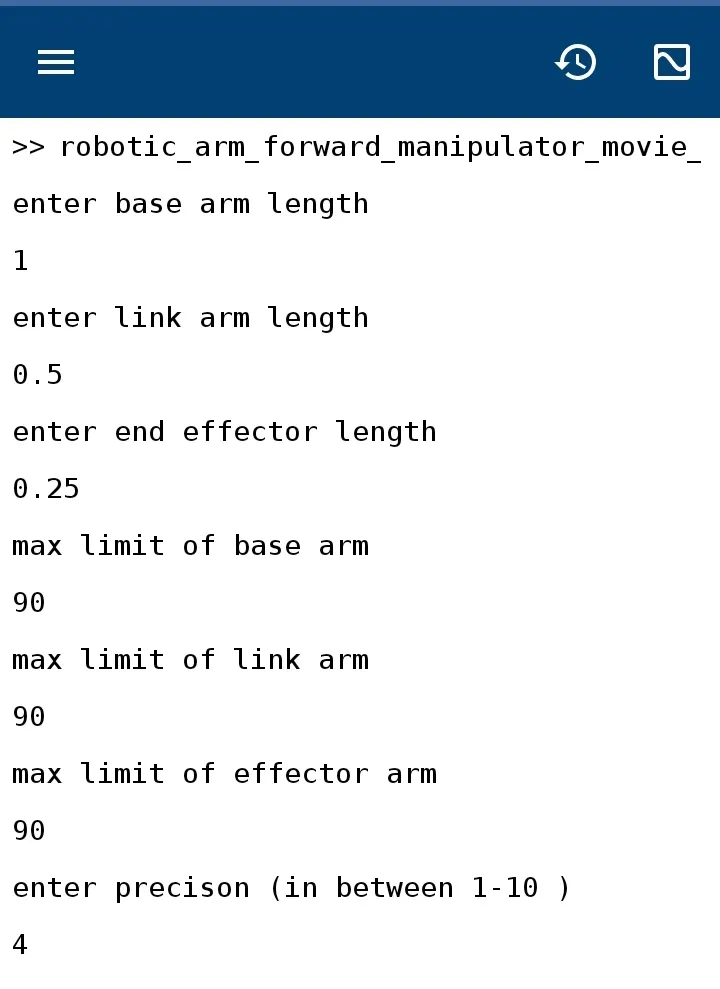
l1 =input('enter base arm length');
l2 =input('enter link arm length');
l3 =input('enter end effector length');
a=input('max limit of base arm');
b=input('max limit of link arm');
c=input('max limit of effector arm');
d=input('enter precison (in between 1-10 )');
theta1 =linspace(0,a,d);
theta2 =linspace(0,b,d);
theta3 =linspace(0,c,d);
ct=1;
for i=1:length(theta1)
    Theta1=theta1(i);
   for j=1:length(theta2)
    Theta2=theta2(j);
      for k=1:length(theta2)
          Theta3=theta3(k);
 %coordinate
          x0 =0;
          y0 =0;
          x1 = l1*cosd(Theta1);
          y1 = l1*sind(Theta1);

          x2= x1 + l2*cosd(Theta2);
          y2= y1 + l2*sind(Theta2);

          x3= x2 + l3*cosd(Theta3);
          y3= y2 + l3*sind(Theta3);
          grid on
%plotting
          plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],[x2 x3],[y2 y3],'linewidth',3)
          axis([-0.1 1.5 0 1.5])
          pause(0.03)
          M(ct) = getframe(gcf);
          ct = ct+1;
      end
   end
end
movie(M)
videofile = VideoWriter('forward kinematics.avi','uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
user input:
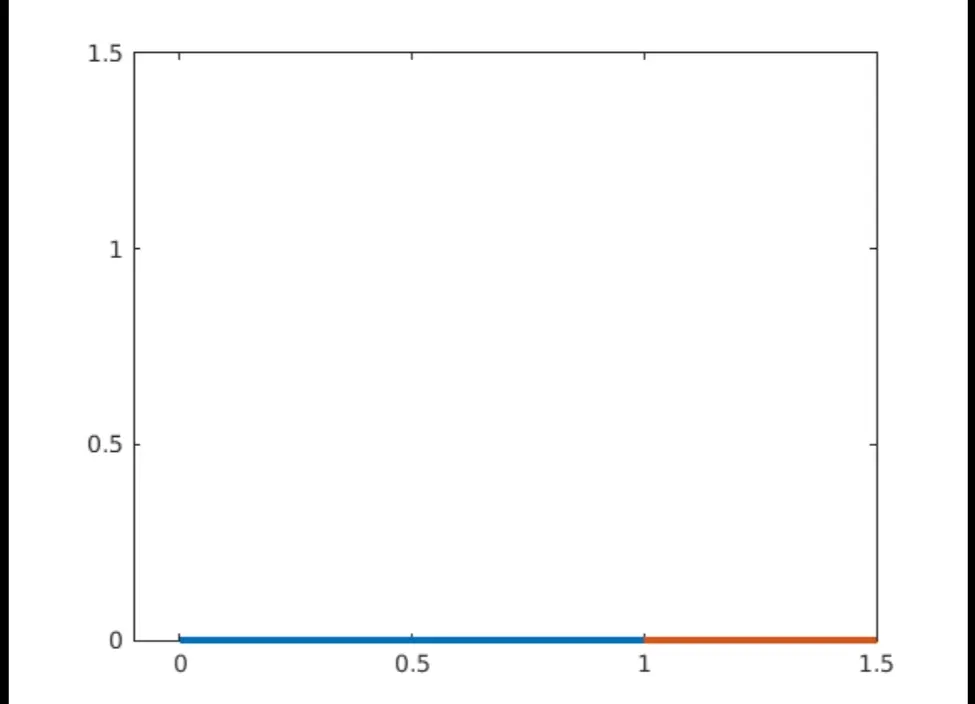
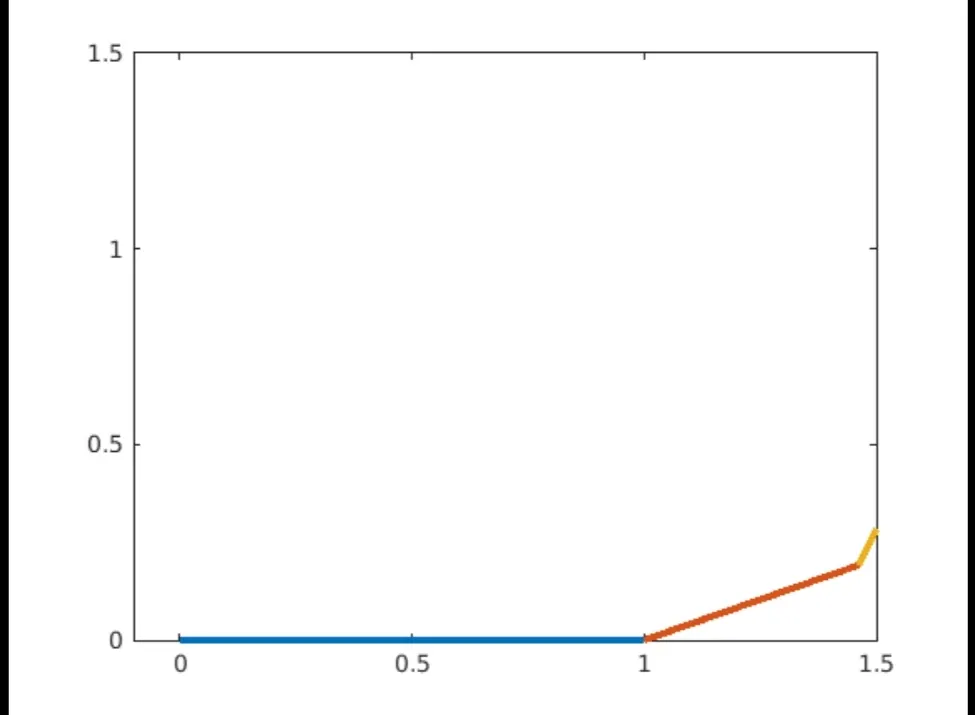
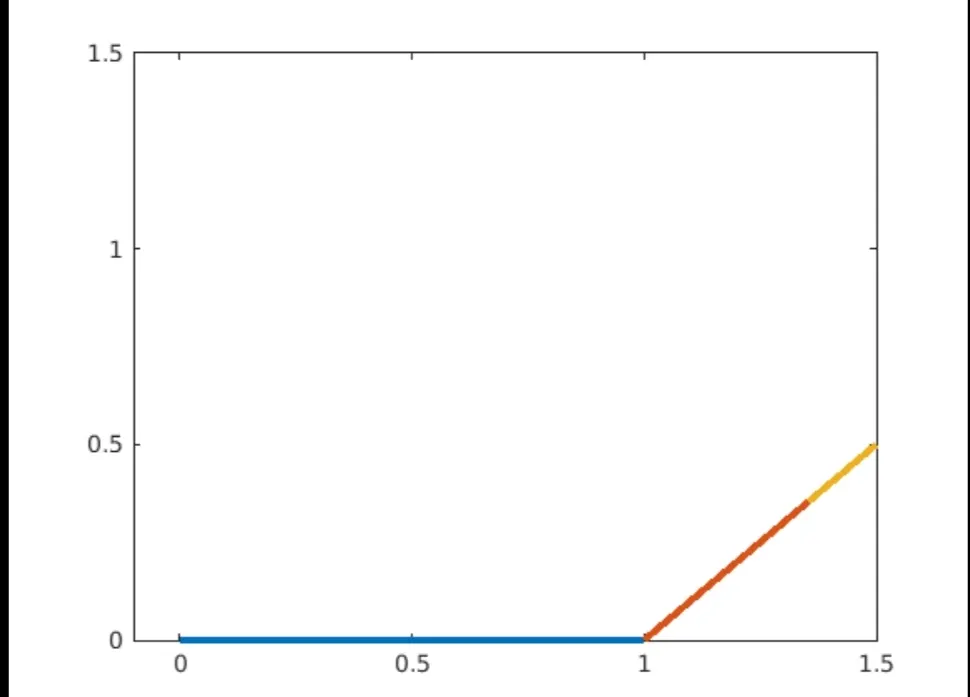
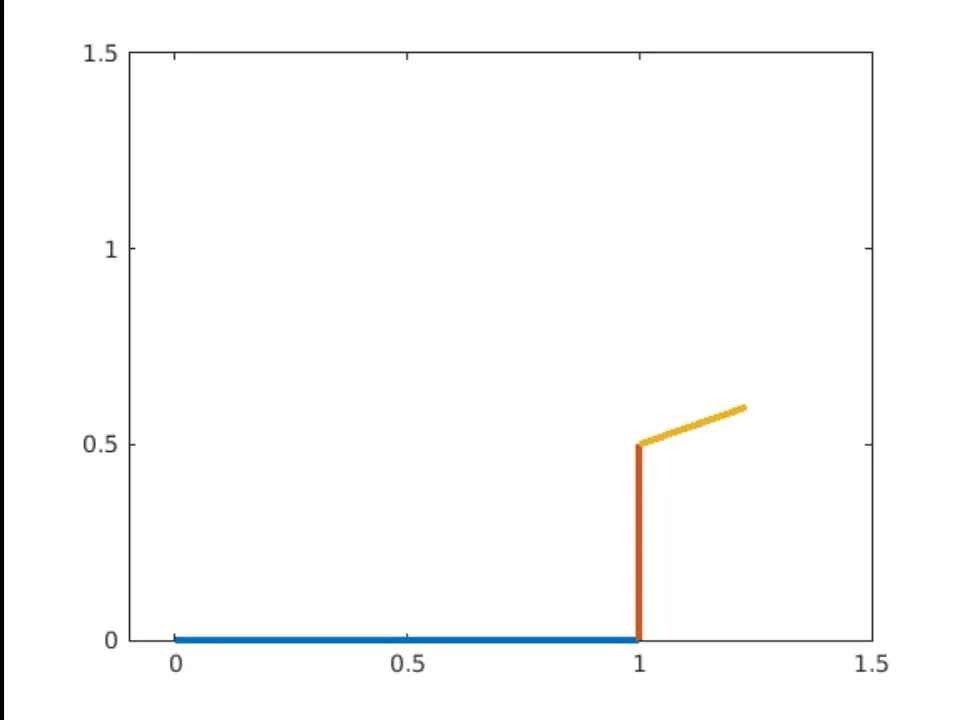
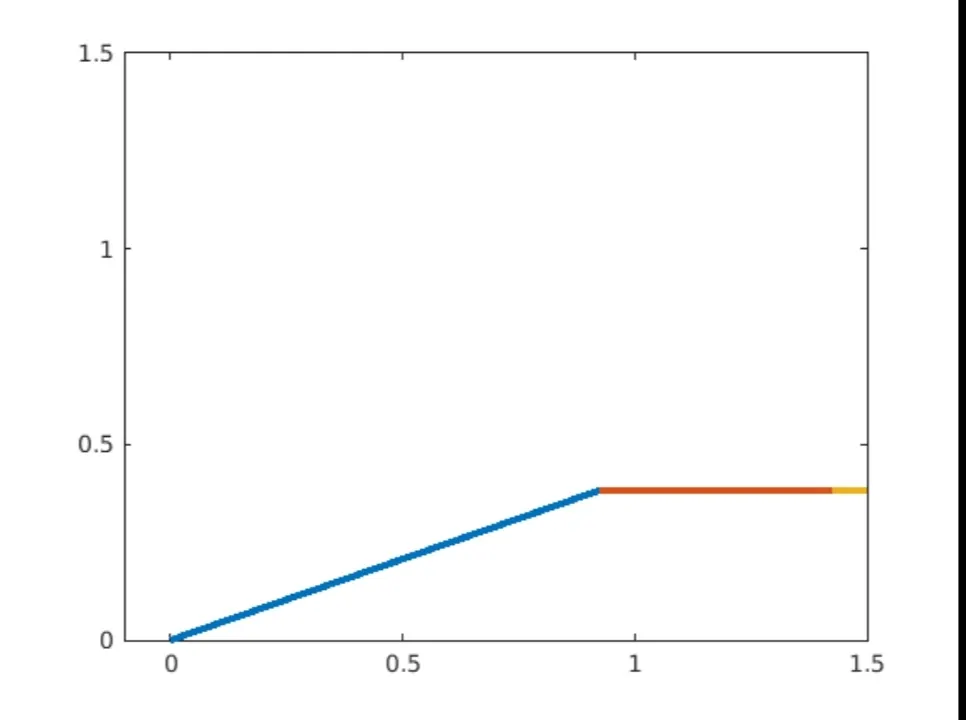
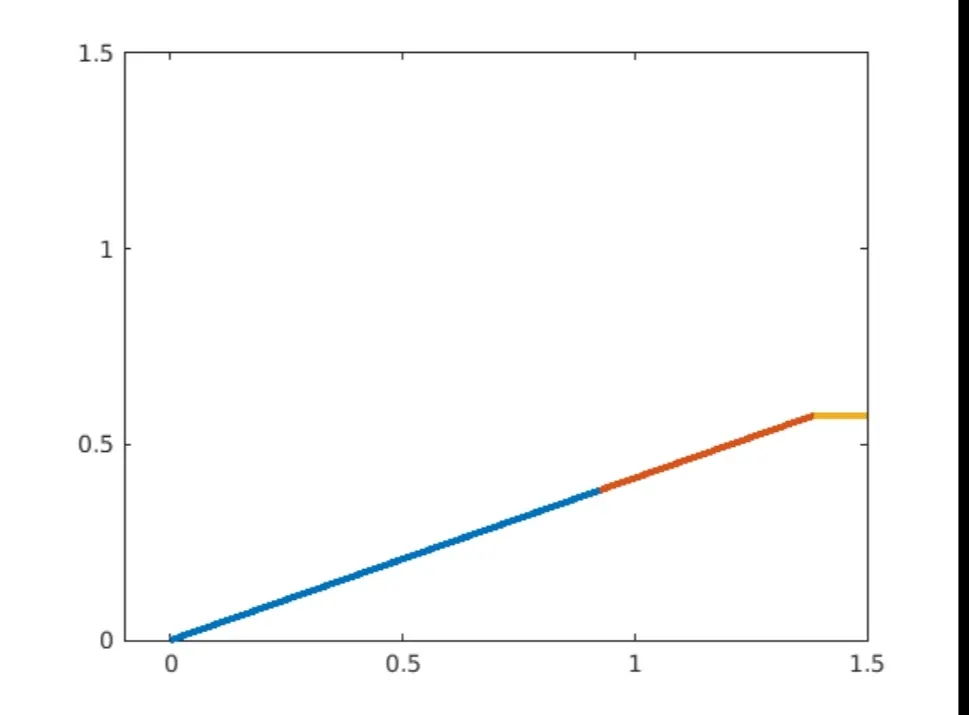
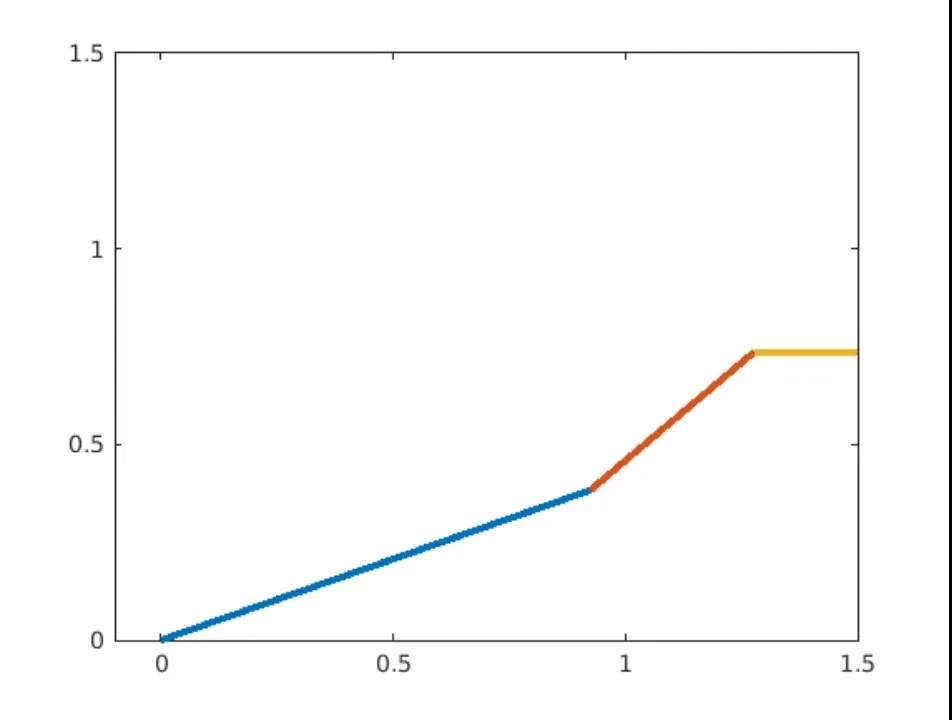
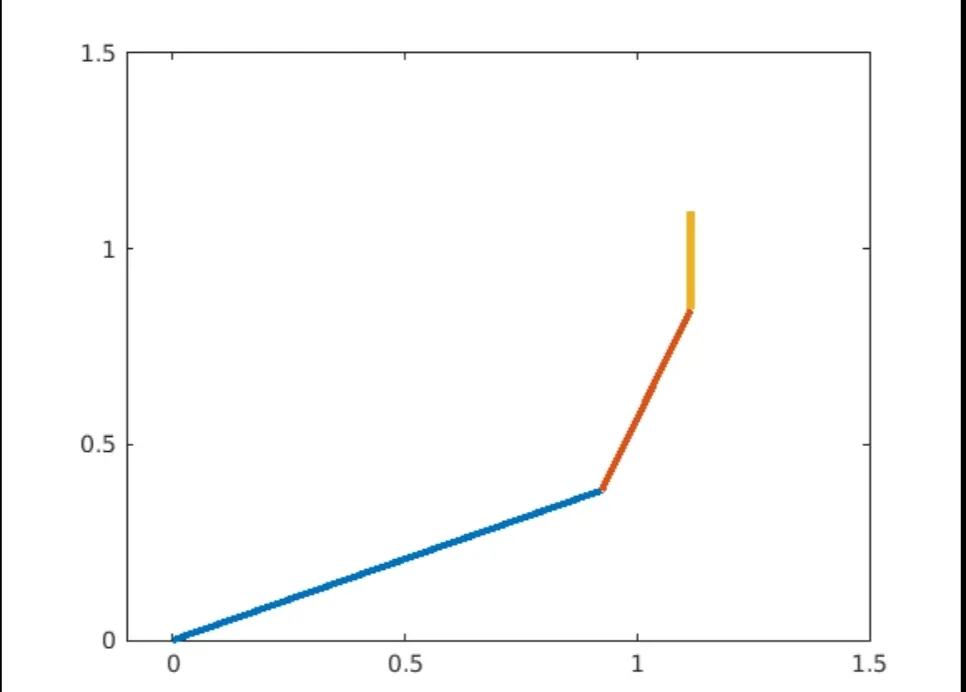
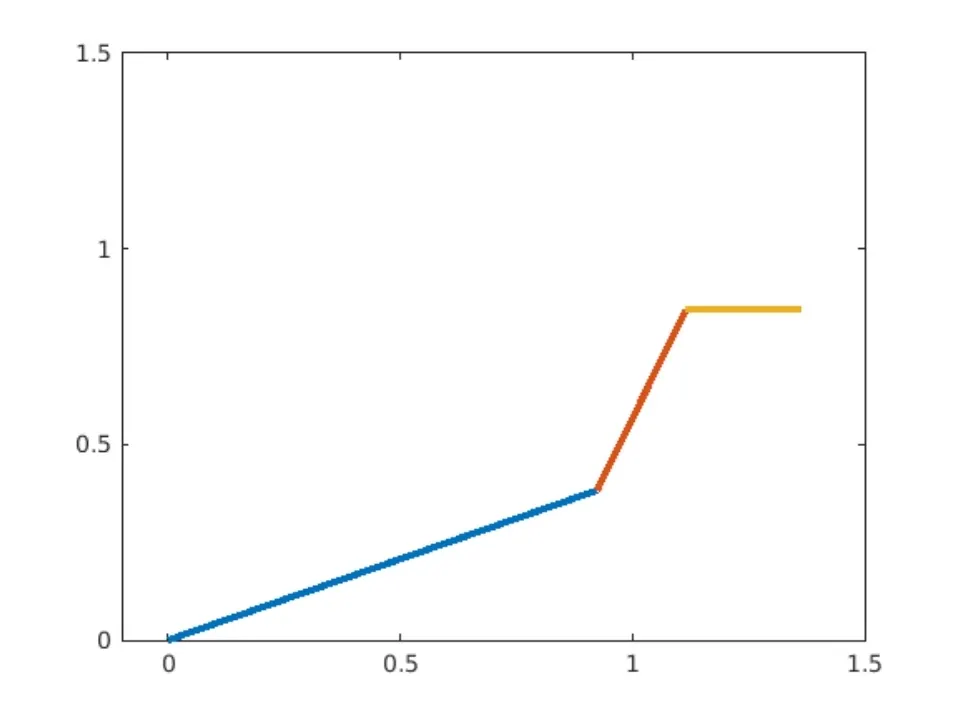
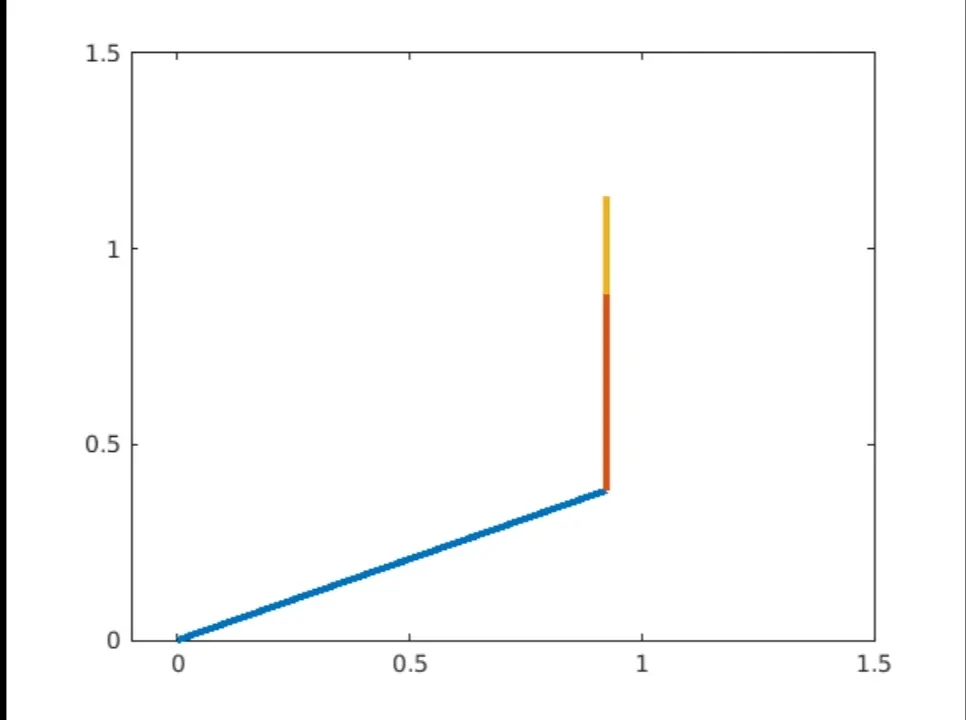
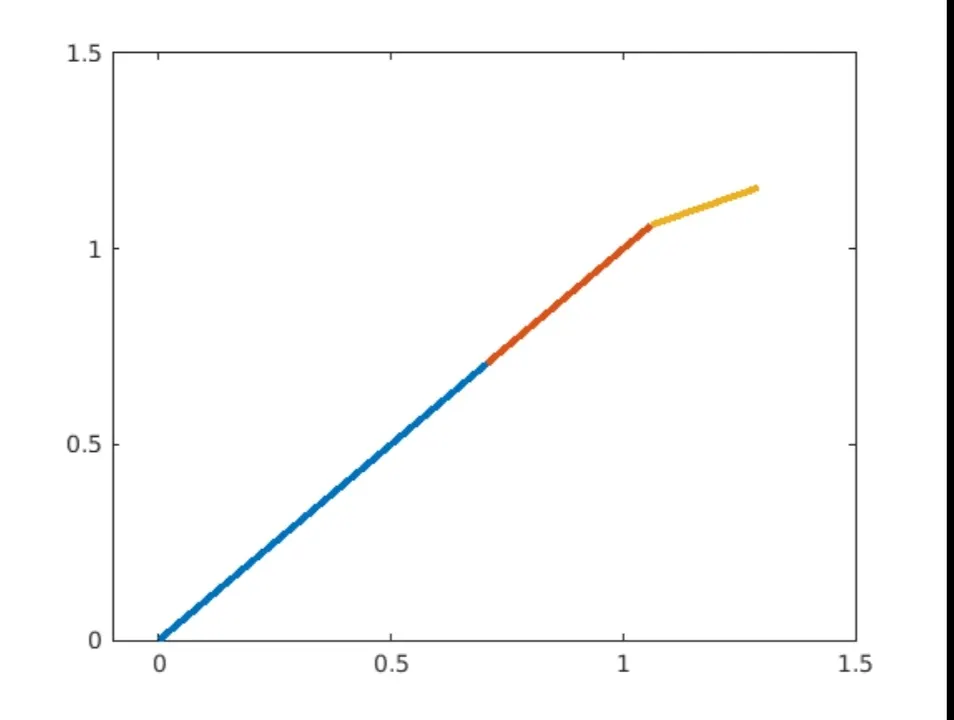
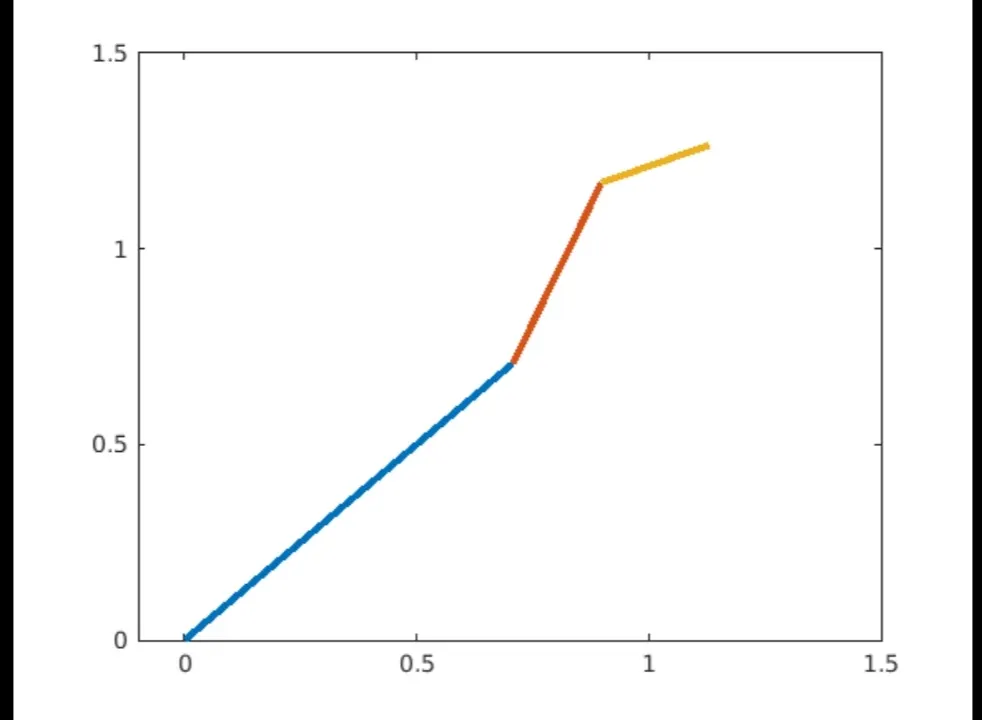
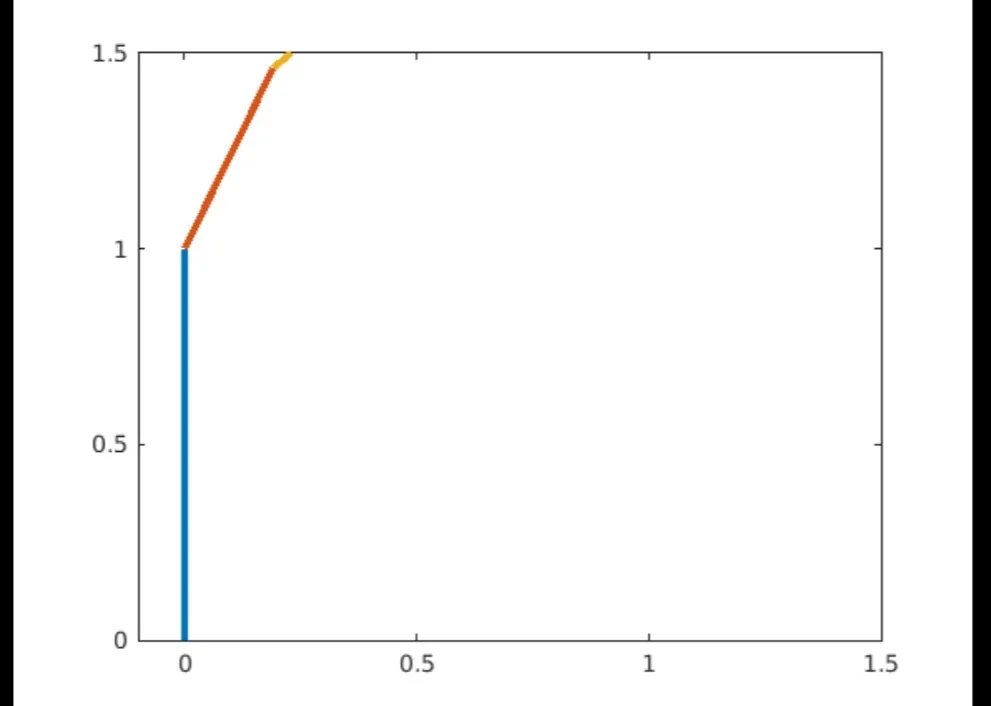
snapshot of the project:
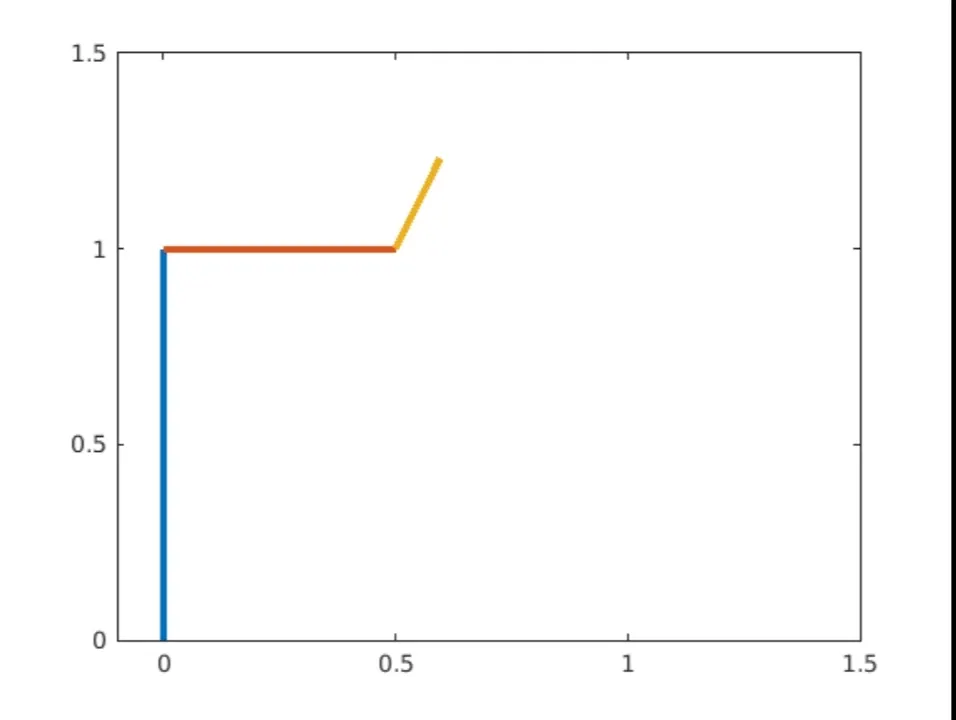
EXPLANATION OF CODE:
1. Firstly we define some inputs in form of length of link's and angle of inclination theta1 theta2 and theta3.
2.then we use theta to store a list value define under a range of angle and intervels.
3.the three for loop are applied to take different values of theta one by one.
4.a plot function is used to plot line joining both end cordinate of link's.
5.now we use movie command to pickup each frame of plot into a video in avi format.
CONCLUSION:
1.from above given example we understand about forward kinematics of the 3d manipulator .
2. The various plot obtained during analysis give brief overview about motion of arm's.