Frontal Crash of a NEON Dodge Model in FMVSS Regulation
Frontal Crash of a NEON Dodge Model in FMVSS Regulation
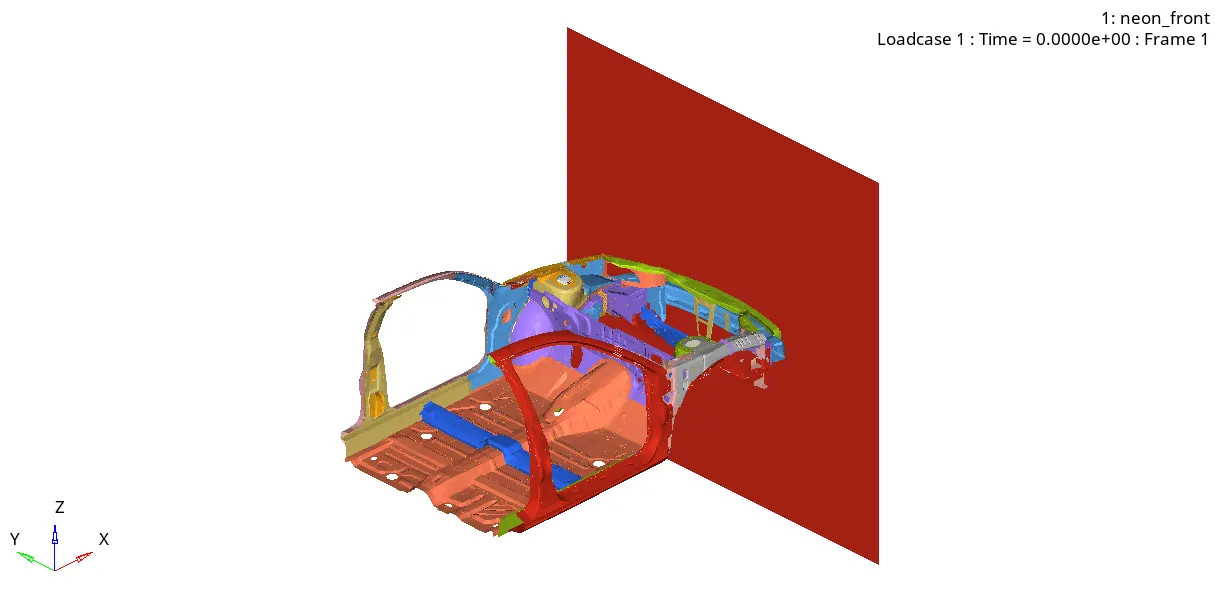
Objective:
In this project, the simulation is set up by creating a rigid wall for the model to impact mass balancing is done to achieve a target load of 700kgs and GC at a specified coordinate. Finally, the simulation is run and post-processed in HyperCrash. Various output results like axial forces on the rails from the bumper, short gun cross-sectional forces are studied by following questions and output requests.
Questions:
Frontal crash-BIW
- Check unit system and either follow (Mg mm s) or (Kg mm ms)
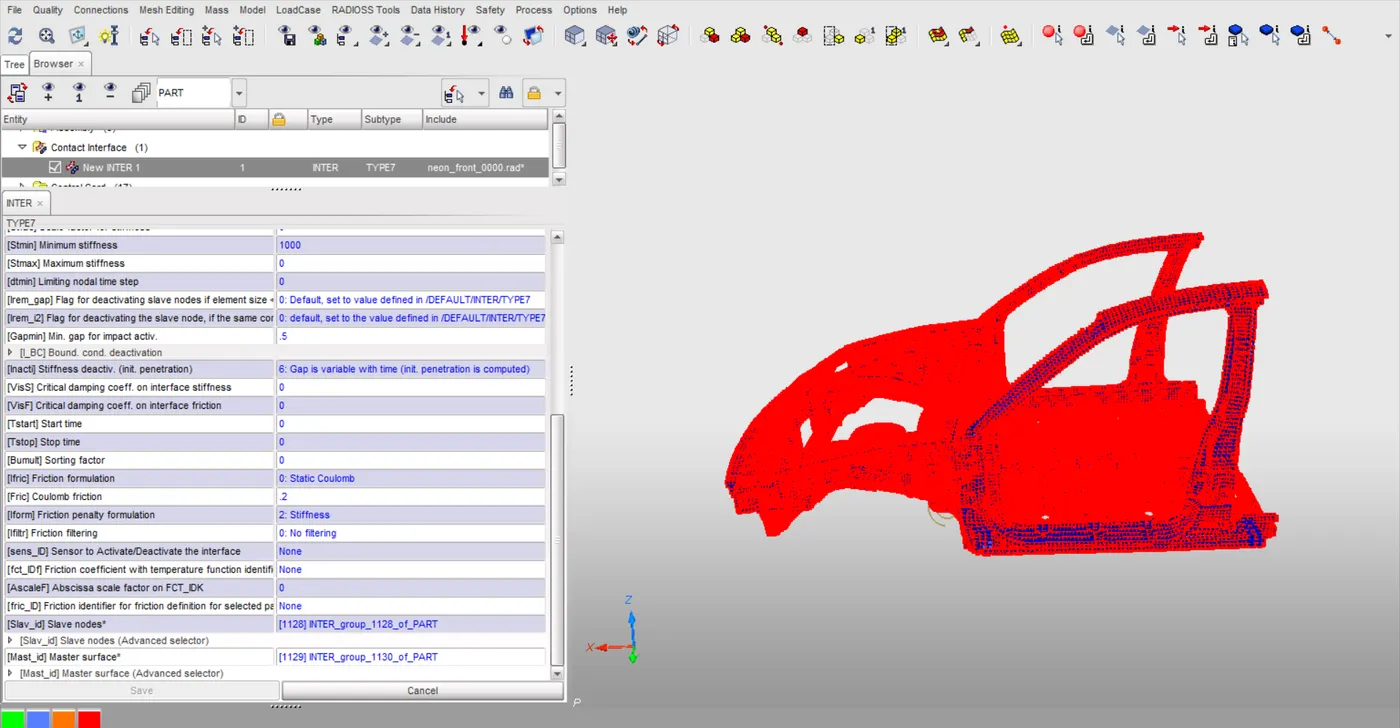
- Create appropriate interface, friction 0.2 and recommended parameters
- Make sure of no penetrations and intersection.
- Correct rigid bodies if any issues.
- Create rigid wall with friction 0.1.
- Compare the model weight with the full scale 300k nodes model and added mass to reach target weight 700kg while getting the CG about the required range.
- Initial velocity 35mph.
- Use model checker to ensure good quality.
- Time step 0.5 to 0.1 microseconds.
- Run 80ms.
Output requests:
- Sectional force in the rails at location of indicated node 174247.
- Axial force received on the rails from bumper.
- Shotgun cross sectional forces.
- A pillar cross section.
- Acceleration curve received on the accelerometer at base of B pillar (on B pillar rocker).
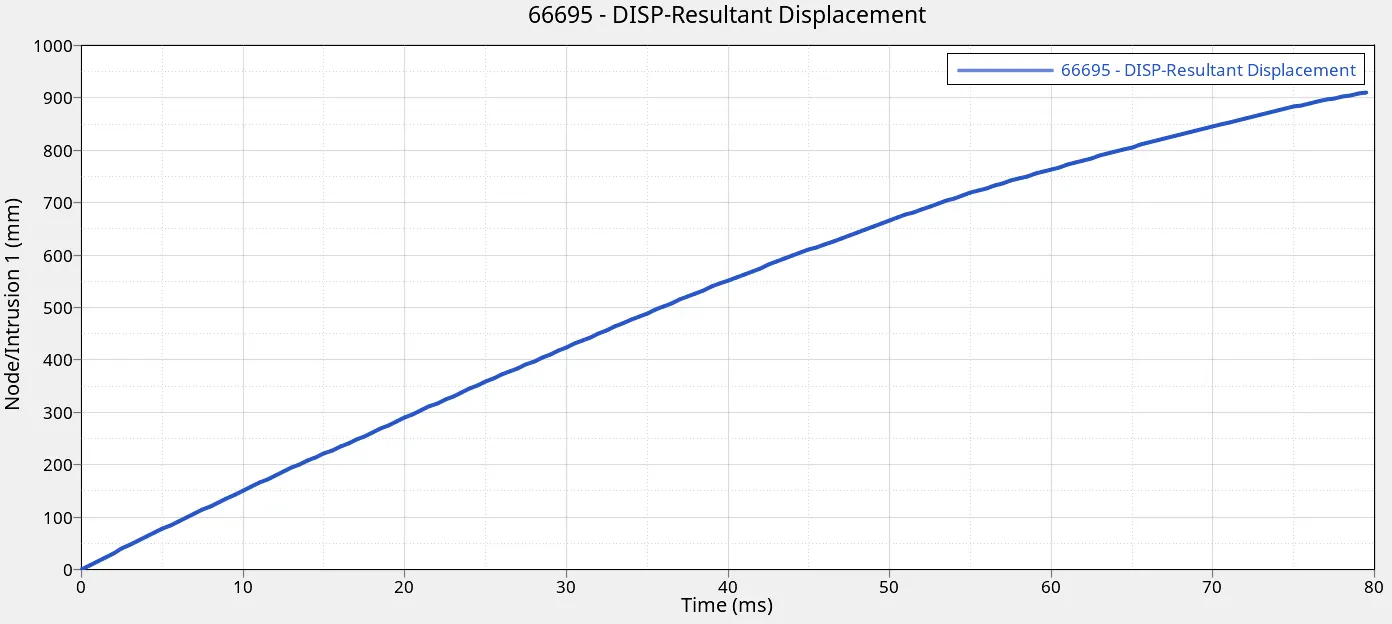
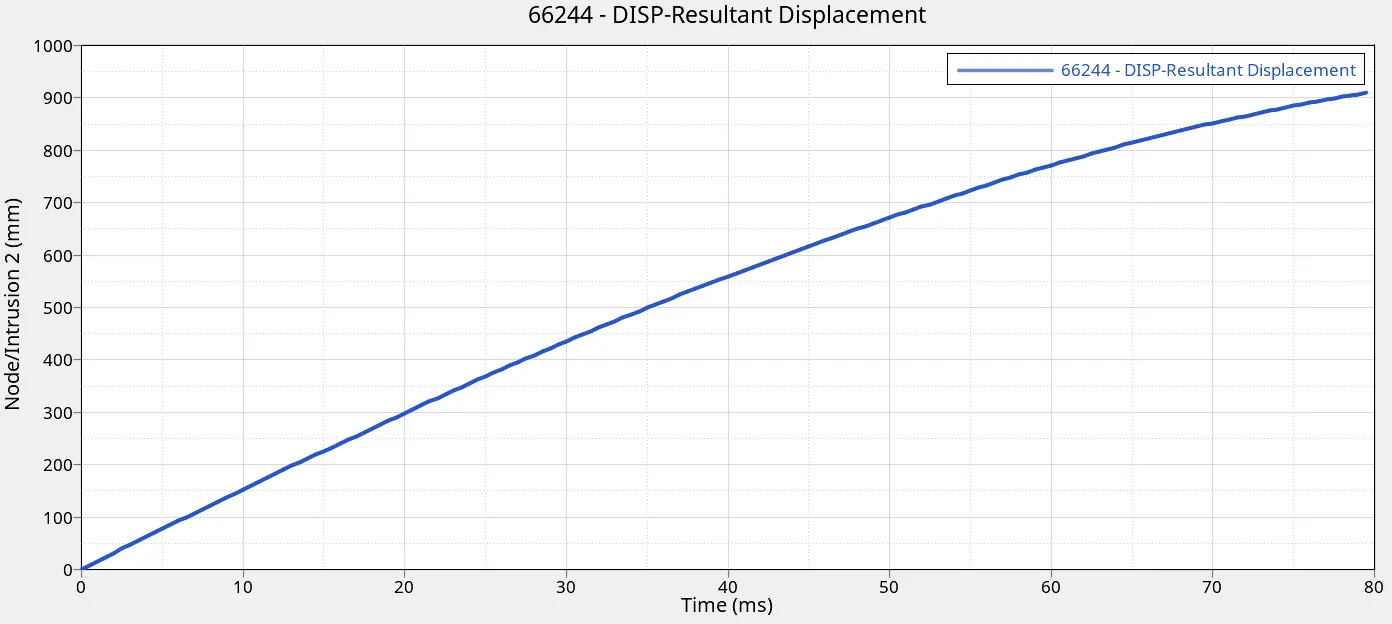
- Intrusions on the dash wall 66695, 66244.
Case set up and Execution with images:
Questions:
Frontal crash-BIW
1.Check unit system and either follow (Mg mm s) or (Kg mm ms)
Sol : To check the unit system open the given starter rad file neon_front_0000.Rad with a text editor and check the unit system which is followed.
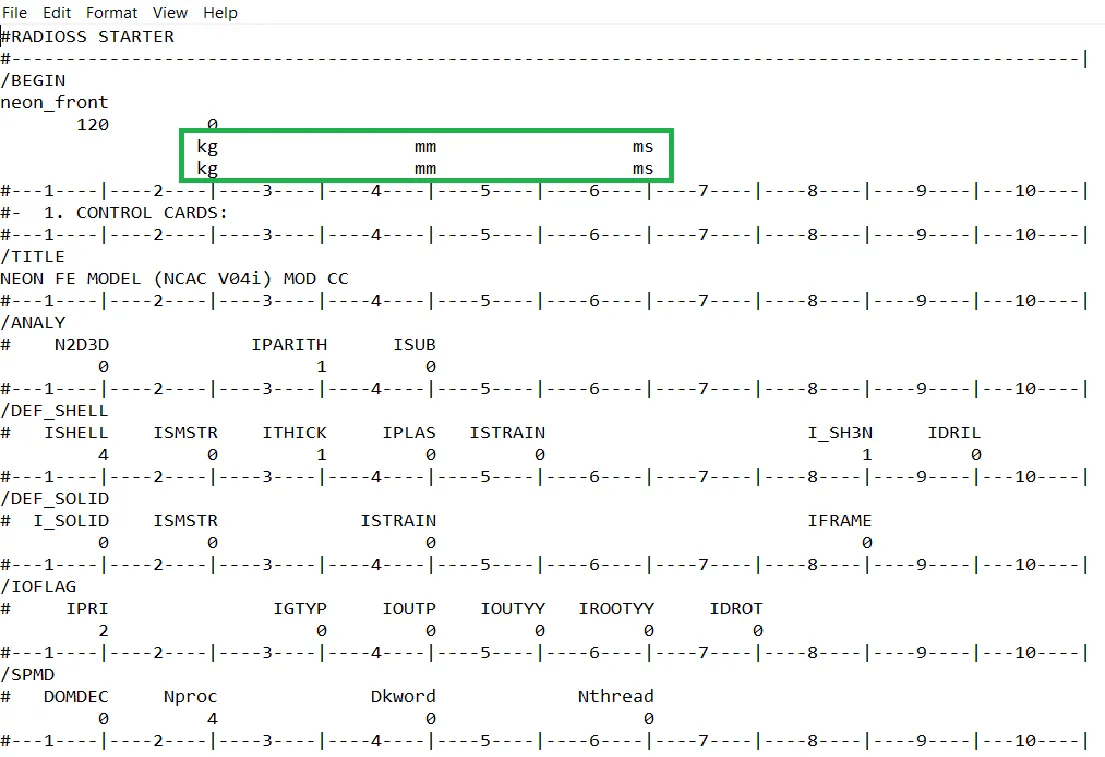
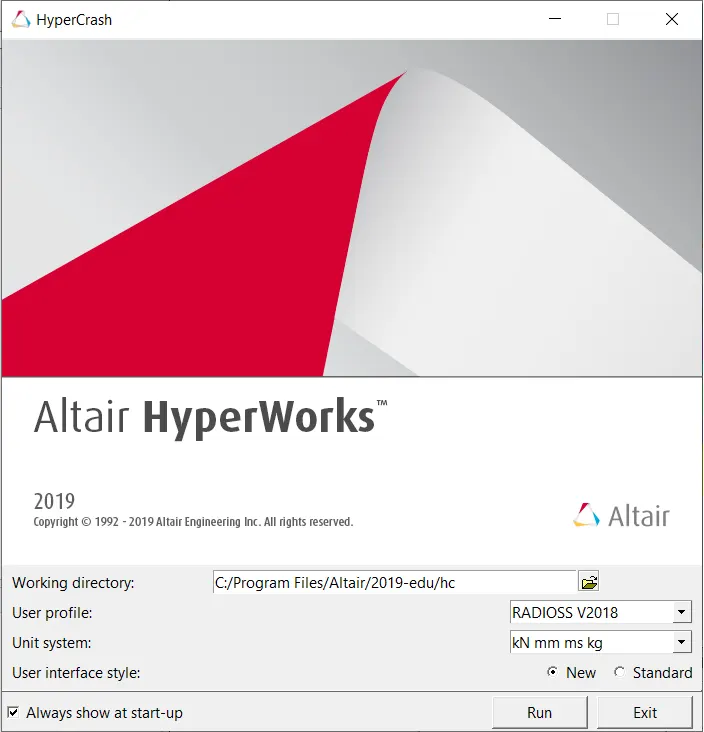
The unit system KN mm ms Kg is followed in this project because it is mostly used in industry and much more relevant to every day measurements.
2.Create appropriate interface, friction 0.2 and recommended parameters
Sol: Checking the given interface is created for entire component or not.
Open the given file in hyper crash review the contact interface applied to entire component or not by clicking the tick marks on the contact interface sub entities.
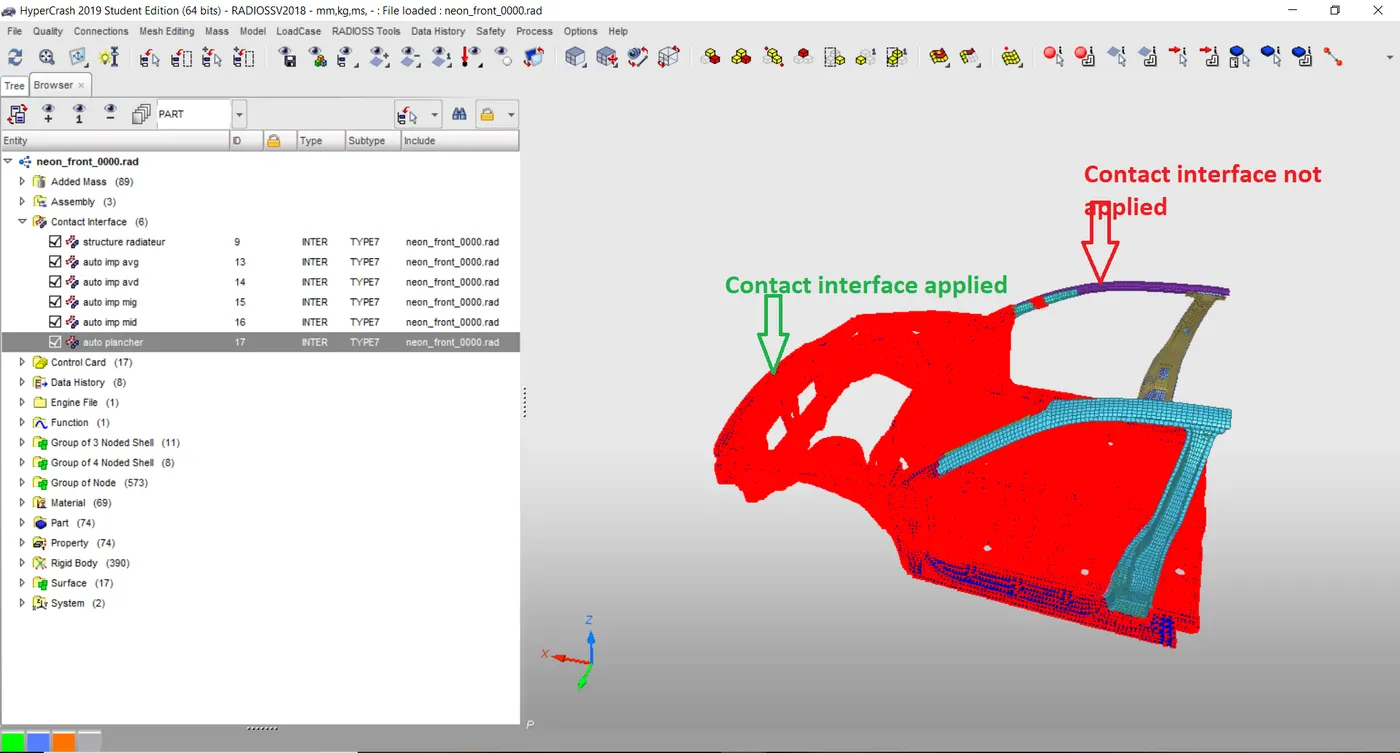
Hence, the contact interface is not applied for entire model we can recreate the contact interface for neon model by deleting the given interface.
Importing the new Contact interface into entity browser by right click and by create new>go to contact interface>choose best contact interface which is recommended for crash applications.
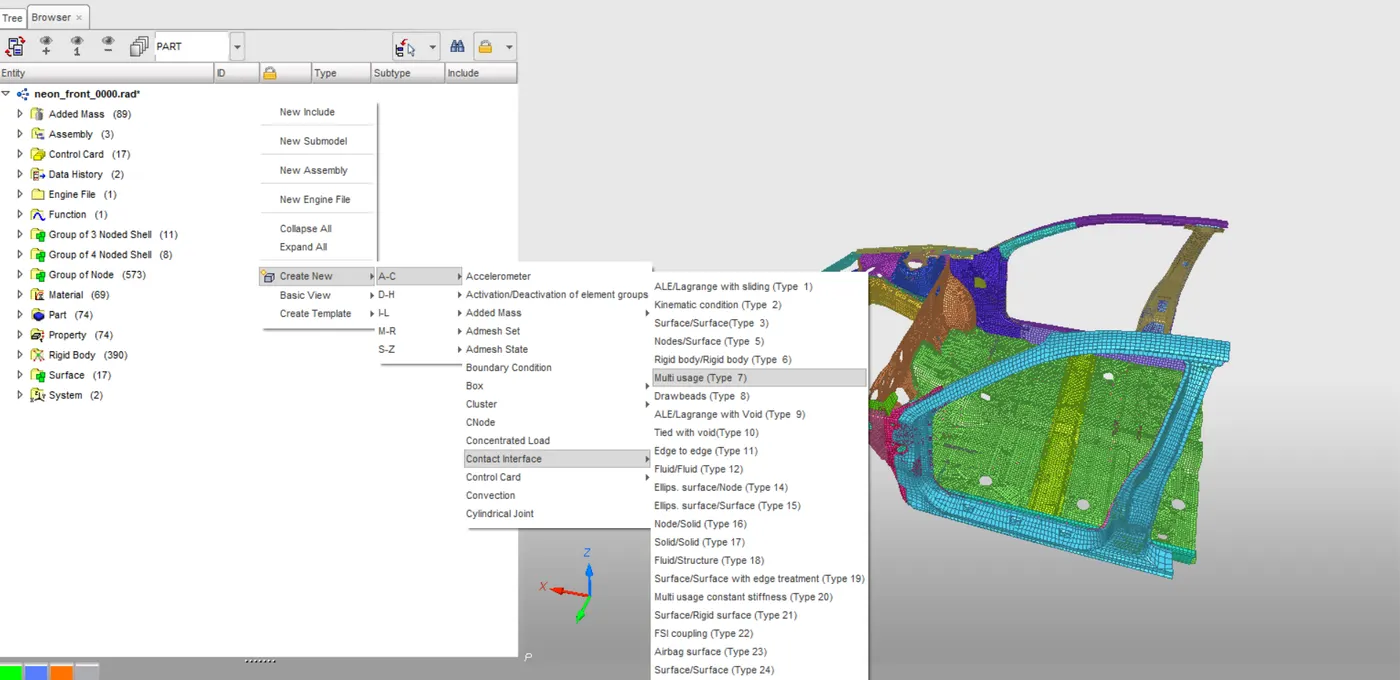
Creating contact interface 7 for all slave nodes and all master surface elements in the given model
3.Make sure of no penetrations and intersection.
Sol: To check the penetrations and interactions in the hyper crash click on the Quality option from menu bar and open the check all solver contact interfaces.
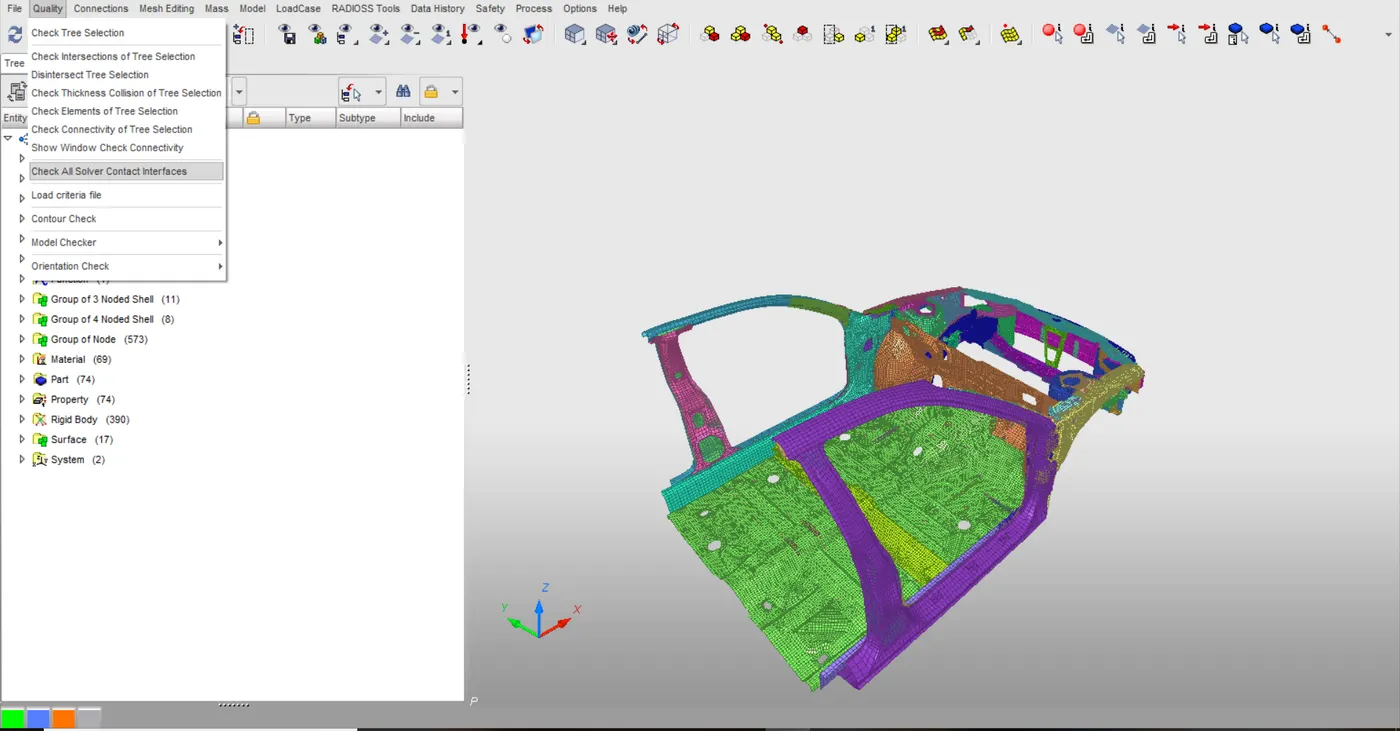
Checking the penetrations and intersections in Quality entity
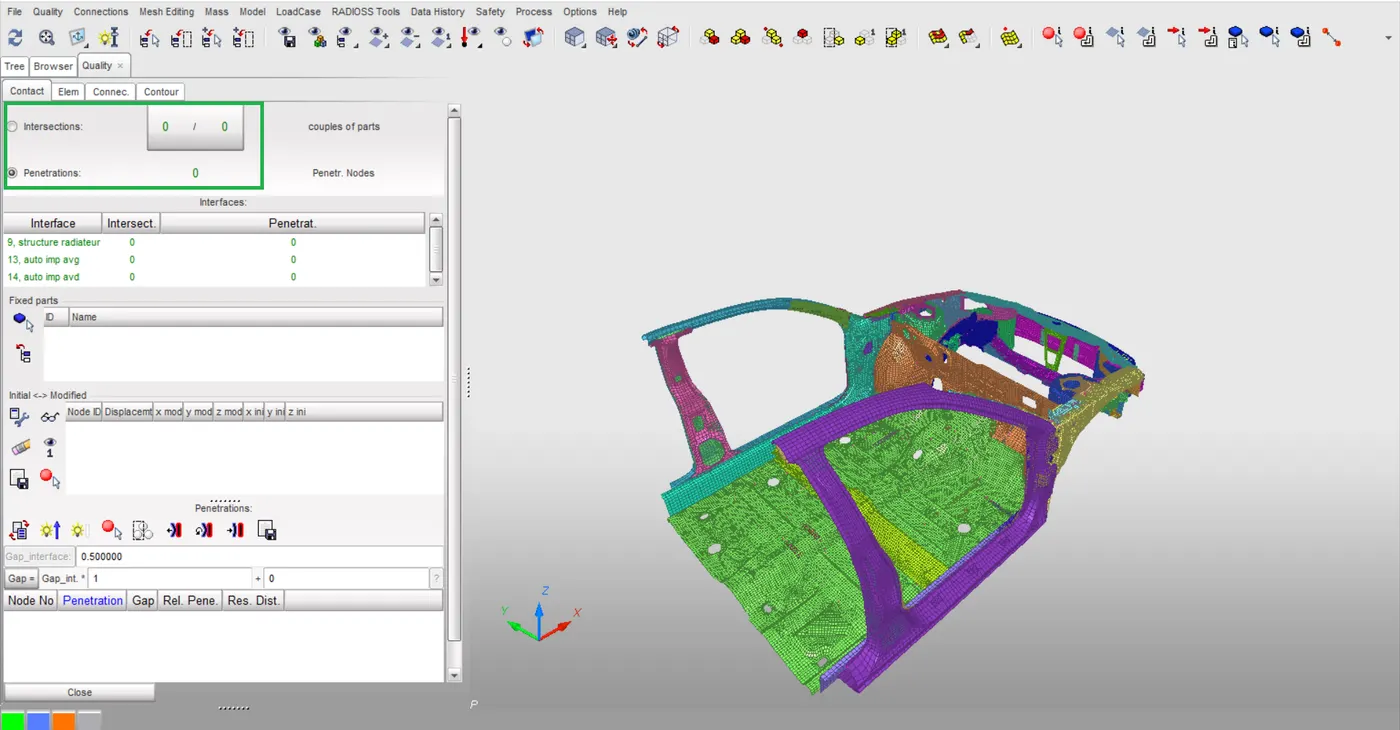
Hence, there is no penetrations and intersections available in the model.
4.Correct rigid bodies if any issues.
Sol: To check any issues in rigid wall in hypercrash open Quality>Model checker>Manage.
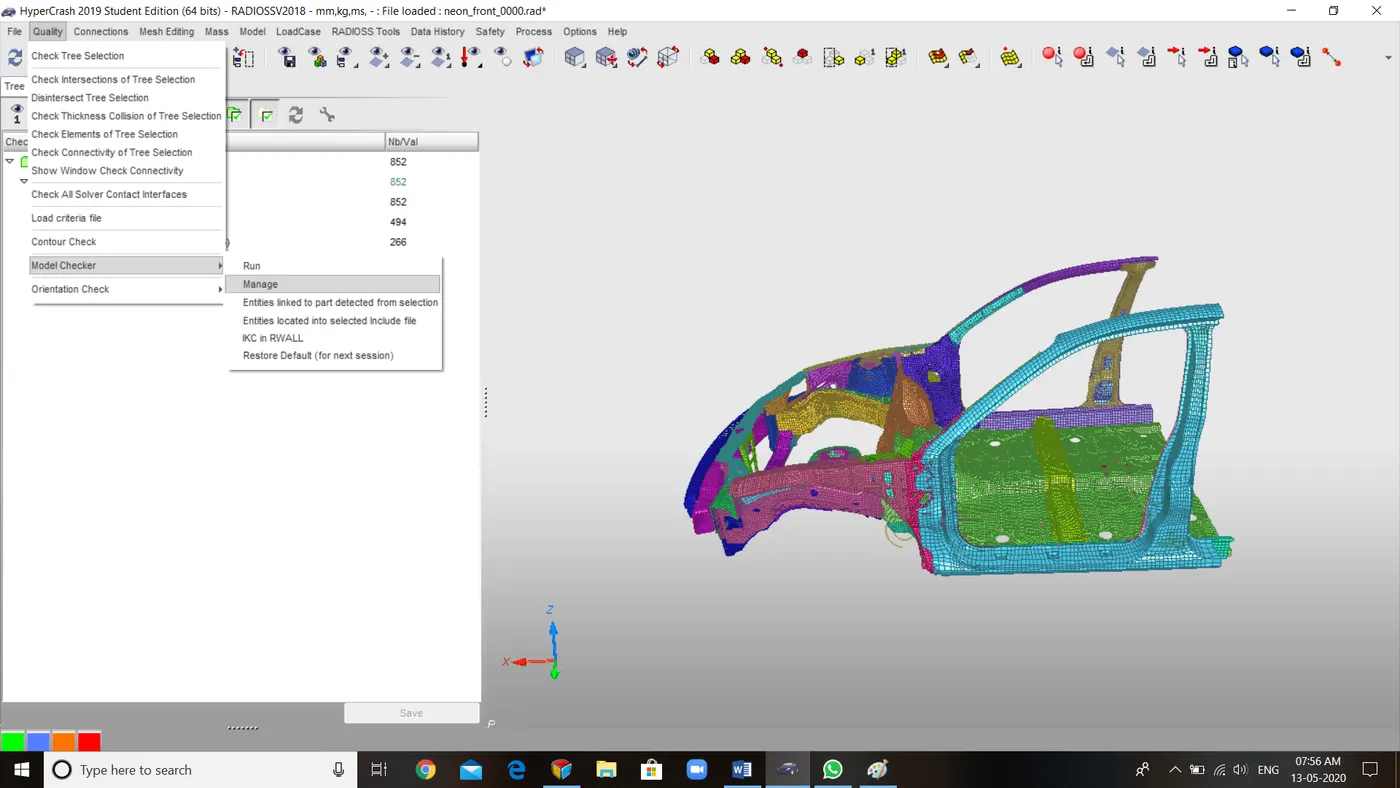
Checking the component any issues in rigid bodies
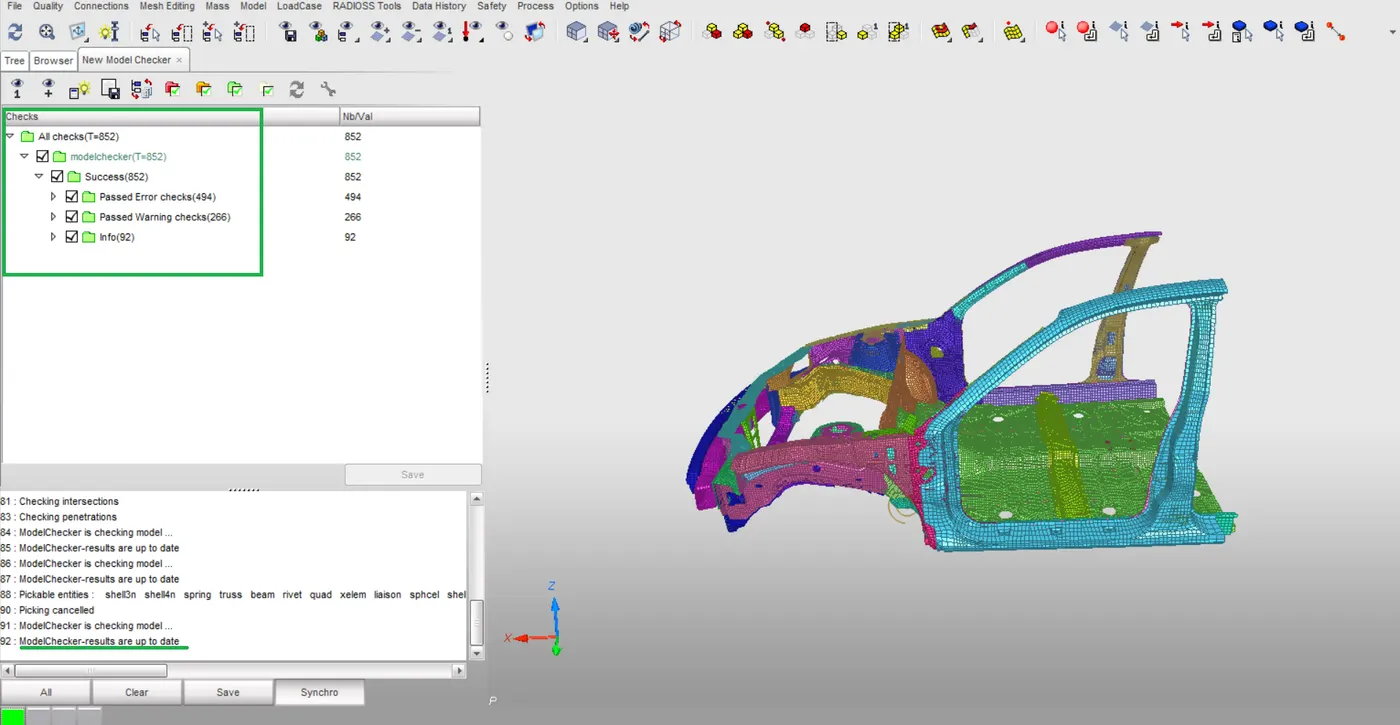
Hence, all entities in the model checker are in green color. So, there is no issues in rigid bodies.
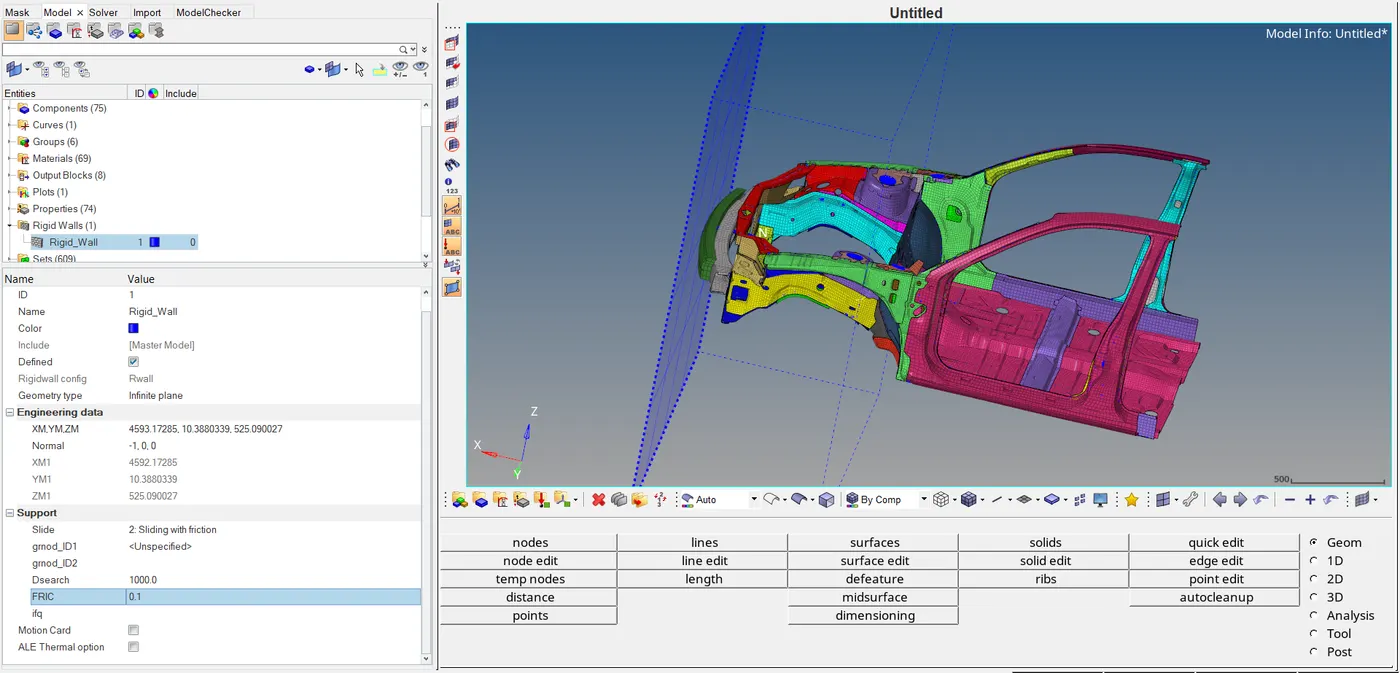
5.Create rigid wall with friction 0.1.
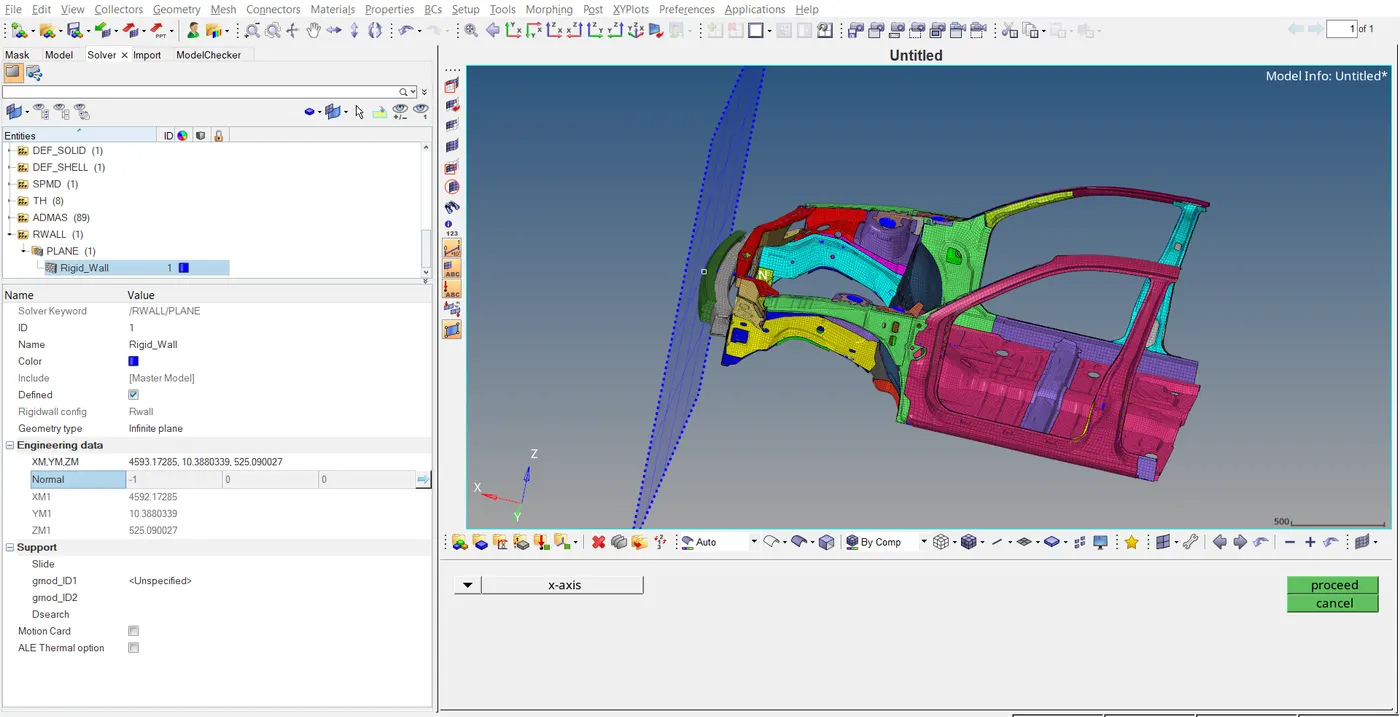
Sol: Creation of rigid wall entity in hypermesh followed by right chick in solver browser Create>RWALL>PLANE
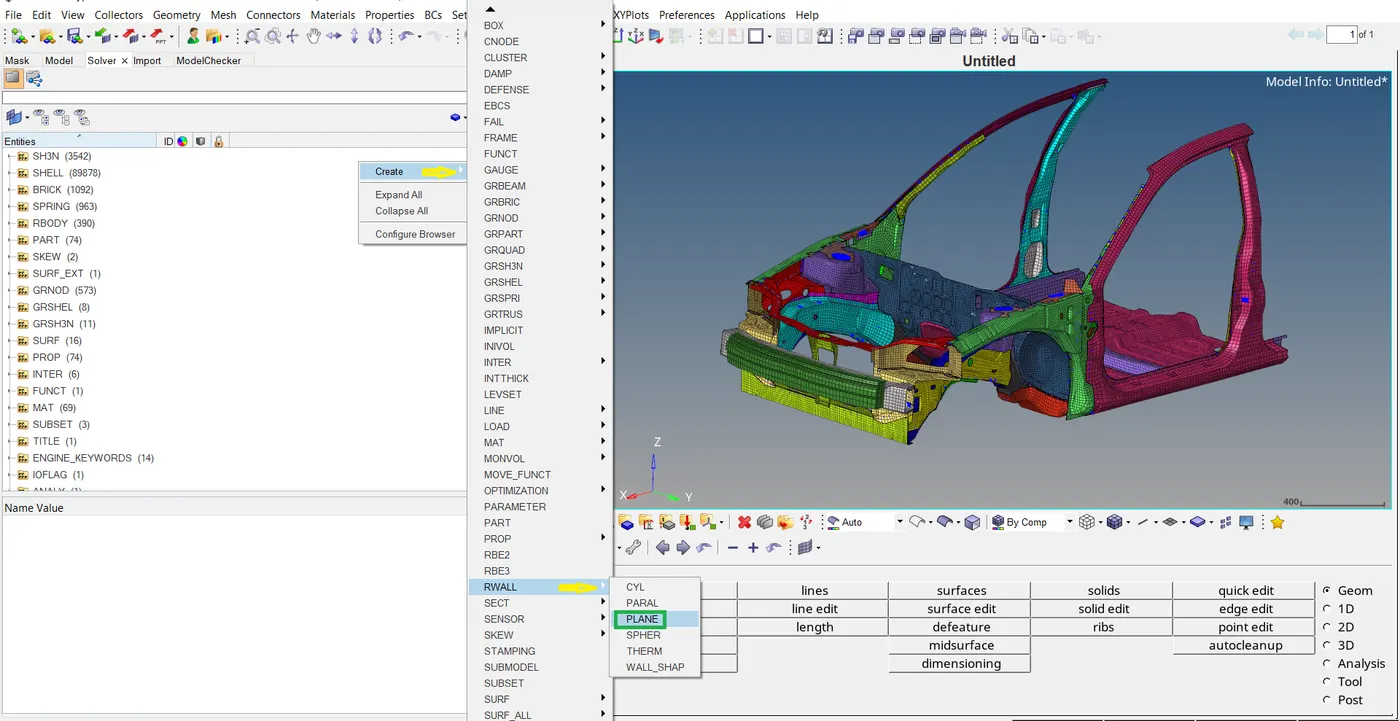
Then creating the base node M for x, y and z coordinates
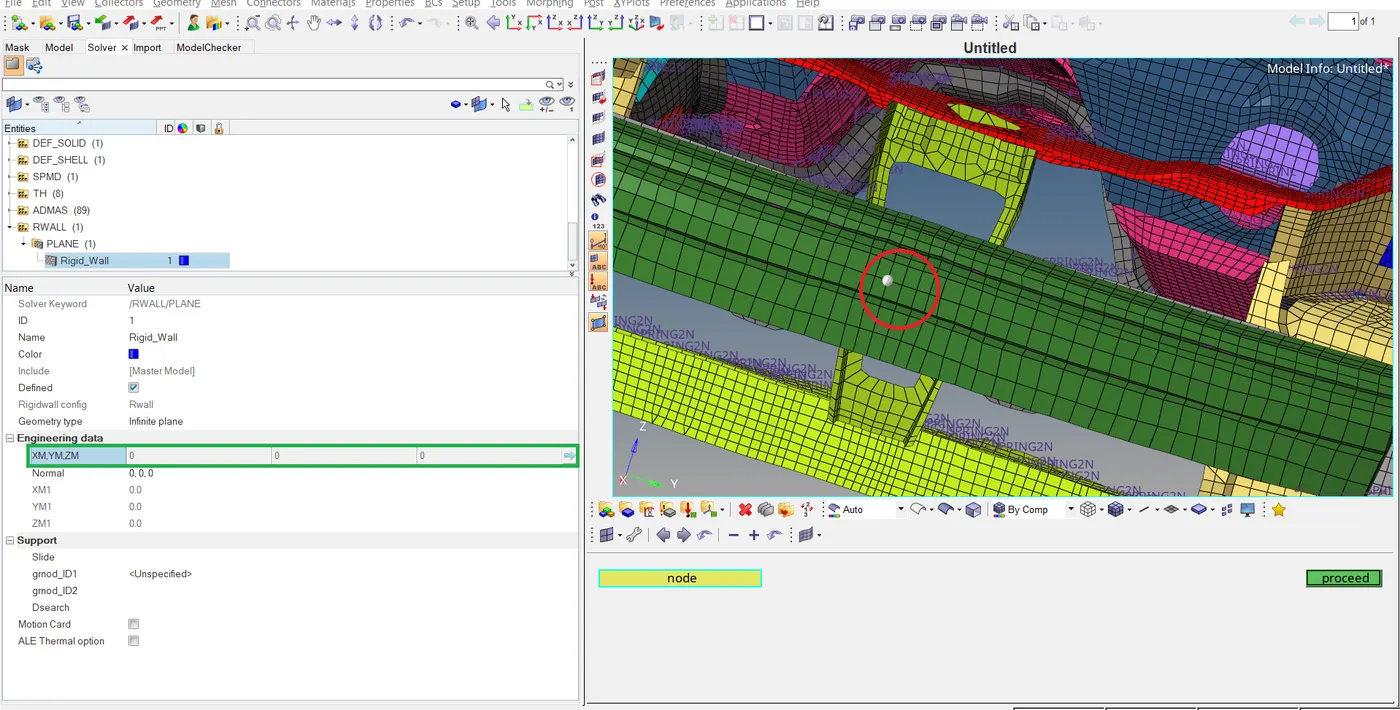
Creating the normal vector from the base node from x axis
Giving the support parameters i.e., slide with friction 0.1 and Dsearch 1000 for rigidwall
6.Compare the model weight with the full scale 300k nodes model and added mass to reach target weight 700kg while getting the CG about the required range.
Sol: Checking the initial mass and CG point
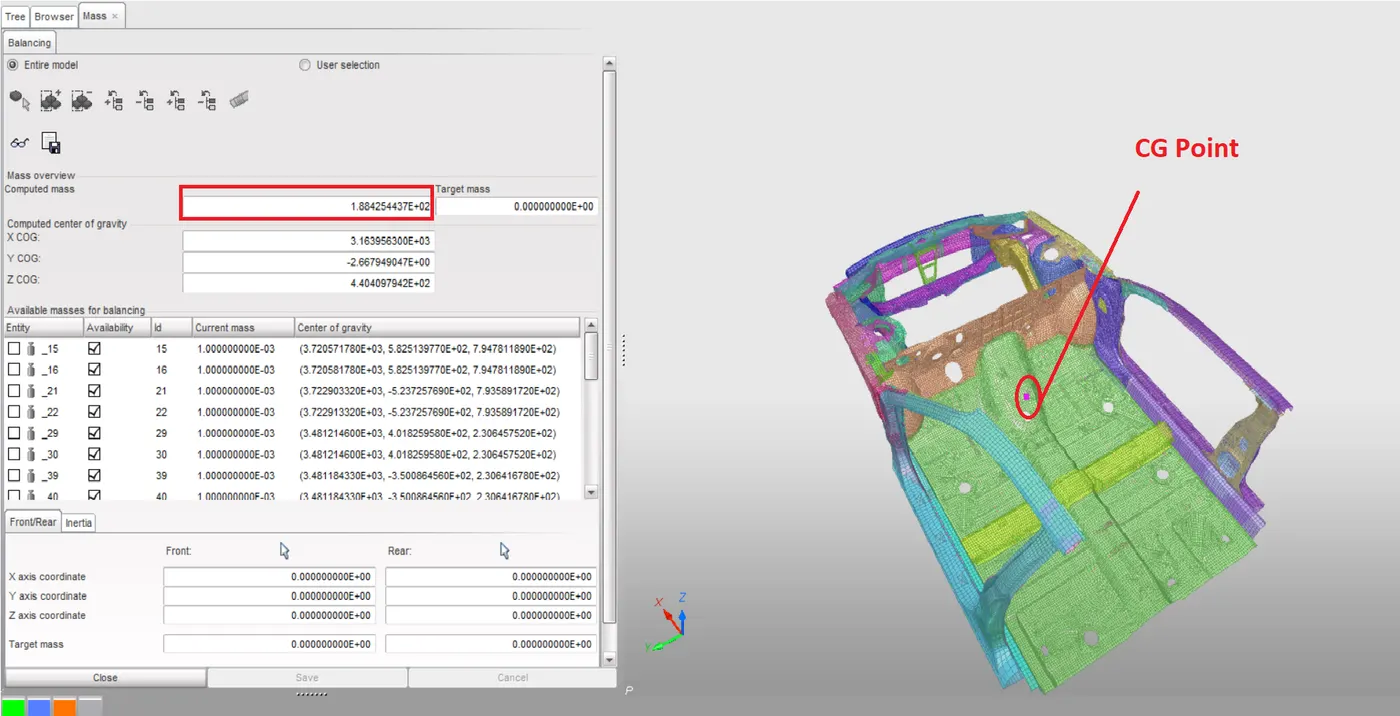
The initial mass is 188.425kgs and cg point is located at the front of the driver seats.
Additional mass is added to the floor area of the car by using the option Mass is distributed each node group which are selected in floor area.
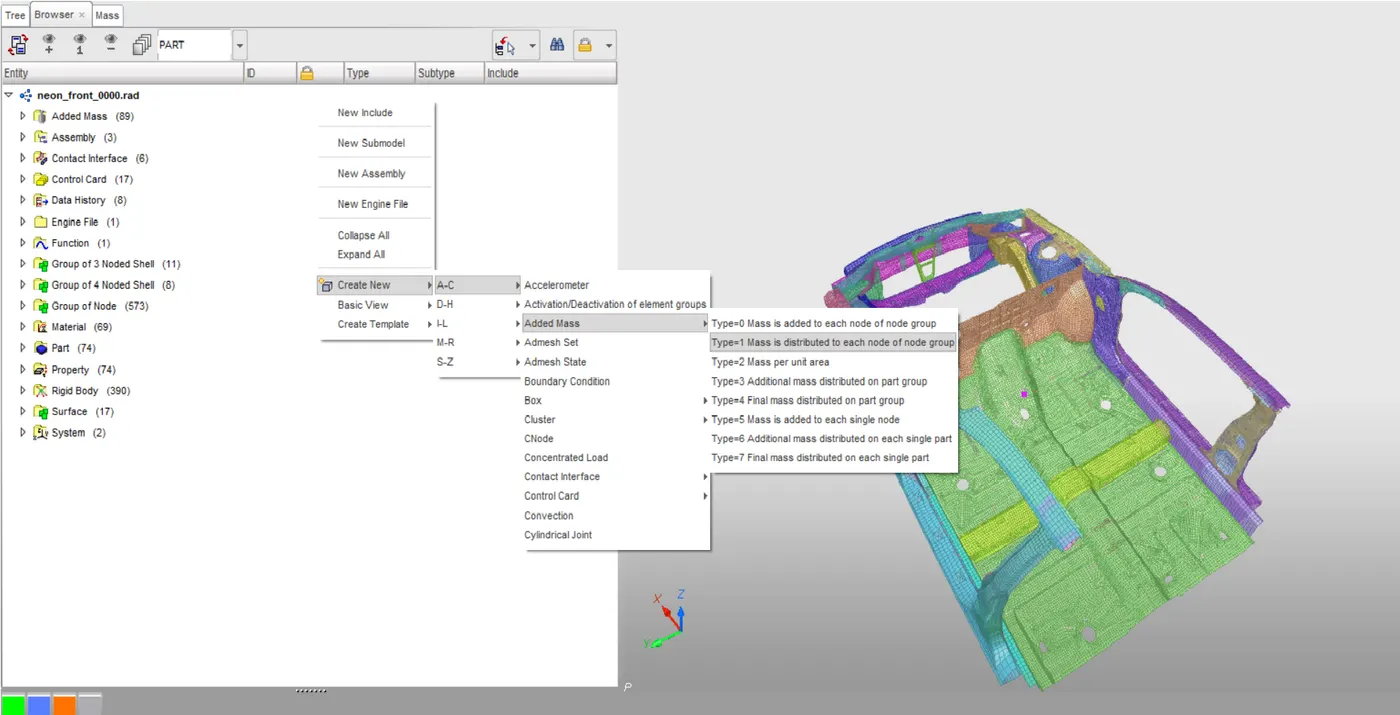
Adding the additional mass 511.574556kgs to floor area by selecting required nodes to increase mass to reach target mass 700kgs.
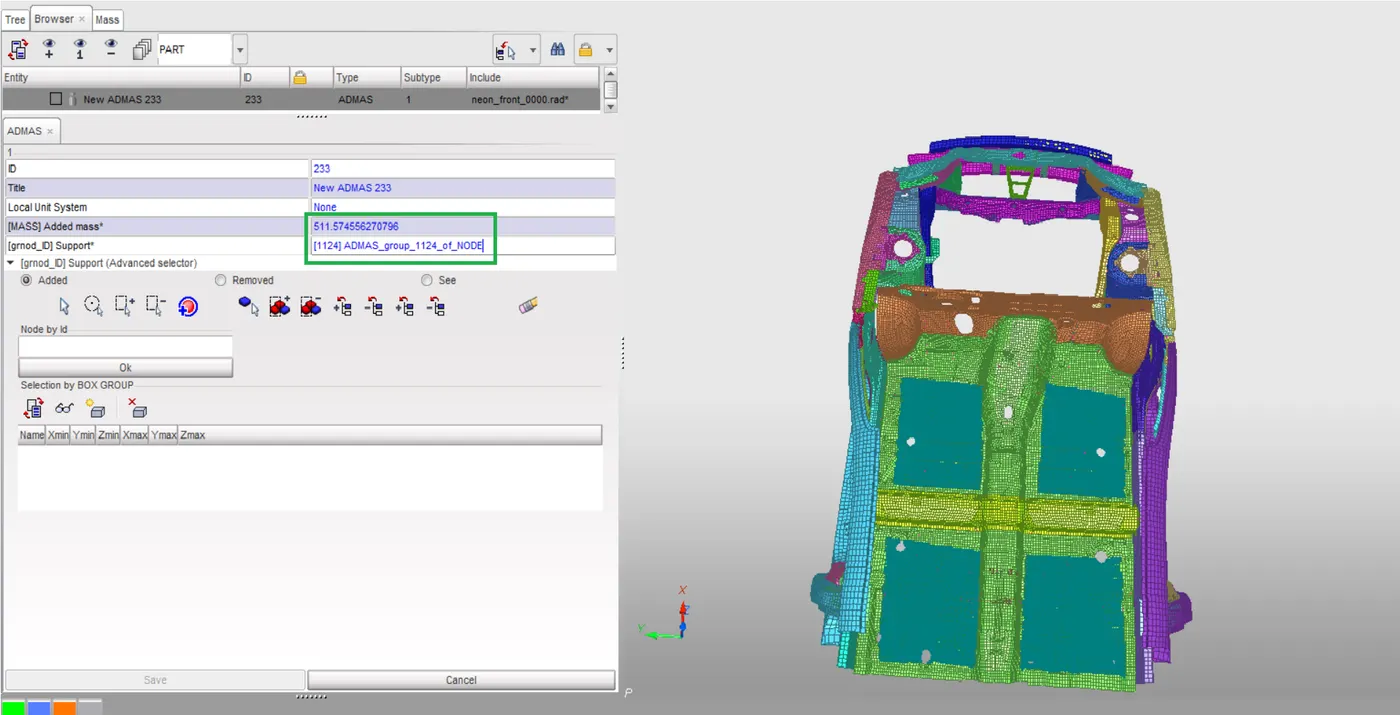
Checking the mass and cg point location after creating the additional mass
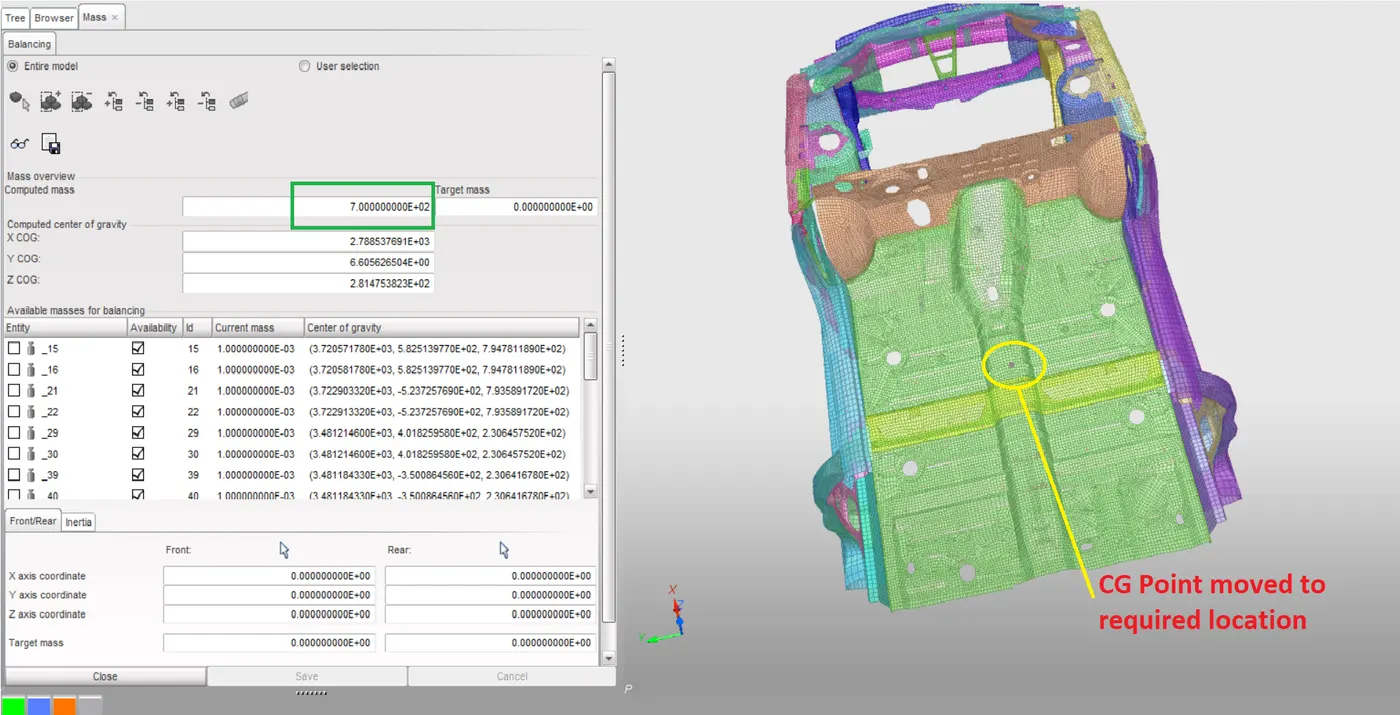
So, the CG point is moved to required location of floor area and mass is reached to 700kgs as shown in above picture.
7.Initial velocity 35mph.
Sol: Converting the 35mph to mm/ms. 35mph is equal to 15.6464mm/ms.
Selecting the node group on which the initial velocity are applied by Grnode_id.
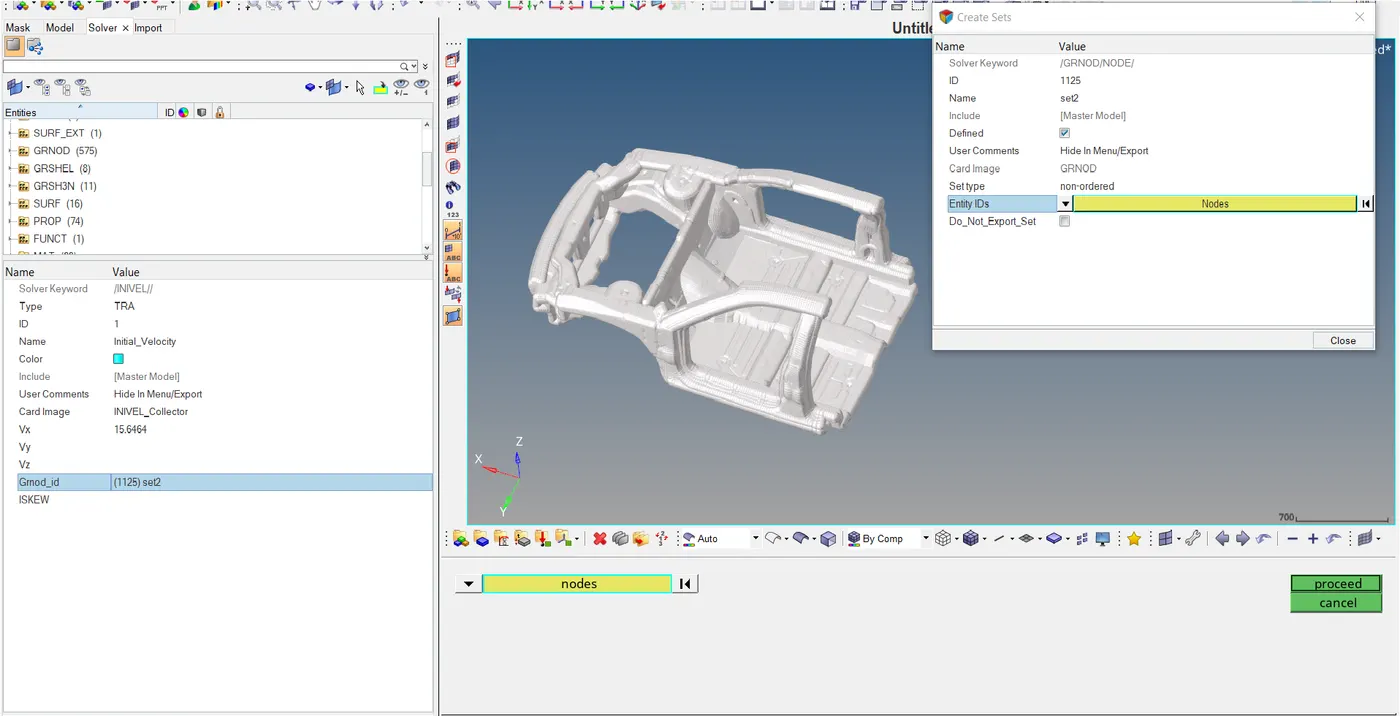
8.Use model checker to ensure good quality.
Sol: Open the model checker by going the Quality option on menu bar and hit run.
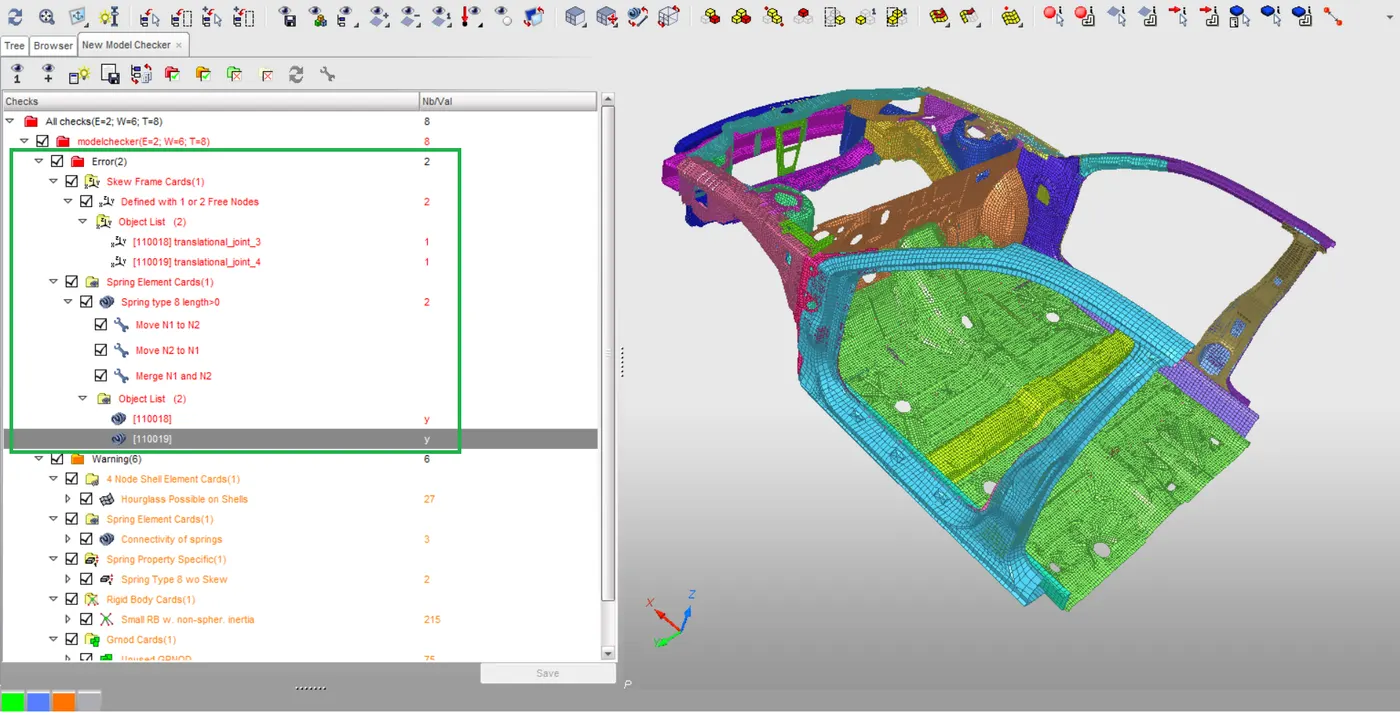
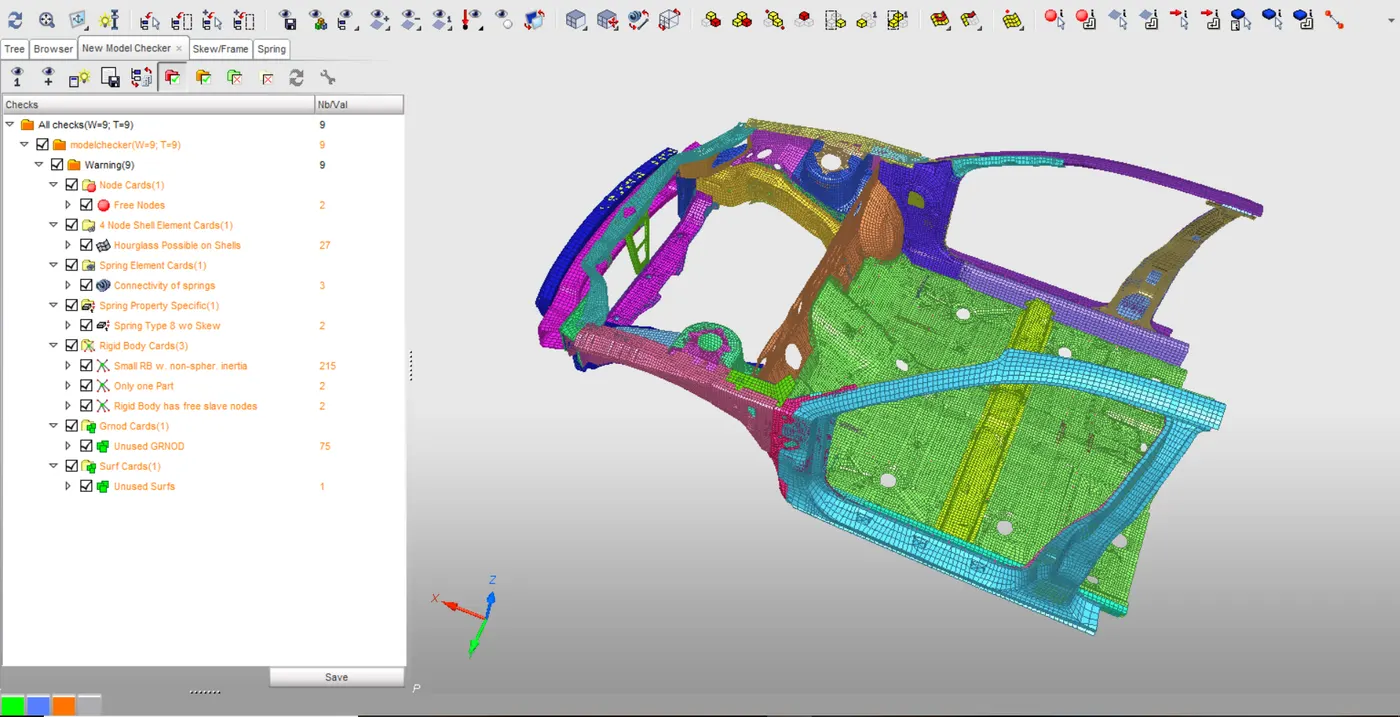
Checking the errors on the component
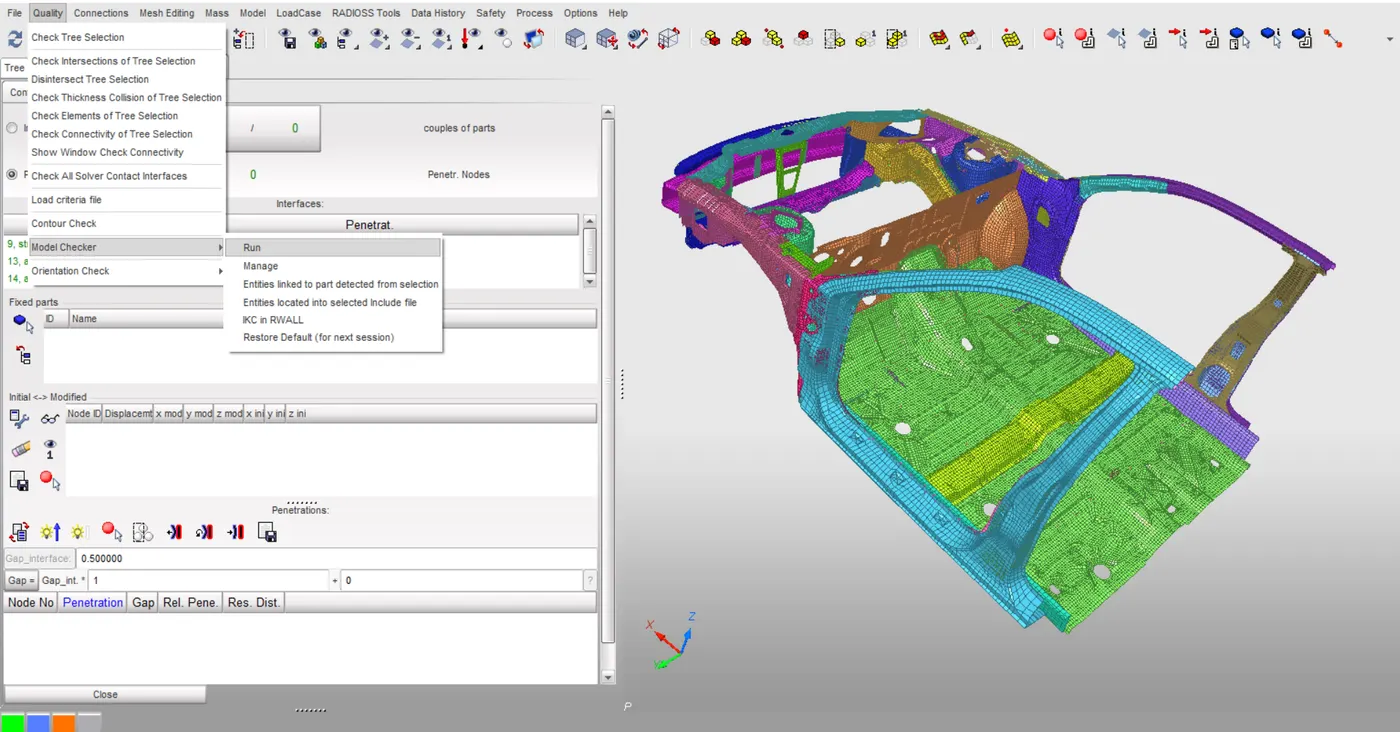
Correcting the Errors in the model by deleting the errors or rectifying the errors in it.
Hence the model is error free.
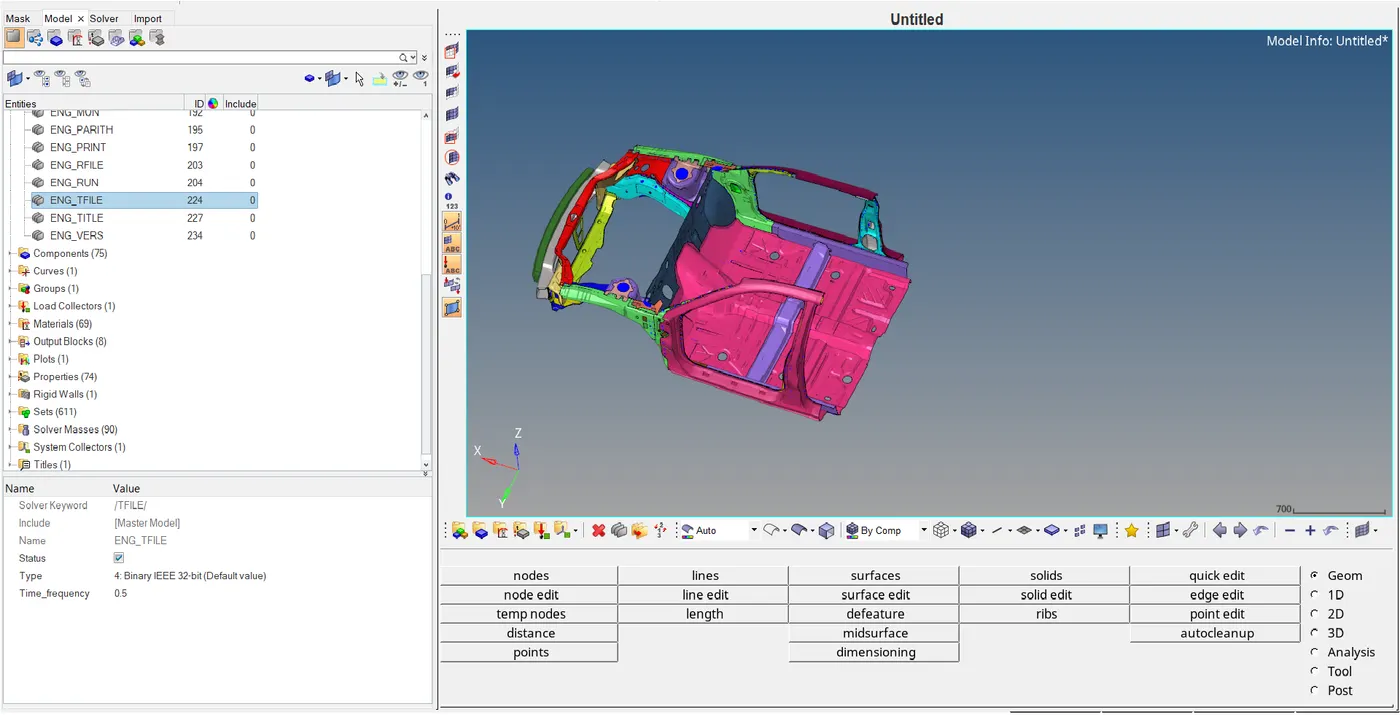
9.Time step 0.5 to 0.1 microseconds.
Sol: Checking the ENG_TFILE frequency for 0.5ms.
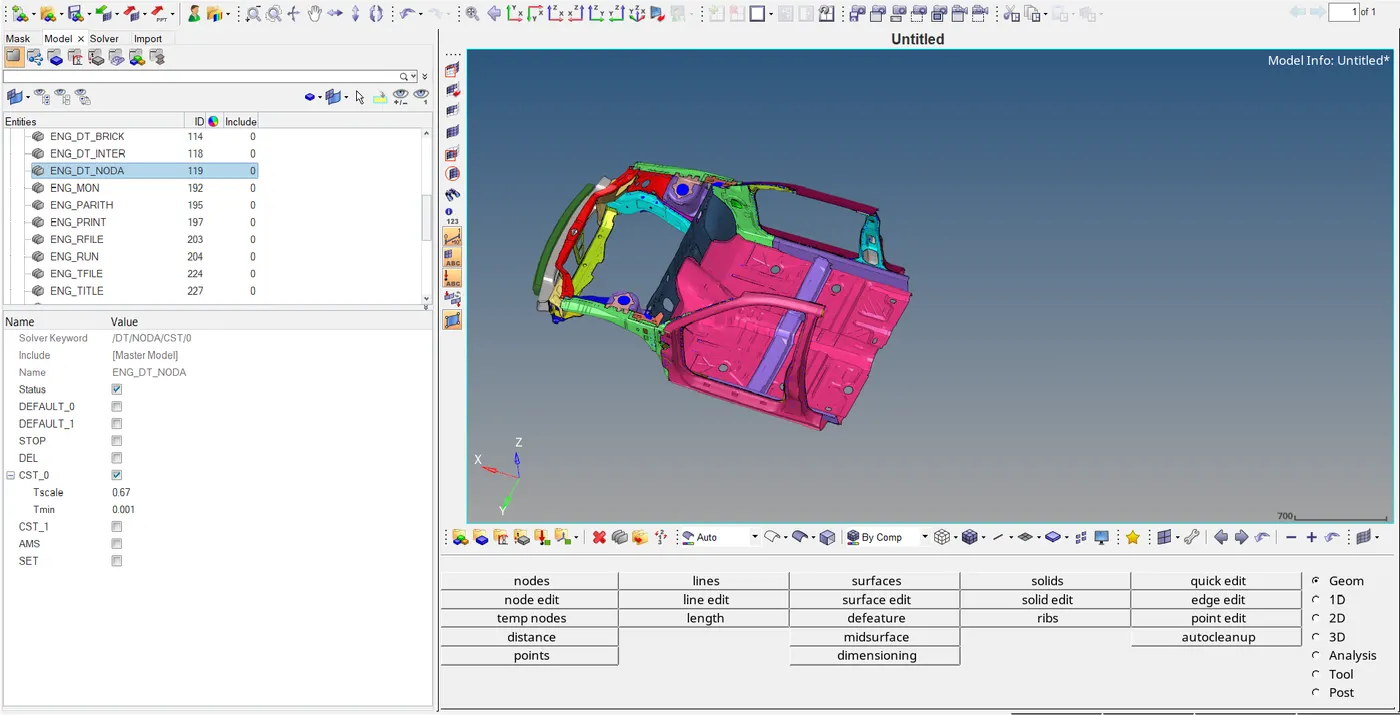
Checking the Element time step control card by DT/INTER/CST. By this the added mass on the contact when time step drops.
10.Run 80ms.
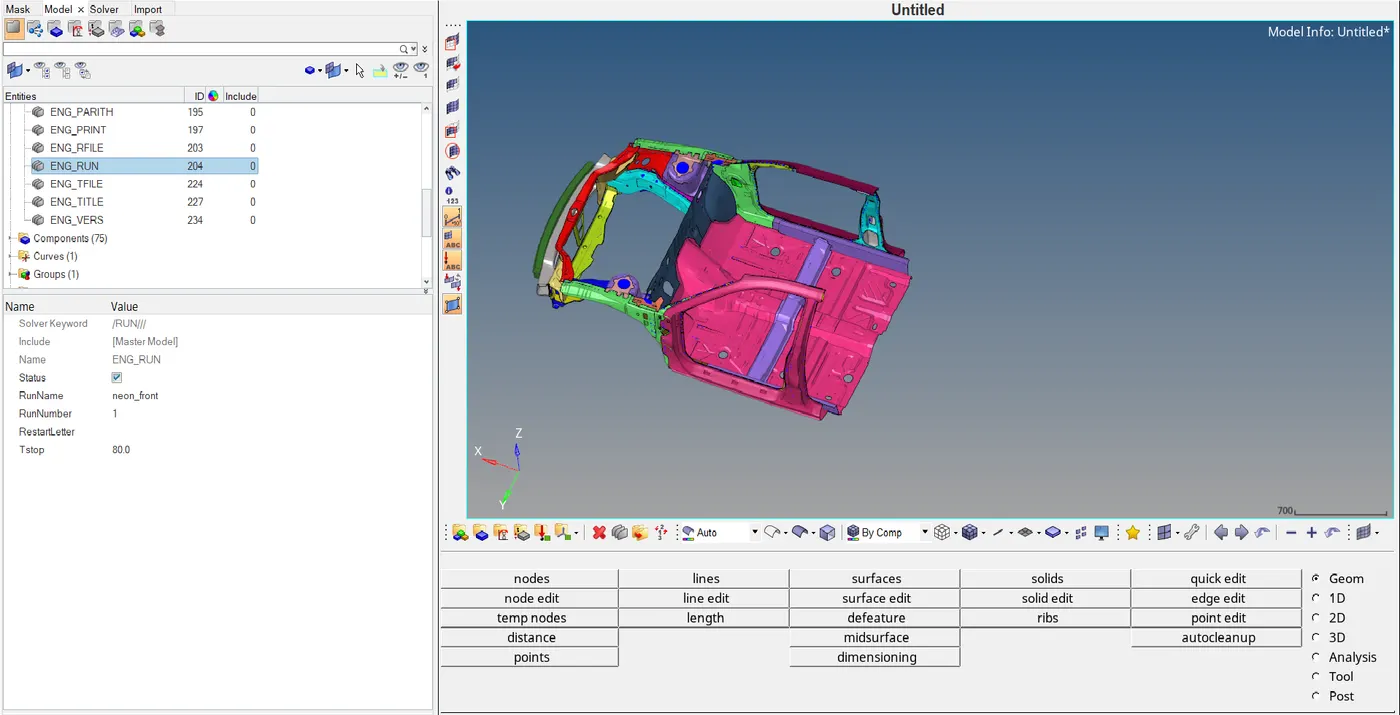
Sol: Checking the run time Tstop for 80ms in model browser cards entitie.
Output Requests:
After running the simulation review the starter output file neon_front_0001.out file with a text editor and check the total number of cycles, energy error and mass error at the end of computation.
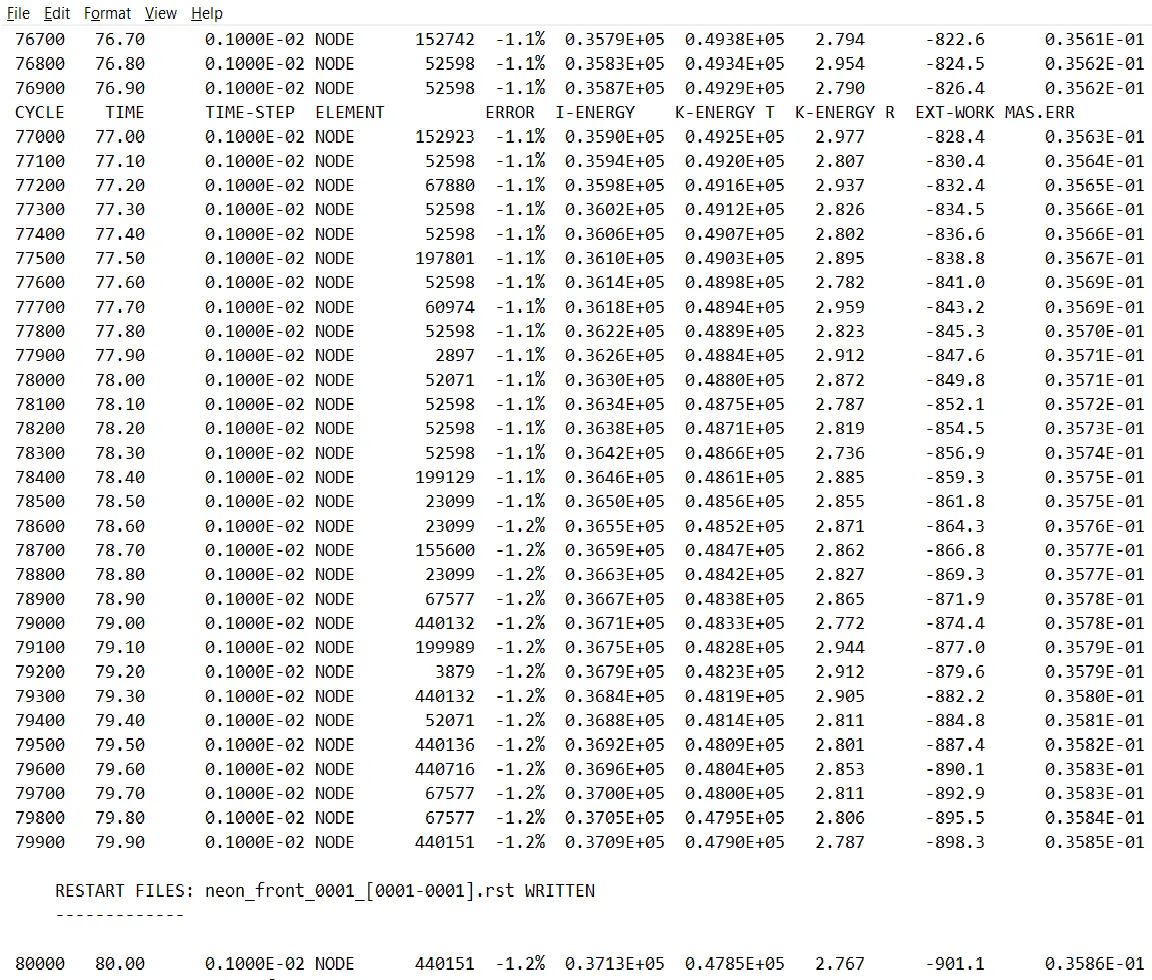
The energy error -1.2% and mass addition 0.3586E-01 are acceptable results for plotting the graphs. The simulation time is 3168.03sec and total number of cycles to complete the simulation is 80001.
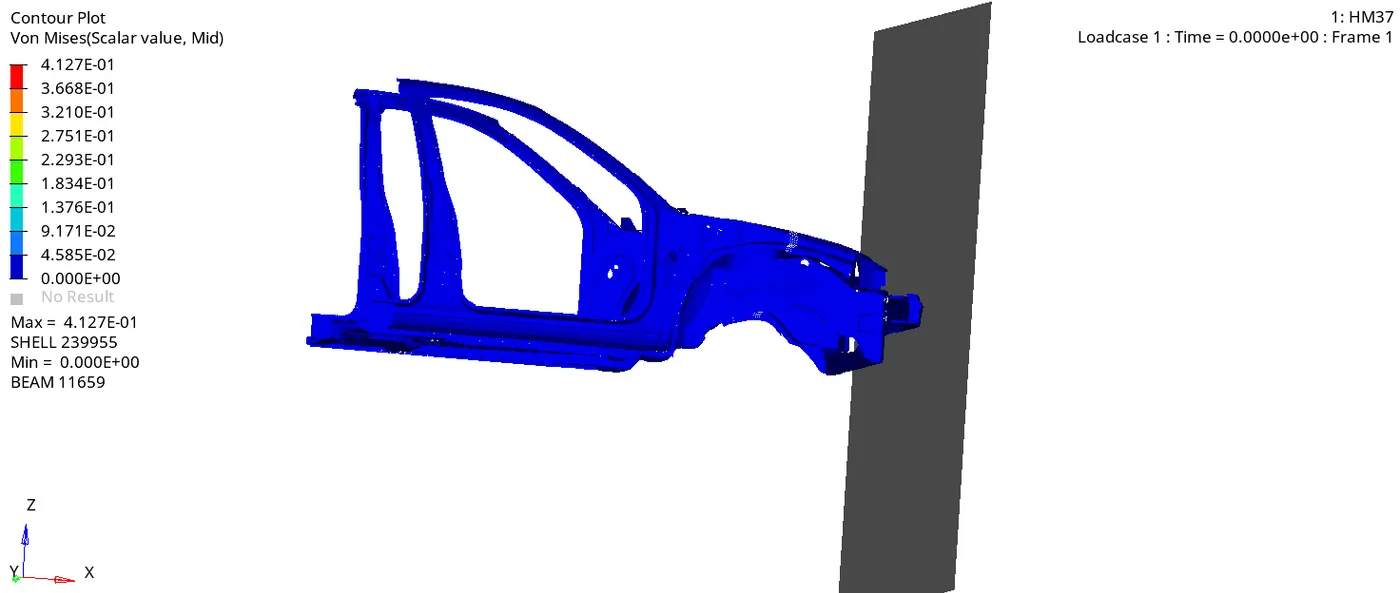
Contour plot of Von Mises
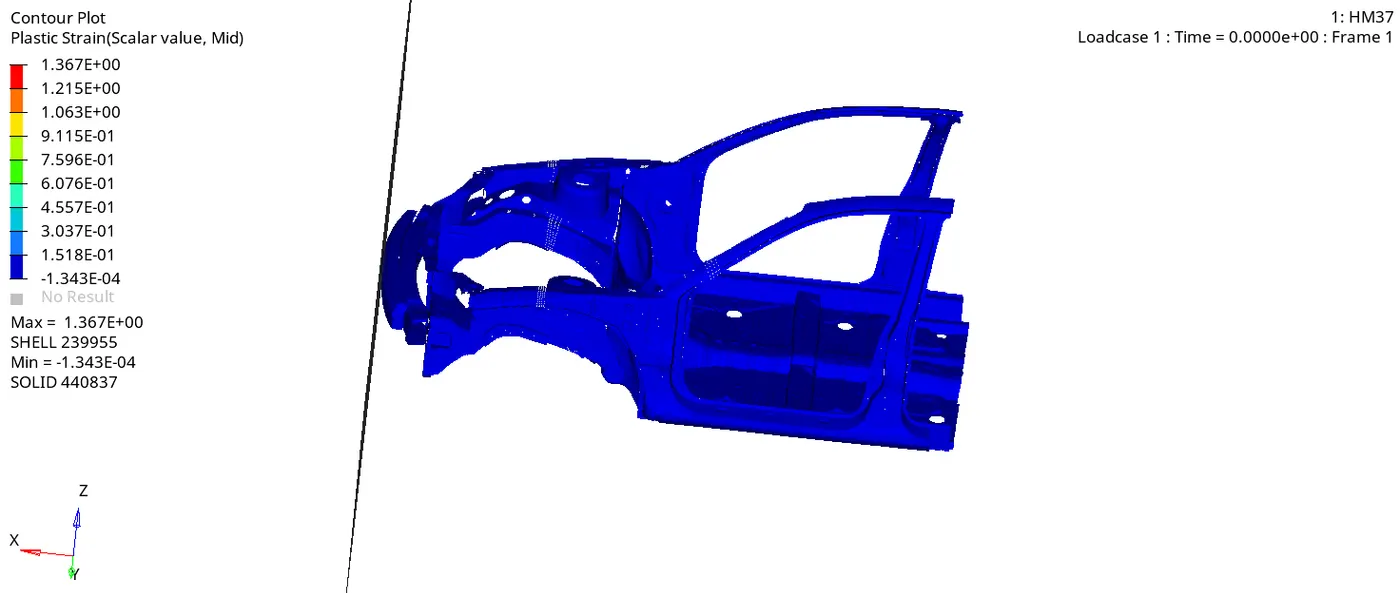
Contour plot of Plastic strain
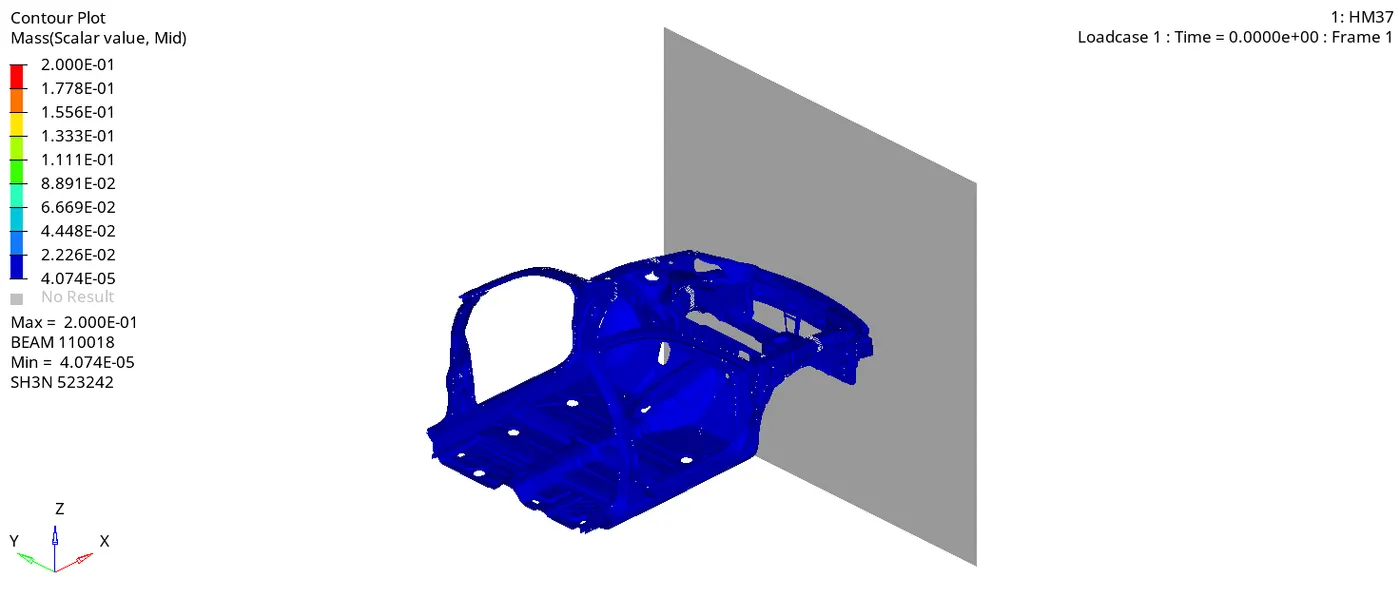
Contour plot of Mass
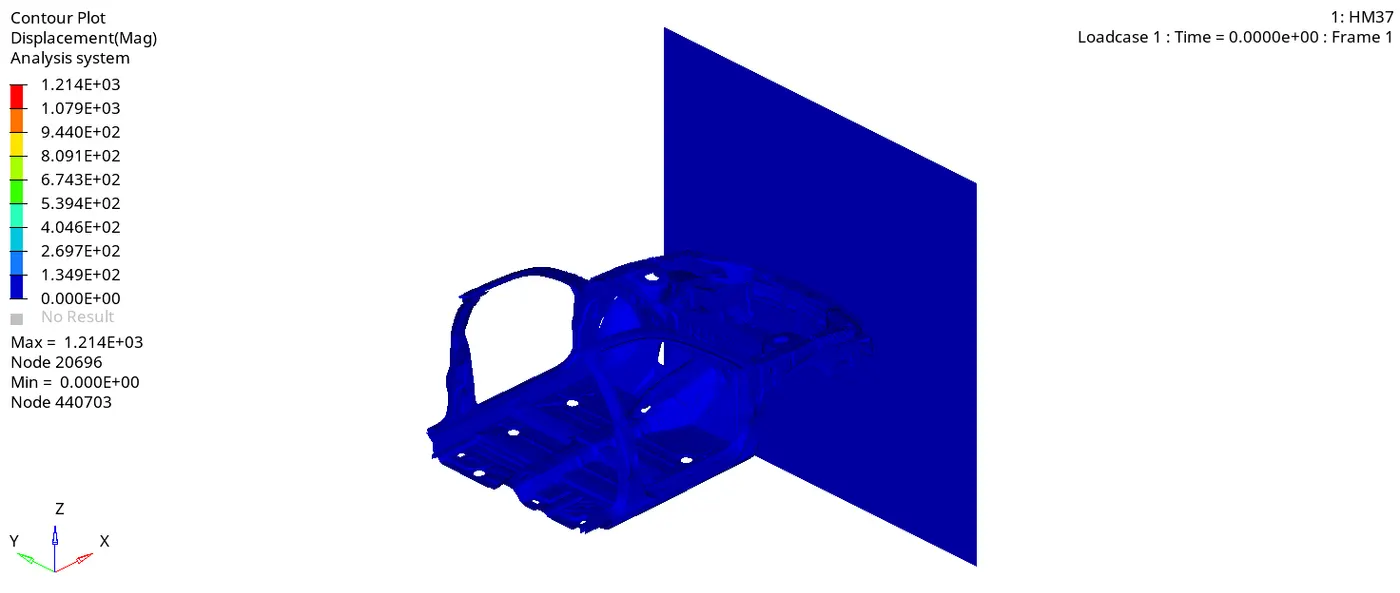
Contour plot of Displacement
1.Sectional force in the rails at location of indicated node 174247 and Axial force received on the rails from bumper.
Sol: Creating new cross section at left rail at indicated node 174247 and right rail for defining the sectional force and axial force from bumper. Then define the N1, N2, N3, nodes at particular location by grnod_ID, select elements in between the selected nodes grshel_id, ISAVE, delta T, alpha & Iframe.
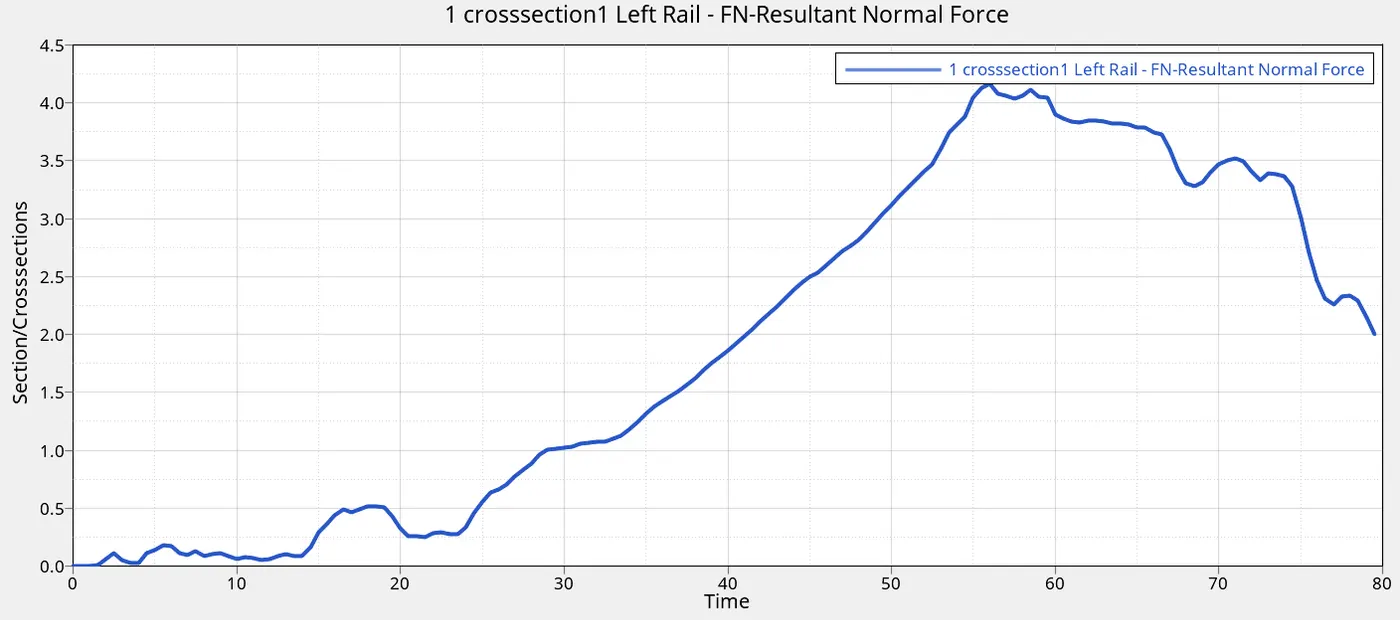
Left rail:
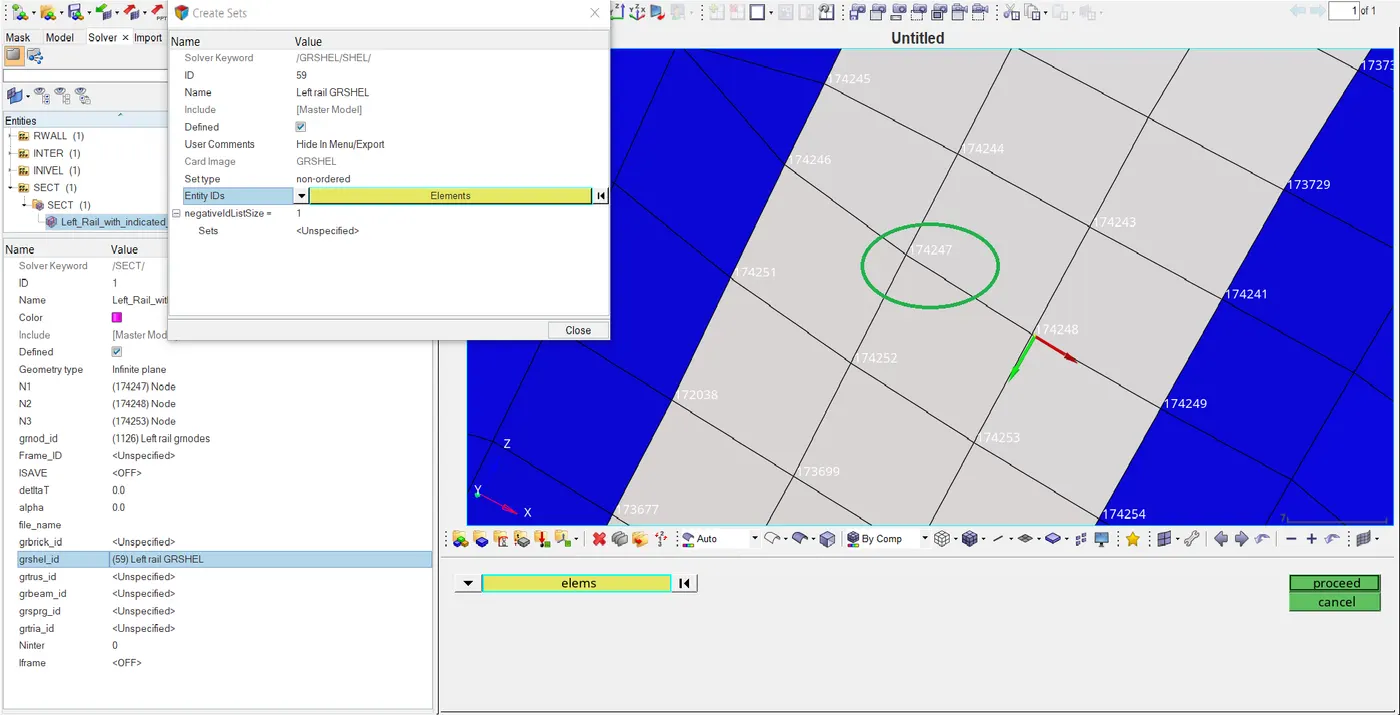
FN Resultant force at left rail at the location of indicated node 174247 is 4.169006KN
Right rail:
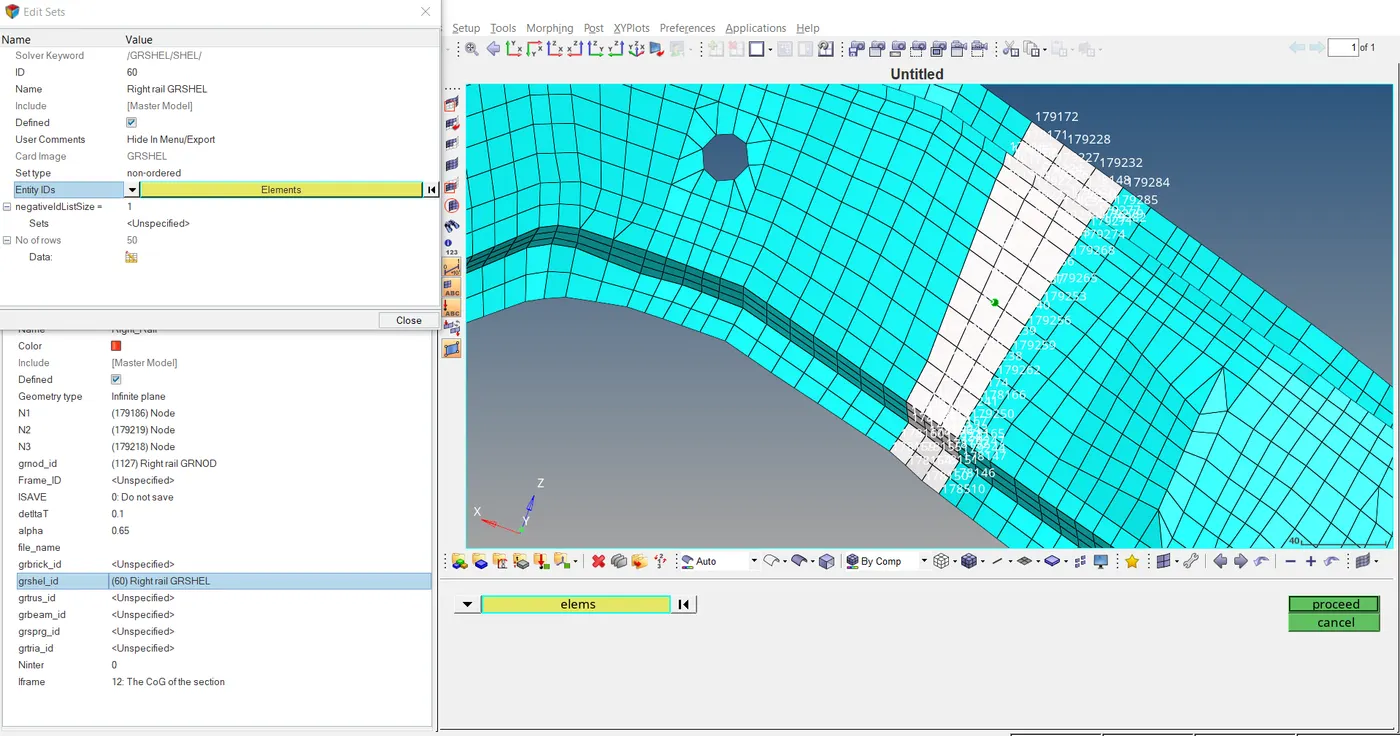
FN Resultant force at right rail as shown in the graph
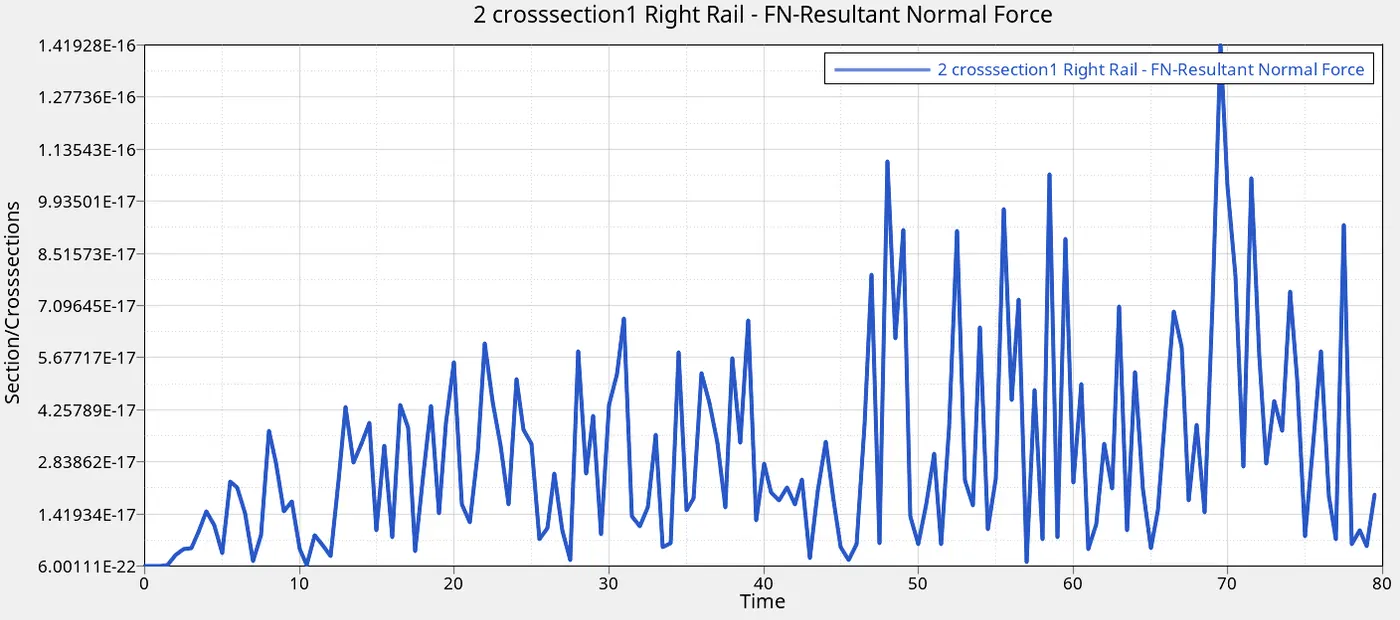
2.Shotgun cross sectional forces.
Sol: Creating cross section for two short guns and assign the parameters which are required.
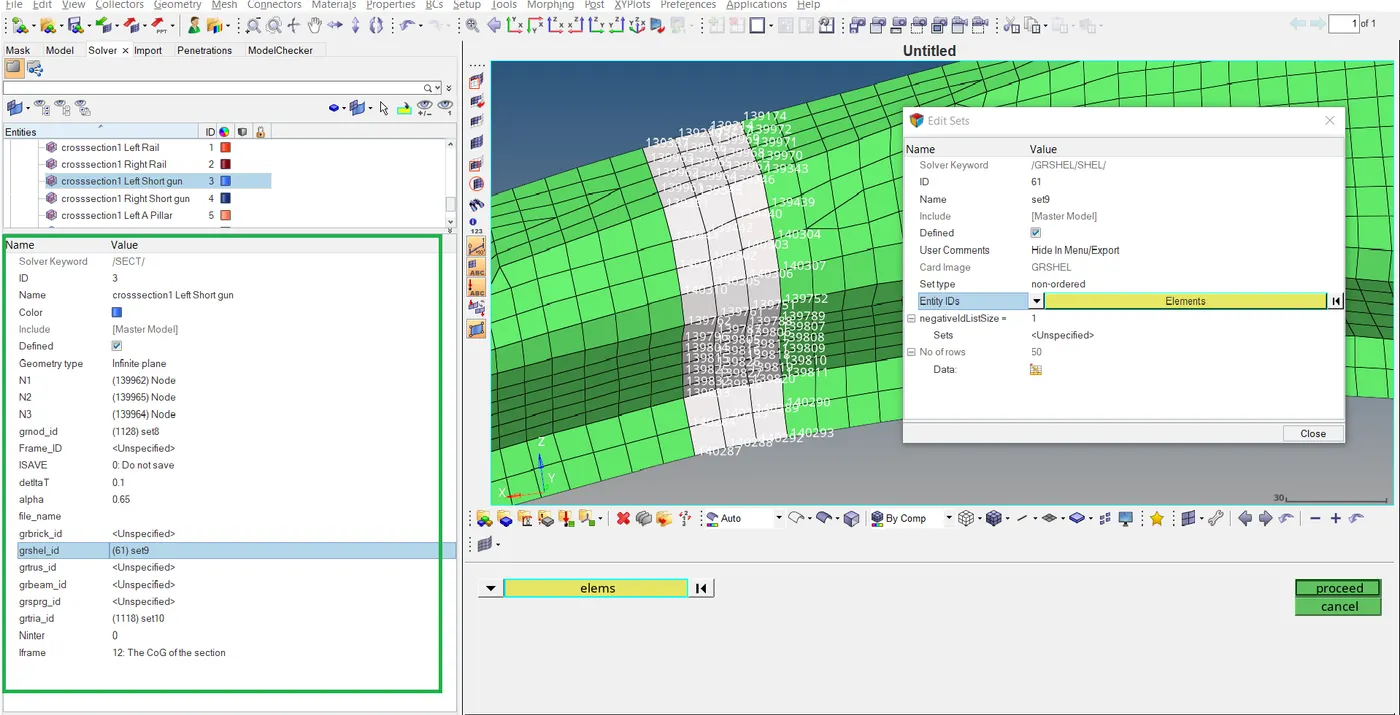
FN Resultant force at left short gun as shown in graph
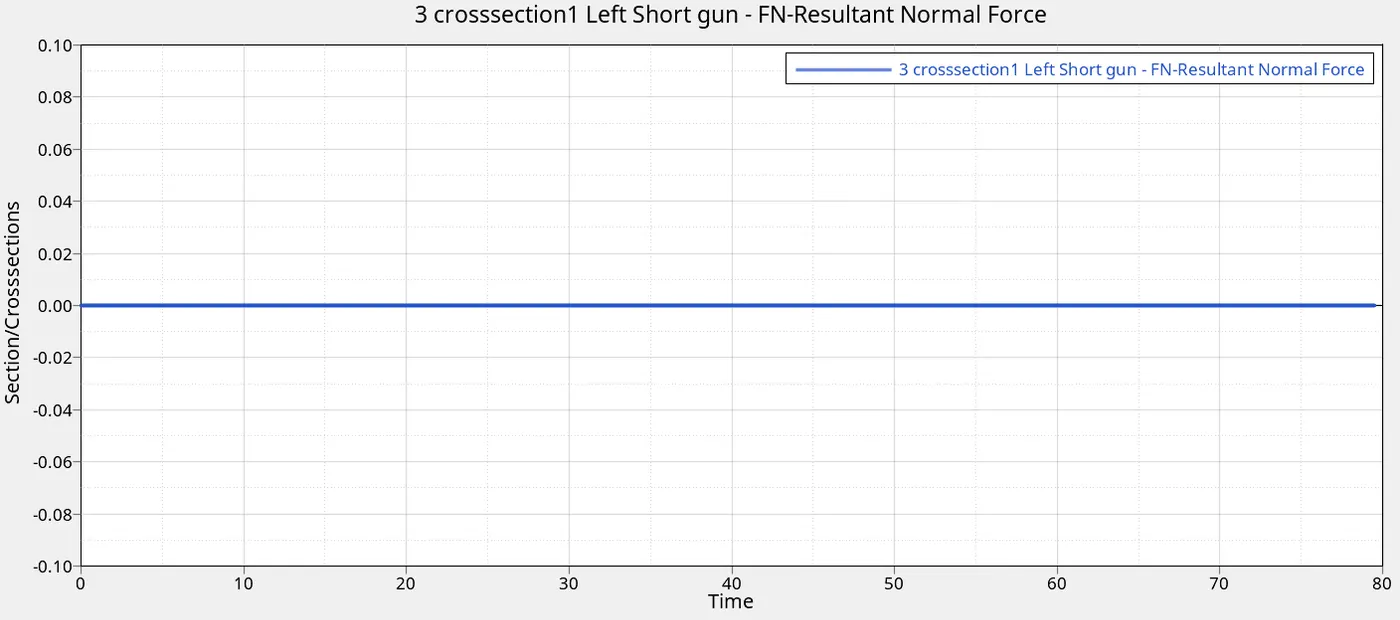
FN Resultant force at right short gun as shown in graph
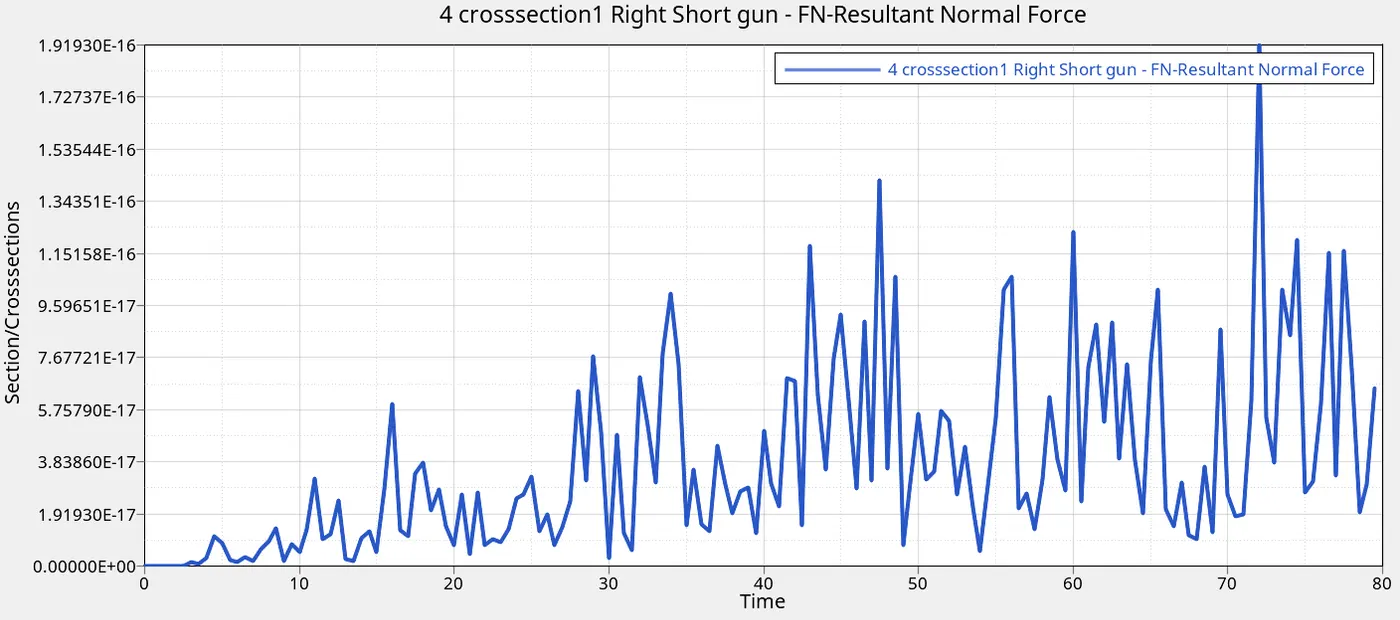
3.A pillar cross section.
Sol: Creating cross section for two A pillars and assign the parameters which are required.
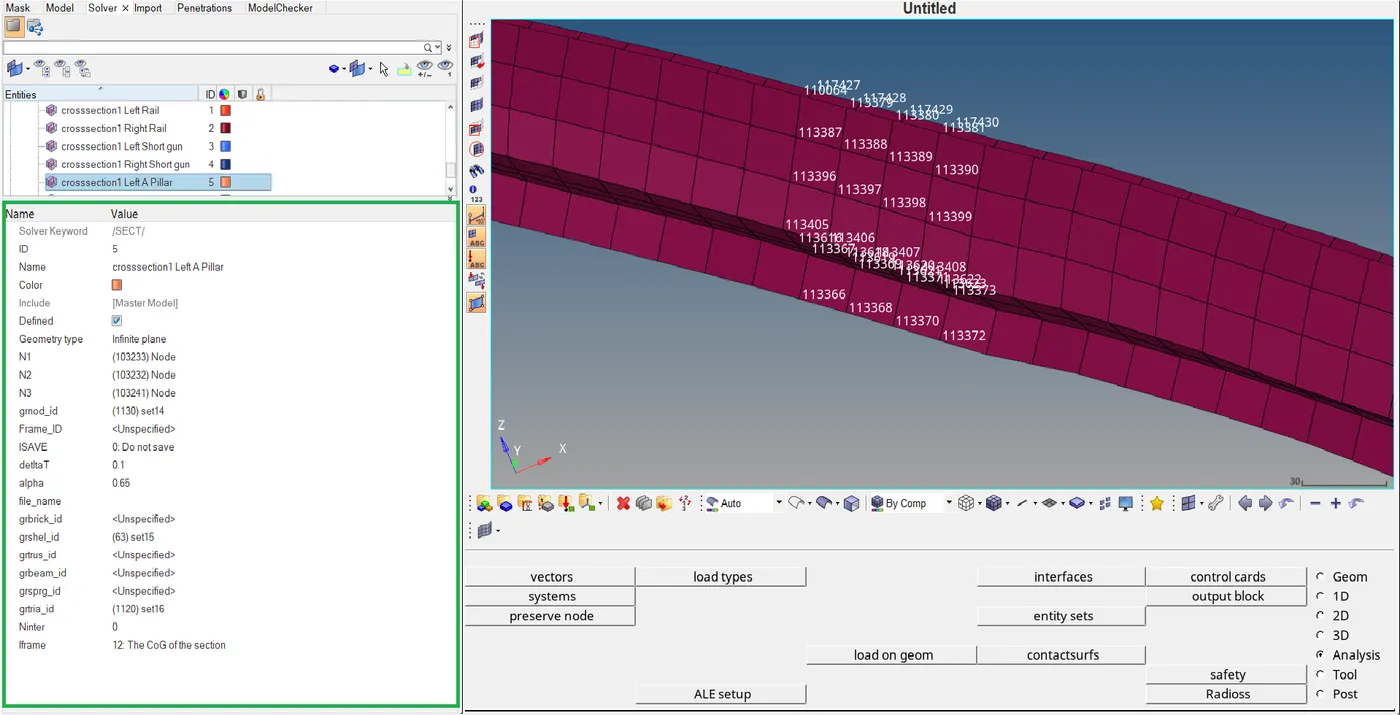
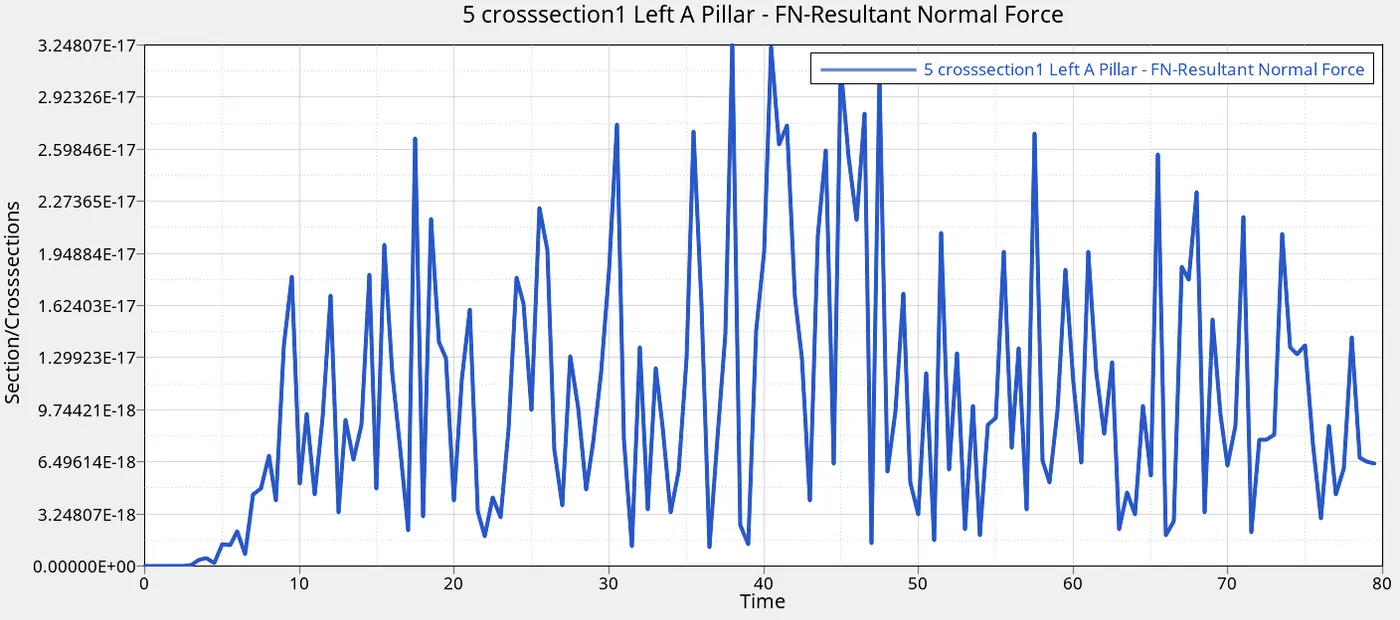
FN Resultant force at left a pillar gun as shown in graph
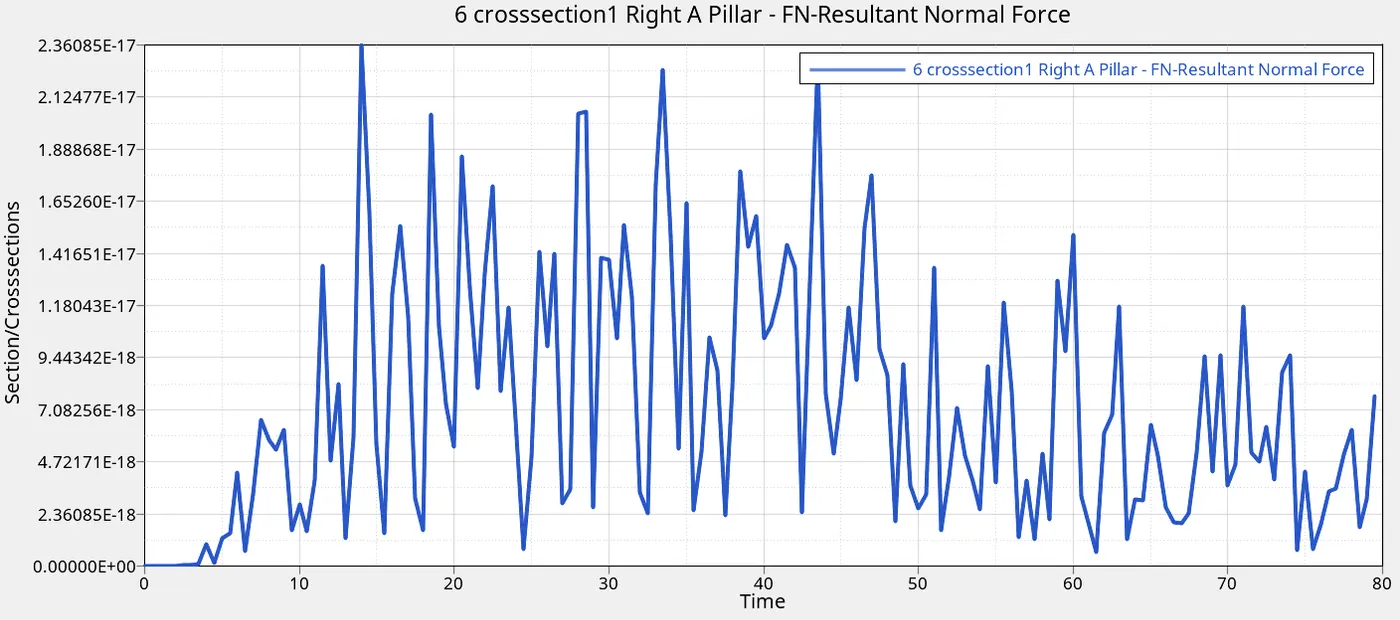
FN Resultant force at right a pillar gun as shown in graph
4.Acceleration curve received on the accelerometer at base of B pillar (on B pillar rocker).
Sol: Creating the two accelerometers below the B pillar rocker for defining the accelerometers.
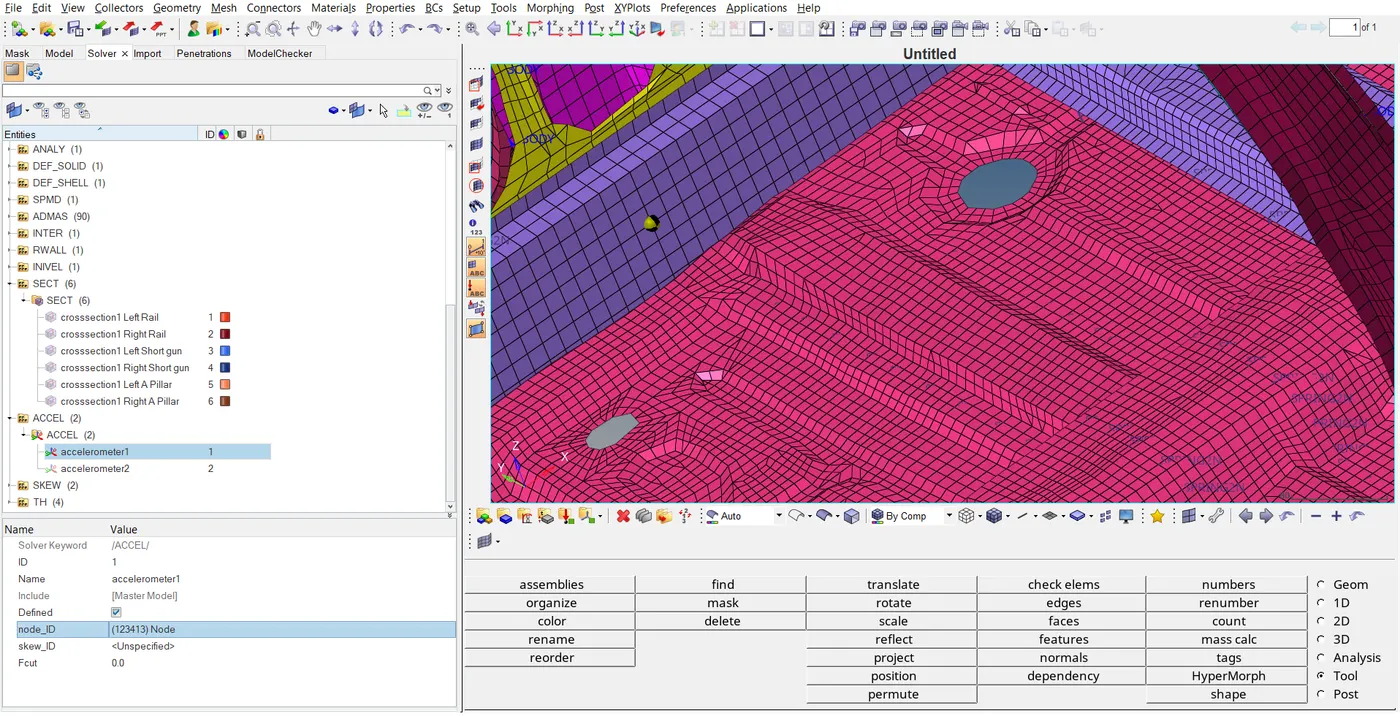
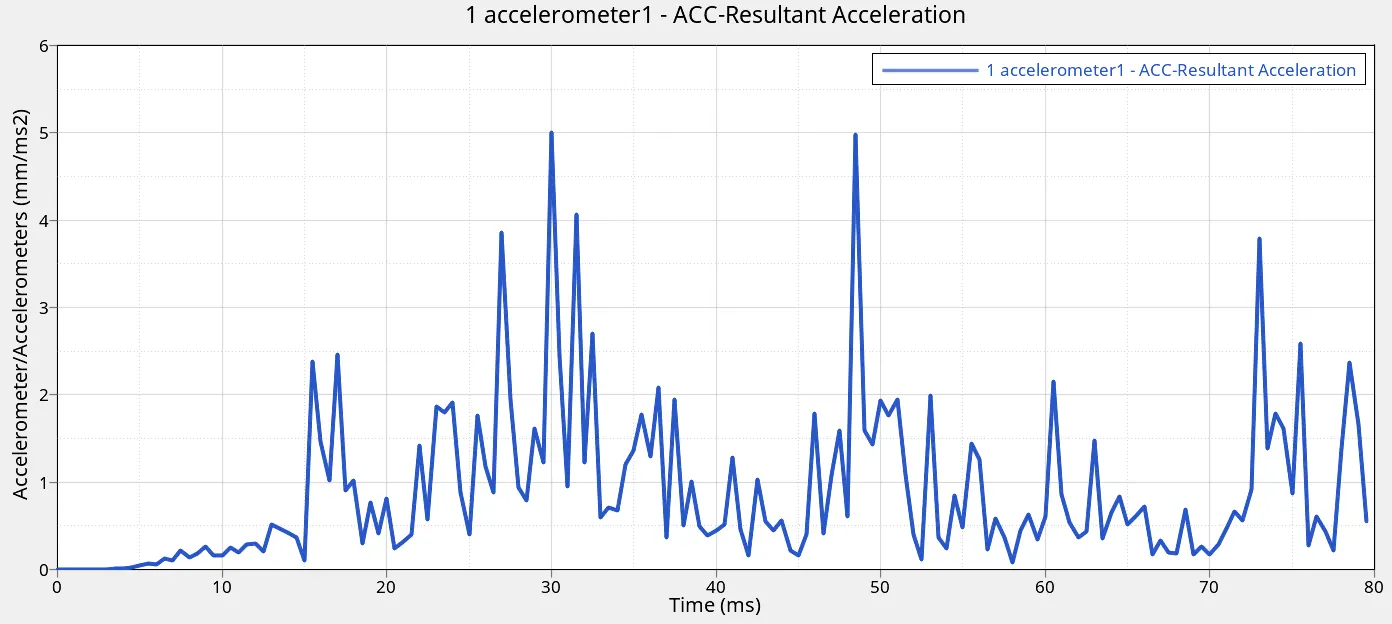
Resultant acceleration for accelerometer 1 is 5.006 mm/ms2.
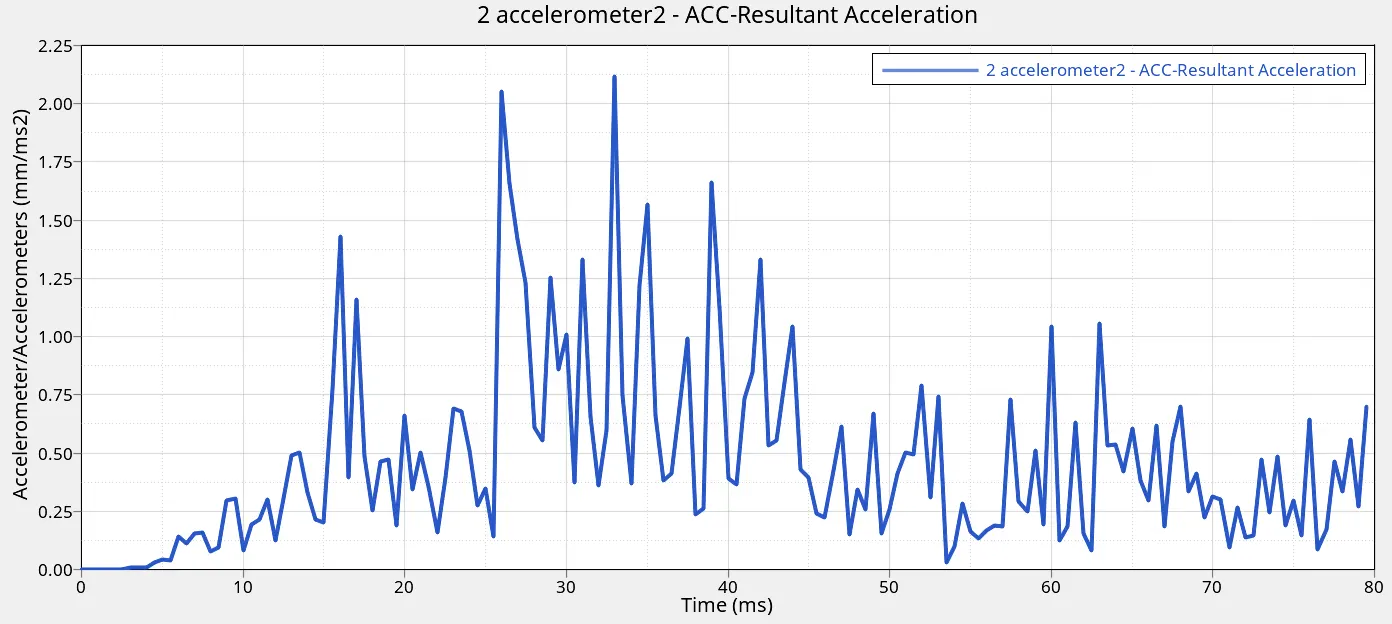
Resultant acceleration for accelerometer 2 is 2.118742 mm/ms2.
5.Intrusions on the dash wall 66695, 66244.
Sol: Creating the intrusions at given nodes for defining the how area is come into the dash wall after the crash.
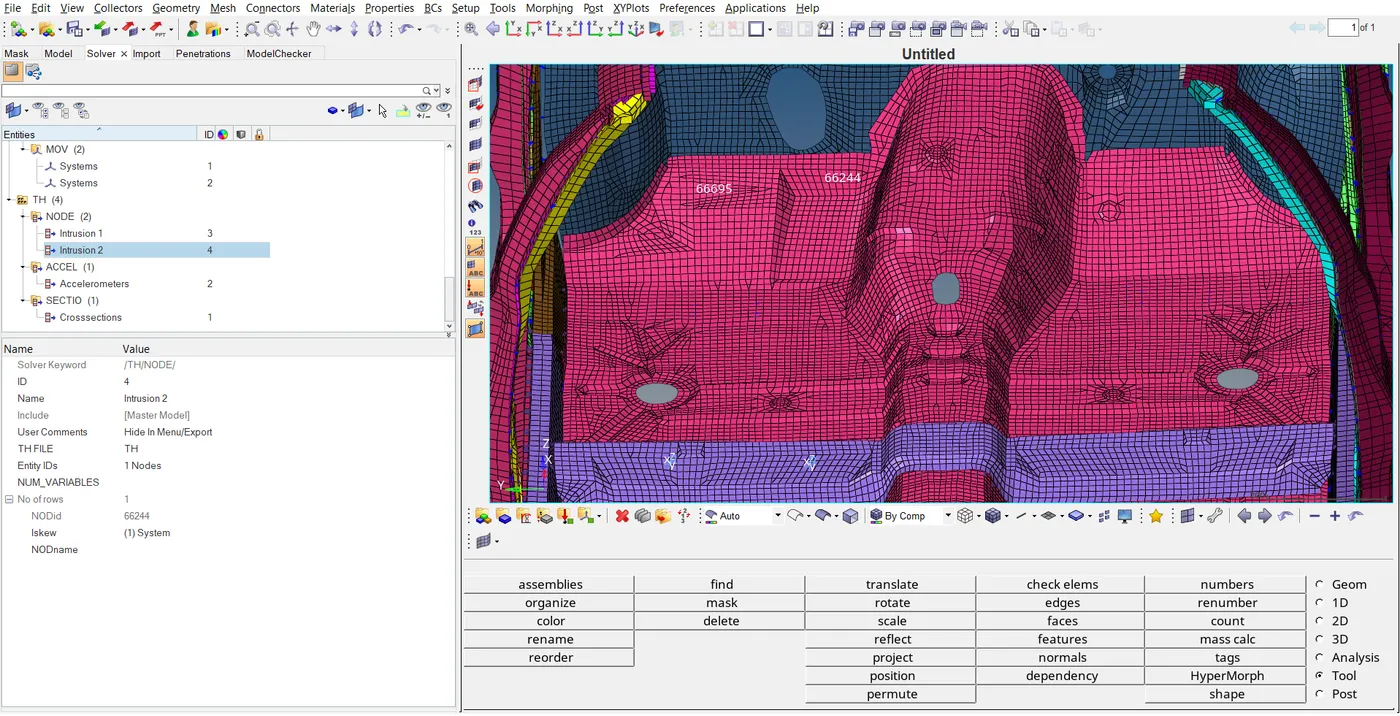
Resultant Displacement for intrusion 66695 is 910.567932mm.
Resultant Displacement for intrusion 66244 is 909.583679mm.
Result:
The simulation is set up by creating a rigid wall for the model to impact mass balancing is done to achieve a target load of 700kgs and GC at a specified coordinate is done successfully. Various output results like Resultant accelerations from two accelerometers, Normal resultant force from six different cross sections (i.e., A pillars, rails and short guns) , Resultant displacement from two intrusions are calculated and plotted in the graphs.
Conclusion:
By this project I am able to learn about how to create the interface for all nodes and elements, how to create rigid wall with friction 0.1, how to adding the mass to reach target 700kgs and to locate CG at particular location, creation of initial velocity, how to check and eliminate the penetrations, interactions, rigid bodies and errors in the model & creating the different output blocks for calculating the displacements at intrusions, accelerations from accelerometers and normal resultant forces from different cross sections.
G-drive link:
https://drive.google.com/open?id=14PdjV2Ac-_y7ITp7KfpVoQKae86d82B4