FORWARD KINEMATICS OF A 2R ROBOTIC ARM
AIM :-
CALCULATING THE POSITION AND MOMENT OF END EFFECTOR OF 2R ROBOT ARM BY USING MATLAB
OBJECTS:-
1.CALCULATING THE POSITION AND MOMENT OF END EFFECTOR OF 2R ROBOT ARM BY USING MATLAB
2.NEED TO UPLOAD AN ROBOT ARM ANIMATION ON YOU TUBE AND PROVIDE THE YOU TUBE LINK FOR AN ANIMATION IN MY REPORT
THEORY:-
A robotic arm (not robotic hand) is a type of mechanical arm, usually programable, with similar functions to a human arm; the arm may be the sum total of the mechanism or may be part of a more complex robot. The links of such a manipulator are connected by joints allowing either rotational motion (such as in an articulated robot) or translational (linear) displacement.The links of the manipulator can be considered to form a kinamatic chain. The terminus of the kinematic chain of the manipulator is called the end effector and it is analogous to the human hand.
Forward kinematics:-
Forward kinematics refers to the use of the kinamatic equations of a robot to compute the position of the end-effector from specified values for the joint parameters.
Kinematics equations
The kinematics equations for the series chain of a robot are obtained using a rigid transfermation [Z] to characterize the realative moment allowed at each joint and separate rigid transformation [X] to define the dimensions of each link. The result is a sequence of rigid transformations alternating joint and link transformations from the base of the chain to its end link, which is equated to the specified position for the end link,
- {\displaystyle [T]=[Z_{1}][X_{1}][Z_{2}][X_{2}]\ldots [X_{n-1}][Z_{n}],\!}
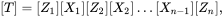
where [T] is the transformation locating the end-link. These equations are called the kinematics equations of the serial chain.
IMAGE OF WHAT ARE THE FACTOR NEED TO CONSIDER ON ROBOT ARM
PROGRAM TO CREATE ROBOT ARMS
clear all
close all
clc

%forward kinamatics of A 2R robotic arm manipulator

%inputs
l1=1.1;
l2=0.7;

theta1=60;
theta2=45;

%coordinates

x0=0;
y0=0;

x1=l1*cosd(theta1);
y1=l1*sind(theta1);


x2=x1+l2*cosd(theta2);
y2=y1+l2*sind(theta2);

%plotting

line([x0 x1],[y0 y1],'linewidth',3,'color','g')
line([x1 x2],[y1 y2],'linewidth',3,'color','r')
RESULT AFTER PROGRAM
PROGRAM TO PROVIDE ANIMATION TO THE ROBOT ARM
clear all
close all
clc
%inputs

l1=1.2;
l2=0.7;

theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i=1:length(theta1);
     THETA1=theta1(i);
     for j=1:length(theta2)
         THETA2=theta2(j);

         x0=0;

         y0=0;

x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);


x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);

%plotting

plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([-0.5 2.2 -0.5 2.2])

pause(0.1)
m(ct)=getframe(gcf);
ct=ct+1;
     end
end

movie(m)
videofile=VideoWriter('forward_kinamatics.avi','uncompressed AVI');
open(videofile)
writeVideo(videofile,m)
close(videofile)
FINAL RESULT:-