Robotic Arm
Forward kinematics is the use of kinetic equations of a robot to calculate the position of the end-effector for a specified value for the joint parameter. The kinematic equations are used in robotics, computer games, and animations.
The essential concept of forward kinematic animation is that the positions of particular parts of the model at a specified time are calculated from the position and orientation of the object, together with any information on the joints of an articulated model.
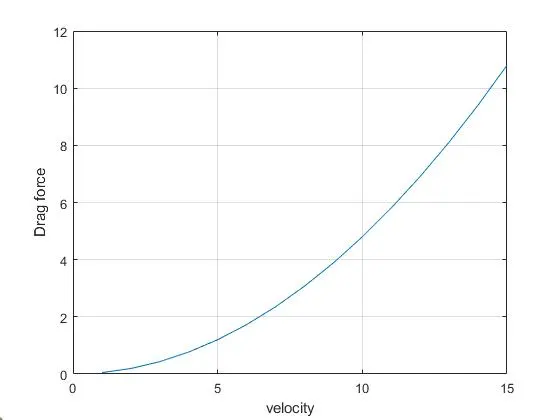
% program to calculate drag force on a bicycle (velocity vs drag_force)
% inputs
c_d= 0.8 % drag coefficient(cube,long_cylinder,cone,sphere,steamlined body)
A=0.1; % m2 % area
d=1.2; % kg/m3 % density
v=[1:15]; % m/s2 % velocity

%Formula
Drag_force=(d*A*v.^2*c_d)/2;

%plot
plot(v,Drag_force)
xlabel('velocity')
ylabel('Drag force')
grid on


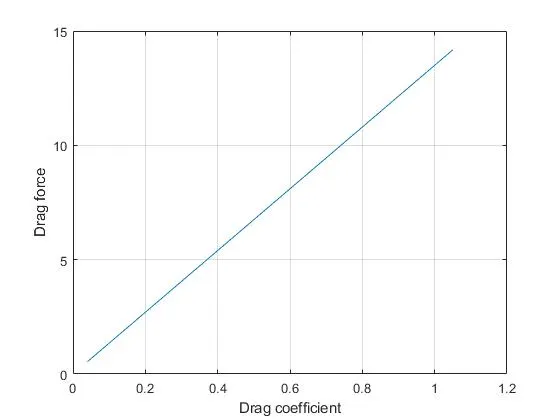
% program to calculate drag force on a bicycle(drag_coefficient vs drag_force)
% inputs
c_d= [1.05,0.82,0.50,0.47,0.04]; % drag coefficient(cube,long_cylinder,cone,sphere,steamlined body)
A=0.1; % m2 % area
d=1.2; % kg/m3 % density
v=15; % m/s2 % velocity

%Formula
Drag_force=(d*A*v.^2*c_d)/2;

%plot
plot(c_d,Drag_force)
xlabel('Drag coefficient')
ylabel('Drag force')
grid on